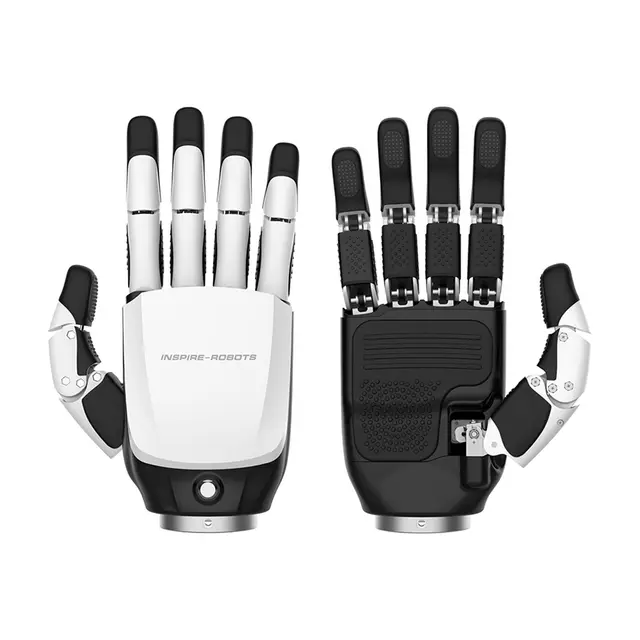
The Inspire RH56F1-E2R-T1 is the right-hand, tactile version of Inspire Robots' RH56F1 dexterous robotic hand: the same six-actuator, twelve-joint, all-metal hand as the RH56F1-E2R, with eight capacitive tactile sensors added in the fingertips and palm. It is the RH56F1 to choose when a robot has to feel where and how it touches an object, not only how hard each finger is pressing.
Each of the five fingertips carries a sensor that reports normal force, tangential force and the direction of that tangential force from 0 to 359°, plus a proximity value as the finger approaches a surface. Three more sensors cover the left, middle and right zones of the palm and report normal and tangential force with direction. The range is 30 N and the accuracy 5 % of full scale, with readings delivered in 0.01 N steps; tangential force and its direction are the readings a controller uses to detect slip.
The mechanics match the rest of the RH56F1 line. Six micro linear servo actuators, each with a force sensor at 0.1 N resolution, move 12 joints; fingertips push with at least 15 N and the thumb with at least 10 N, and they repeat to ±0.2 mm. The thumb rotates laterally through 60–180°, the hand closes in 0.8 s or less, and Inspire rates the passive payload at 30 kg. It weighs 620 g and is 183.3 mm long and 79.1 mm across the palm.
Tactile values come from their own registers next to each actuator's position, force, current and temperature, over the E2 interface: EtherCAT, or RS-485 with Inspire's open protocol or Modbus RTU, with 1 kHz real-time communication on a 24–48 V supply. Each finger can run speed-force protection, force closed-loop or impedance control. The wrist mounts on four 3.5 mm through holes, and fitment to your arm or humanoid is confirmed with the quotation.
For a two-handed robot, the RH56F1 tactile left hand (E2L-T1) is the mirror of this one. When finger force feedback is enough, the RH56F1 right hand without tactile sensors (E2R) has the same mechanics and interfaces. Compare the full range of dexterous robotic hands.
Key Capabilities
-
Eight capacitive tactile sensors: One sensor in each fingertip and three across the palm measure contact up to 30 N with 5 % full-scale accuracy.
-
Force direction, not just pressure: Fingertip and palm sensors report normal force, tangential force and its direction from 0 to 359°, in 0.01 N steps.
-
Proximity at the fingertips: Each fingertip sensor also returns a proximity value as the finger approaches a surface.
-
Six force-sensing actuators: Six micro linear servo actuators move 12 joints, and each reports finger force at 0.1 N resolution.
-
620 g all-metal right hand: The hand is 183.3 mm long and 79.1 mm across the palm, pushes at least 15 N per fingertip and is rated for a 30 kg passive payload.
-
EtherCAT and RS-485 at 1 kHz: The E2 interface combines both buses with 1 kHz real-time communication on a 24–48 V supply.
Buying through Robotix Market
This unit is sourced new through established distribution channels and ships worldwide with the manufacturer warranty. Technical support is coordinated with the manufacturer's own service network. Deployment scope, configuration, and commissioning responsibilities are agreed as part of the quotation — on-site installation is not included in the product price.