Середня ціна за день
Суми у валюті USD


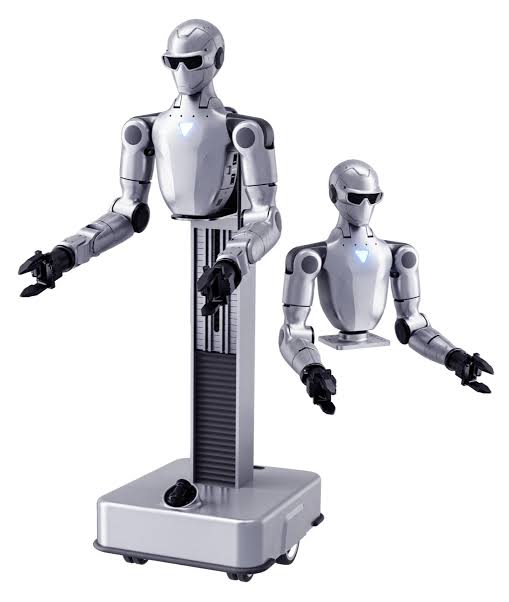
Fixed-Base Dual-Arm Humanoid Robot with Dex1-1 V2 Parallel Grippers & Onboard Orin Nano 40 TOPS. 13 DOF, 5-DOF precision arms, 60 Nm shoulder torque, binocular vision & full-stack open SDK. The entry point to humanoid research.

R1-A5 Smart A — fixed-base humanoid with Dex1-1 V2 parallel grippers & Orin Nano 40 TOPS
The R1-A5 Smart A is the entry-level configuration of the R1-A5 platform. You get the full fixed-base dual-arm humanoid body with binocular vision, voice interaction, and open SDK — paired with the reliable Dex1-1 V2 two-finger parallel grippers for standard pick-and-place, grasping, and manipulation tasks. The built-in Orin Nano 40 TOPS compute module enables on-device deep learning, visual perception pipelines, and larger model inference right out of the box.
The R1-A5 Smart A is engineered around two 5-DOF high-performance arms, each driven by low-inertia inner-rotor PMSM motors with crossed-roller bearings. With 420 mm reach, 60 Nm peak shoulder torque, and a ~2 kg payload per arm, it handles precise assembly, pick-and-place, and manipulation research with human-like fluidity. Dual encoders on every joint deliver closed-loop precision down to ±0.1 mm.

Dual 5-DOF arms with Dex1-1 V2 parallel grippers for reliable pick-and-place and manipulation
The Dex1-1 V2 is a robust two-finger parallel gripper designed for speed and consistency. It excels at grasping regular-shaped objects, tools, and components in structured environments. While more advanced dexterous hands are available as upgrades, the Dex1-1 V2 provides everything a research lab needs to start collecting manipulation data immediately — at the lowest entry price in the R1 lineup.
Unlike the bare R1-A5 base model, Smart A ships with a built-in NVIDIA Jetson Orin Nano delivering 40 TOPS of AI compute. This means visual SLAM runs in real time, object detection models process frames locally, and reinforcement learning policies execute with sub-millisecond latency. No external GPU server, no cloud dependency — just plug in power and start training.
A binocular camera head delivers a 146° × 124° field of view with a 60 mm stereo baseline. RGB streams at 1280×720@30 Hz and depth at 544×448@10 Hz give the R1-A5 true spatial awareness. Paired with an 8-core high-performance CPU + 10 TOPS NPU in the head module, plus the Orin Nano 40 TOPS body compute, it runs visual SLAM, object detection, and gesture recognition locally — no cloud required.
Four-array beamforming microphones and dual 3 W speakers enable clear voice capture and synthesis in noisy labs or classrooms. The open audio framework supports custom wake words, multilingual TTS, and integration with LLMs for conversational command-and-control.
At just 700 × 357 × 190 mm and approximately 11 kg, the R1-A5 Smart A fits on a standard lab bench or classroom desk. The fixed-base design eliminates footprint concerns while delivering full upper-body humanoid kinematics. Power via the included external supply — an optional upper-body Li-ion battery is available for ~1.5 hours of untethered operation.

Compact 11 kg fixed-base design — deploy on any desk or lab bench
Unitree provides a mature, Linux-based robot development framework with open APIs for the underlying system, robotic arms, audio, lighting, and visual control. ROS 2 native support, dual encoders on every arm joint, and hollow internal wiring make the R1-A5 Smart A a clean slate for reinforcement learning, teleoperation research, and embodied AI. The built-in Orin Nano 40 TOPS handles model training and inference without external hardware.
Start with Smart A and expand as your projects evolve. The R1-A5 platform is fully modular:

Start with Smart A (fixed base) and upgrade to R1-A5-D (mobile base) as your research scales
| Model | Unitree R1-A5 Smart A (Fixed Base) |
| Dimensions | 700 × 357 × 190 mm |
| Weight | ~11 kg (with external PSU) |
| Total DOF | 13 (Arm 5×2, Waist 1, Head 2) |
| Arm Reach | 420 mm (forearm + upper arm) |
| Peak Shoulder Torque | 60 Nm |
| Max Arm Payload | ~2 kg (posture-dependent) |
| End-Effector Precision | ±0.1 mm |
| End Effectors | Dex1-1 V2 two-finger parallel grippers (both arms) |
| Vision | Binocular camera — RGB 1280×720@30 Hz, Depth 544×448@10 Hz, FOV 146°×124° |
| Head Compute | 8-core high-performance CPU + 10 TOPS NPU |
| Body Compute | 8-core high-performance CPU |
| Onboard AI Compute | NVIDIA Jetson Orin Nano 40 TOPS (built-in) |
| Audio | 4-array microphone + dual 3 W speakers |
| Connectivity | Wi-Fi 6, Bluetooth 5.2, OTA updates |
| Power | External DC PSU included (optional Li-ion battery, ~1.5 h) |
| SDK & Interfaces | Linux-based framework, ROS 2, open APIs for arm/audio/vision/lighting |
| Controllers | Standard dual-hand controllers included |
| Warranty | 12 months on the entire unit |
Smart A is the entry point. Every configuration shares the same R1-A5 body — the difference is the end effector. Choose the one that matches your research goals:
| Config | Hand | Features |
|---|---|---|
| Smart A | Dex1-1 V2 | Entry-level parallel grippers, Orin Nano 40 TOPS |
| Smart B | Dex3-1 (RGB) | 3-finger dexterous hand with wrist RGB camera |
| Smart C | Dex3-1 Tactile (RGB) | 3-finger hand with tactile sensors + wrist RGB camera |
| Smart D | BrainCo Revo 2 Basic (RGB) | 5-finger anthropomorphic hand with wrist RGB camera |
| Smart E | BrainCo Revo 2 Tactile (RGB) | 5-finger hand with tactile sensors + wrist RGB camera |
| Smart F | LinkerBot O6 (RGB) | 6-DOF dexterous hand with wrist RGB camera |
| Smart G | LinkerBot O6 Tactile (RGB) | 6-DOF hand with tactile sensors + wrist RGB camera |
| Smart H | Tendon-driven dexterous hand | Advanced tendon-driven mechanism for research-grade dexterity |
* Specifications are based on manufacturer data and may vary slightly by production batch. Optional battery, compute module, and alternative end effectors sold separately.
Unitree® is a registered trademark of Unitree Robotics. Images are for reference; actual product appearance may differ.
Users must maintain a sufficient safety distance. This is a civilian robot — comply with local laws and regulations.
Fixed-Base Dual-Arm Humanoid Robot with Dex1-1 V2 Parallel Grippers & Onboard Orin Nano 40 TOPS. 13 DOF, 5-DOF precision arms, 60 Nm shoulder torque, binocular vision & full-stack open SDK. The entry point to humanoid research.
R1-A5 Smart A — fixed-base humanoid with Dex1-1 V2 parallel grippers & Orin Nano 40 TOPS
The R1-A5 Smart A is the entry-level configuration of the R1-A5 platform. You get the full fixed-base dual-arm humanoid body with binocular vision, voice interaction, and open SDK — paired with the reliable Dex1-1 V2 two-finger parallel grippers for standard pick-and-place, grasping, and manipulation tasks. The built-in Orin Nano 40 TOPS compute module enables on-device deep learning, visual perception pipelines, and larger model inference right out of the box.
The R1-A5 Smart A is engineered around two 5-DOF high-performance arms, each driven by low-inertia inner-rotor PMSM motors with crossed-roller bearings. With 420 mm reach, 60 Nm peak shoulder torque, and a ~2 kg payload per arm, it handles precise assembly, pick-and-place, and manipulation research with human-like fluidity. Dual encoders on every joint deliver closed-loop precision down to ±0.1 mm.
Dual 5-DOF arms with Dex1-1 V2 parallel grippers for reliable pick-and-place and manipulation
The Dex1-1 V2 is a robust two-finger parallel gripper designed for speed and consistency. It excels at grasping regular-shaped objects, tools, and components in structured environments. While more advanced dexterous hands are available as upgrades, the Dex1-1 V2 provides everything a research lab needs to start collecting manipulation data immediately — at the lowest entry price in the R1 lineup.
Unlike the bare R1-A5 base model, Smart A ships with a built-in NVIDIA Jetson Orin Nano delivering 40 TOPS of AI compute. This means visual SLAM runs in real time, object detection models process frames locally, and reinforcement learning policies execute with sub-millisecond latency. No external GPU server, no cloud dependency — just plug in power and start training.
A binocular camera head delivers a 146° × 124° field of view with a 60 mm stereo baseline. RGB streams at 1280×720@30 Hz and depth at 544×448@10 Hz give the R1-A5 true spatial awareness. Paired with an 8-core high-performance CPU + 10 TOPS NPU in the head module, plus the Orin Nano 40 TOPS body compute, it runs visual SLAM, object detection, and gesture recognition locally — no cloud required.
Four-array beamforming microphones and dual 3 W speakers enable clear voice capture and synthesis in noisy labs or classrooms. The open audio framework supports custom wake words, multilingual TTS, and integration with LLMs for conversational command-and-control.
At just 700 × 357 × 190 mm and approximately 11 kg, the R1-A5 Smart A fits on a standard lab bench or classroom desk. The fixed-base design eliminates footprint concerns while delivering full upper-body humanoid kinematics. Power via the included external supply — an optional upper-body Li-ion battery is available for ~1.5 hours of untethered operation.
Compact 11 kg fixed-base design — deploy on any desk or lab bench
Unitree provides a mature, Linux-based robot development framework with open APIs for the underlying system, robotic arms, audio, lighting, and visual control. ROS 2 native support, dual encoders on every arm joint, and hollow internal wiring make the R1-A5 Smart A a clean slate for reinforcement learning, teleoperation research, and embodied AI. The built-in Orin Nano 40 TOPS handles model training and inference without external hardware.
Start with Smart A and expand as your projects evolve. The R1-A5 platform is fully modular:
Start with Smart A (fixed base) and upgrade to R1-A5-D (mobile base) as your research scales
| Model | Unitree R1-A5 Smart A (Fixed Base) |
| Dimensions | 700 × 357 × 190 mm |
| Weight | ~11 kg (with external PSU) |
| Total DOF | 13 (Arm 5×2, Waist 1, Head 2) |
| Arm Reach | 420 mm (forearm + upper arm) |
| Peak Shoulder Torque | 60 Nm |
| Max Arm Payload | ~2 kg (posture-dependent) |
| End-Effector Precision | ±0.1 mm |
| End Effectors | Dex1-1 V2 two-finger parallel grippers (both arms) |
| Vision | Binocular camera — RGB 1280×720@30 Hz, Depth 544×448@10 Hz, FOV 146°×124° |
| Head Compute | 8-core high-performance CPU + 10 TOPS NPU |
| Body Compute | 8-core high-performance CPU |
| Onboard AI Compute | NVIDIA Jetson Orin Nano 40 TOPS (built-in) |
| Audio | 4-array microphone + dual 3 W speakers |
| Connectivity | Wi-Fi 6, Bluetooth 5.2, OTA updates |
| Power | External DC PSU included (optional Li-ion battery, ~1.5 h) |
| SDK & Interfaces | Linux-based framework, ROS 2, open APIs for arm/audio/vision/lighting |
| Controllers | Standard dual-hand controllers included |
| Warranty | 12 months on the entire unit |
Smart A is the entry point. Every configuration shares the same R1-A5 body — the difference is the end effector. Choose the one that matches your research goals:
| Config | Hand | Features |
|---|---|---|
| Smart A | Dex1-1 V2 | Entry-level parallel grippers, Orin Nano 40 TOPS |
| Smart B | Dex3-1 (RGB) | 3-finger dexterous hand with wrist RGB camera |
| Smart C | Dex3-1 Tactile (RGB) | 3-finger hand with tactile sensors + wrist RGB camera |
| Smart D | BrainCo Revo 2 Basic (RGB) | 5-finger anthropomorphic hand with wrist RGB camera |
| Smart E | BrainCo Revo 2 Tactile (RGB) | 5-finger hand with tactile sensors + wrist RGB camera |
| Smart F | LinkerBot O6 (RGB) | 6-DOF dexterous hand with wrist RGB camera |
| Smart G | LinkerBot O6 Tactile (RGB) | 6-DOF hand with tactile sensors + wrist RGB camera |
| Smart H | Tendon-driven dexterous hand | Advanced tendon-driven mechanism for research-grade dexterity |
* Specifications are based on manufacturer data and may vary slightly by production batch. Optional battery, compute module, and alternative end effectors sold separately.
Unitree® is a registered trademark of Unitree Robotics. Images are for reference; actual product appearance may differ.
Users must maintain a sufficient safety distance. This is a civilian robot — comply with local laws and regulations.

Історія цін
Одна точка даних на день — середнє за датою спостереження.
Суми у валюті USD
Середні значення обчислюються за кожен день UTC на основі всіх зафіксованих цін пропозицій.

Unitree
$6 870
Unitree
$7 290

Unitree
$6 870
Unitree
$8 090
Unitree
$8 390
Unitree
$7 990
Unitree
$8 690
Unitree
$8 590
Unitree
£4 800,33
Unitree
£5 920

Unitree
від 7 548,17 €

Unitree
від 8 225,14 €
🍪 Налаштування файлів cookie
Ми використовуємо файли cookie для вимірювання ефективності. Політика конфіденційності