Середня ціна за день
Суми у валюті USD
Опис
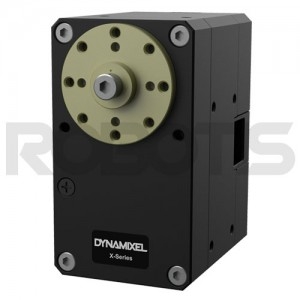
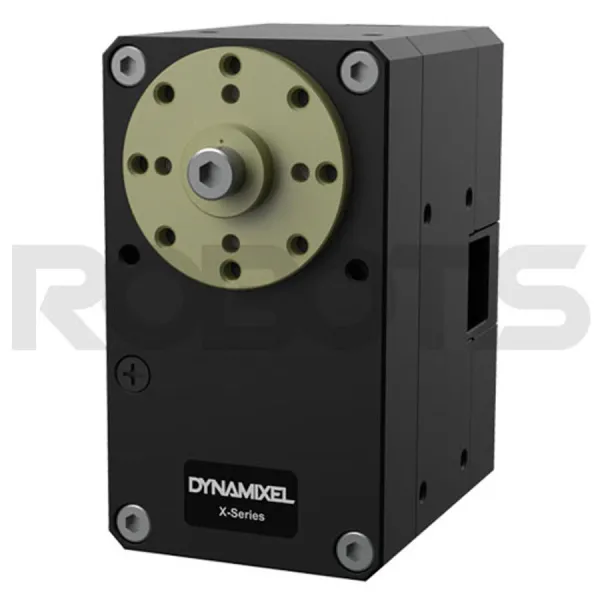
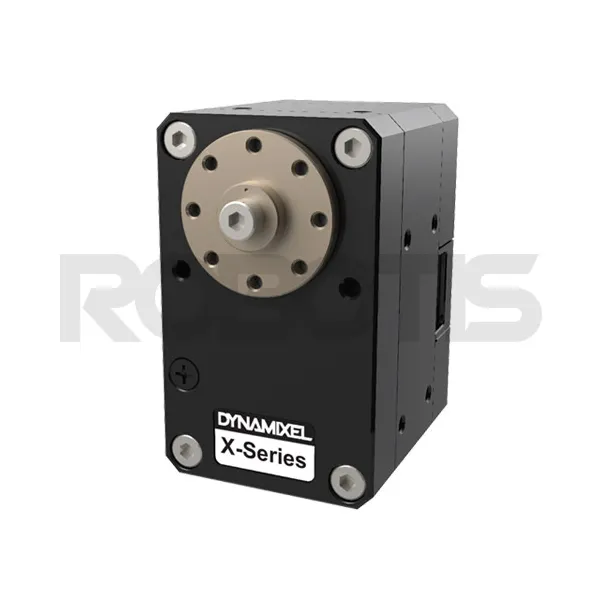
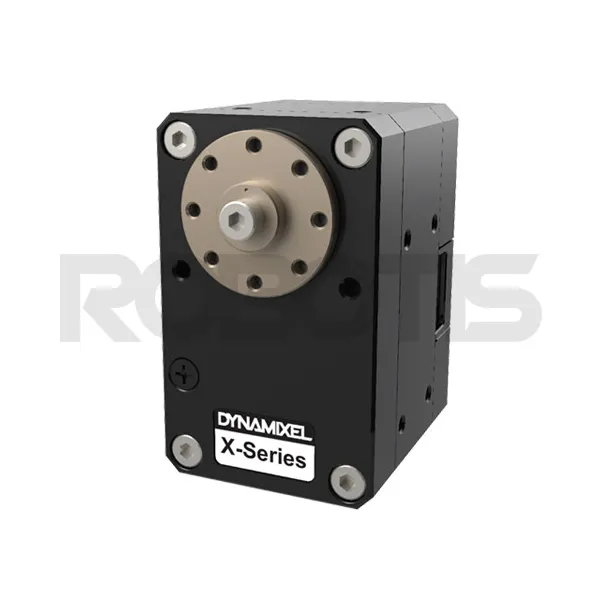
■ Basic Features • Improved Torque, Compact Design • Enhanced Durability and Expandability • Hollow Back Case Minimizes Cable Stress (3-Way Wiring) • Frames Directly Screwed onto the Case (No Nuts Needed) • Improved Aluminum Case Heat Sink • 6 Operating Modes • Current-Based Torque Control (4096 steps, 2.69mA/step) • Profile Control for Smooth Motion Planning • Trajectory Data and Moving Status (In-Position, Following Error, etc.) • Energy Efficient (Standby Current Reduced from 100mA to 40mA) • 28.4% reduced volume compared to the MX-106 ■ Package Contents Description Quantity DYNAMIXEL XM540-W270-R 1 HORN HN13-N101 1 WASHER Teflon Washer (for Horn Assembly) 1 CABLE Robot Cable-X4P 180mm 1 Robot Cable-X4P (Convertible) 180mm 1 3P Sync Cable 160MM 1 BOLT/NUT Wrench Bolt (WB M2.5*5) 16 Wrench Bolt (WB M2.5*4) 10 Wrench Bolt (WB M3*8) 1 ETC Spacer Ring 8 ■ H/W Specifications Model Name XM540-W270-R Weight (g) 165 Dimensions (mm) 33.5 x 58.5 x 44 Gear Ratio 272.5 : 1 Operation Voltage (V) 11.1 12.0 14.8 Stall Torque (N.m) 10.0 10.6 12.9 Stall Current (A) 4.2 4.4 5.5 No Load Speed (RPM) 28 30 37 MCU ST CORTEX-M3 (STM32F103C8 @ 72MHZ,32BIT) Position Sensor Contactless absolute encoder (12BIT,360°) by AMS Motor Coreless Resolution 0.088° x 4,096 steps Operating Range Current Control Mode : Endless turnVelocity Control Mode : Endless turnPosition Control Mode : 360[deg]Extended Control Mode : ±256[rev] Current-based Position Control Mode : ±256[rev] PWM Control Mode : Endless turn Input Voltage (V) 10~14.8V (Recommended voltage : 12V) Operating Temperature -5°C ~ 80°C Communication Signal Digital Packet Protocol RS485 Asynchronous Serial Communication (8bit,1stop, No Parity Link (physical) RS485 Multi Drop Bus ID 253 ID (0~252) Baud Rate 9600 bps ~ 4.5 Mbps Feedback Position, Velocity, Current, Realtime tick, Trajectory, Temperature, Input Voltage, etc. Material Case : Metal Body(Front, Middle) Engineering Plastic Body(Back) Gear : Full Metal Standby current (mA) 40 ■ Default Settings ID : 1 Baud Rate : 57600bps *Please make necessary modifications to ID, baud rate, etc. after purchase. ■ Hyperlinks Frame, Horn, Bearing Compatible Chart : Click Here Controller Compatibility Chart : Click Here Download Drawing : Click Here Dynamixel SDK : Click Here OpenCM IDE : Click Here Software RoboPlus (R+) : Click Here Link to e-Manual : Click Here ■ Caution The DYNAMIXEL X-Series adopted a new gold-plated JST connector for secure and reliable communication. For more information, please see the [DYNAMIXEL Connector Standard] page on the e-Manual. To control DYNAMIXEL X-Series actuators via OpenCM or USB2Dynamixel, please use the JST-Molex Convertible Cable enclosed in the package. However, the Molex-JST convertible cable is NOT included in the XL430 model. Please purchase a convertible cable when using a controller and interface that supports the JST connector. OpenCM+485 Expansion Board Molex (3P, 4P) Robot Cable-X3P 180mm (Convertible) JST-3P TTL USB2Dynamixel OpenCR1.0 JST (3P, 4P) Robot Cable -X3P (by length) U2D2 OpenCM+485 Expansion Board Molex (3P, 4P) Robot Cable -X4P 180mm (Convertible) JST-4P RS-485 USB2Dynamixel OpenCR1.0 JST (3P, 4P) Robot Cable -X4P (by length) U2D2 The DYNAMIXEL X-Series is a new line-up of high performance networked actuators. Improved Torque, Compact Design, Enhanced Durability and Expandability.
■ Basic Features • Improved Torque, Compact Design • Enhanced Durability and Expandability • Hollow Back Case Minimizes Cable Stress (3-Way Wiring) • Frames Directly Screwed onto the Case (No Nuts Needed) • Improved Aluminum Case Heat Sink • 6 Operating Modes • Current-Based Torque Control (4096 steps, 2.69mA/step) • Profile Control for Smooth Motion Planning • Trajectory Data and Moving Status (In-Position, Following Error, etc.) • Energy Efficient (Standby Current Reduced from 100mA to 40mA) • 28.4% reduced volume compared to the MX-106 ■ Package Contents Description Quantity DYNAMIXEL XM540-W270-R 1 HORN HN13-N101 1 WASHER Teflon Washer (for Horn Assembly) 1 CABLE Robot Cable-X4P 180mm 1 Robot Cable-X4P (Convertible) 180mm 1 3P Sync Cable 160MM 1 BOLT/NUT Wrench Bolt (WB M2.5*5) 16 Wrench Bolt (WB M2.5*4) 10 Wrench Bolt (WB M3*8) 1 ETC Spacer Ring 8 ■ H/W Specifications Model Name XM540-W270-R Weight (g) 165 Dimensions (mm) 33.5 x 58.5 x 44 Gear Ratio 272.5 : 1 Operation Voltage (V) 11.1 12.0 14.8 Stall Torque (N.m) 10.0 10.6 12.9 Stall Current (A) 4.2 4.4 5.5 No Load Speed (RPM) 28 30 37 MCU ST CORTEX-M3 (STM32F103C8 @ 72MHZ,32BIT) Position Sensor Contactless absolute encoder (12BIT,360°) by AMS Motor Coreless Resolution 0.088° x 4,096 steps Operating Range Current Control Mode : Endless turnVelocity Control Mode : Endless turnPosition Control Mode : 360[deg]Extended Control Mode : ±256[rev] Current-based Position Control Mode : ±256[rev] PWM Control Mode : Endless turn Input Voltage (V) 10~14.8V (Recommended voltage : 12V) Operating Temperature -5°C ~ 80°C Communication Signal Digital Packet Protocol RS485 Asynchronous Serial Communication (8bit,1stop, No Parity Link (physical) RS485 Multi Drop Bus ID 253 ID (0~252) Baud Rate 9600 bps ~ 4.5 Mbps Feedback Position, Velocity, Current, Realtime tick, Trajectory, Temperature, Input Voltage, etc. Material Case : Metal Body(Front, Middle) Engineering Plastic Body(Back) Gear : Full Metal Standby current (mA) 40 ■ Default Settings ID : 1 Baud Rate : 57600bps *Please make necessary modifications to ID, baud rate, etc. after purchase. ■ Hyperlinks Frame, Horn, Bearing Compatible Chart : Click Here Controller Compatibility Chart : Click Here Download Drawing : Click Here Dynamixel SDK : Click Here OpenCM IDE : Click Here Software RoboPlus (R+) : Click Here Link to e-Manual : Click Here ■ Caution The DYNAMIXEL X-Series adopted a new gold-plated JST connector for secure and reliable communication. For more information, please see the [DYNAMIXEL Connector Standard] page on the e-Manual. To control DYNAMIXEL X-Series actuators via OpenCM or USB2Dynamixel, please use the JST-Molex Convertible Cable enclosed in the package. However, the Molex-JST convertible cable is NOT included in the XL430 model. Please purchase a convertible cable when using a controller and interface that supports the JST connector. OpenCM+485 Expansion Board Molex (3P, 4P) Robot Cable-X3P 180mm (Convertible) JST-3P TTL USB2Dynamixel OpenCR1.0 JST (3P, 4P) Robot Cable -X3P (by length) U2D2 OpenCM+485 Expansion Board Molex (3P, 4P) Robot Cable -X4P 180mm (Convertible) JST-4P RS-485 USB2Dynamixel OpenCR1.0 JST (3P, 4P) Robot Cable -X4P (by length) U2D2
Історія цін
Одна точка даних на день — середнє за датою спостереження.
Суми у валюті USD
Середні значення обчислюються за кожен день UTC на основі всіх зафіксованих цін пропозицій.
Robotis
489,96 €

Robotis
$494,39
Robotis
319,15 €
Robotis
300,26 €
Robotis
331,43 €
Robotis
329,40 €
Robotis
340,74 €
Robotis
325,56 €
Robotis
327,54 €
Robotis
317,40 €
Robotis
317,40 €
Robotis
304,20 €
🍪 Налаштування файлів cookie
Ми використовуємо файли cookie для вимірювання ефективності. Політика конфіденційності