Dagligt genomsnittspris
Belopp i USD


Mobile-Base Dual-Arm Humanoid Robot with Dex1-1 V2 Parallel Grippers. 16 DOF, Orin Nano 40 TOPS, MID360 LiDAR, stereo vision & full-stack open SDK. The entry-level platform for mobile manipulation research.

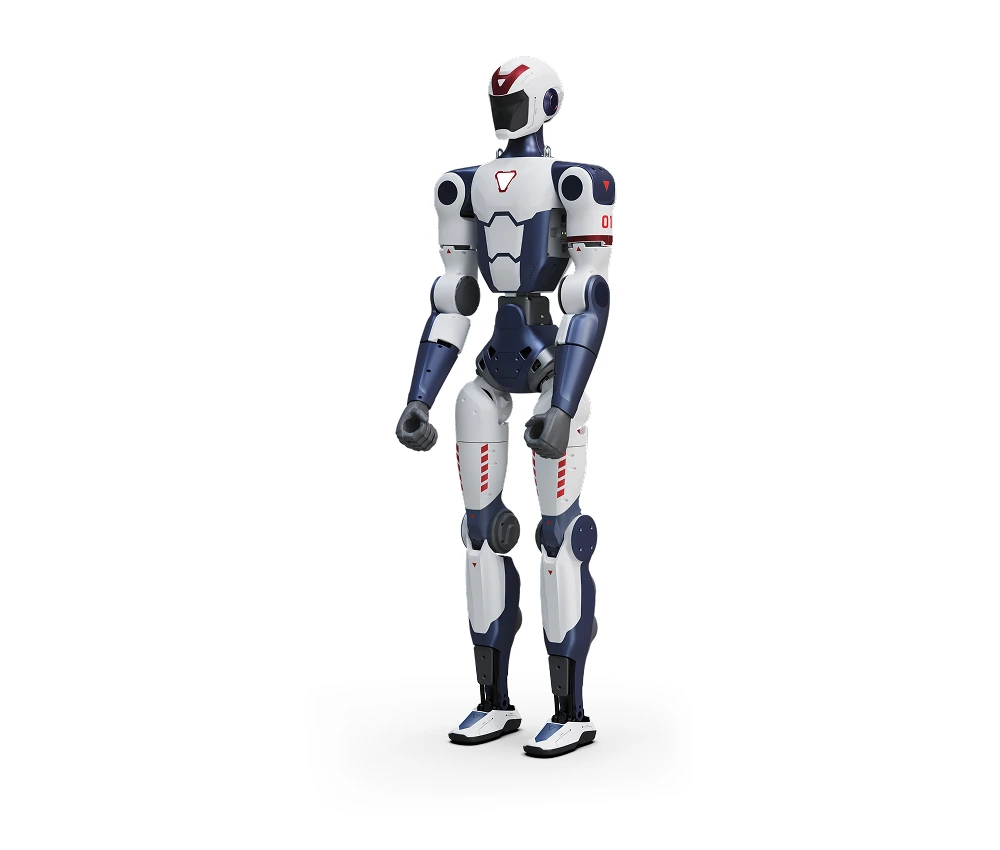
R1-A5-D Smart A — mobile-base humanoid with Dex1-1 V2 parallel grippers, MID360 LiDAR & stereo vision
The R1-A5-D Smart A is the entry point into mobile humanoid research. It pairs the R1-A5-D autonomous mobile base — complete with MID360 LiDAR, stereo vision, and a removable chassis battery — with Dex1-1 V2 parallel grippers for reliable pick-and-place. The built-in Orin Nano 40 TOPS handles onboard navigation, perception, and control without external compute.
The Dex1-1 V2 is a proven two-finger parallel gripper designed for consistency and durability. Its simple, robust mechanism delivers repeatable grasping force for a wide range of industrial and research objects — from small electronic components to medium-weight boxes. Pre-installed on both arms, it turns the R1-A5-D into a capable mobile manipulator for logistics, laboratory automation, and introductory robotics research.

Dex1-1 V2 parallel grippers — robust, repeatable, and ready for mobile pick-and-place
The R1-A5-D chassis adds 3 degrees of freedom to the upper body: a telescopic pillar for height adjustment and a 2-DOF wheeled base for omnidirectional navigation. Combined with the MID360 LiDAR and stereo camera head, the robot builds real-time maps, plans paths, and avoids obstacles autonomously — then stops precisely to manipulate. The removable lithium-ion battery in the chassis delivers approximately 1.5 hours of untethered operation.
Smart A processes data from two complementary sensors: a MID360 360° LiDAR for metrically accurate mapping and long-range obstacle detection, and a binocular camera head (146°×124° FOV, 60 mm baseline) for colour vision, object recognition, and depth estimation. Fused on the Orin Nano 40 TOPS, this dual-modality perception stack supports research in visual-LiDAR SLAM, semantic navigation, and active perception for mobile manipulation.
The built-in NVIDIA Jetson Orin Nano delivers 40 TOPS of AI compute, running SLAM, path planning, object detection, and arm trajectory generation locally. No external GPU server, no cloud dependency — just power on and deploy. The module is pre-installed and thermally integrated with the chassis cooling system.
A binocular camera head delivers a 146° × 124° field of view with a 60 mm stereo baseline for scene-level understanding. RGB streams at 1280×720@30 Hz and depth at 544×448@10 Hz. Combined with the MID360 LiDAR, the R1-A5-D Smart A offers a complete perception stack for research in visual-LiDAR fusion, semantic navigation, and mobile manipulation.
Four-array beamforming microphones and dual 3 W speakers enable clear voice capture and synthesis in noisy labs, warehouses, or classrooms. The open audio framework supports custom wake words, multilingual TTS, and integration with LLMs for conversational command-and-control — even while the base is in motion.
At 683 × 520 × 440 mm collapsed (1323 mm elevated), the R1-A5-D Smart A navigates standard doorways, elevators, and lab aisles. The telescopic pillar lowers the upper body for transport and raises it for manipulation. At approximately 30 kg with battery, it is a self-contained mobile research platform — no external compute rack, no tether cables during operation.

Collapsed (683 mm) and elevated (1323 mm) configurations for navigation and manipulation
Unitree provides a mature, Linux-based robot development framework with open APIs for the underlying system, robotic arms, mobile base, audio, lighting, and visual control. ROS 2 native support, dual encoders on every arm joint, and hollow internal wiring make the R1-A5-D Smart A a clean slate for reinforcement learning, mobile manipulation research, embodied AI, and autonomous navigation studies. The built-in Orin Nano 40 TOPS handles perception and planning locally without external hardware.
Smart A is the entry-level mobile configuration. Expand capability as your research evolves:
| Model | Unitree R1-A5-D Smart A (Mobile Base) |
| Dimensions (Collapsed) | 683 × 520 × 440 mm (H × W × D) |
| Dimensions (Elevated) | 1323 × 520 × 440 mm (H × W × D) |
| Weight (with Battery) | ~30 kg |
| Total DOF | 16 (Arm 5×2, Waist 1, Head 2, Pillar 1, Base 2) |
| Arm Reach | 420 mm (forearm + upper arm) |
| Peak Shoulder Torque | 60 Nm |
| Max Arm Payload | ~2 kg (posture-dependent) |
| End-Effector Precision | ±0.1 mm |
| End Effectors | Dex1-1 V2 parallel grippers (both arms, pre-installed) |
| Wrist Cameras | Not included (optional) |
| Vision | Binocular camera — RGB 1280×720@30 Hz, Depth 544×448@10 Hz, FOV 146°×124° |
| LiDAR | MID360 360° LiDAR (chassis-integrated) |
| Head Compute | 8-core high-performance CPU + 10 TOPS NPU |
| Body Compute | 8-core high-performance CPU |
| Onboard AI Compute | NVIDIA Jetson Orin Nano 40 TOPS (built-in) |
| Audio | 4-array microphone + dual 3 W speakers |
| Connectivity | Wi-Fi 6, Bluetooth 5.2, OTA updates |
| Power | Removable chassis Li-ion battery (~1.5 h) + external DC PSU. Upper body does not accept a battery. |
| SDK & Interfaces | Linux-based framework, ROS 2, open APIs for arm/base/audio/vision/lighting |
| Controllers | Standard dual-hand controllers included |
| Warranty | 12 months on the entire unit |
Every configuration shares the same R1-A5-D mobile base — the difference is the end effector. Choose the one that matches your research goals:
| Config | Hand | Features |
|---|---|---|
| Smart A | Dex1-1 V2 | Entry-level parallel grippers, Orin Nano 40 TOPS, MID360 LiDAR |
| Smart B | Dex3-1 (RGB) | 3-finger dexterous hand with wrist RGB camera |
| Smart C | Dex3-1 Tactile (RGB) | 3-finger hand with tactile sensors + wrist RGB camera |
| Smart D | BrainCo Revo 2 Basic (RGB) | 5-finger anthropomorphic hand with wrist RGB camera |
| Smart E | BrainCo Revo 2 Tactile (RGB) | 5-finger hand with tactile sensors + wrist RGB camera |
| Smart F | LinkerBot O6 (RGB) | 6-DOF dexterous hand with wrist RGB camera |
| Smart G | LinkerBot O6 Tactile (RGB) | 6-DOF hand with tactile sensors + wrist RGB camera |
| Smart H | Tendon-driven dexterous hand | Advanced tendon-driven mechanism for research-grade dexterity |
* Specifications are based on manufacturer data and may vary slightly by production batch. Optional wrist cameras, compute modules, and alternative end effectors sold separately.
Unitree® is a registered trademark of Unitree Robotics. Images are for reference; actual product appearance may differ.
Users must maintain a sufficient safety distance. This is a civilian robot — comply with local laws and regulations.
Mobile-Base Dual-Arm Humanoid Robot with Dex1-1 V2 Parallel Grippers. 16 DOF, Orin Nano 40 TOPS, MID360 LiDAR, stereo vision & full-stack open SDK. The entry-level platform for mobile manipulation research.
R1-A5-D Smart A — mobile-base humanoid with Dex1-1 V2 parallel grippers, MID360 LiDAR & stereo vision
The R1-A5-D Smart A is the entry point into mobile humanoid research. It pairs the R1-A5-D autonomous mobile base — complete with MID360 LiDAR, stereo vision, and a removable chassis battery — with Dex1-1 V2 parallel grippers for reliable pick-and-place. The built-in Orin Nano 40 TOPS handles onboard navigation, perception, and control without external compute.
The Dex1-1 V2 is a proven two-finger parallel gripper designed for consistency and durability. Its simple, robust mechanism delivers repeatable grasping force for a wide range of industrial and research objects — from small electronic components to medium-weight boxes. Pre-installed on both arms, it turns the R1-A5-D into a capable mobile manipulator for logistics, laboratory automation, and introductory robotics research.
Dex1-1 V2 parallel grippers — robust, repeatable, and ready for mobile pick-and-place
The R1-A5-D chassis adds 3 degrees of freedom to the upper body: a telescopic pillar for height adjustment and a 2-DOF wheeled base for omnidirectional navigation. Combined with the MID360 LiDAR and stereo camera head, the robot builds real-time maps, plans paths, and avoids obstacles autonomously — then stops precisely to manipulate. The removable lithium-ion battery in the chassis delivers approximately 1.5 hours of untethered operation.
Smart A processes data from two complementary sensors: a MID360 360° LiDAR for metrically accurate mapping and long-range obstacle detection, and a binocular camera head (146°×124° FOV, 60 mm baseline) for colour vision, object recognition, and depth estimation. Fused on the Orin Nano 40 TOPS, this dual-modality perception stack supports research in visual-LiDAR SLAM, semantic navigation, and active perception for mobile manipulation.
The built-in NVIDIA Jetson Orin Nano delivers 40 TOPS of AI compute, running SLAM, path planning, object detection, and arm trajectory generation locally. No external GPU server, no cloud dependency — just power on and deploy. The module is pre-installed and thermally integrated with the chassis cooling system.
A binocular camera head delivers a 146° × 124° field of view with a 60 mm stereo baseline for scene-level understanding. RGB streams at 1280×720@30 Hz and depth at 544×448@10 Hz. Combined with the MID360 LiDAR, the R1-A5-D Smart A offers a complete perception stack for research in visual-LiDAR fusion, semantic navigation, and mobile manipulation.
Four-array beamforming microphones and dual 3 W speakers enable clear voice capture and synthesis in noisy labs, warehouses, or classrooms. The open audio framework supports custom wake words, multilingual TTS, and integration with LLMs for conversational command-and-control — even while the base is in motion.
At 683 × 520 × 440 mm collapsed (1323 mm elevated), the R1-A5-D Smart A navigates standard doorways, elevators, and lab aisles. The telescopic pillar lowers the upper body for transport and raises it for manipulation. At approximately 30 kg with battery, it is a self-contained mobile research platform — no external compute rack, no tether cables during operation.
Collapsed (683 mm) and elevated (1323 mm) configurations for navigation and manipulation
Unitree provides a mature, Linux-based robot development framework with open APIs for the underlying system, robotic arms, mobile base, audio, lighting, and visual control. ROS 2 native support, dual encoders on every arm joint, and hollow internal wiring make the R1-A5-D Smart A a clean slate for reinforcement learning, mobile manipulation research, embodied AI, and autonomous navigation studies. The built-in Orin Nano 40 TOPS handles perception and planning locally without external hardware.
Smart A is the entry-level mobile configuration. Expand capability as your research evolves:
| Model | Unitree R1-A5-D Smart A (Mobile Base) |
| Dimensions (Collapsed) | 683 × 520 × 440 mm (H × W × D) |
| Dimensions (Elevated) | 1323 × 520 × 440 mm (H × W × D) |
| Weight (with Battery) | ~30 kg |
| Total DOF | 16 (Arm 5×2, Waist 1, Head 2, Pillar 1, Base 2) |
| Arm Reach | 420 mm (forearm + upper arm) |
| Peak Shoulder Torque | 60 Nm |
| Max Arm Payload | ~2 kg (posture-dependent) |
| End-Effector Precision | ±0.1 mm |
| End Effectors | Dex1-1 V2 parallel grippers (both arms, pre-installed) |
| Wrist Cameras | Not included (optional) |
| Vision | Binocular camera — RGB 1280×720@30 Hz, Depth 544×448@10 Hz, FOV 146°×124° |
| LiDAR | MID360 360° LiDAR (chassis-integrated) |
| Head Compute | 8-core high-performance CPU + 10 TOPS NPU |
| Body Compute | 8-core high-performance CPU |
| Onboard AI Compute | NVIDIA Jetson Orin Nano 40 TOPS (built-in) |
| Audio | 4-array microphone + dual 3 W speakers |
| Connectivity | Wi-Fi 6, Bluetooth 5.2, OTA updates |
| Power | Removable chassis Li-ion battery (~1.5 h) + external DC PSU. Upper body does not accept a battery. |
| SDK & Interfaces | Linux-based framework, ROS 2, open APIs for arm/base/audio/vision/lighting |
| Controllers | Standard dual-hand controllers included |
| Warranty | 12 months on the entire unit |
Every configuration shares the same R1-A5-D mobile base — the difference is the end effector. Choose the one that matches your research goals:
| Config | Hand | Features |
|---|---|---|
| Smart A | Dex1-1 V2 | Entry-level parallel grippers, Orin Nano 40 TOPS, MID360 LiDAR |
| Smart B | Dex3-1 (RGB) | 3-finger dexterous hand with wrist RGB camera |
| Smart C | Dex3-1 Tactile (RGB) | 3-finger hand with tactile sensors + wrist RGB camera |
| Smart D | BrainCo Revo 2 Basic (RGB) | 5-finger anthropomorphic hand with wrist RGB camera |
| Smart E | BrainCo Revo 2 Tactile (RGB) | 5-finger hand with tactile sensors + wrist RGB camera |
| Smart F | LinkerBot O6 (RGB) | 6-DOF dexterous hand with wrist RGB camera |
| Smart G | LinkerBot O6 Tactile (RGB) | 6-DOF hand with tactile sensors + wrist RGB camera |
| Smart H | Tendon-driven dexterous hand | Advanced tendon-driven mechanism for research-grade dexterity |
* Specifications are based on manufacturer data and may vary slightly by production batch. Optional wrist cameras, compute modules, and alternative end effectors sold separately.
Unitree® is a registered trademark of Unitree Robotics. Images are for reference; actual product appearance may differ.
Users must maintain a sufficient safety distance. This is a civilian robot — comply with local laws and regulations.

Prishistorik
En datapunkt per dag, beräknad utifrån observationsdatumet.
Belopp i USD
Genomsnittet beräknas per UTC-dygn utifrån alla registrerade erbjudandepriser.
Unitree
$11 290
Unitree
10 599 €

Unitree
$9 990

Unitree
$13 090
Unitree
$8 090
Unitree
$8 390
Unitree
$7 990
Unitree
$12 090
Unitree
$12 390
Unitree
$11 990
Unitree
$12 790
Unitree
$13 690
🍪 Cookieinställningar
Vi använder cookies för att mäta prestanda. Integritetspolicy