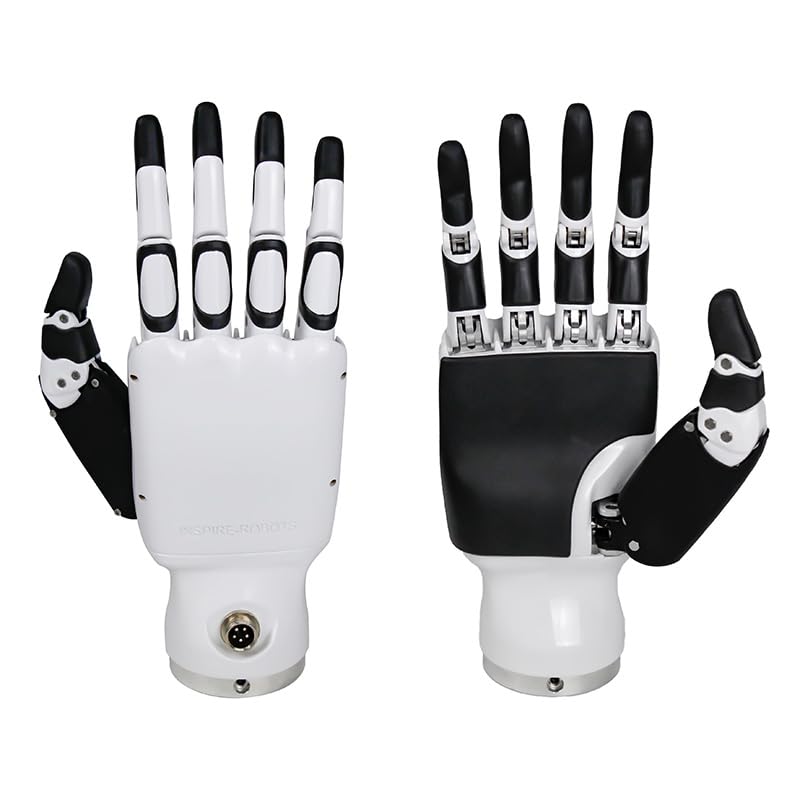
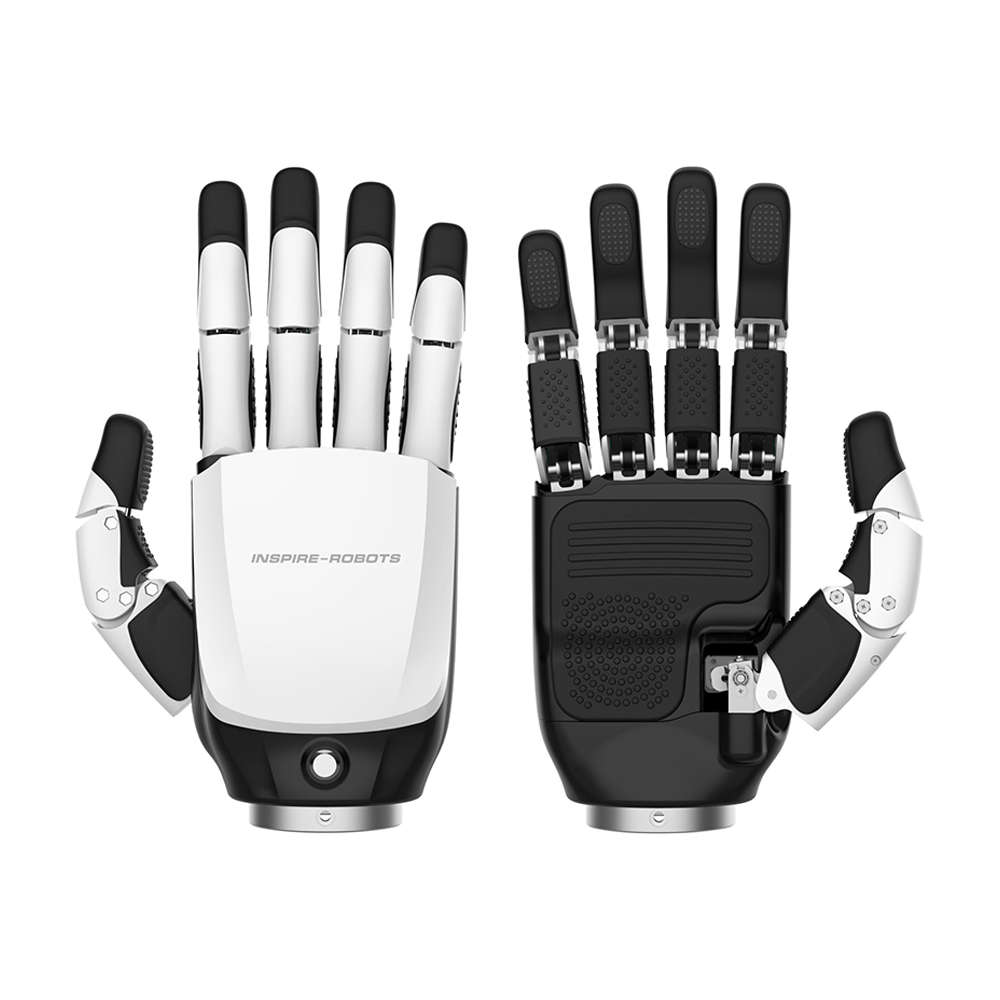
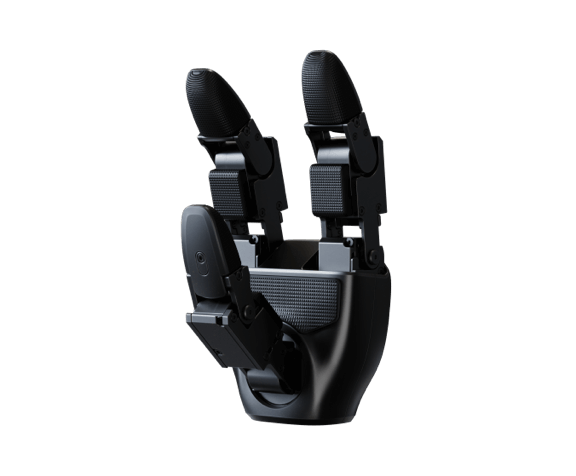
The Casbot Handle L1 PRO is the upgraded tier of Casbot's five-finger dexterous hand, an anthropomorphic end-effector built for humanoid robots and embodied-operation platforms. Like the Handle L1 line shown at China's World Robot Conference, it gives a robot human-like manipulation: coordinated fingers that close securely around objects, pinch with precision and reposition items under control, so machines can engage tools, handles and everyday items the way people do.
Engineering centres on a highly integrated architecture that combines drive, transmission, sensing and control inside a compact palm, keeping the hand deployment-ready rather than experimental. A multi-source perception scheme spanning tactile, force and vision feedback underpins adaptive grasping and dependable execution when objects differ in texture, mass or slip. Casbot reports a single-hand weight around 800 g with a rated payload near 5 kg, a favourable load-to-mass balance that helps preserve arm stability, energy efficiency and motion smoothness.
Positioned for integrators and demanding manipulation work, the PRO supports pick-and-place across diverse geometries, contact-rich tasks where tactile cues raise reliability, and advanced research into grasp stability, force control and learned in-hand manipulation.