Средняя цена за день
Суммы в USD
Описание
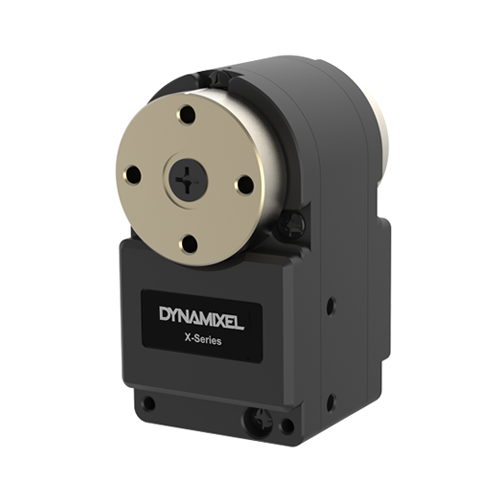
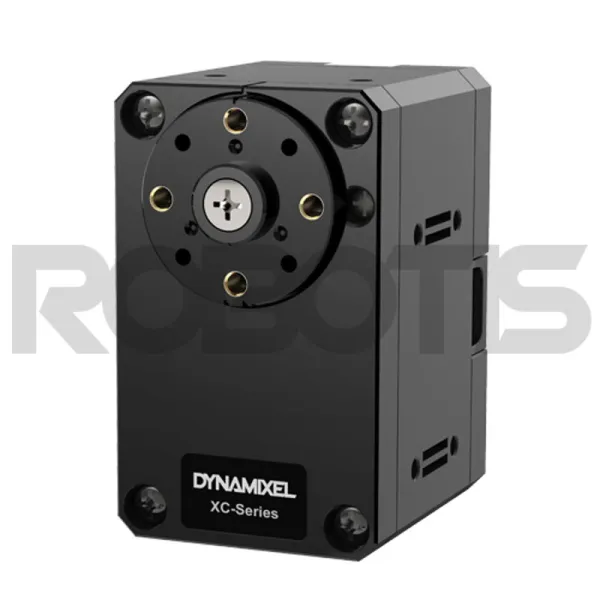
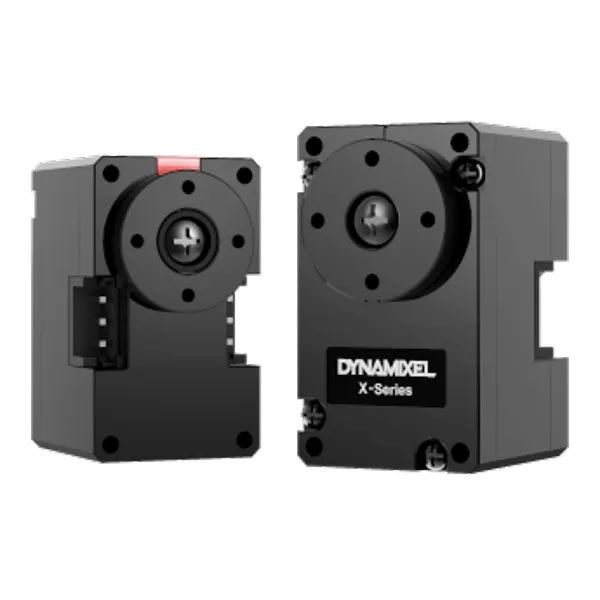
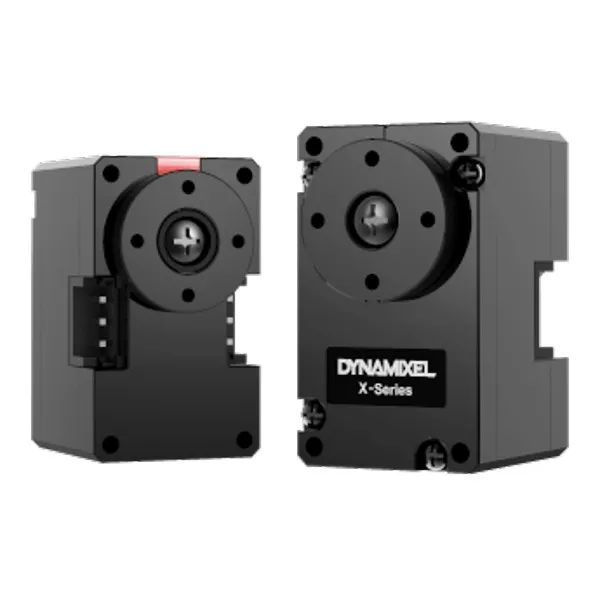
The XM335 model is a dedicated actuator for robotic fingers. It supports a total of six control modes, including Current Control and Current-based Position Control, as well as the RC protocol, enabling efficient use in various applications. *Caution: The recommended voltage is DC 11.1V, so please exercise caution during use. *The XM335 series is a compact and lightweight product, making it easy to use in extremely narrow spaces. *Durability has been reinforced through the application of metal gears and a metal case. 1.Various Operating Modes Velocity Control, Position Control, Extended Position Control, PWM Control, Current Control, Current Based Position Control 2.Profile Control for Smooth Motion Planning 3.Input Voltage : 6.5V ~ 12.0V ( Recommended 11.1V) 4.Enhanced Durability by applying Metal Gear and Bearing 5.Support RC Protocol without additional converting device 6.Energy Saving with Reduced Current Package Components Item Quantity Description XM335-T323-T 1 DYNAMIXEL Robot Cable-X3P(HRS) 80mm 1 TTL 3p cable(HRS - HRS) FHS_M2X06 1 Bolts for horns CHS_M1_7X04 10 Bolts for frames PHS_M2X04 14 Bolts for frames HORN 1 Horn for XM335 The idler set for hinge frame mounting is not included. Drawing Compatible Products Important Notes Due to a change in the connector specifications for the XM335 cables, a 3P JST-HRS Conversion Board is required for connection to existing JST connector-based products, such as the U2D2, OpenCR1.0, and OpenRB-150. The conversion board is scheduled to be available for separate purchase in February. Installation Example Specification Model Name XM335-T323-T Series DYNAMIXEL X MCU ARM CORTEX-M0+ (64 [MHz], 32Bit) Input Voltage Min. [V] 6.5 Recommended [V] 11.1 Max. [V] 12.0 Performance Characteristics Voltage [V] 11.0 Stall Torque [N·m] 1.03 Stall Current [A] 0.8 No Load Speed [rpm] 53.0 No Load Current [A] - Continuous Operation Voltage [V] - Torque [N·m] - Speed [rpm] - Current [A] - Resolution Resolution [deg/pulse] 0.0879000000 Step [pulse/rev] 4,096 Angle [degree] 360 Position Sensor Contactless absolute encoder (12Bit, 360 [deg]) Maker : ams(www.ams.com), Part No : AS5601 Operating Temperature Min. [°C] -5 Max. [°C] 70 Motor Coreless Baud Rate Min. [bps] 9600 Max. [bps] 4000000 Control Algorithm PID Gear Type Spur Gear Material Full Metal Case Material Full Metal Dimensions (WⅹHⅹD) [mm] 19.0 x 35.0 x 22.0 Dimensions (WⅹHⅹD) [inch] 7.48 x 13.78 x 8.66 Weight [g] 27.00 Weight [oz] 0.95 Gear Ratio 323.04 : 1 Backlash [arcmin] - Backlash [deg] - Command Signal Digital Packet Protocol Type Half duplex Asynchronous Serial Communication (8bit, 1stop, No Parity) Link (Physical) TTL Level Multidrop Bus ID 0 ~ 252 Feedback Position, Velocity, Current, Realtime tick, Trajectory, Temperature, Input Voltage, etc Protocol version Protocol 2.0 Experimental S.BUS Experimental iBUS RC-PWM Operating Mode / Angle Current Control mode:Endless turn Velocity Control mode:Endless turn Position Control Mode:360 [deg] Extended Position Control Mode:±256 [rev] Current-based Position Control Mode:±256 [rev] PWM Control Mode:Endless turn Output [W] - Standby Current [mA] 17 Links e-Manual Drawing Software (DYNAMIXEL Wizard 2.0) Selection Guide DYNAMIXEL SDK
The XM335 model is a dedicated actuator for robotic finger s. It supports a total of six control modes, including Current Control and Current-based Position Control, as well as the RC protocol, enabling efficient use in various applications. *Caution: The recommended voltage is DC 11.1V, so please exercise caution during use. *The XM335 series is a compact and lightweight product, making it easy to use in extremely narrow spaces. *Durability has been reinforced through the application of metal gears and a metal case. 1.Various Operating Modes Velocity Control, Position Control, Extended Position Control, PWM Control, Current Control, Current Based Position Control 2.Profile Control for Smooth Motion Planning 3.Input Voltage : 6.5V ~ 12.0V ( Recommended 11.1V) 4.Enhanced Durability by applying Metal Gear and Bearing 5.Support RC Protocol without additional converting device 6.Energy Saving with Reduced Current Package Components Item Quantity Description XM335-T323-T 1 DYNAMIXEL Robot Cable-X3P(HRS) 80mm 1 TTL 3p cable(HRS - HRS) FHS_M2X06 1 Bolts for horns CHS_M1_7X04 10 Bolts for frames PHS_M2X04 14 Bolts for frames HORN 1 Horn for XM335 The idler set for hinge frame mounting is not included. Drawing Compatible Products Important Notes Due to a change in the connector specifications for the XM335 cables, a 3P JST-HRS Conversion Board is required for connection to existing JST connector-based products, such as the U2D2, OpenCR1.0, and OpenRB-150. The conversion board is scheduled to be available for separate purchase in February. Installation Example Specification Model Name XM335-T323-T Series DYNAMIXEL X MCU ARM CORTEX-M0+ (64 [MHz], 32Bit) Input Voltage Min. [V] 6.5 Recommended [V] 11.1 Max. [V] 12.0 Performance Characteristics Voltage [V] 11.0 Stall Torque [N·m] 1.03 Stall Current [A] 0.8 No Load Speed [rpm] 53.0 No Load Current [A] - Continuous Operation Voltage [V] - Torque [N·m] - Speed [rpm] - Current [A] - Resolution Resolution [deg/pulse] 0.0879000000 Step [pulse/rev] 4,096 Angle [degree] 360 Position Sensor Contactless absolute encoder (12Bit, 360 [deg]) Maker : ams(www.ams.com), Part No : AS5601 Operating Temperature Min. [°C] -5 Max. [°C] 70 Motor Coreless Baud Rate Min. [bps] 9600 Max. [bps] 4000000 Control Algorithm PID Gear Type Spur Gear Material Full Metal Case Material Full Metal Dimensions (WⅹHⅹD) [mm] 19.0 x 35.0 x 22.0 Dimensions (WⅹHⅹD) [inch] 7.48 x 13.78 x 8.66 Weight [g] 27.00 Weight [oz] 0.95 Gear Ratio 323.04 : 1 Backlash [arcmin] - Backlash [deg] - Command Signal Digital Packet Protocol Type Half duplex Asynchronous Serial Communication (8bit, 1stop, No Parity) Link (Physical) TTL Level Multidrop Bus ID 0 ~ 252 Feedback Position, Velocity, Current, Realtime tick, Trajectory, Temperature, Input Voltage, etc Protocol version Protocol 2.0 Experimental S.BUS Experimental iBUS RC-PWM Operating Mode / Angle Current Control mode:Endless turn Velocity Control mode:Endless turn Position Control Mode:360 [deg] Extended Position Control Mode:±256 [rev] Current-based Position Control Mode:±256 [rev] PWM Control Mode:Endless turn Output [W] - Standby Current [mA] 17 Links e-Manual Drawing Software (DYNAMIXEL Wizard 2.0) Selection Guide DYNAMIXEL SDK
История цен
Одна точка данных на день; усреднение ведётся по дате наблюдения.
Суммы в USD
Средние значения рассчитываются за каждый день по UTC на основе всех зафиксированных цен предложений.
Robotis
174 €
Robotis
123,58 €
Robotis
131,94 €
Robotis
131,94 €
Robotis
110,40 €
Robotis
110,40 €
Robotis
110,40 €
Robotis
110,40 €

Robotis
$126,39

Robotis
$115

Robotis
$115

Robotis
$115
🍪 Настройки файлов cookie
Мы используем файлы cookie для оценки производительности. Политика конфиденциальности