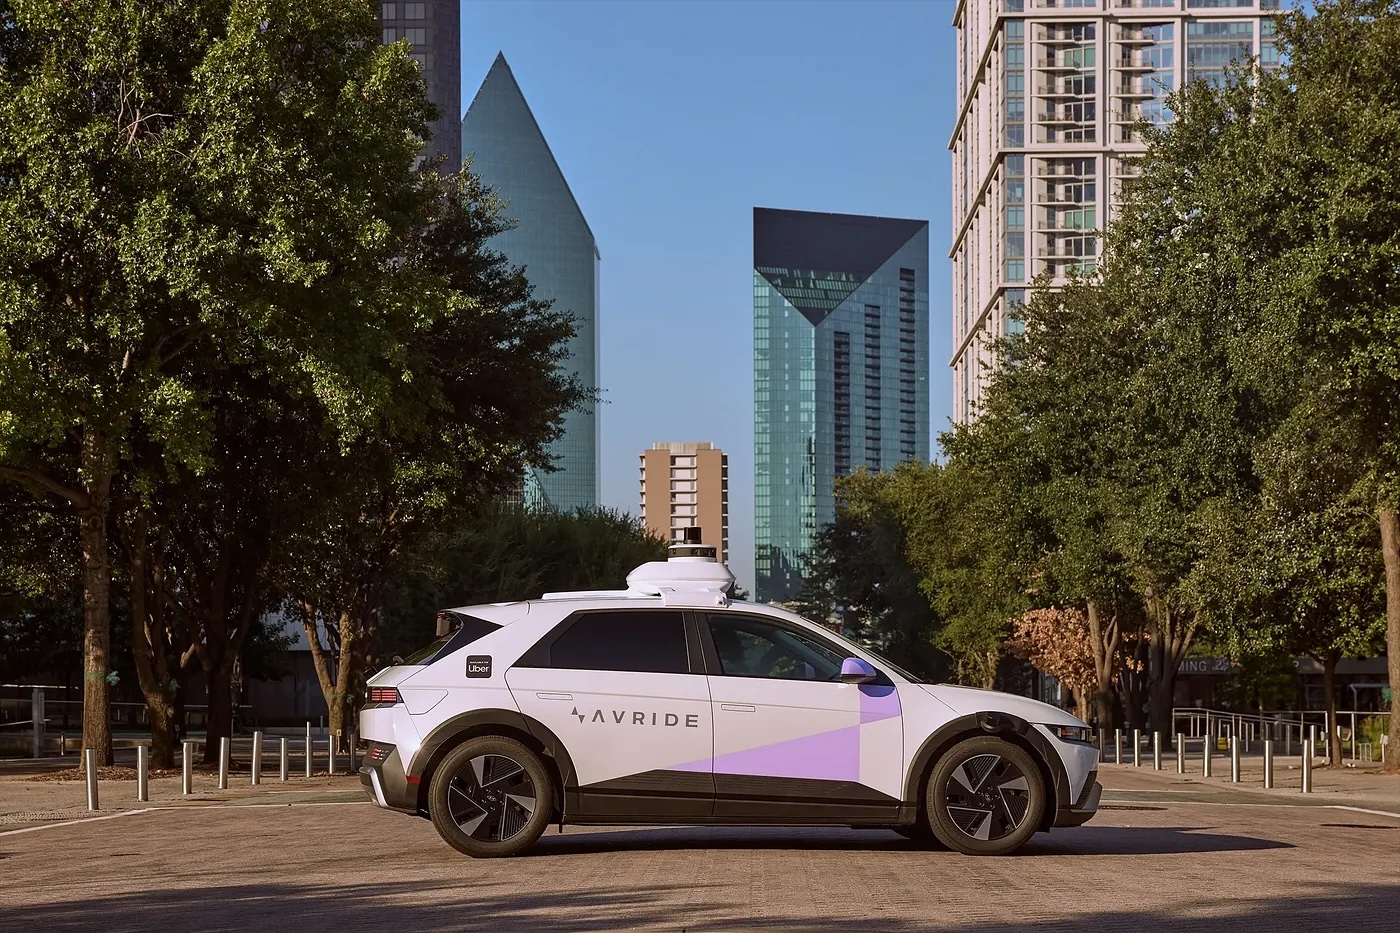
An Avride self-driving vehicle struck and killed a mother duck in Austin's Mueller neighborhood, prompting community backlash and raising a harder question the AV industry rarely discusses openly: autonomous vehicles still struggle to reliably detect small, unpredictable animals — and most perception systems weren't designed with them in mind.
Table of Contents
- What happened in Austin's Mueller neighborhood?
- Why do AV sensors miss small animals?
- How do major AV players compare on urban edge cases?
- What does this mean for urban AV deployment?
- Frequently Asked Questions
What Happened in Austin's Mueller Neighborhood?
An Avride autonomous vehicle struck and killed a nesting duck near the Mueller neighborhood in Austin, Texas — a walkable, mixed-use community with parks, pedestrian paths, and resident wildlife. A witness described the incident bluntly: "It didn't slow down or hesitate at all, just steamrolled right through." The vehicle showed no evidence of braking, swerving, or detection before impact.
The incident quickly drew neighborhood outrage, particularly given Mueller's reputation as a family-friendly community where ducks are a recognisable fixture of daily street life. But beyond the local uproar lies a more technically significant problem: this wasn't a one-off glitch. It reflects a structural gap in how autonomous perception systems classify and prioritise non-human entities in urban environments.
Avride, a robotaxi and sidewalk delivery robot company that spun out of Yandex, operates AV services in Austin as part of its expanding US footprint. The company had not issued a formal public statement on the incident at time of writing.
Why Do AV Sensors Miss Small Animals?
Modern autonomous vehicles rely on a sensor fusion stack — typically combining LiDAR (light detection and ranging), radar, and camera arrays — to build a real-time model of the environment. For large, predictable objects like cars, cyclists, and pedestrians, this stack performs reasonably well. For small, low-profile, erratically-moving animals, the failure modes are systematic.
Three compounding problems drive this:
1. LiDAR point cloud density. A standard 64-channel LiDAR unit generates sparse point returns at ground level for objects under 30cm tall. A duck, sitting or waddling, may not generate enough returns to cross the object-detection threshold — especially at mid-range distances where the system needs to begin braking.
2. Training data imbalance. AV perception models are trained primarily on annotated urban driving datasets — millions of images and LiDAR scans labelled for cars, trucks, pedestrians, cyclists, and traffic infrastructure. Small animals are dramatically underrepresented. A duck registers as a statistical anomaly, not a learned category. The model either ignores it or misclassifies it as road debris.
3. Behavioural prediction gaps. Even when an object is detected, AV systems use motion models to predict its trajectory. These models are calibrated for human-speed movement and human-like path logic. Animals — particularly birds — move in ways that are genuinely difficult to anticipate, making the second-order problem (predict and respond) harder than the first (detect).
The honest takeaway: AV systems are optimised to pass regulatory benchmarks around human-centric safety. Non-human biological entities in road environments are largely an afterthought in both dataset construction and safety evaluation frameworks.
How Do Major AV Players Compare on Urban Edge Cases?
No standardised public benchmark exists specifically for small animal detection in AV systems — which is itself a problem. What we can do is compare the stated approaches and known track records of the leading players:
| Company | Sensor Stack | Known Edge Case Focus | Public Animal Incident Record |
|---|---|---|---|
| Waymo | LiDAR + radar + cameras (custom hardware) | Extensive edge case simulation library; reports unusual object types in safety reports | Low — no widely reported animal fatalities |
| Cruise | LiDAR + radar + cameras | Heavy urban SF environment; irregular object handling documented | Suspended after pedestrian incidents; animal data limited |
| Zoox | 360° LiDAR + cameras, bidirectional AV | Purpose-built urban focus; edge case data largely proprietary | No major public reports |
| Avride | Camera-primary + LiDAR | Delivery-focused perception tuning; sidewalk robots and road AVs share stack elements | Austin duck incident (2025); prior record limited |
| Aurora | LiDAR + radar + cameras (highway/freight focus) | Optimised for highway; urban animal scenarios not a stated priority | No major public reports — different operating domain |
Waymo's safety reports — among the most transparent in the industry — document millions of disengagements and edge case encounters without a comparable incident pattern. Crucially, Waymo's custom LiDAR hardware generates significantly higher point cloud density at low profiles than commodity sensor units used by smaller operators.
The gap between Waymo's sensor investment and what smaller AV entrants deploy is substantial. Waymo's custom Laser Bear Honeycomb sensor array reportedly costs multiple times more per unit than off-the-shelf LiDAR alternatives. Smaller players, under commercial cost pressure, make trade-offs — and those trade-offs have real consequences in complex urban environments.
What This Means for Urban AV Deployment
For policymakers, mobility planners, and communities considering AV deployment, the Mueller incident is a concrete signal that current safety evaluation frameworks are incomplete. Most AV certification and testing regimes focus on human traffic participants. Fauna — whether urban wildlife, domestic animals, or livestock in mixed-use environments — occupies a regulatory blind spot.
Three practical implications stand out:
For regulators: Safety audits for urban AV deployment should include non-human biological entity detection as a testable requirement, not an optional metric. Cities with parks, waterways, or known wildlife corridors — like Austin's Mueller — represent distinct operating environments that warrant specific certification criteria.
For AV operators: Perception system training datasets need systematic augmentation with small animal annotations. This is not a major engineering challenge; it's a prioritisation and resourcing decision. The cost of re-labelling and retraining is far lower than the reputational cost of preventable incidents in residential communities.
For communities: Incidents like this one accelerate a necessary conversation about where AVs should operate before their perception systems mature. Mueller's dense pedestrian and wildlife environment is arguably not the right proving ground for a camera-primary perception stack still catching up to the edge case distribution of urban life.
The broader robotics and autonomous systems industry faces a version of this problem too. Mobile robots and autonomous ground vehicles (AGVs) navigating warehouse floors, hospital corridors, or outdoor campuses encounter similar edge cases — small objects, animals, children, and unpredictable movement patterns that standard obstacle detection pipelines handle poorly. If you're evaluating autonomous platforms for complex environments, browse used industrial robots and AGVs on Robot Overflow to compare sensor specifications across platforms before committing to a deployment.