Preço médio diário
Valores em USD
Descrição
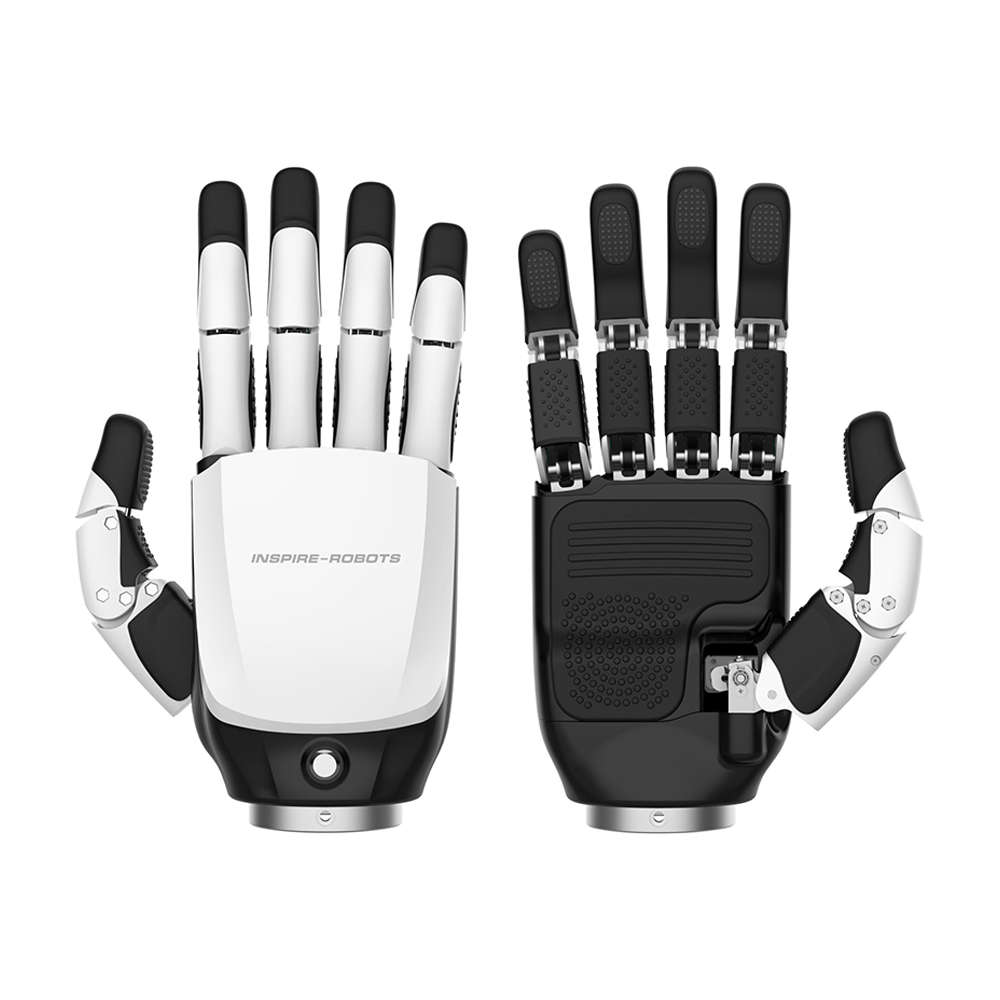
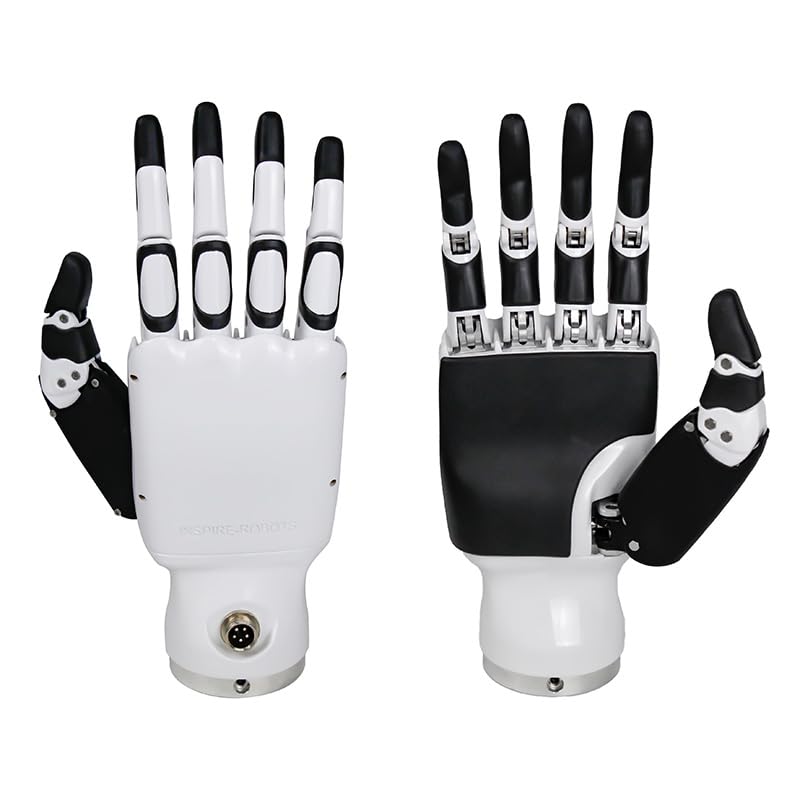
#html-body [data-pb-style=A6TL81Q],#html-body [data-pb-style=JY6J769],#html-body [data-pb-style=M451E47],#html-body [data-pb-style=U2U23ME],#html-body [data-pb-style=WMF2D59]{justify-content:flex-start;display:flex;flex-direction:column;background-position:left top;background-size:cover;background-repeat:no-repeat;background-attachment:scroll}The FTP series integrates 17 tactile sensor in a single hand,which setup allows real-time acquisition of tactile information from various parts, helping to optimize gripping actions and improve operational precision. The FTP series extended its lifespan to over a million, providing long-term reliable support.The fingertips can exert a force of up to 3 kg, making its gripping strength comparable to that of a human hand.<table border="1" cellpadding="6" cellspacing="0"> <thead> <tr> <th colspan="4">Comparison</th> </tr> <tr> <th>Robot Hands</th> <th> RH56DFTP-0L, RH56DFTP-0R (CAN)<br> RH56DFTP-2L, RH56DFTP-2R (RS485)<br> <span style="color:red;">(newest)</span> </th> <th> RH56DFX-2L<br> RH56DFX-2R<br> <span style="color:red;">(strong grip)</span> </th> <th> RH56BFX-2L<br> RH56BFX-2R<br> <span style="color:red;">(fast speed)</span> </th> </tr> </thead> <tbody> <tr><td>1. Side</td><td colspan="3">Left hand / Right hand</td></tr> <tr><td>2. Control interface</td><td>CAN + ModbusTCP (Optional: RS485)</td><td>RS485</td><td>RS485</td></tr> <tr><td>3. Degree of freedom</td><td>6</td><td>6</td><td>6</td></tr> <tr><td>4. Number of joints</td><td>12</td><td>12</td><td>12</td></tr> <tr><td>5. Weight</td><td>790±10g</td><td>540g</td><td>540g</td></tr> <tr><td>6. Operation Voltage</td><td>DC24V±10%</td><td>DC24V±10%</td><td>DC24V±10%</td></tr> <tr><td>7. Peak Current</td><td>4A</td><td>2A</td><td>2A</td></tr> <tr><td>8. Repeatability</td><td>±0.2mm</td><td>±0.2mm</td><td>±0.2mm</td></tr> <tr><td>9. Max finger grip force</td><td>30N</td><td>4N</td><td>10N</td></tr> <tr><td>10. Number of force sensors</td><td>6</td><td>6</td><td>6</td></tr> <tr><td>11. Number of tactile sensors</td><td style="color:red;">17</td><td>/</td><td>/</td></tr> <tr><td>12. Haptic data refresh rate</td><td>≥ 30Hz</td><td>/</td><td>/</td></tr> <tr><td>13. Thumb lateral rotation range</td><td>85°</td><td>65°</td><td>65°</td></tr> <tr><td>14. Angular velocity of thumb movement</td><td>130°/s</td><td>70°/s</td><td>150°/s</td></tr> <tr><td>15. Angular velocity of four-finger movement</td><td>200°/s</td><td>260°/s</td><td>570°/s</td></tr> <tr><td>16. Actuator</td><td colspan="3">6PCS micro actuator</td></tr> <tr><td>17. Max thumb grip</td><td style="color:red;">30N</td><td>15N</td><td>6N</td></tr> <tr><td>18. Max parm finger grip</td><td style="color:red;">30N</td><td>10N</td><td>4N</td></tr> <tr><td>19. Force resolution</td><td>25g (tactile sensor resolution)</td><td>0.5N</td><td>0.5N</td></tr> <tr><td>20. Thumb lateral rotation speed</td><td>130°/s</td><td>107°/s</td><td>235°/s</td></tr> <tr><td>21. Thumb bend speed</td><td>80°/s</td><td>70°/s</td><td>150°/s</td></tr> <tr><td>22. Palm finger bend speed</td><td>200°/s</td><td>260°/s</td><td>570°/s</td></tr> <tr> <td>Application</td> <td> Special Industries<br> Industrial Automation<br> Humanoid Robots<br> Welcome Reception<br> Unmanned Retail<br> Unmanned Laboratories<br> Education and Research<br> Elderly and Disabled Help </td> <td> Humanoid Robots<br> Welcome Reception<br> Unmanned Retail<br> Unmanned Laboratories<br> Education and Research<br> Elderly and Disabled Help </td> <td> Piano Playing<br> Gesture Interaction<br> Welcome Reception<br> Unmanned Laboratories<br> Education and Research </td> </tr> </tbody> </table>Software RH56DFTP Testing Software TCP Connection Check Connection Video Data Sheet RH56DFTP Brochure RH56DFTP Datasheet Other FTP_ROS2 2024-10-25 FTP_URDF_LEFT 2024-10-25 FTP_URDF_RIGHT 2024-10-25 FTP_Python Demo 2024-10-25 3D Files The FTP series integrates 17 tactile sensor in a single hand,which setup allows real-time acquisition of tactile information from various parts, helping to optimize gripping actions and improve operational precision. The FTP series extended its lifespan to over a million, providing long-term reliable support.The fingertips can exert a force of up to 3 kg, making its gripping strength comparable to that of a human hand. Choose the FTP series dexterous hands, ushering in a new era of smart manufacturing.
#html-body [data-pb-style=A6TL81Q],#html-body [data-pb-style=JY6J769],#html-body [data-pb-style=M451E47],#html-body [data-pb-style=U2U23ME],#html-body [data-pb-style=WMF2D59]{justify-content:flex-start;display:flex;flex-direction:column;background-position:left top;background-size:cover;background-repeat:no-repeat;background-attachment:scroll}The FTP series integrates 17 tactile sensor in a single hand,which setup allows real-time acquisition of tactile information from various parts, helping to optimize gripping actions and improve operational precision. The FTP series extended its lifespan to over a million, providing long-term reliable support.The fingertips can exert a force of up to 3 kg, making its gripping strength comparable to that of a human hand.<table border="1" cellpadding="6" cellspacing="0"> <thead> <tr> <th colspan="4">Comparison</th> </tr> <tr> <th>Robot Hands</th> <th> RH56DFTP-0L, RH56DFTP-0R (CAN)<br> RH56DFTP-2L, RH56DFTP-2R (RS485)<br> <span style="color:red;">(newest)</span> </th> <th> RH56DFX-2L<br> RH56DFX-2R<br> <span style="color:red;">(strong grip)</span> </th> <th> RH56BFX-2L<br> RH56BFX-2R<br> <span style="color:red;">(fast speed)</span> </th> </tr> </thead> <tbody> <tr><td>1. Side</td><td colspan="3">Left hand / Right hand</td></tr> <tr><td>2. Control interface</td><td>CAN + ModbusTCP (Optional: RS485)</td><td>RS485</td><td>RS485</td></tr> <tr><td>3. Degree of freedom</td><td>6</td><td>6</td><td>6</td></tr> <tr><td>4. Number of joints</td><td>12</td><td>12</td><td>12</td></tr> <tr><td>5. Weight</td><td>790±10g</td><td>540g</td><td>540g</td></tr> <tr><td>6. Operation Voltage</td><td>DC24V±10%</td><td>DC24V±10%</td><td>DC24V±10%</td></tr> <tr><td>7. Peak Current</td><td>4A</td><td>2A</td><td>2A</td></tr> <tr><td>8. Repeatability</td><td>±0.2mm</td><td>±0.2mm</td><td>±0.2mm</td></tr> <tr><td>9. Max finger grip force</td><td>30N</td><td>4N</td><td>10N</td></tr> <tr><td>10. Number of force sensors</td><td>6</td><td>6</td><td>6</td></tr> <tr><td>11. Number of tactile sensors</td><td style="color:red;">17</td><td>/</td><td>/</td></tr> <tr><td>12. Haptic data refresh rate</td><td>≥ 30Hz</td><td>/</td><td>/</td></tr> <tr><td>13. Thumb lateral rotation range</td><td>85°</td><td>65°</td><td>65°</td></tr> <tr><td>14. Angular velocity of thumb movement</td><td>130°/s</td><td>70°/s</td><td>150°/s</td></tr> <tr><td>15. Angular velocity of four-finger movement</td><td>200°/s</td><td>260°/s</td><td>570°/s</td></tr> <tr><td>16. Actuator</td><td colspan="3">6PCS micro actuator</td></tr> <tr><td>17. Max thumb grip</td><td style="color:red;">30N</td><td>15N</td><td>6N</td></tr> <tr><td>18. Max parm finger grip</td><td style="color:red;">30N</td><td>10N</td><td>4N</td></tr> <tr><td>19. Force resolution</td><td>25g (tactile sensor resolution)</td><td>0.5N</td><td>0.5N</td></tr> <tr><td>20. Thumb lateral rotation speed</td><td>130°/s</td><td>107°/s</td><td>235°/s</td></tr> <tr><td>21. Thumb bend speed</td><td>80°/s</td><td>70°/s</td><td>150°/s</td></tr> <tr><td>22. Palm finger bend speed</td><td>200°/s</td><td>260°/s</td><td>570°/s</td></tr> <tr> <td>Application</td> <td> Special Industries<br> Industrial Automation<br> Humanoid Robots<br> Welcome Reception<br> Unmanned Retail<br> Unmanned Laboratories<br> Education and Research<br> Elderly and Disabled Help </td> <td> Humanoid Robots<br> Welcome Reception<br> Unmanned Retail<br> Unmanned Laboratories<br> Education and Research<br> Elderly and Disabled Help </td> <td> Piano Playing<br> Gesture Interaction<br> Welcome Reception<br> Unmanned Laboratories<br> Education and Research </td> </tr> </tbody> </table>Software RH56DFTP Testing Software TCP Connection Check Connection Video Data Sheet RH56DFTP Brochure RH56DFTP Datasheet Other FTP_ROS2 2024-10-25 FTP_URDF_LEFT 2024-10-25 FTP_URDF_RIGHT 2024-10-25 FTP_Python Demo 2024-10-25 3D Files
Histórico de preços
Um ponto de dados por dia, calculado pela média com base na data da observação.
Valores em USD
As médias são calculadas por dia UTC com base nos preços de todas as ofertas registradas.

Inspire Robots
a partir de $5.600
Inspire Robots
£4.115,88
Inspire Robots
£4.115,88

Inspire Robots
$4.500

Inspire Robots
$4.500

Inspire Robots
$6.294

Inspire Robots
$6.294

Inspire Robots
5.900 €

Inspire Robots
a partir de $6.500

Inspire Robots
a partir de $5.750

Inspire Robots
a partir de $4.500

Inspire Robots
$7.500
🍪 Preferências de cookies
Usamos cookies para medir o desempenho. Política de privacidade