Preço médio diário
Valores em USD
Descrição
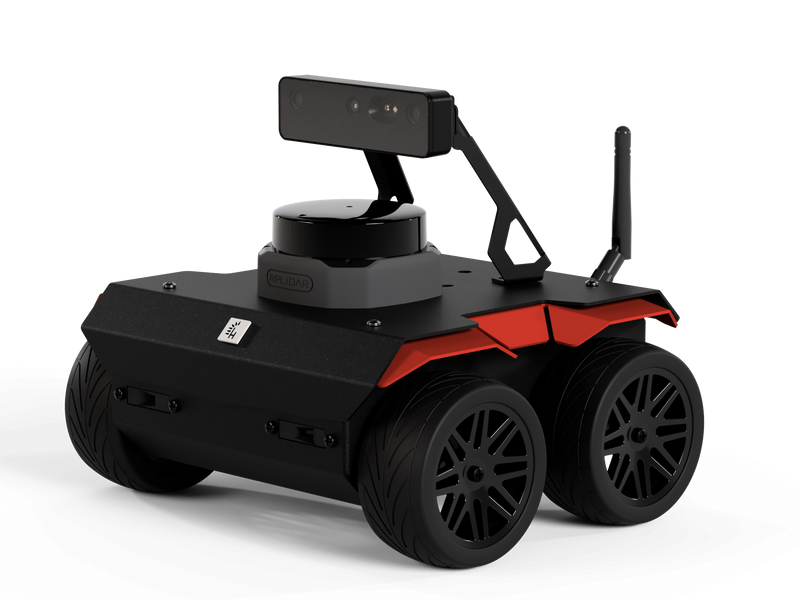
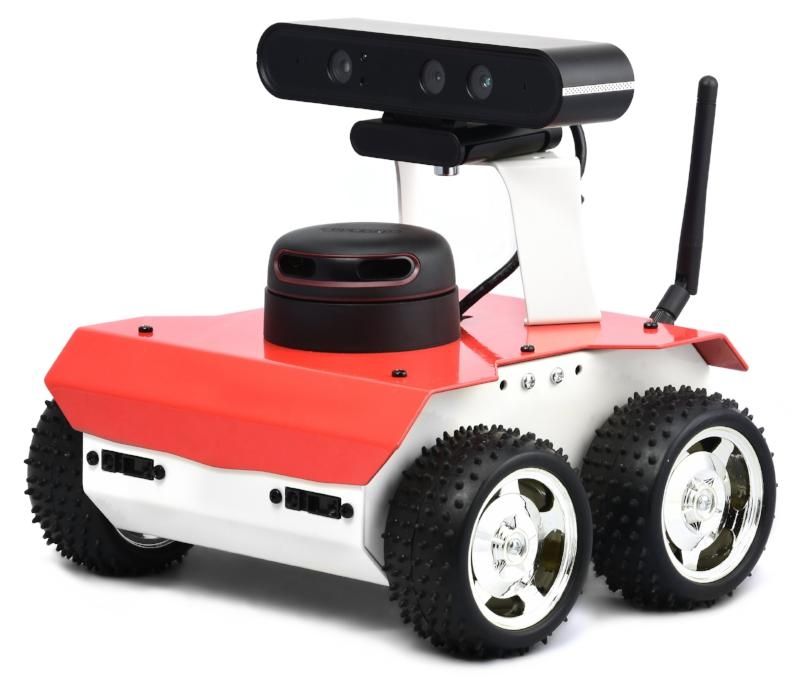
ROSbot 3 / ROSbot 3 PRO is an indoor mobile robot platform, purpose-built for research and education. Powered by a Raspberry Pi 5 and constructed with a durable 1.5mm alloy chassis, it offers robust performance and reliability. The ROSbot 3 features a SLAMTEC C1 LIDAR and Luxonis OAK-D Lite camera, while the ROSbot 3 PRO is equipped with an enhanced SLAMTEC S2 LIDAR and OAK-D Pro camera for superior perception and SLAM capabilities. The open-source ROS 2 drivers are pre-installed and configured, enabling out-of-the-box operation without additional setup. Users can start interacting with the ROSbot through a web-based interface or a gamepad—no coding required—making it an ideal platform for beginners and experts alike. With four DC motors, each equipped with independent quadrature encoders, ROSbot 3 provides precise motion control for navigating complex indoor environments, accelerating your research and development in robotics. It integrates: CPU: Raspberry Pi 5 (8GB RAM, VideoCore VII GPU) Storage: 64GB microSD card IMU: BNO055 (accelerometer + gyro) Distance sensor: VL53L0X (time-of-flight) Networking: 2.4 GHz and 5 GHz 802.11b/g/n/ac wireless LAN 4-wheel mobile platform with DC motors Li-on batteries: 3 x 3500 mAh (with protection circuits) Rear panel providing interfaces for additional modules Robust aluminium chassis In ROSbot 3 RGBD Camera: Luxonis OAK-D Lite LIDAR: Slamtec RPLIDAR C1 In ROSbot 3 PRO RGBD Camera: Luxonis OAK-D Pro LIDAR: Slamtec RPLIDAR S2 Component Quantity Description Infrared distance sensor 4 VL53L0X Time-of-Flight distance sensor with up to 200 cm range Built-in Microcontroller 1 STM32F407 DC motor 4 Xinhe Motor XH-25D, Motor used: RF-370, 6VDC nominal, 6200rpm. Maximum mechanical power: 4W, no load speed at the output shaft: 180 rpm, stall torque at the output shaft: 2.9 kg*cm, stall current: 2.0A, gear ratio: ~34 (exact ratio is 30613/900) Encoder 4 Magnetic, 48cpr, 12 poles Batteries 3 Li-Ion 18650 protected, rechargeable batteries, 3500mAh capacity, 3.7V nominal voltage. Note: Device may be shipped interchangeably with similar batteries. SBC 1 Raspberry Pi 5 (ARM64 architecture) quad-core ARM-8 Cortex A76 @ 2.4GHz, 8GB RAM and 64 GB MicroSD flash memory. The SBC runs on Ubuntu-based OS, customized to use ROS. 3D camera 1 Luxonis OAK-D Lite (in ROSbot 3) / OAK-D Pro (in ROSbot 3 PRO) LIDAR 1 RPLIDAR C1 (in ROSbot 3) / S2 (in ROSbot 3 PRO), 360 degree IMU sensor 1 Intelligent 9-axis absolute orientation sensor BNO055 Antenna 1 Dual-band, connected to the Wi-Fi USB adapter. Set contains: ROSbot 3/3 PRO Dedicated charger USB Ethernet Adapter Aluminium Case Resources ROSbot 3/3 PRO manual ROSbot 3 quick start guide [1] WH12 option is included as a base only for ROSbot 3 PRO. ROSbot 3 / ROSbot 3 PRO is an indoor mobile robot platform, purpose-built for research and education. Powered by a Raspberry Pi 5 and constructed with a durable 1.5mm alloy chassis, it offers robust performance and reliability.
ROSbot 3 / ROSbot 3 PRO is an indoor mobile robot platform, purpose-built for research and education. Powered by a Raspberry Pi 5 and constructed with a durable 1.5mm alloy chassis, it offers robust performance and reliability. The ROSbot 3 features a SLAMTEC C1 LIDAR and Luxonis OAK-D Lite camera, while the ROSbot 3 PRO is equipped with an enhanced SLAMTEC S2 LIDAR and OAK-D Pro camera for superior perception and SLAM capabilities. The open-source ROS 2 drivers are pre-installed and configured, enabling out-of-the-box operation without additional setup. Users can start interacting with the ROSbot through a web-based interface or a gamepad—no coding required—making it an ideal platform for beginners and experts alike. With four DC motors, each equipped with independent quadrature encoders, ROSbot 3 provides precise motion control for navigating complex indoor environments, accelerating your research and development in robotics. It integrates: CPU: Raspberry Pi 5 (8GB RAM, VideoCore VII GPU) Storage: 64GB microSD card IMU: BNO055 (accelerometer + gyro) Distance sensor: VL53L0X (time-of-flight) Networking: 2.4 GHz and 5 GHz 802.11b/g/n/ac wireless LAN 4-wheel mobile platform with DC motors Li-on batteries: 3 x 3500 mAh (with protection circuits) Rear panel providing interfaces for additional modules Robust aluminium chassis In ROSbot 3 RGBD Camera: Luxonis OAK-D Lite LIDAR: Slamtec RPLIDAR C1 In ROSbot 3 PRO RGBD Camera: Luxonis OAK-D Pro LIDAR: Slamtec RPLIDAR S2 Component Quantity Description Infrared distance sensor 4 VL53L0X Time-of-Flight distance sensor with up to 200 cm range Built-in Microcontroller 1 STM32F407 DC motor 4 Xinhe Motor XH-25D, Motor used: RF-370, 6VDC nominal, 6200rpm. Maximum mechanical power: 4W, no load speed at the output shaft: 180 rpm, stall torque at the output shaft: 2.9 kg*cm, stall current: 2.0A, gear ratio: ~34 (exact ratio is 30613/900) Encoder 4 Magnetic, 48cpr, 12 poles Batteries 3 Li-Ion 18650 protected, rechargeable batteries, 3500mAh capacity, 3.7V nominal voltage. Note: Device may be shipped interchangeably with similar batteries. SBC 1 Raspberry Pi 5 (ARM64 architecture) quad-core ARM-8 Cortex A76 @ 2.4GHz, 8GB RAM and 64 GB MicroSD flash memory. The SBC runs on Ubuntu-based OS, customized to use ROS. 3D camera 1 Luxonis OAK-D Lite (in ROSbot 3) / OAK-D Pro (in ROSbot 3 PRO) LIDAR 1 RPLIDAR C1 (in ROSbot 3) / S2 (in ROSbot 3 PRO), 360 degree IMU sensor 1 Intelligent 9-axis absolute orientation sensor BNO055 Antenna 1 Dual-band, connected to the Wi-Fi USB adapter. Set contains: ROSbot 3/3 PRO Dedicated charger USB Ethernet Adapter Aluminium Case Resources ROSbot 3/3 PRO manual ROSbot 3 quick start guide [1] WH12 option is included as a base only for ROSbot 3 PRO.
Histórico de preços
Um ponto de dados por dia, calculado pela média com base na data da observação.
Valores em USD
As médias são calculadas por dia UTC com base nos preços de todas as ofertas registradas.
Husarion
4.080 €
Husarion
£3.191,90
Husarion
5.472 €
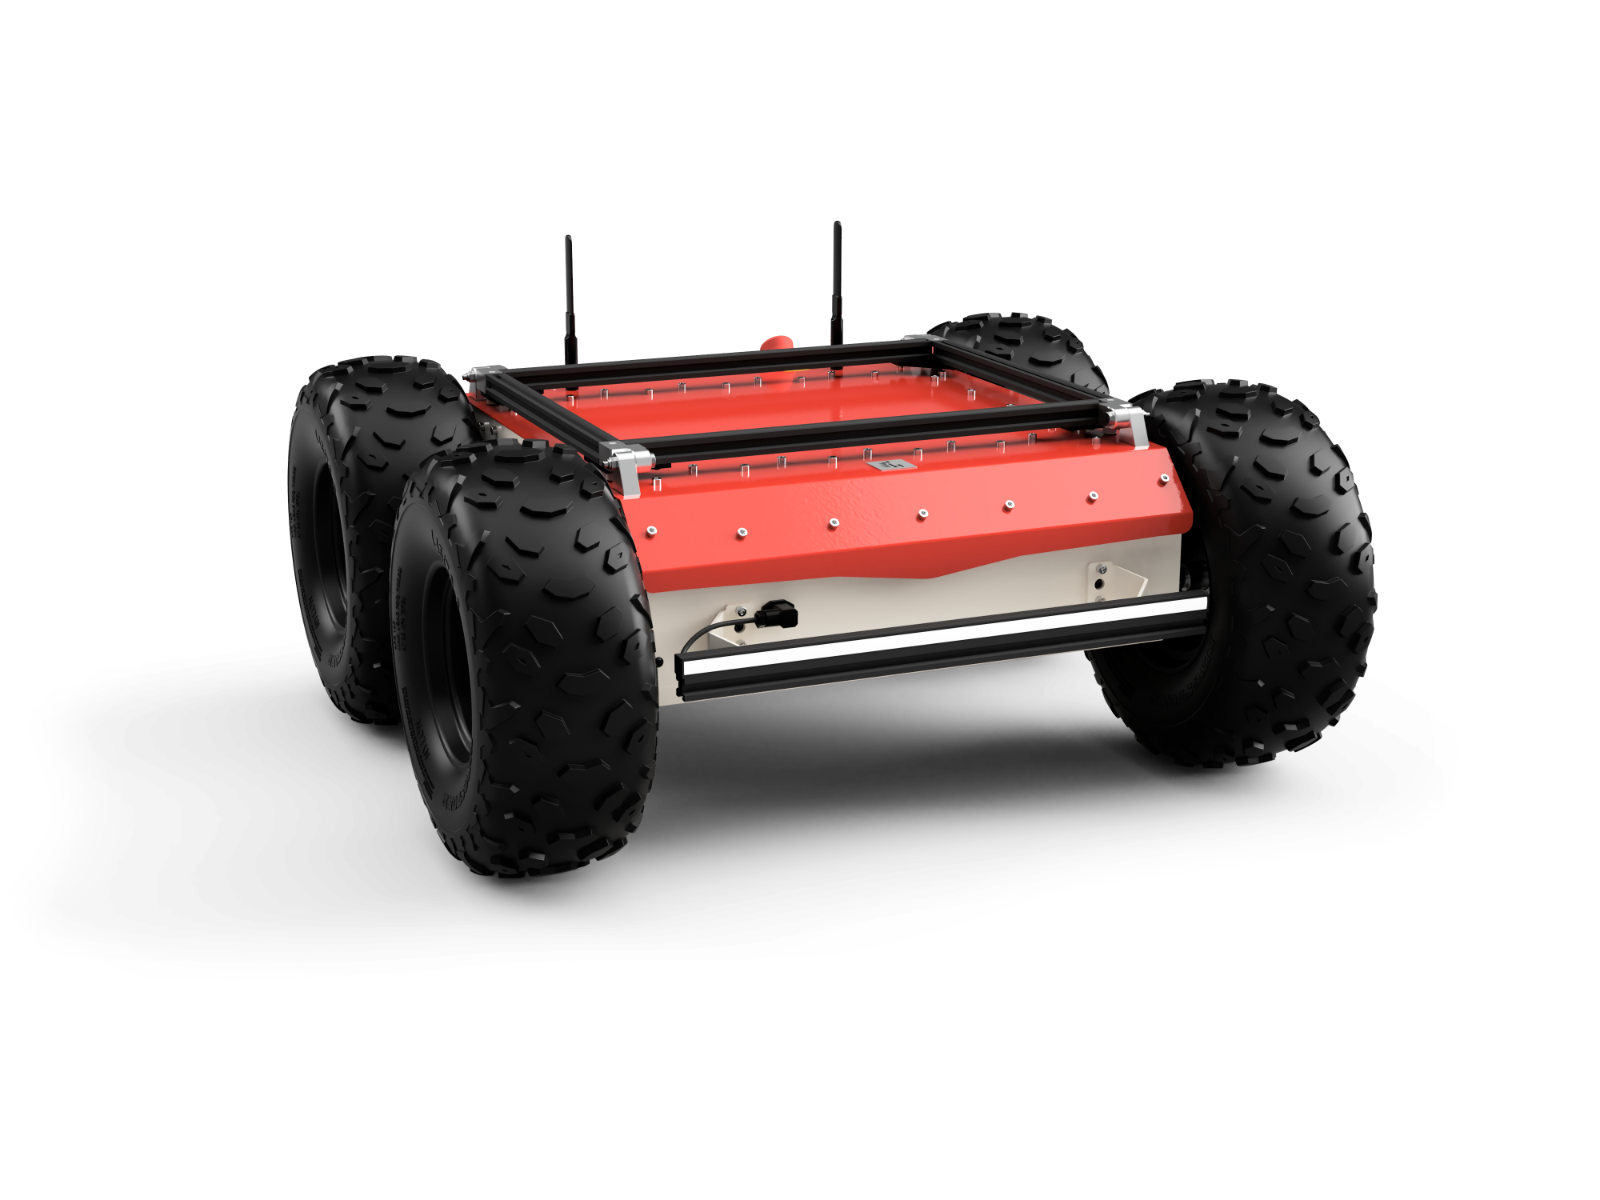
Husarion
£14.620,03
Husarion
£1.121,25
AgileX
2.400 €
Robotis
£2.232,71
Robotis
£2.215,05
Robotis
£2.215,05

Elephant Robotics
$2.399

Elephant Robotics
$2.499

Dobot
2.399 €
🍪 Preferências de cookies
Usamos cookies para medir o desempenho. Política de privacidade