Gemiddelde prijs per dag
Bedragen in USD
Beschrijving
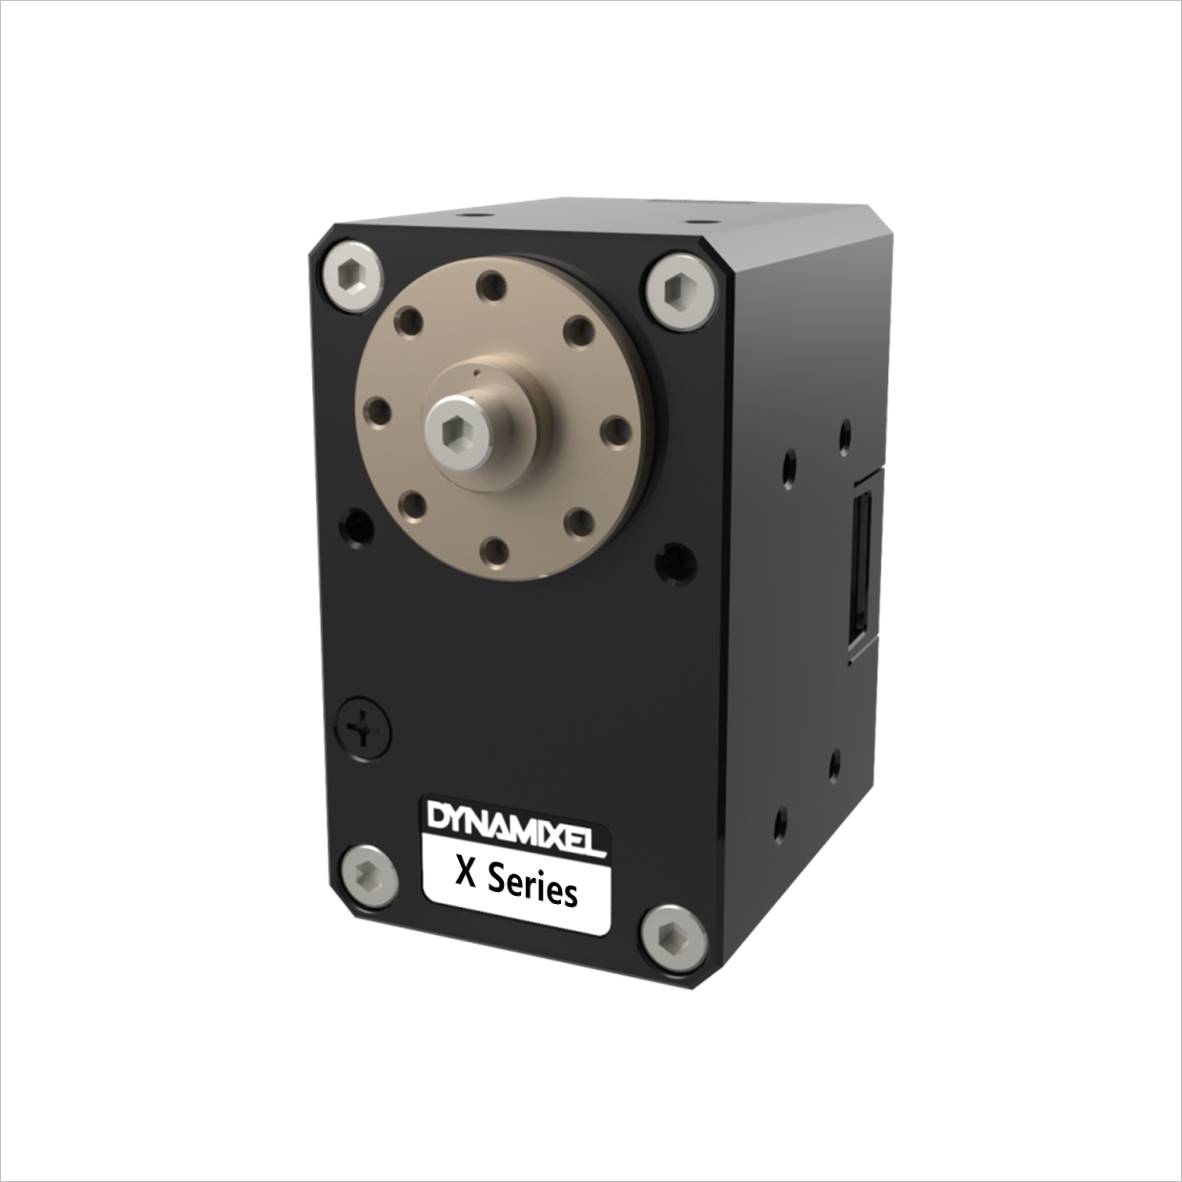
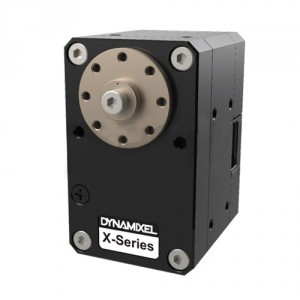
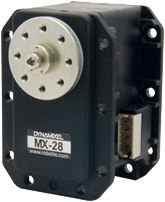
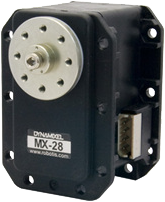
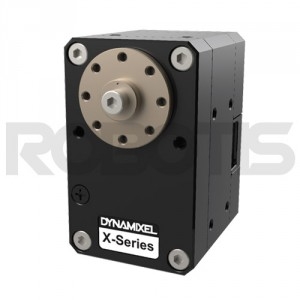
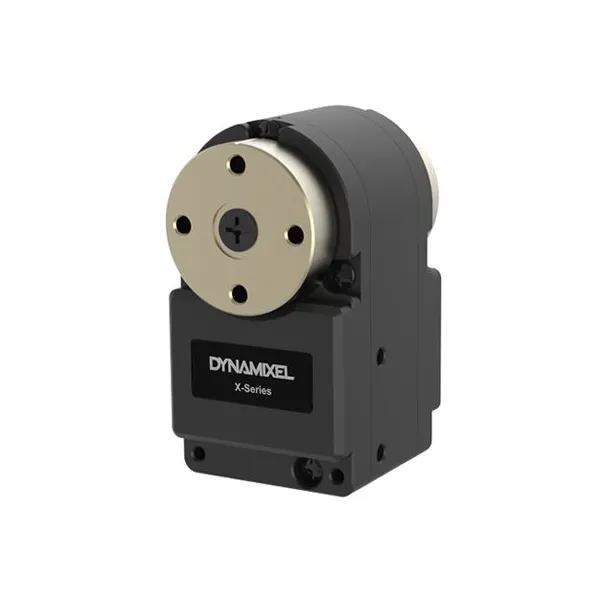
Features Improved Torque, Compact Size Enhanced Durability and Expandability Hollow Back Case Minimizes Cable Stress (3-way-routing) Direct Screw Assembly to the Case(without Nut Insert) Improved Heat Sink Featuring an Aluminum Case 6 Operating Modes Current-Based Torque Control (4096 steps, 2.69mA/step) Profile Control for Smooth Motion Planning Trajectory Data and Moving Status (In-Position, Following Error, etc.) Energy Saving (Reduced Current from 100mA to 40mA) Package Contents Description Quantity DYNAMIXEL XM430-W350-R 1 HORN HN12-N101 1 WASHER Teflon Washer (for Horn Assembly) 1 CABLE Robot Cable-X4P 180mm 1 Robot Cable-X4P (Convertible) 180mm 1 BOLT/NUT Wrench Bolt (WB M2.5*4) 16 Wrench Bolt (WB M2.5*8) 1 Wrench Bolt (WB M2*3) 10 ETC Spacer Ring 8 Hardware Specification Model Number XM430-W350-R Weight 82g Dimension 28.5mm x 46.5mm x 34mm Gear Ratio 353.5 : 1 Operation Voltage (V) 11.1 12 14.8 Stall Torque (N.m) 3.8 4.1 4.8 Stall Current (A) 2.1 2.3 2.6 No Load Speed (RPM) 43 46 57 MCU ST CORTEX-M3 ( STM32F103C8 @ 72MHZ, 32BIT) Position Sensor Contactless absolute encoder (12bit, 360degree) by AMS Motor Coreless Motor Resolution Approx. 0.088° x 4,096 Operation Range Position Control Mode : 360° Extended Position Control Mode : 512 turns Velocity Control Mode : Endless turn Operation Voltage 10~14.8V (Recommended voltage : 12V) Operating Temperature -5°C ~ 80°C Command Signal Digital Packet Protocol Type RS485 Asynchronous Serial Communication (8bit, 1stop, No Parity) Link (physical) RS485 Multi Drop Bus (daisy chain type connector) ID 253 ID (0~252) Baud Rate 9600 bps ~ 4.5 Mbps Feedback Position, Velocity, Current, Realtime tick, Trajectory, Temperature, Input Voltage, etc. Material Case : Metal (Front, Middle) Engineering Plastic (Back) Gear : Full Metal Standby current 40 mA Default Settings ID : 1 Baud Rate : 57,600bps (Please make necessary modifications after purchase. Such as the ID, baud rate, etc) Compatible Devices Embedded Board : OpenCM9.04 + 485 Expansion Board PC Interface : USB2Dynamixel (Molex-JST Convertible Cable is required) Development Environment GUI Software : RoboPlus 2.0 (Task / Motion / Manager) : download OpenCM IDE : download SDK : download Drawings : download E-manual : link PLEASE NOTE DYNAMIXEL X-Series adopted new JST connector with gold plating for secure and reliable communication. For more information, please visit e-Manual [DYNAMIXEL Connector Standard] To control DYNAMIXEL X-Series via OpenCM or USB2Dynamixel, please use JST-Molex Convertible Cable enclosed in the package. DYNAMIXEL X-Series is a new line-up of high performance networked actuator module, which has been widely used for building multi-joint robots with reliability and expandability.
Features Improved Torque, Compact Size Enhanced Durability and Expandability Hollow Back Case Minimizes Cable Stress (3-way-routing) Direct Screw Assembly to the Case(without Nut Insert) Improved Heat Sink Featuring an Aluminum Case 6 Operating Modes Current-Based Torque Control (4096 steps, 2.69mA/step) Profile Control for Smooth Motion Planning Trajectory Data and Moving Status (In-Position, Following Error, etc.) Energy Saving (Reduced Current from 100mA to 40mA) Package Contents Description Quantity DYNAMIXEL XM430-W350-R 1 HORN HN12-N101 1 WASHER Teflon Washer (for Horn Assembly) 1 CABLE Robot Cable-X4P 180mm 1 Robot Cable-X4P (Convertible) 180mm 1 BOLT/NUT Wrench Bolt (WB M2.5*4) 16 Wrench Bolt (WB M2.5*8) 1 Wrench Bolt (WB M2*3) 10 ETC Spacer Ring 8 Hardware Specification Model Number XM430-W350-R Weight 82g Dimension 28.5mm x 46.5mm x 34mm Gear Ratio 353.5 : 1 Operation Voltage (V) 11.1 12 14.8 Stall Torque (N.m) 3.8 4.1 4.8 Stall Current (A) 2.1 2.3 2.6 No Load Speed (RPM) 43 46 57 MCU ST CORTEX-M3 ( STM32F103C8 @ 72MHZ, 32BIT) Position Sensor Contactless absolute encoder (12bit, 360degree) by AMS Motor Coreless Motor Resolution Approx. 0.088° x 4,096 Operation Range Position Control Mode : 360° Extended Position Control Mode : 512 turns Velocity Control Mode : Endless turn Operation Voltage 10~14.8V (Recommended voltage : 12V) Operating Temperature -5°C ~ 80°C Command Signal Digital Packet Protocol Type RS485 Asynchronous Serial Communication (8bit, 1stop, No Parity) Link (physical) RS485 Multi Drop Bus (daisy chain type connector) ID 253 ID (0~252) Baud Rate 9600 bps ~ 4.5 Mbps Feedback Position, Velocity, Current, Realtime tick, Trajectory, Temperature, Input Voltage, etc. Material Case : Metal (Front, Middle) Engineering Plastic (Back) Gear : Full Metal Standby current 40 mA Default Settings ID : 1 Baud Rate : 57,600bps (Please make necessary modifications after purchase. Such as the ID, baud rate, etc) Compatible Devices Embedded Board : OpenCM9.04 + 485 Expansion Board PC Interface : USB2Dynamixel (Molex-JST Convertible Cable is required) Development Environment GUI Software : RoboPlus 2.0 (Task / Motion / Manager) : download OpenCM IDE : download SDK : download Drawings : download E-manual : link PLEASE NOTE DYNAMIXEL X-Series adopted new JST connector with gold plating for secure and reliable communication. For more information, please visit e-Manual [DYNAMIXEL Connector Standard] To control DYNAMIXEL X-Series via OpenCM or USB2Dynamixel, please use JST-Molex Convertible Cable enclosed in the package.
Prijsgeschiedenis
Eén gegevenspunt per dag, gemiddeld per waarnemingsdatum.
Bedragen in USD
Gemiddelden worden per UTC-dag berekend op basis van alle geregistreerde aanbiedingsprijzen.
Robotis
325,56 €

Robotis
$333,39
Robotis
223,40 €
Robotis
223,08 €
Robotis
£224,24
Robotis
£208,54
Robotis
£231,81
Robotis
£224,02
Robotis
£208,53
Robotis
£224,02
Robotis
£208,79
Robotis
174 €
🍪 Cookievoorkeuren
We gebruiken cookies om de prestaties te meten. Privacybeleid