일일 평균 가격
USD 기준 금액
설명
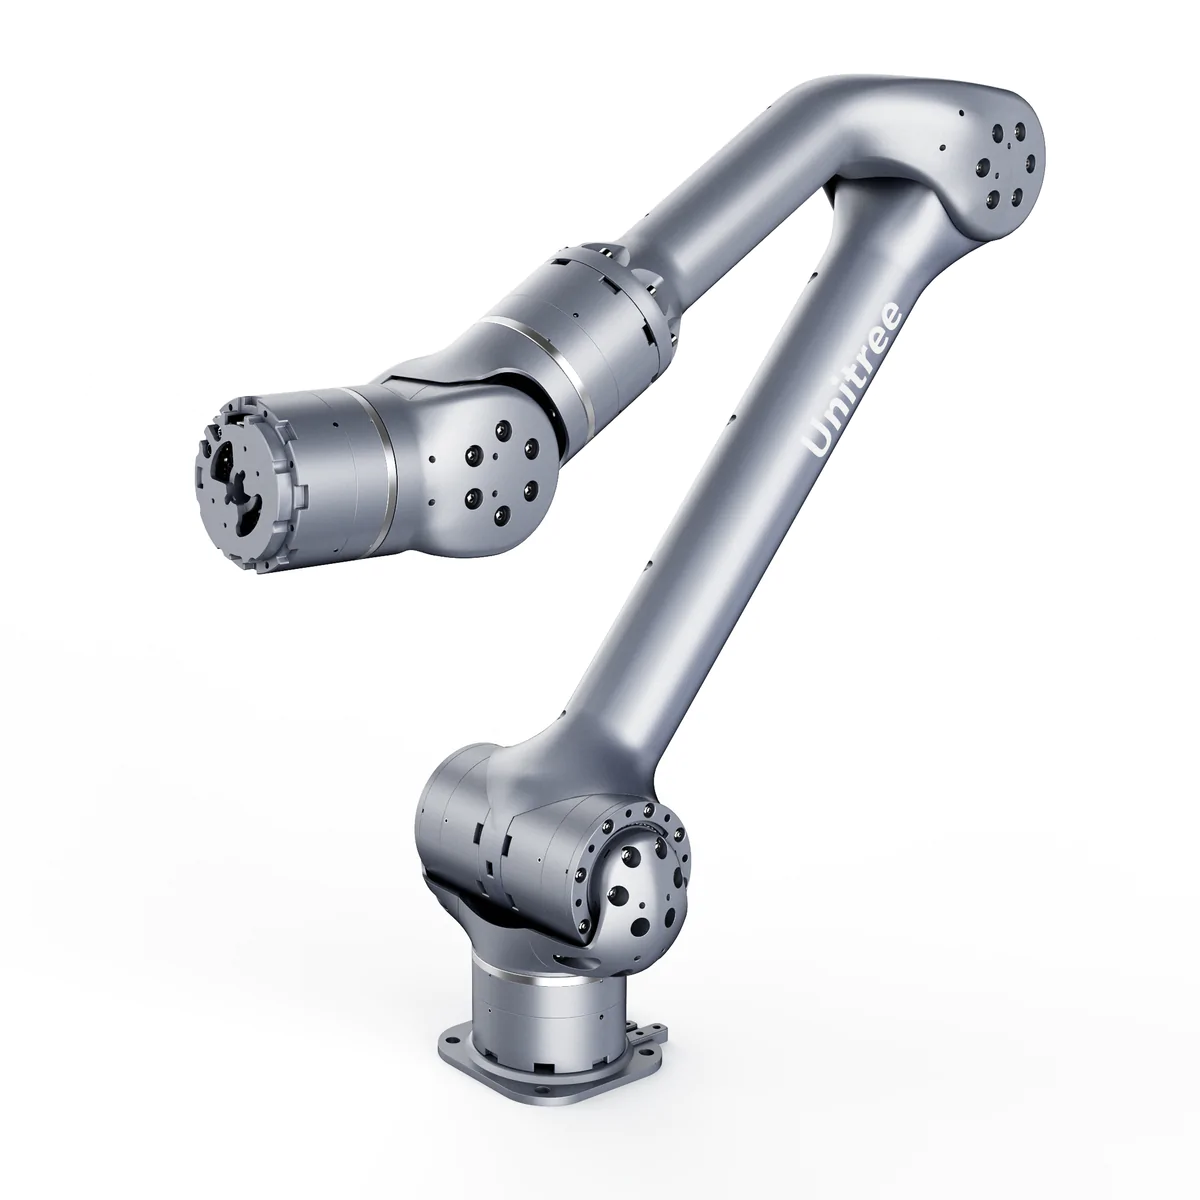
.containerimgtext { position: relative; text-align: center; color: white; } .bottom-leftimgtext { position: absolute; bottom: 8px; left: 16px; } .top-leftimgtext { position: absolute; top: 8px; left: 16px; } .top-rightimgtext { position: absolute; top: 8px; right: 16px; } .bottom-rightimgtext { position: absolute; bottom: 8px; right: 16px; } .centeredimgtext { position: absolute; top: 50%; left: 25%; transform: translate(-50%, -50%); } Compact & Lightweight Dexterous & Flexible Sufficient Payload Sufficient Accuracy Support Joint Force Control With Collision Protection Open Programming Interface and Extended Interface The manipulator control program and control interface are successively opened, and different actuators can be quickly replaced at the end of the manipulator. Application Various mobile robots, mobile robot onboard manipulator, e-commerce logistics, new consumption, daily life, etc. Synergy It can cooperate with Aliengo or B1 quadruped and other mobile robots to complete complex tasks and explore various application scenarios. Model Z1 AIR Z1 PRO DOF 6 6 Weight 4.1kg 4.3 Payload 2kg 3-5kg Reach 700mm Repeatability * ~0.1 mm Power Supply Voltage 24V Current > 20A Interface Ethernet User Operating System Ubuntu Force Feedback and Collision Detection Provide Power MAX 500w Control Interface Position + Force Control Joint Range Max Speed J1 +- 150º 180º/s J2 +- 90º 180º/s J3 +- 90º 180º/s J4 +- 160º 180º/s J5 +- 90º 180º/s J6 +- 162º 180º/s * It depends on the actual test according to the use requirements (the test standards of manipulator vary greatly, and the accuracy varies greatly under different test conditions) ** Since the reduction ratio used by each joint is relatively low, the position control stiffness of the whole machine is low. If the control mode is not optimized, there will be large position control error and shaking when the manipulator moves. FUNCTION PARAMETER Backlash ~6 arcmin Maximum Torque 33 N.m Weight 405g Size 65*50mm Reducer Harmonic Reducer Reduction Ratio 60+ Voltage 24V (Recommended) Communication Method RS 485 Encoder Resolution 15bit Bearing Industrial Grade cross roller Motor Sensing Feedback Torque, Angle, angular velocity Motor Control Command Torque, angle, angular velocity, stiffness, damping Force Control Accuracy ~0.2 N.m Control Frequency 1KHz Unitree - Z1 Robot Arm
.containerimgtext { position: relative; text-align: center; color: white; } .bottom-leftimgtext { position: absolute; bottom: 8px; left: 16px; } .top-leftimgtext { position: absolute; top: 8px; left: 16px; } .top-rightimgtext { position: absolute; top: 8px; right: 16px; } .bottom-rightimgtext { position: absolute; bottom: 8px; right: 16px; } .centeredimgtext { position: absolute; top: 50%; left: 25%; transform: translate(-50%, -50%); } Compact & Lightweight Dexterous & Flexible Sufficient Payload Sufficient Accuracy Support Joint Force Control With Collision Protection Open Programming Interface and Extended Interface The manipulator control program and control interface are successively opened, and different actuators can be quickly replaced at the end of the manipulator. Application Various mobile robots, mobile robot onboard manipulator, e-commerce logistics, new consumption, daily life, etc. Synergy It can cooperate with Aliengo or B1 quadruped and other mobile robots to complete complex tasks and explore various application scenarios. Model Z1 AIR Z1 PRO DOF 6 6 Weight 4.1kg 4.3 Payload 2kg 3-5kg Reach 700mm Repeatability * ~0.1 mm Power Supply Voltage 24V Current > 20A Interface Ethernet User Operating System Ubuntu Force Feedback and Collision Detection Provide Power MAX 500w Control Interface Position + Force Control Joint Range Max Speed J1 +- 150º 180º/s J2 +- 90º 180º/s J3 +- 90º 180º/s J4 +- 160º 180º/s J5 +- 90º 180º/s J6 +- 162º 180º/s * It depends on the actual test according to the use requirements (the test standards of manipulator vary greatly, and the accuracy varies greatly under different test conditions) ** Since the reduction ratio used by each joint is relatively low, the position control stiffness of the whole machine is low. If the control mode is not optimized, there will be large position control error and shaking when the manipulator moves. FUNCTION PARAMETER Backlash ~6 arcmin Maximum Torque 33 N.m Weight 405g Size 65*50mm Reducer Harmonic Reducer Reduction Ratio 60+ Voltage 24V (Recommended) Communication Method RS 485 Encoder Resolution 15bit Bearing Industrial Grade cross roller Motor Sensing Feedback Torque, Angle, angular velocity Motor Control Command Torque, angle, angular velocity, stiffness, damping Force Control Accuracy ~0.2 N.m Control Frequency 1KHz
가격 변동 내역
관측 날짜별로 평균한 일일 데이터 포인트 하나를 표시합니다.
USD 기준 금액
기록된 모든 상품 가격을 협정 세계시 기준 날짜별로 평균합니다.

Unitree
7,563 €

Unitree
9,280 €
 판매
Unitree
$13,900$11,81515% 절약

Unitree
$11,900
 판매
Unitree
$16,050$13,85814% 절약

Unitree
$11,900부터

Unitree
$11,900

Unitree
$13,900

Unitree
$11,800부터

Unitree
15,349 €
Unitree
$16,050
Unitree
8,112 €
🍪 쿠키 설정
성능 측정을 위해 쿠키를 사용합니다. 개인정보 처리방침