일일 평균 가격
USD 기준 금액
설명
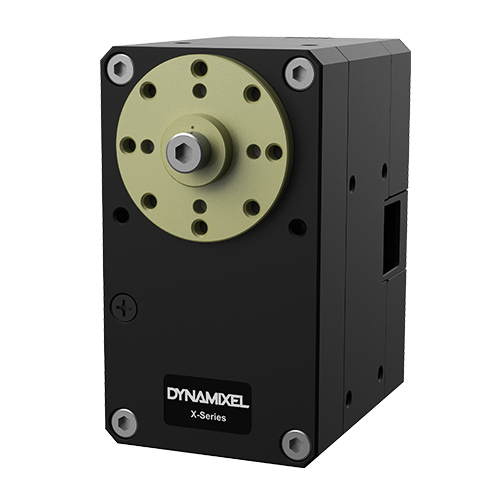
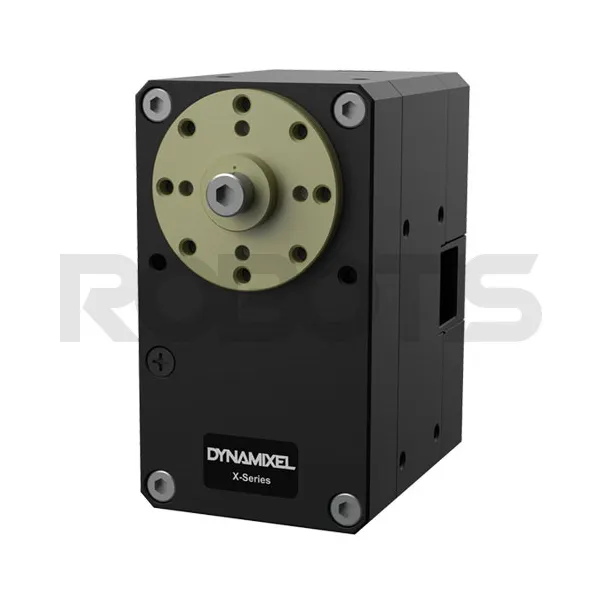
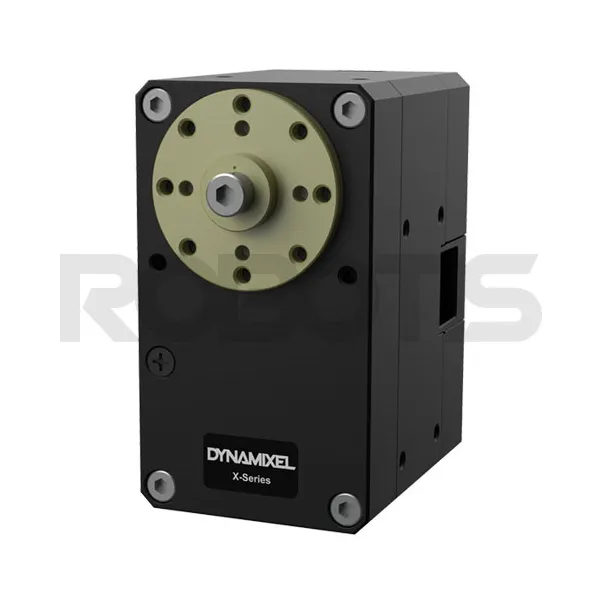
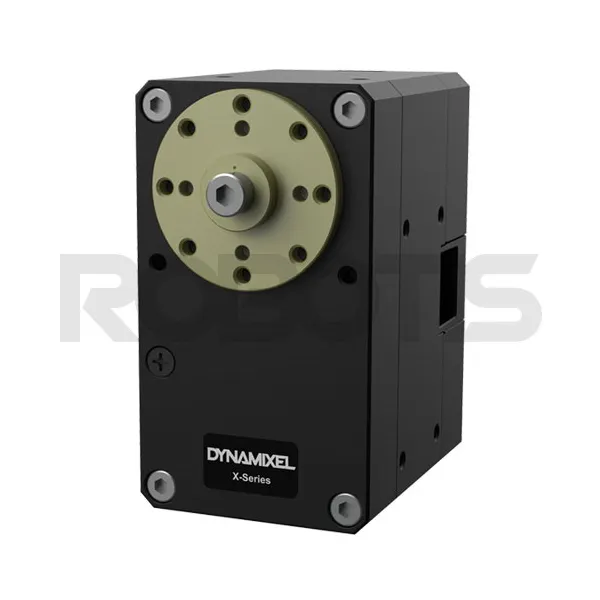
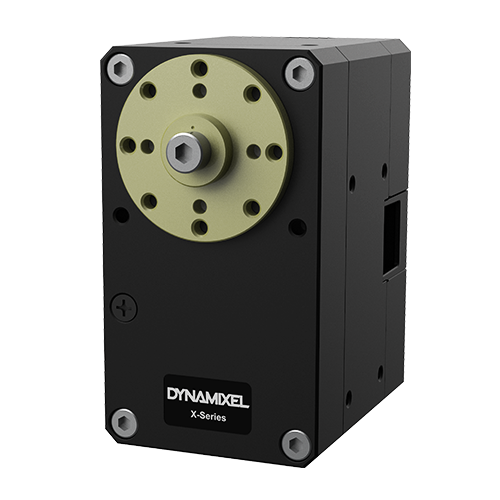
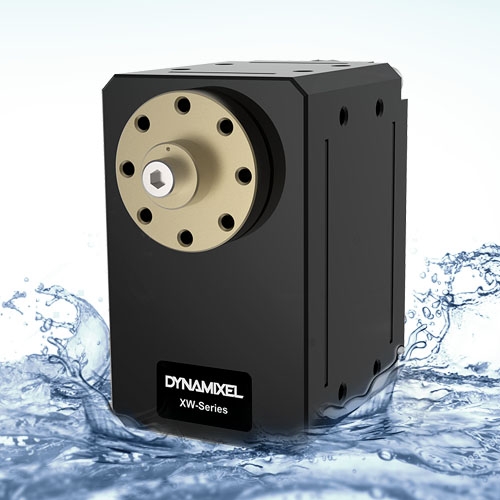
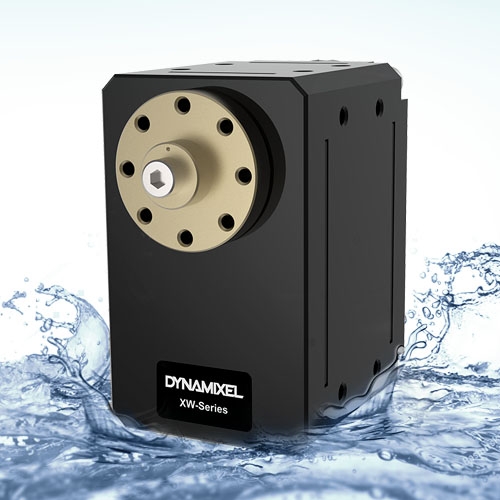
Features DYNAMIXEL-XD series is a high-performance lineup specially designed for industrial applications. The XD series shares an identical form factor with the XH/XM series and has long lifetime with a robust metal gear. The aluminum housing and the hollow cable assembly technique are adopted to maximize user convenience. 1. 6 Operating Modes (Torque Control, Velocity Control, Position Control, Extended Position Control, Current based Position Control, PWM Control) 2. Profile Control for Smooth Motion Planning 3. Improved Heat Dissipation with Aluminum Housing 4. Hollow Back Housing Minimizes Cable Stress (3-way-routing) 5. Easy and Simple Assembly Structure 6. Energy Efficient (Reduced Standby Current from 100mA to 40mA) Package Components Item Quantity Description XD540-T270-R 1 DYNAMIXEL HN13-N101 1 Standard horn for X540 models Thrust Washer (for Horn Assembly) 1 Preventing friction between horn and case Robot Cable-X4P 180mm 1 RS485 4p Cable (JST-JST) Robot Cable-X4P (Convertible) 180mm 1 RS485 4p Cable (MOLEX-JST) Robot Cable-3P-Sync 160mm 1 Cable for Dual Joints Wrench Bolt WB M2.5x5 16 For frame assembly (Side hole) Wrench Bolt WB M2.5x4 10 For frame assembly Wrench Bolt WB M3x8 1 For horn assembly Spacer Ring 8 For frame assembly Various Cabling Methods Drawing Drawing Download Compatible Products Caution DYNAMIXEL-X Series cable assembly through hollow case Organize the entangled cable before assembling the back case. Do not assemble the back case with entangled cable. The entangled cable can be squashed by the case and cause communication error. If you use two cables through the hollow case, the cables will be damaged. Use only one cable through the hollow case. The DYNAMIXEL-X Series adopted a new gold-plated JST connector for secure and reliable communication. The connector used for the previous DYNAMIXEL is Molex. To control DYNAMIXEL-X Series actuators via OpenCM or USB2Dynamixel, please use the JST-Molex Convertible Cable enclosed in the package. However, the Molex-JST convertible cable is NOT included in the XL430 model. Please purchase a convertible cable when using a controller and interface that supports the JST connector. Installation Example Specification Model Name XD540-T270-R Series DYNAMIXEL X MCU ARM Cortex-M3 (72 [Mhz], 32 [bit]) Input Voltage Min. [V] 10.0 Recommended [V] 12.0 Max. [V] 14.8 Performance Characteristics Voltage [V] 12.0 Stall Torque [N·m] 9.90 Stall Current [A] 4.9 No Load Speed [rpm] 39.0 No Load Current [A] 0.07 Continuous Operation Voltage [V] - Torque [N·m] - Speed [rpm] - Current [A] - Resolution Resolution [deg/pulse] 0.0879000000 Step [pulse/rev] 4,096 Angle [degree] 360 Position Sensor Contactless absolute encoder (12 [bit], 360 [deg])Maker : ams(www.ams.com), Part No : AS5045 Operating Temperature Min. [°C] -5 Max. [°C] 80 Motor Coreless (Maxon) Baud Rate Min. [bps] 9,600 Max. [bps] 4,500,000 Control Algorithm PID Gear Type Spur Gear Material Metal Case Material Metal(Front, Middle) Engineering Plastic(Back) Dimensions (WⅹHⅹD) [mm] 33.5 x 58.5 x 44 Dimensions (WⅹHⅹD) [inch] 1.32 x 2.30 x 1.73 Weight [g] 170.00 Weight [oz] 5.99 Gear Ratio 272.5 : 1 Backlash [arcmin] - Backlash [deg] - Command Signal Digital Packet Protocol Type Half duplex Asynchronous Serial Communication (8bit, 1stop, No Parity) Link (Physical) RS485 Multidrop Bus ID 0 ~ 252 Feedback Position, Velocity, Current, Realtime tick, Trajectory, Temperature, Voltage, External Port, etc. Protocol version Protocol 1.0Protocol 2.0(Default) Operating Mode / Angle Current Control mode:Endless turnVelocity Control mode:Endless turnPosition Control Mode:360 [deg]Extended Position Control Mode:±256 [rev]Current-based Position Control Mode:±256 [rev]PWM Control Mode:Endless turn Output [W] - Standby Current [mA] 40 Link ○ e-Manual ○ Drawing ○ Software (DYNAMIXEL Wizard 2.0) ○ Compatibility Guide ○ Selection Guide ○ DYNAMIXEL SDK ○ [Video] Quick Start Guide 12.0V / 9.90Nm / 39.00rpm / Maxon / Long Life / RS-485
Features DYNAMIXEL-XD series is a high-performance lineup specially designed for industrial applications. The XD series shares an identical form factor with the XH/XM series and has long lifetime with a robust metal gear. The aluminum housing and the hollow cable assembly technique are adopted to maximize user convenience. 1. 6 Operating Modes (Torque Control, Velocity Control, Position Control, Extended Position Control, Current based Position Control, PWM Control) 2. Profile Control for Smooth Motion Planning 3. Improved Heat Dissipation with Aluminum Housing 4. Hollow Back Housing Minimizes Cable Stress (3-way-routing) 5. Easy and Simple Assembly Structure 6. Energy Efficient (Reduced Standby Current from 100mA to 40mA) Package Components Item Quantity Description XD540-T270-R 1 DYNAMIXEL HN13-N101 1 Standard horn for X540 models Thrust Washer (for Horn Assembly) 1 Preventing friction between horn and case Robot Cable-X4P 180mm 1 RS485 4p Cable (JST-JST) Robot Cable-X4P (Convertible) 180mm 1 RS485 4p Cable (MOLEX-JST) Robot Cable-3P-Sync 160mm 1 Cable for Dual Joints Wrench Bolt WB M2.5x5 16 For frame assembly (Side hole) Wrench Bolt WB M2.5x4 10 For frame assembly Wrench Bolt WB M3x8 1 For horn assembly Spacer Ring 8 For frame assembly Various Cabling Methods Drawing Drawing Download Compatible Products Caution DYNAMIXEL-X Series cable assembly through hollow case Organize the entangled cable before assembling the back case. Do not assemble the back case with entangled cable. The entangled cable can be squashed by the case and cause communication error. If you use two cables through the hollow case, the cables will be damaged. Use only one cable through the hollow case. The DYNAMIXEL-X Series adopted a new gold-plated JST connector for secure and reliable communication. The connector used for the previous DYNAMIXEL is Molex. To control DYNAMIXEL-X Series actuators via OpenCM or USB2Dynamixel, please use the JST-Molex Convertible Cable enclosed in the package. However, the Molex-JST convertible cable is NOT included in the XL430 model. Please purchase a convertible cable when using a controller and interface that supports the JST connector. Installation Example Specification Model Name XD540-T270-R Series DYNAMIXEL X MCU ARM Cortex-M3 (72 [Mhz], 32 [bit]) Input Voltage Min. [V] 10.0 Recommended [V] 12.0 Max. [V] 14.8 Performance Characteristics Voltage [V] 12.0 Stall Torque [N·m] 9.90 Stall Current [A] 4.9 No Load Speed [rpm] 39.0 No Load Current [A] 0.07 Continuous Operation Voltage [V] - Torque [N·m] - Speed [rpm] - Current [A] - Resolution Resolution [deg/pulse] 0.0879000000 Step [pulse/rev] 4,096 Angle [degree] 360 Position Sensor Contactless absolute encoder (12 [bit], 360 [deg])Maker : ams(www.ams.com), Part No : AS5045 Operating Temperature Min. [°C] -5 Max. [°C] 80 Motor Coreless (Maxon) Baud Rate Min. [bps] 9,600 Max. [bps] 4,500,000 Control Algorithm PID Gear Type Spur Gear Material Metal Case Material Metal(Front, Middle) Engineering Plastic(Back) Dimensions (WⅹHⅹD) [mm] 33.5 x 58.5 x 44 Dimensions (WⅹHⅹD) [inch] 1.32 x 2.30 x 1.73 Weight [g] 170.00 Weight [oz] 5.99 Gear Ratio 272.5 : 1 Backlash [arcmin] - Backlash [deg] - Command Signal Digital Packet Protocol Type Half duplex Asynchronous Serial Communication (8bit, 1stop, No Parity) Link (Physical) RS485 Multidrop Bus ID 0 ~ 252 Feedback Position, Velocity, Current, Realtime tick, Trajectory, Temperature, Voltage, External Port, etc. Protocol version Protocol 1.0Protocol 2.0(Default) Operating Mode / Angle Current Control mode:Endless turnVelocity Control mode:Endless turnPosition Control Mode:360 [deg]Extended Position Control Mode:±256 [rev]Current-based Position Control Mode:±256 [rev]PWM Control Mode:Endless turn Output [W] - Standby Current [mA] 40 Link ○ e-Manual ○ Drawing ○ Software (DYNAMIXEL Wizard 2.0) ○ Compatibility Guide ○ Selection Guide ○ DYNAMIXEL SDK ○ [Video] Quick Start Guide
가격 변동 내역
관측 날짜별로 평균한 일일 데이터 포인트 하나를 표시합니다.
USD 기준 금액
기록된 모든 상품 가격을 협정 세계시 기준 날짜별로 평균합니다.

Robotis
$885.39
Robotis
945.42 €
Robotis
619.14 €
Robotis
642.12 €
Robotis
627.96 €
Robotis
642.06 €
Robotis
627.96 €
Robotis
£595.84
Robotis
£594.57
Robotis
£594.57

Robotis
$655.39

Robotis
$632.39
🍪 쿠키 설정
성능 측정을 위해 쿠키를 사용합니다. 개인정보 처리방침