일일 평균 가격
USD 기준 금액
설명
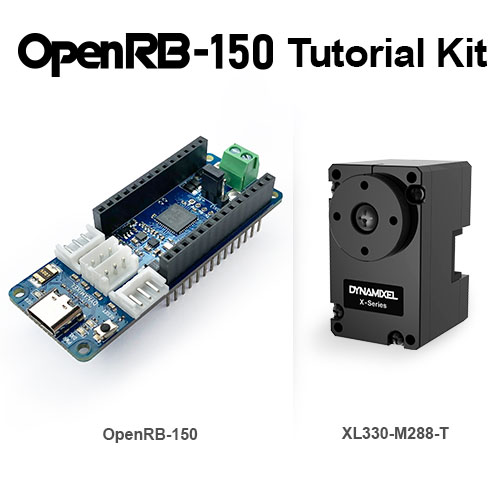
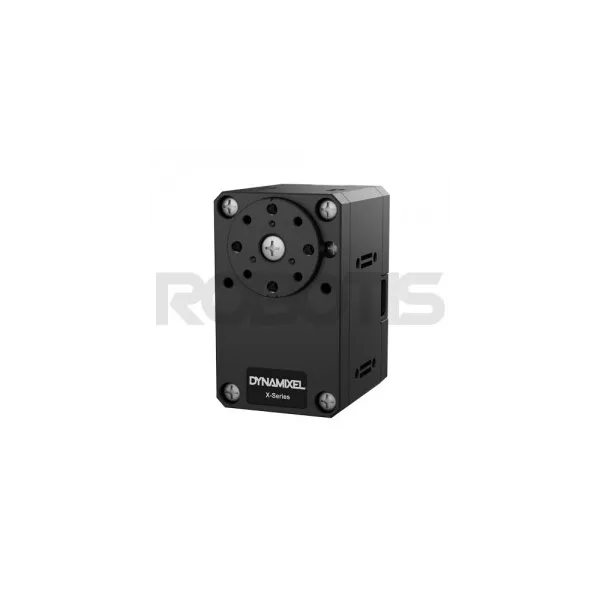
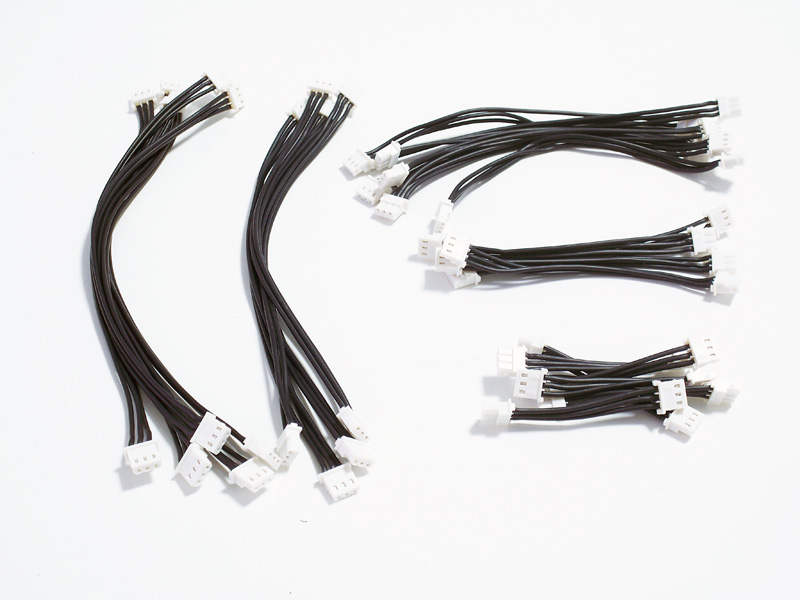
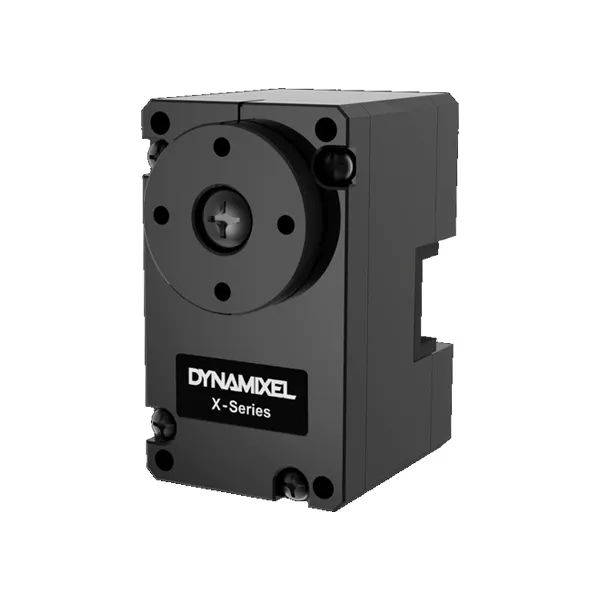
Features * OpenRB-150 Tutorial Kit is a product consisting of OpenRB-150 and XL330-M288-T. * Product Name Change on May 20, 2025 (Previous Name: OpenRB-150 Starter Kit) * Batteries, USB Cables, and Power Cables are not included. OpenRB-150 Has the same pinout and form factor as the Arduino MKR, and supports programming using the Arduino IDE. XL330-M288-T Compact and lightweight DYNAMIXEL. Supports RC protocol & 6 control modes including Current Control and Current Based Position Control. Package Components Product Name Quantity Product Description OpenRB-150 1 DYNAMIXEL Controller XL330-M288-T 1 DYNAMIXEL Robot Cable-X3P 180mm 1 TTL 3P cable (JST-JST) PHS M2x6 TAP 6 Bolts for Horn PHS M2x8 TAP 10 Bolts for Frame Assembly H/W Specifications OpenRB-150 Category Specifications MCUSAMD21 Cortex-M0+ 32bit low power ARM® Operation Voltage5.0V (USB 3.0)3.7V ~ 12.6V (VIN or Terminal) Operation Temperature-40℃ ~ 85℃ Allowable Current3.0A (DYNAMIXEL Port) Connector TypeUSB C-Type, Terminal Block DYNAMIXEL Port (TTL)JST B3B-EH-A(2), JST S3B-EH-A(2) [Max 1Mbps] Dimensions66 × 25 mm Weight13g XL330-M288-T Category Item Specifications MCU Cortex-M0+ (64 [MHz], 32bit) Input Voltage Min. [V] 3.7 Recommended [V] 5.0 Max. [V] 6.0 Performance Characteristics Voltage [V] 5.0 Stall Torque [N·m] 0.52 Stall Current [A] 1.5 No Load Speed [rpm] 104.0 No Load Current [A] 0.15 Continuous Operation Voltage / Torque / Speed / Current – Torque [N·m] – Speed [rpm] – Current [A] – Resolution Resolution [deg/pulse] 0.0879 Step [pulse/rev] 4 Angle [degree] 360 Position Sensor Contactless absolute encoder (12Bit, 360 [deg])Maker: ams (www.ams.com), Part No: AS5601 Operating Temperature Min. [°C] -5 Max. [°C] 60 Motor Cored Baud Rate Min. [bps] 9,600 Max. [bps] 4,000,000 Control Algorithm PID Gear Type Spur Gear Material Engineering Plastic Case Material Engineering Plastic Dimensions (W×H×D) 20 × 34 × 26 mm / 0.78 × 1.33 × 1.02 in Weight 18.00 g / 0.63 oz Gear Ratio 288.4 : 1 Command Signal Digital Packet Communication Half duplex Asynchronous Serial Communication (8bit, 1stop, No Parity) Physical Link TTL Level Multi Drop Bus ID 0 ~ 252 Feedback Position, Velocity, Current, Realtime tick, Trajectory, Temperature, Input Voltage, etc. Protocol Protocol 2.0 Experimental S.BUS, iBUS, RC-PWM Operating Mode / Angle Current Control: Endless turnVelocity Control: Endless turnPosition Control: 360°Extended Position Control: ±256 revCurrent-based Position Control: ±256 revPWM Control: Endless turn Output [W] – Standby Current [mA] 15 How to Supply Power (3 Methods) Power can be supplied to the OpenRB-150 in three ways depending on the voltage and serial communication type of DYNAMIXEL. 1. 5V TTL DYNAMIXEL 2. 12V TTL DYNAMIXEL 3. 12V RS-485 DYNAMIXEL Compatible DYNAMIXEL The OpenRB-150 is compatible with all DYNAMIXEL models. However, additional equipment is required for use with the following types of DYNAMIXEL. 1. RS-485 The DYNAMIXEL Communication Bridge is required to convert signals. 2. 24V A separate power supply is required. 3. DYNAMIXEL-AX and MX Series (Molex connectors) A Molex-JST convertible cable is required. Caution 1. The Arduino MKR board is not included in the package. 2. When supplying power, please check the jumper settings. (USB C Type, VIN, Terminal VIN) 3. Please do not charge the battery when it is connected to the controller. 4. Please check the power input terminal before connecting it to the controller. Link e-Manual Drawing Board Manager(GitHub) DYNAMIXEL2Arduino Library [Video] DYNAMIXEL Quick Start Guide with Arduino [Video] DYNAMIXEL Quick Start Guide with DYNAMIXEL Wizard 2.0 Features OpenRB-150 Tutorial Kit is a product consisting of OpenRB-150 and XL330-M288-T. Product Name Change on May 20, 2025 (Previous Name: OpenRB-150 Starter Kit) Batteries, USB Cables, and Power Cables are not included.
Features * OpenRB-150 Tutorial Kit is a product consisting of OpenRB-150 and XL330-M288-T. * Product Name Change on May 20, 2025 (Previous Name: OpenRB-150 Starter Kit) * Batteries, USB Cables, and Power Cables are not included. OpenRB-150 Has the same pinout and form factor as the Arduino MKR, and supports programming using the Arduino IDE. XL330-M288-T Compact and lightweight DYNAMIXEL. Supports RC protocol & 6 control modes including Current Control and Current Based Position Control. Package Components Product Name Quantity Product Description OpenRB-150 1 DYNAMIXEL Controller XL330-M288-T 1 DYNAMIXEL Robot Cable-X3P 180mm 1 TTL 3P cable (JST-JST) PHS M2x6 TAP 6 Bolts for Horn PHS M2x8 TAP 10 Bolts for Frame Assembly H/W Specifications OpenRB-150 Category Specifications MCUSAMD21 Cortex-M0+ 32bit low power ARM® Operation Voltage5.0V (USB 3.0)3.7V ~ 12.6V (VIN or Terminal) Operation Temperature-40℃ ~ 85℃ Allowable Current3.0A (DYNAMIXEL Port) Connector TypeUSB C-Type, Terminal Block DYNAMIXEL Port (TTL)JST B3B-EH-A(2), JST S3B-EH-A(2) [Max 1Mbps] Dimensions66 × 25 mm Weight13g XL330-M288-T Category Item Specifications MCU Cortex-M0+ (64 [MHz], 32bit) Input Voltage Min. [V] 3.7 Recommended [V] 5.0 Max. [V] 6.0 Performance Characteristics Voltage [V] 5.0 Stall Torque [N·m] 0.52 Stall Current [A] 1.5 No Load Speed [rpm] 104.0 No Load Current [A] 0.15 Continuous Operation Voltage / Torque / Speed / Current – Torque [N·m] – Speed [rpm] – Current [A] – Resolution Resolution [deg/pulse] 0.0879 Step [pulse/rev] 4 Angle [degree] 360 Position Sensor Contactless absolute encoder (12Bit, 360 [deg])Maker: ams (www.ams.com), Part No: AS5601 Operating Temperature Min. [°C] -5 Max. [°C] 60 Motor Cored Baud Rate Min. [bps] 9,600 Max. [bps] 4,000,000 Control Algorithm PID Gear Type Spur Gear Material Engineering Plastic Case Material Engineering Plastic Dimensions (W×H×D) 20 × 34 × 26 mm / 0.78 × 1.33 × 1.02 in Weight 18.00 g / 0.63 oz Gear Ratio 288.4 : 1 Command Signal Digital Packet Communication Half duplex Asynchronous Serial Communication (8bit, 1stop, No Parity) Physical Link TTL Level Multi Drop Bus ID 0 ~ 252 Feedback Position, Velocity, Current, Realtime tick, Trajectory, Temperature, Input Voltage, etc. Protocol Protocol 2.0 Experimental S.BUS, iBUS, RC-PWM Operating Mode / Angle Current Control: Endless turnVelocity Control: Endless turnPosition Control: 360°Extended Position Control: ±256 revCurrent-based Position Control: ±256 revPWM Control: Endless turn Output [W] – Standby Current [mA] 15 How to Supply Power (3 Methods) Power can be supplied to the OpenRB-150 in three ways depending on the voltage and serial communication type of DYNAMIXEL. 1. 5V TTL DYNAMIXEL 2. 12V TTL DYNAMIXEL 3. 12V RS-485 DYNAMIXEL Compatible DYNAMIXEL The OpenRB-150 is compatible with all DYNAMIXEL models. However, additional equipment is required for use with the following types of DYNAMIXEL. 1. RS-485 The DYNAMIXEL Communication Bridge is required to convert signals. 2. 24V A separate power supply is required. 3. DYNAMIXEL-AX and MX Series (Molex connectors) A Molex-JST convertible cable is required. Caution 1. The Arduino MKR board is not included in the package. 2. When supplying power, please check the jumper settings. (USB C Type, VIN, Terminal VIN) 3. Please do not charge the battery when it is connected to the controller. 4. Please check the power input terminal before connecting it to the controller. Link e-Manual Drawing Board Manager(GitHub) DYNAMIXEL2Arduino Library [Video] DYNAMIXEL Quick Start Guide with Arduino [Video] DYNAMIXEL Quick Start Guide with DYNAMIXEL Wizard 2.0
가격 변동 내역
관측 날짜별로 평균한 일일 데이터 포인트 하나를 표시합니다.
USD 기준 금액
기록된 모든 상품 가격을 협정 세계시 기준 날짜별로 평균합니다.
Robotis
36 €
Robotis
£35
Robotis
£32.08
Robotis
£37.75
Robotis
£32.33
Robotis
£36.42

Robotis
$30.94

Robotis
$32.89

Robotis
$32.89
Robotis
40.20 €
Robotis
40.20 €
Robotis
£38.56
🍪 쿠키 설정
성능 측정을 위해 쿠키를 사용합니다. 개인정보 처리방침