दैनिक औसत कीमत
USD में राशियाँ
विवरण
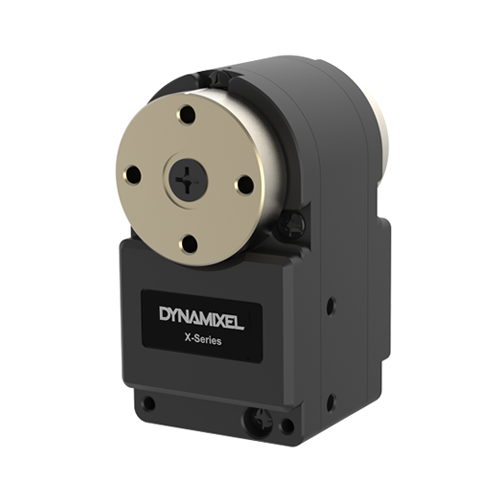
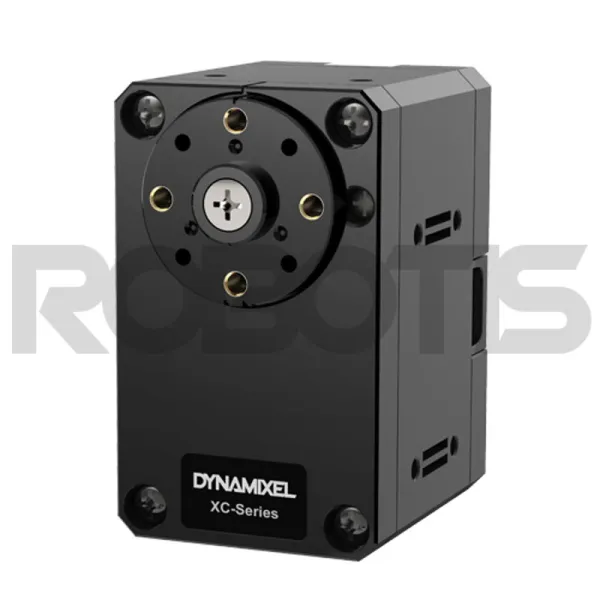
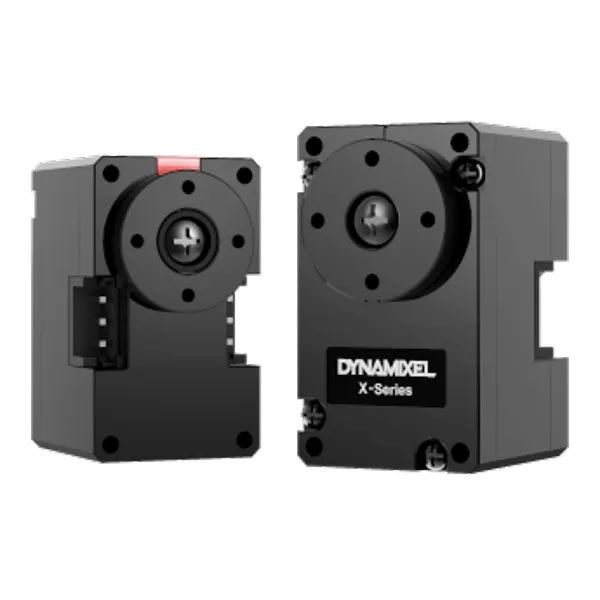
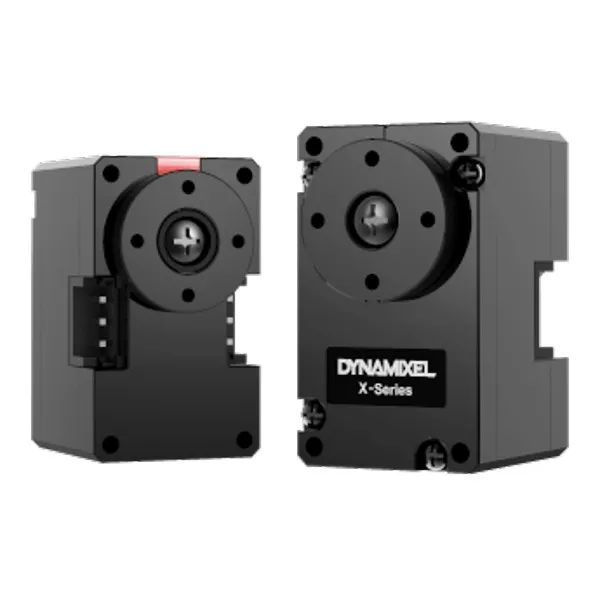
The XM335 model is a dedicated actuator for robotic fingers. It supports a total of six control modes, including Current Control and Current-based Position Control, as well as the RC protocol, enabling efficient use in various applications. *Caution: The recommended voltage is DC 11.1V, so please exercise caution during use. *The XM335 series is a compact and lightweight product, making it easy to use in extremely narrow spaces. *Durability has been reinforced through the application of metal gears and a metal case. 1.Various Operating Modes Velocity Control, Position Control, Extended Position Control, PWM Control, Current Control, Current Based Position Control 2.Profile Control for Smooth Motion Planning 3.Input Voltage : 6.5V ~ 12.0V ( Recommended 11.1V) 4.Enhanced Durability by applying Metal Gear and Bearing 5.Support RC Protocol without additional converting device 6.Energy Saving with Reduced Current Package Components Item Quantity Description XM335-T323-T 1 DYNAMIXEL Robot Cable-X3P(HRS) 80mm 1 TTL 3p cable(HRS - HRS) FHS_M2X06 1 Bolts for horns CHS_M1_7X04 10 Bolts for frames PHS_M2X04 14 Bolts for frames HORN 1 Horn for XM335 The idler set for hinge frame mounting is not included. Drawing Compatible Products Important Notes Due to a change in the connector specifications for the XM335 cables, a 3P JST-HRS Conversion Board is required for connection to existing JST connector-based products, such as the U2D2, OpenCR1.0, and OpenRB-150. The conversion board is scheduled to be available for separate purchase in February. Installation Example Specification Model Name XM335-T323-T Series DYNAMIXEL X MCU ARM CORTEX-M0+ (64 [MHz], 32Bit) Input Voltage Min. [V] 6.5 Recommended [V] 11.1 Max. [V] 12.0 Performance Characteristics Voltage [V] 11.0 Stall Torque [N·m] 1.03 Stall Current [A] 0.8 No Load Speed [rpm] 53.0 No Load Current [A] - Continuous Operation Voltage [V] - Torque [N·m] - Speed [rpm] - Current [A] - Resolution Resolution [deg/pulse] 0.0879000000 Step [pulse/rev] 4,096 Angle [degree] 360 Position Sensor Contactless absolute encoder (12Bit, 360 [deg]) Maker : ams(www.ams.com), Part No : AS5601 Operating Temperature Min. [°C] -5 Max. [°C] 70 Motor Coreless Baud Rate Min. [bps] 9600 Max. [bps] 4000000 Control Algorithm PID Gear Type Spur Gear Material Full Metal Case Material Full Metal Dimensions (WⅹHⅹD) [mm] 19.0 x 35.0 x 22.0 Dimensions (WⅹHⅹD) [inch] 7.48 x 13.78 x 8.66 Weight [g] 27.00 Weight [oz] 0.95 Gear Ratio 323.04 : 1 Backlash [arcmin] - Backlash [deg] - Command Signal Digital Packet Protocol Type Half duplex Asynchronous Serial Communication (8bit, 1stop, No Parity) Link (Physical) TTL Level Multidrop Bus ID 0 ~ 252 Feedback Position, Velocity, Current, Realtime tick, Trajectory, Temperature, Input Voltage, etc Protocol version Protocol 2.0 Experimental S.BUS Experimental iBUS RC-PWM Operating Mode / Angle Current Control mode:Endless turn Velocity Control mode:Endless turn Position Control Mode:360 [deg] Extended Position Control Mode:±256 [rev] Current-based Position Control Mode:±256 [rev] PWM Control Mode:Endless turn Output [W] - Standby Current [mA] 17 Links e-Manual Drawing Software (DYNAMIXEL Wizard 2.0) Selection Guide DYNAMIXEL SDK
The XM335 model is a dedicated actuator for robotic finger s. It supports a total of six control modes, including Current Control and Current-based Position Control, as well as the RC protocol, enabling efficient use in various applications. *Caution: The recommended voltage is DC 11.1V, so please exercise caution during use. *The XM335 series is a compact and lightweight product, making it easy to use in extremely narrow spaces. *Durability has been reinforced through the application of metal gears and a metal case. 1.Various Operating Modes Velocity Control, Position Control, Extended Position Control, PWM Control, Current Control, Current Based Position Control 2.Profile Control for Smooth Motion Planning 3.Input Voltage : 6.5V ~ 12.0V ( Recommended 11.1V) 4.Enhanced Durability by applying Metal Gear and Bearing 5.Support RC Protocol without additional converting device 6.Energy Saving with Reduced Current Package Components Item Quantity Description XM335-T323-T 1 DYNAMIXEL Robot Cable-X3P(HRS) 80mm 1 TTL 3p cable(HRS - HRS) FHS_M2X06 1 Bolts for horns CHS_M1_7X04 10 Bolts for frames PHS_M2X04 14 Bolts for frames HORN 1 Horn for XM335 The idler set for hinge frame mounting is not included. Drawing Compatible Products Important Notes Due to a change in the connector specifications for the XM335 cables, a 3P JST-HRS Conversion Board is required for connection to existing JST connector-based products, such as the U2D2, OpenCR1.0, and OpenRB-150. The conversion board is scheduled to be available for separate purchase in February. Installation Example Specification Model Name XM335-T323-T Series DYNAMIXEL X MCU ARM CORTEX-M0+ (64 [MHz], 32Bit) Input Voltage Min. [V] 6.5 Recommended [V] 11.1 Max. [V] 12.0 Performance Characteristics Voltage [V] 11.0 Stall Torque [N·m] 1.03 Stall Current [A] 0.8 No Load Speed [rpm] 53.0 No Load Current [A] - Continuous Operation Voltage [V] - Torque [N·m] - Speed [rpm] - Current [A] - Resolution Resolution [deg/pulse] 0.0879000000 Step [pulse/rev] 4,096 Angle [degree] 360 Position Sensor Contactless absolute encoder (12Bit, 360 [deg]) Maker : ams(www.ams.com), Part No : AS5601 Operating Temperature Min. [°C] -5 Max. [°C] 70 Motor Coreless Baud Rate Min. [bps] 9600 Max. [bps] 4000000 Control Algorithm PID Gear Type Spur Gear Material Full Metal Case Material Full Metal Dimensions (WⅹHⅹD) [mm] 19.0 x 35.0 x 22.0 Dimensions (WⅹHⅹD) [inch] 7.48 x 13.78 x 8.66 Weight [g] 27.00 Weight [oz] 0.95 Gear Ratio 323.04 : 1 Backlash [arcmin] - Backlash [deg] - Command Signal Digital Packet Protocol Type Half duplex Asynchronous Serial Communication (8bit, 1stop, No Parity) Link (Physical) TTL Level Multidrop Bus ID 0 ~ 252 Feedback Position, Velocity, Current, Realtime tick, Trajectory, Temperature, Input Voltage, etc Protocol version Protocol 2.0 Experimental S.BUS Experimental iBUS RC-PWM Operating Mode / Angle Current Control mode:Endless turn Velocity Control mode:Endless turn Position Control Mode:360 [deg] Extended Position Control Mode:±256 [rev] Current-based Position Control Mode:±256 [rev] PWM Control Mode:Endless turn Output [W] - Standby Current [mA] 17 Links e-Manual Drawing Software (DYNAMIXEL Wizard 2.0) Selection Guide DYNAMIXEL SDK
कीमत का इतिहास
हर दिन के लिए एक डेटा बिंदु, अवलोकन की तारीख के अनुसार औसत।
USD में राशियाँ
हर दर्ज ऑफ़र की कीमत से UTC के प्रत्येक दिन का औसत निकाला जाता है।
Robotis
174 €
Robotis
123.58 €
Robotis
131.94 €
Robotis
131.94 €
Robotis
110.40 €
Robotis
110.40 €
Robotis
110.40 €
Robotis
110.40 €

Robotis
$126.39

Robotis
$115

Robotis
$115

Robotis
$115
🍪 कुकी प्राथमिकताएँ
प्रदर्शन मापने के लिए हम कुकीज़ का उपयोग करते हैं। गोपनीयता नीति