Prix moyen quotidien
Montants en USD
Description
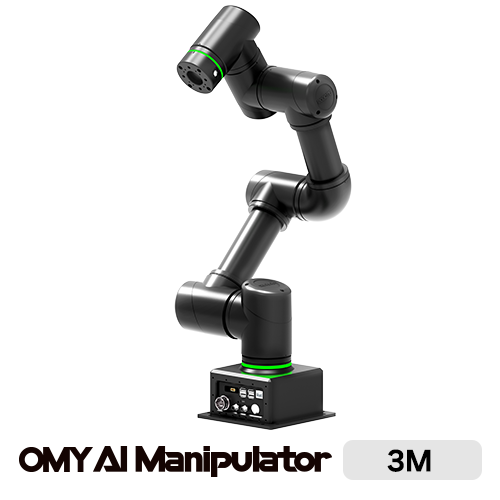
Features Custom Manipulator Easy integration of 3rd-party components (such as hands, sensors, vision systems) depending on the working environment. Providing customizable development environment (C, C#, Python, etc.) via the DYNAMIXEL SDK. Plug-and-Play Realizing a perfect benchtop manipulator through a minimal footprint and lightweight design. Providing a robot control environment via an integrated controller (SBC) without the need for a separate PC. OpenSource Platform Delivering perfect compatibility with ROS2 and open-source support. Offering various packages and simulators (e.g., Movelt 2, Gazebo). Supporting development convenience through a dedicated OMY Control GUI. Specification Items OMY-3M DOF 6 Reach 580 [mm] Weight 13.5 [kg] Operating Voltage 24 [VDC] Joint Resolution -π(rad) ~ π(rad), -262,144 ~ 262,144 [pulse/rev] Joint Range Joint 1,2: ±360° Joint 3: ±150° Joint 4,5,6: ±360° DYNAMIXEL-Y Specification Joint 1,2: YM080-230-A099-RH Joint 3,4,5,6: YM070-210-A099-RH Repeatability ±0.05 [mm] Brake Force 200% of the continuous torque for each joint TCP Speed
Features Custom Manipulator Easy integration of 3rd-party components (such as hands, sensors, vision systems) depending on the working environment. Providing customizable development environment (C, C#, Python, etc.) via the DYNAMIXEL SDK. Plug-and-Play Realizing a perfect benchtop manipulator through a minimal footprint and lightweight design. Providing a robot control environment via an integrated controller (SBC) without the need for a separate PC. OpenSource Platform Delivering perfect compatibility with ROS2 and open-source support. Offering various packages and simulators (e.g., Movelt 2, Gazebo). Supporting development convenience through a dedicated OMY Control GUI. Specification Items OMY-3M DOF 6 Reach 580 [mm] Weight 13.5 [kg] Operating Voltage 24 [VDC] Joint Resolution -π(rad) ~ π(rad), -262,144 ~ 262,144 [pulse/rev] Joint Range Joint 1,2: ±360° Joint 3: ±150° Joint 4,5,6: ±360° DYNAMIXEL-Y Specification Joint 1,2: YM080-230-A099-RH Joint 3,4,5,6: YM070-210-A099-RH Repeatability ±0.05 [mm] Brake Force 200% of the continuous torque for each joint TCP Speed
Historique des prix
Un point de données par jour, calculé selon la date d’observation.
Montants en USD
Les moyennes sont calculées par jour UTC à partir de tous les prix d’offre enregistrés.
Robotis
13 923,95 €

Robotis
$11 498,85
Robotis
£9 313,13

Robotis
$4 834,51
Robotis
£11 145,87

Robotis
$14 373,85
Robotis
894,92 €
Robotis
17 272,96 €
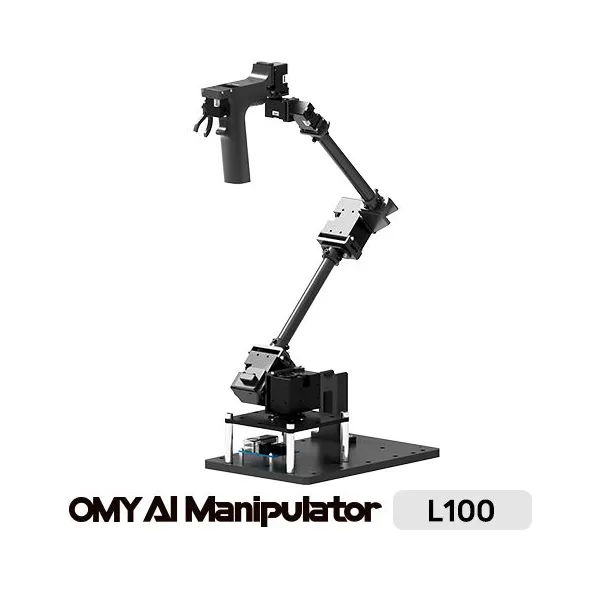
Robotis
3 291,60 €
Robotis
444 €
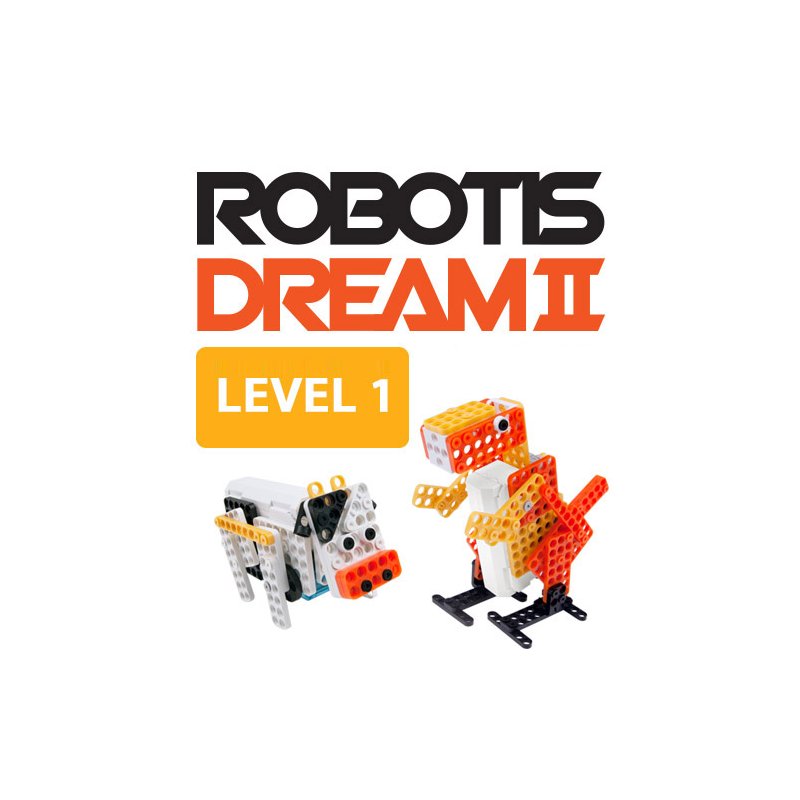
Robotis
157,95 €
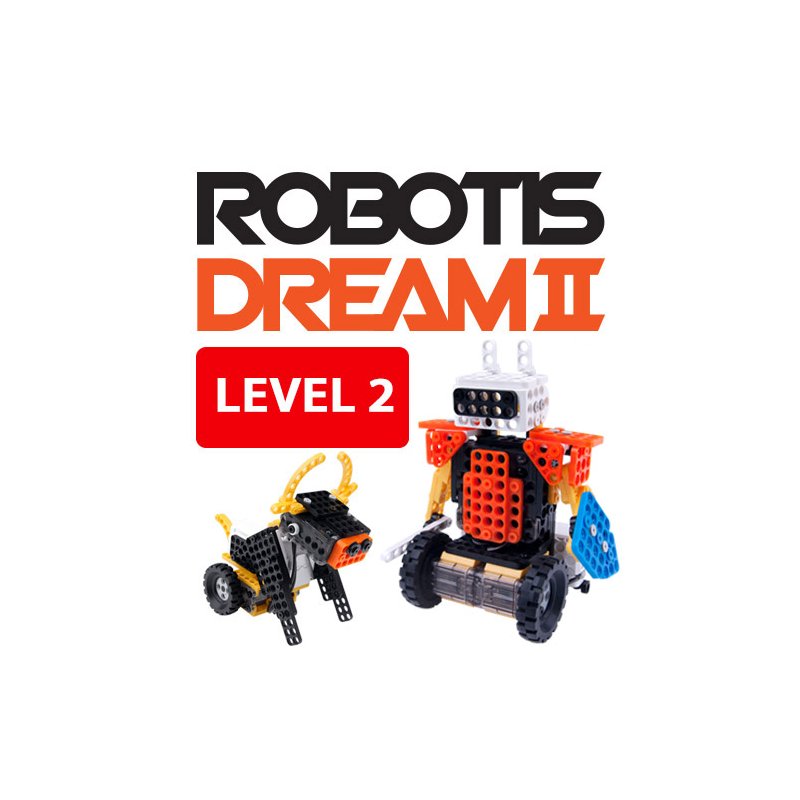
Robotis
157,95 €
🍪 Préférences relatives aux cookies
Nous utilisons des cookies pour mesurer les performances. Politique de confidentialité