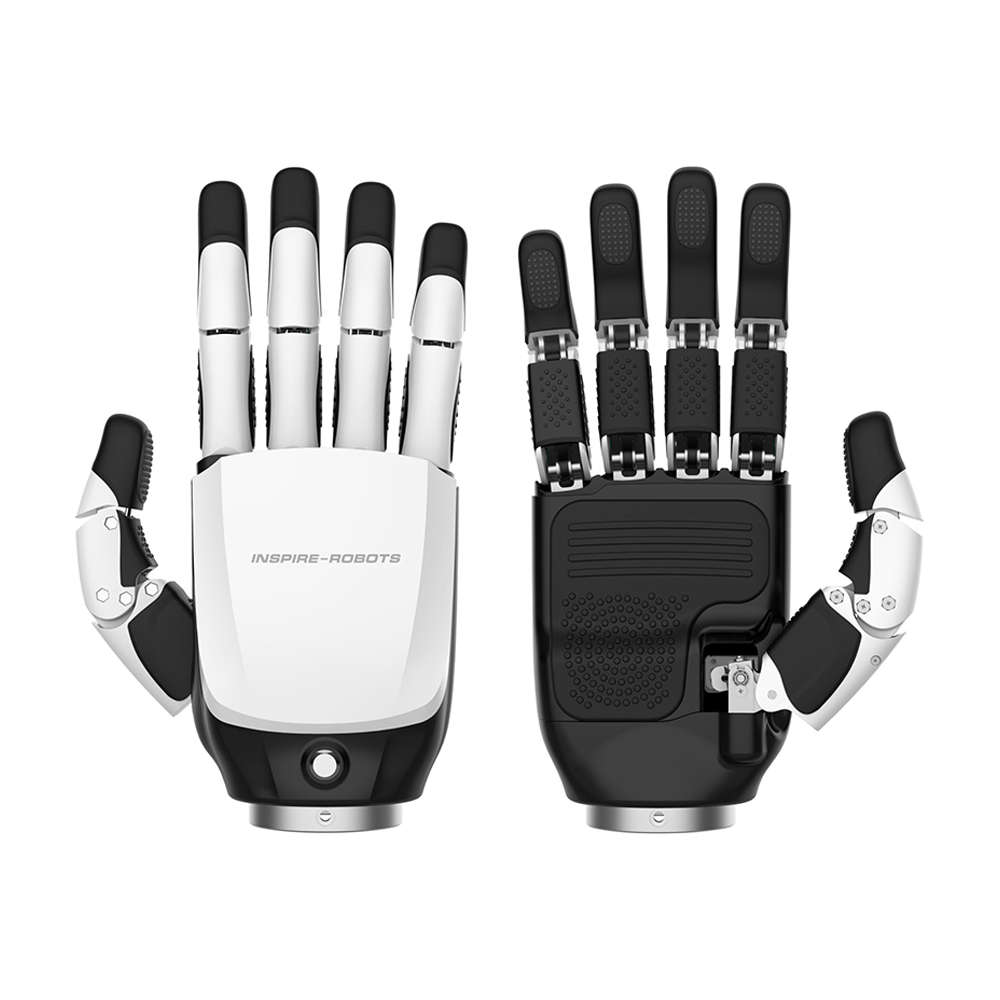
Inspire Robots 5-Finger Robotic Dexterous Hand - RH56E2 (RH56DFTP for Unitree G1, H2 Humanoid Robot)
Go to slide 1 Go to slide 2 Go to slide 3 Go to slide 4 Go to slide 5 Go to slide 6 Go to slide 7
Inspire Robots 5-Finger Robotic Dexterous Hand - RH56E2 (RH56DFTP for Unitree G1, H2 Humanoid Robot)

Inspire Robots 5-Finger Robotic Dexterous Hand - RH56E2 (RH56DFTP for Unitree G1, H2 Humanoid Robot)

Sale price$8,900.00

Communication:RS485 + ModbusTCP
Hand:Left Hand

The Inspire Robots RH56E2 (RH56DFTP) is a 5-finger dexterous robotic hand designed for humanoid robots such as the Unitree H2. It features 6 DOF, 12 joints, and integrated tactile sensors (up to 17) that provide real-time contact feedback for precise grasping and stable manipulation. With strong fingertip force and support for RS485, CAN, and Modbus TCP communication, the RH56E2 is ideal for humanoid robotics research, AI development, and advanced robotic manipulation tasks.

Description

RH56E2 — Key Specifications

Control & Electrical

  • Control interface: RS485 / CAN / Modbus TCP

  • Operating voltage: 24 V ±10%

  • Quiescent current: 0.25 A

  • Peak current: 4 A

Mechanical

  • Finger configuration: 5-finger anthropomorphic hand

  • Degrees of freedom (DOF): 6

  • Number of joints: 12

Physical

  • Weight: 790 ± 10 g

  • Available versions: Left or right hand

Accuracy & Force

  • Repeatability: ±0.20 mm

  • Thumb fingertip strength: 30 N

  • Finger fingertip strength: 28 N

  • Force resolution: ±0.05 N

Motion Performance

  • Thumb lateral rotation range: 75° – 170°

  • Thumb lateral rotation speed: >130°/s

  • Thumb flexion speed: >130°/s

  • Four-finger flexion speed: >200°/s

Sensors

  • Force sensors: 6

  • Tactile sensors: 5/ 17 depending on configuration

  • Tactile sensing range: 0–30 N

  • Tactile sensor accuracy: ≤5% FS

Other

  • Maximum fingertip pressure: 8 kg

  • Hand closing time: ~0.8 s

Key Features

  • Integrated multi-point tactile sensing (up to 17 sensors) for grasp feedback

  • High-precision force control and manipulation

  • Designed for humanoid robots, AI research, manipulation experiments, and robotic arms

Historique des prix

Historique des prix moyens

Un point de données par jour, calculé selon la date d’observation.

Prix moyen quotidien

Montants en USD

$8 900
Graphique de l’historique des prix moyens en USDGraphique linéaire de 7 observations du 2 oct. 2026 au 7 oct. 2026.$8 900,03$8 900,02$8 900,01$8 900$8 899,992 oct.3 oct.4 oct.5 oct.7 oct.2 oct. 2026 : moyenne de $8 9003 oct. 2026 : moyenne de $8 9004 oct. 2026 : moyenne de $8 9005 oct. 2026 : moyenne de $8 9006 oct. 2026 : moyenne de $8 9007 oct. 2026 : moyenne de $8 900

Les moyennes sont calculées par jour UTC à partir de tous les prix d’offre enregistrés.