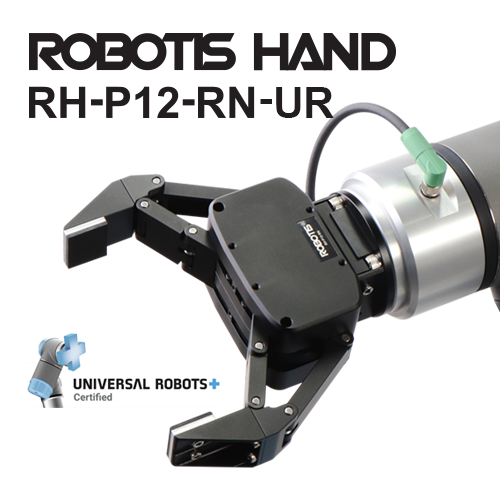
- 6 DoF with 11 joints 6 active and 5 passive joints across a five-finger architecture deliver a wide range of grasp postures while keeping mechanical complexity and mass low.
- 130 N five-finger grip force High total grip force combined with individual finger force metrics (28 N thumb tip, 33 N four-finger tips) supports reliable handling of varied object geometries.
- ±0.2 mm repeat positioning accuracy Worm-gear transmission provides positional stiffness and repeatable joint control suitable for assembly and precision placement tasks.
- Ultra-lightweight at ~370 g Minimal weight reduces payload burden on the host arm and improves dynamic response, enabling deployment on compact cobots and smaller platforms.
- Optional tactile force sensing Fingertip tactile sensors enable force-aware grasping—adjusting grip to prevent crushing fragile objects or detecting slip during manipulation.
- CAN / RS485 industrial interface Standard industrial communication at DC 24 V allows integration into a wide range of automation cells, cobots, and embedded control architectures.

میانگین روزانهٔ قیمت
مبالغ به USD