LIMO Open-Source Mobile Robot (ROS compatible)

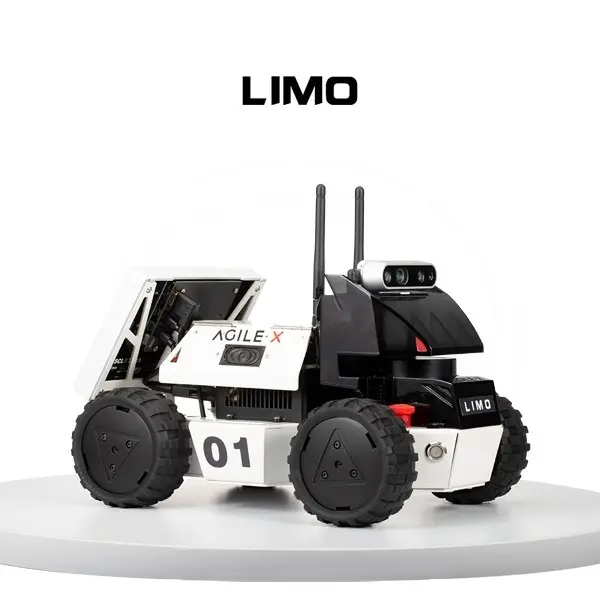
AgileX Robotics LIMO Pro Mobile Robot

LIMO Open-Source Mobile Robot (ROS compatible)
AgileX | A-000000-04918
€3,368.35 VAT incl. €2,806.96 VAT excl.

The AgileX Robotics LIMO Pro is a compact mobile robotics platform designed for research, education, and the development of applications in autonomous navigation, SLAM, computer vision, and embedded AI.
Version
-- Please select an item --
  • Pro
Quantity
1 Available

Get it in 24/48h! (see T&C)

Create a cart and turn it into a quote instantly!
Payment methods (see T&C)
Debit card
PayPal
Payment by invoice
Wire transfer

IMO Pro: a compact ROS 2 platform for mobile robotics

  • ROS 2 Humble compatible: AgileX development packages available for Ubuntu 22.04 and ROS 2 Humble.
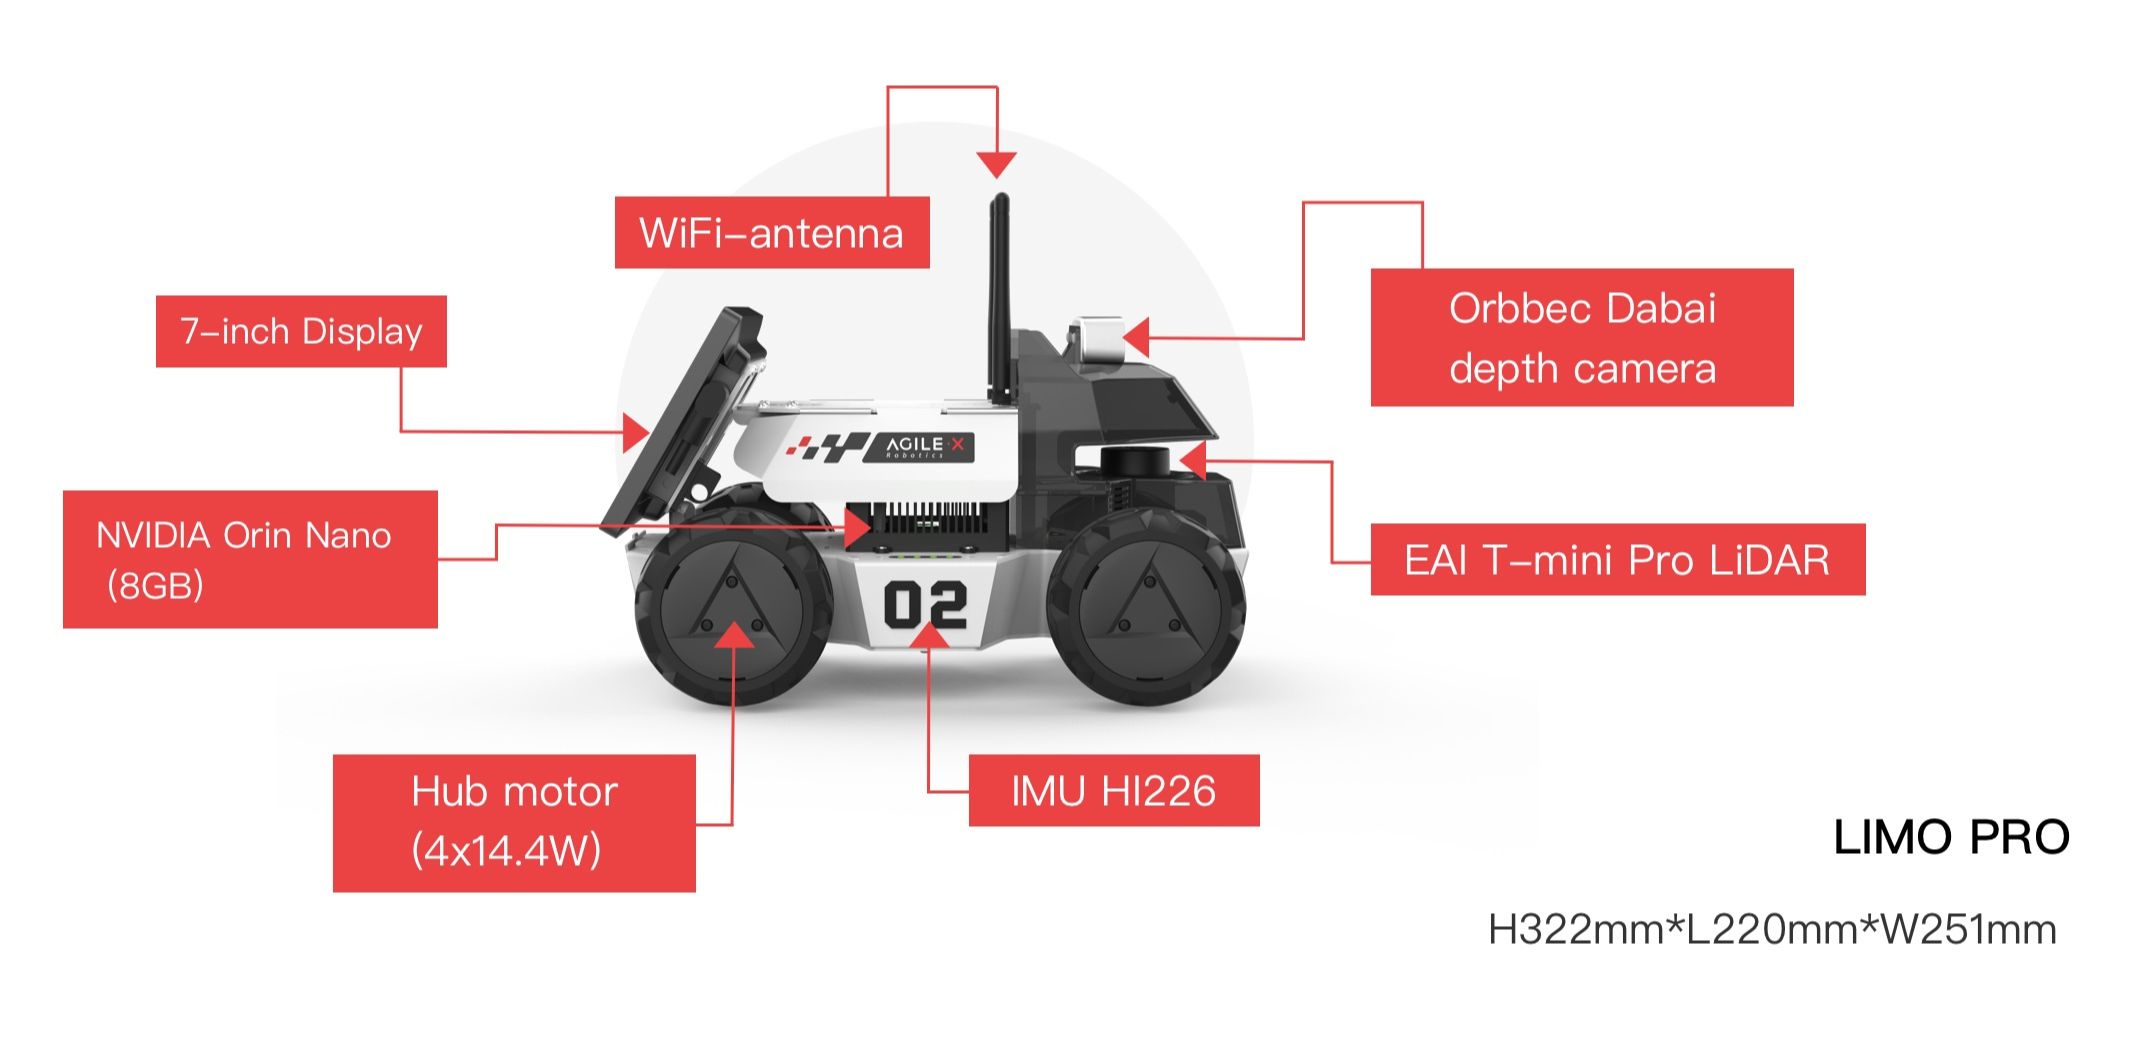
  • NVIDIA Jetson Orin Nano: onboard computing for sensor fusion, SLAM, vision, and AI models.
  • EAI T-mini Pro LiDAR: laser sensing for mapping, localization, and obstacle detection.
  • Orbbec DaBai depth camera: RGB-D perception for navigation and computer vision applications.
  • 4 locomotion modes: 4-wheel differential drive, Ackermann steering, tracked drive, and Mecanum wheels.
  • Payload up to 4 kg: for integrating additional sensors, accessories, or modules.
  • Speed up to 1 m/s: suitable for autonomous navigation experiments in laboratories and experimental environments.
  • Open interfaces: development with ROS, Python, C++, and Gazebo.

Thanks to its compact format, the LIMO Pro provides a complete robotics platform without requiring the space or resources needed for a larger UGV. It is particularly suited to universities, laboratories, engineering schools, and R&D teams looking to develop and test algorithms directly on a physical robot.

4 locomotion modes to test different mobile robot models

One of the main advantages of the AgileX LIMO Pro is its ability to operate with four different locomotion architectures. The same platform can therefore be used to experiment with several kinematic models and control strategies.

  • 4-wheel differential drive: a simple configuration for navigation and SLAM.
  • Ackermann steering: vehicle-like behaviour, relevant for autonomous driving research.
  • Tracked mode: for experimenting with mobility on more irregular surfaces.
  • Mecanum wheels: omnidirectional movement for working on more complex trajectories and manoeuvres.

This multimodal architecture makes it possible to use a single robot for different practical exercises or research projects involving kinematics, control, autonomous navigation, or path planning.

ROS 2 Humble compatible for SLAM, navigation, and simulation

The LIMO Pro is compatible with ROS 2 Humble through the ROS 2 packages maintained by AgileX Robotics. The ROS 2 Humble development environment provides access to chassis control, IMU data, odometry, and the robot’s various sensors.

This compatibility enables the development of projects involving:

  • SLAM and mapping: map generation using LiDAR and odometry data.
  • Autonomous localization: estimation of the robot’s position within an existing map.
  • Autonomous navigation: path planning and movement towards target positions.
  • Obstacle avoidance: use of LiDAR and depth camera data.
  • Gazebo simulation: development and validation of algorithms before deployment on the physical robot.
  • Teleoperation: robot control via ROS 2, keyboard, or control interfaces.

Jetson Orin Nano, LiDAR, and RGB-D camera for onboard perception

The LIMO Pro integrates an NVIDIA Jetson Orin Nano combined with an EAI T-mini Pro LiDAR and an Orbbec DaBai depth camera. This combination provides a ready-to-use hardware platform for projects combining navigation and perception.

  • 3D SLAM
  • Vision-based line following
  • Object recognition with YOLO
  • Target detection and tracking
  • Autonomous navigation
  • Dynamic obstacle avoidance

The Jetson Orin Nano can also run vision processing and deep learning models locally, without systematically relying on an external computer.

A mobile robot for research, education, and prototyping

The LIMO Pro can be used as a platform for a wide range of mobile robotics projects:

  • ROS 2 education: topics, nodes, TF, odometry, sensors, and mobile base control.
  • Autonomous navigation research: SLAM, localization, planning, and obstacle avoidance.
  • Robot vision: object recognition, target tracking, and RGB-D perception.
  • Embedded artificial intelligence: running models on NVIDIA Jetson Orin Nano.
  • Multimodal robotics: comparison of several locomotion architectures on a single platform.
  • Prototyping: rapid validation of algorithms before integration on a larger robot.

Its compact footprint also makes the LIMO Pro particularly suitable for teaching laboratories, test benches, and research environments where several robots need to be deployed simultaneously.

LIMO Pro package contents

  • 1 LIMO Pro mobile robot
  • 1 battery
  • 1 charger
  • 4 Mecanum wheels
  • 2 tracks
  • Mounting accessories and hardware

Technical specifications of the AgileX Robotics LIMO Pro

Dimensions322 × 220 × 251 mm
Weight4.8 kg
Payload4 kg
Runtime2.5 h
Standby time4 h
Wheelbase200 mm
Track width175 mm
Minimum ground clearance24 mm
Drive system4 wheel motors × 14.4 W
Maximum speed1 m/s
Minimum turning radius in Ackermann mode0.4 m
Locomotion modes4-wheel differential drive, Ackermann, tracks, Mecanum
Operating temperature-10 °C to +40 °C
Onboard computerNVIDIA Jetson Orin Nano
CPU6-core Arm Cortex-A78AE
GPU1024 CUDA cores
LiDAREAI T-mini Pro
Depth cameraOrbbec DaBai
IMUHI226
Battery10 Ah / 12 V
ConnectivityWi-Fi, Bluetooth
InterfacesUSB Type-C, USB 2.0, HDMI
Rear display7-inch IPS touchscreen, 1024 × 600
Front display1.54-inch OLED, 128 × 64
ROSROS 2 Humble compatible
ROS 2 environmentUbuntu 22.04 + ROS 2 Humble via AgileX limo_ros2 packages
Programming languagesPython, C++
SimulationGazebo

Resources for the LIMO Pro open-source mobile robot

تاریخچهٔ قیمت

تاریخچهٔ میانگین قیمت

برای هر روز یک نقطهٔ داده؛ میانگین‌گیری بر اساس تاریخ مشاهده انجام شده است.

میانگین روزانهٔ قیمت

مبالغ به USD

$۳٬۶۹۷٫۴۲
نمودار تاریخچهٔ میانگین قیمت (به USD)نمودار خطیِ 61 مشاهده از ۱۰ مهر ۱۴۰۵ تا ۱ آذر ۱۴۰۵.$۳٬۷۵۰$۳٬۵۰۰$۳٬۲۵۰$۳٬۰۰۰$۲٬۷۵۰۱۰ مهر۲۲ مهر۵ آبان۱۸ آبان۱ آذر۱۰ مهر ۱۴۰۵: میانگین $۲٬۹۵۷٫۹۴۱۱ مهر ۱۴۰۵: میانگین $۲٬۹۵۷٫۹۴۱۲ مهر ۱۴۰۵: میانگین $۲٬۹۵۷٫۹۴۱۳ مهر ۱۴۰۵: میانگین $۲٬۹۵۷٫۹۴۱۴ مهر ۱۴۰۵: میانگین $۲٬۹۵۷٫۹۴۱۵ مهر ۱۴۰۵: میانگین $۲٬۹۵۷٫۹۴۱۶ مهر ۱۴۰۵: میانگین $۲٬۹۵۷٫۹۴۱۷ مهر ۱۴۰۵: میانگین $۲٬۹۵۷٫۹۴۱۸ مهر ۱۴۰۵: میانگین $۲٬۹۵۷٫۹۴۱۹ مهر ۱۴۰۵: میانگین $۲٬۹۵۷٫۹۴۲۰ مهر ۱۴۰۵: میانگین $۲٬۹۵۷٫۹۴۲۱ مهر ۱۴۰۵: میانگین $۲٬۹۵۷٫۹۴۲۲ مهر ۱۴۰۵: میانگین $۲٬۹۵۷٫۹۴۲۳ مهر ۱۴۰۵: میانگین $۲٬۹۵۷٫۹۴۲۴ مهر ۱۴۰۵: میانگین $۲٬۹۵۷٫۹۴۲۵ مهر ۱۴۰۵: میانگین $۲٬۹۵۷٫۹۴۲۶ مهر ۱۴۰۵: میانگین $۲٬۹۵۷٫۹۴۲۷ مهر ۱۴۰۵: میانگین $۲٬۹۵۷٫۹۴۲۸ مهر ۱۴۰۵: میانگین $۲٬۹۵۷٫۹۴۲۹ مهر ۱۴۰۵: میانگین $۲٬۹۵۷٫۹۴۳۰ مهر ۱۴۰۵: میانگین $۲٬۹۵۷٫۹۴۱ آبان ۱۴۰۵: میانگین $۲٬۹۵۷٫۹۴۲ آبان ۱۴۰۵: میانگین $۲٬۹۵۷٫۹۴۳ آبان ۱۴۰۵: میانگین $۲٬۹۵۷٫۹۴۴ آبان ۱۴۰۵: میانگین $۲٬۹۵۷٫۹۴۵ آبان ۱۴۰۵: میانگین $۲٬۹۵۷٫۹۴۶ آبان ۱۴۰۵: میانگین $۲٬۹۵۷٫۹۴۷ آبان ۱۴۰۵: میانگین $۲٬۹۵۷٫۹۴۸ آبان ۱۴۰۵: میانگین $۳٬۳۲۷٫۶۸۹ آبان ۱۴۰۵: میانگین $۳٬۶۹۷٫۴۲۱۰ آبان ۱۴۰۵: میانگین $۳٬۶۹۷٫۴۲۱۱ آبان ۱۴۰۵: میانگین $۳٬۶۹۷٫۴۲۱۲ آبان ۱۴۰۵: میانگین $۳٬۶۹۷٫۴۲۱۳ آبان ۱۴۰۵: میانگین $۳٬۶۹۷٫۴۲۱۴ آبان ۱۴۰۵: میانگین $۳٬۶۹۷٫۴۲۱۵ آبان ۱۴۰۵: میانگین $۳٬۶۹۷٫۴۲۱۶ آبان ۱۴۰۵: میانگین $۳٬۶۹۷٫۴۲۱۷ آبان ۱۴۰۵: میانگین $۳٬۶۹۷٫۴۲۱۸ آبان ۱۴۰۵: میانگین $۳٬۶۹۷٫۴۲۱۹ آبان ۱۴۰۵: میانگین $۳٬۶۹۷٫۴۲۲۰ آبان ۱۴۰۵: میانگین $۳٬۶۹۷٫۴۲۲۱ آبان ۱۴۰۵: میانگین $۳٬۶۹۷٫۴۲۲۲ آبان ۱۴۰۵: میانگین $۳٬۶۹۷٫۴۲۲۳ آبان ۱۴۰۵: میانگین $۳٬۶۹۷٫۴۲۲۴ آبان ۱۴۰۵: میانگین $۳٬۶۹۷٫۴۲۲۵ آبان ۱۴۰۵: میانگین $۳٬۶۹۷٫۴۲۲۶ آبان ۱۴۰۵: میانگین $۳٬۶۹۷٫۴۲۲۷ آبان ۱۴۰۵: میانگین $۳٬۶۹۷٫۴۲۲۸ آبان ۱۴۰۵: میانگین $۳٬۶۹۷٫۴۲۲۹ آبان ۱۴۰۵: میانگین $۳٬۶۹۷٫۴۲۳۰ آبان ۱۴۰۵: میانگین $۳٬۶۹۷٫۴۲۱ آذر ۱۴۰۵: میانگین $۳٬۶۹۷٫۴۲

میانگین‌ها بر اساس همهٔ قیمت‌های پیشنهادی ثبت‌شده در هر روزِ UTC محاسبه می‌شوند.