Papers — teadustööd
Viimaste robootikauuringute lihtsas keeles kokkuvõtted — humanoidrobotid, neljajalgsed robotid, tööstusautomaatika ja tehisintellekt.
Humanoid13 p eest
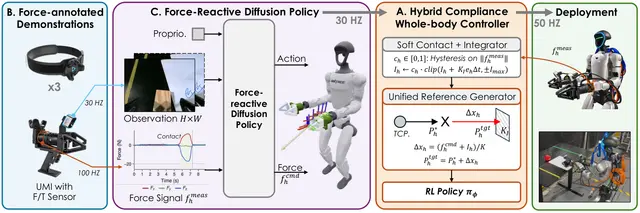
Force-Reactive Learning for Humanoid Loco-Manipulation in Contact-Rich Tasks
Robotics14 p eest
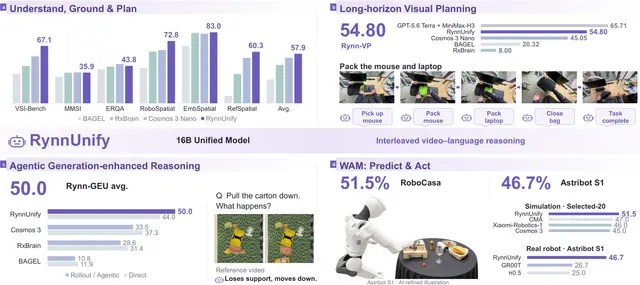
RynnUnify Unifies Robot Reasoning and Video Generation for Embodied Tasks
AI14 p eest
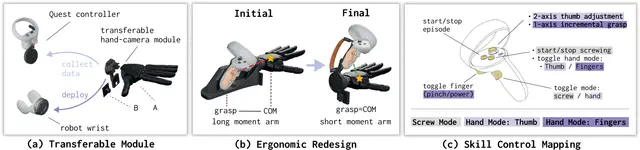
DexPort Makes Dexterous Hand Demonstrations Easier to Collect and Deploy
AI14 p eest
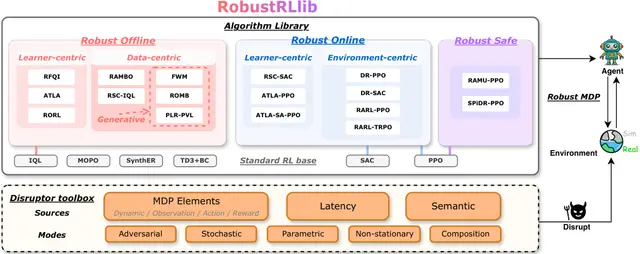
A Shared Testbed Reveals Where Robust Robot Learning Holds Up Best
Robotics15 p eest
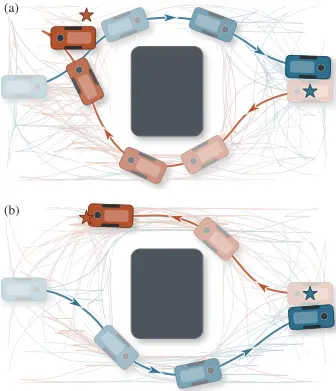
How Robot Teams Coordinate Motion with Dispersive Tree Search
Robotics15 p eest
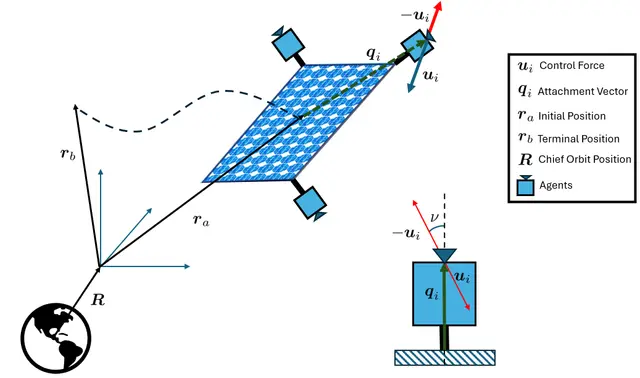
How Robot Swarms Can Move a Rigid Payload Through Orbit Together
Robotics15 p eest
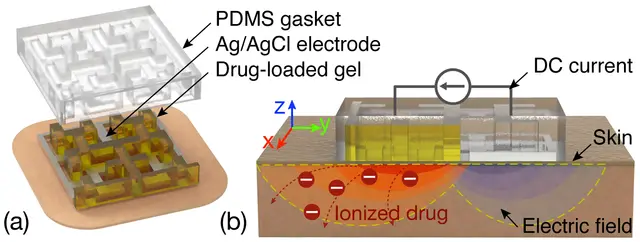
How Hydrogel Shape Can Tune Drug Delivery in Soft Robotic Devices
Robotics16 p eest
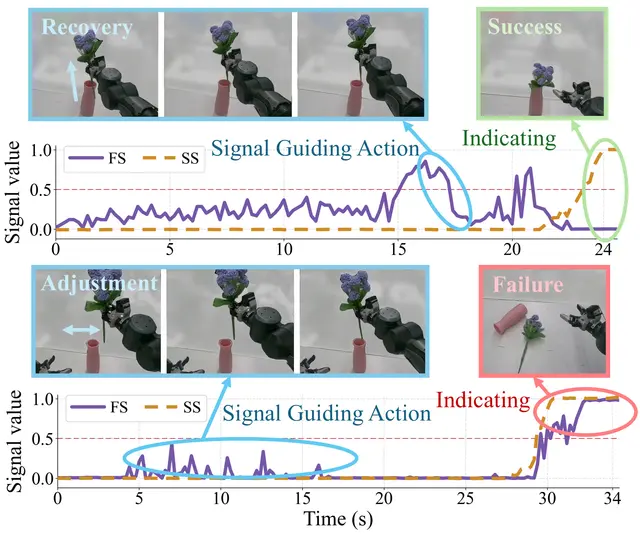
Echo Couples Robot Actions and Task Status Signals in Vision-Language Models
Humanoid16 p eest
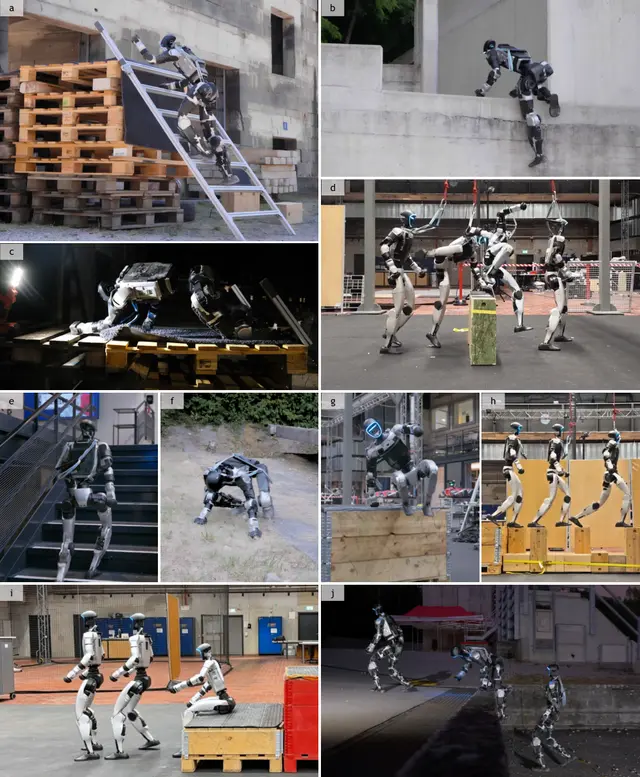
Humanoid Robots Use Attention and Contact Plans to Cross Difficult Terrain
Robotics16 p eest
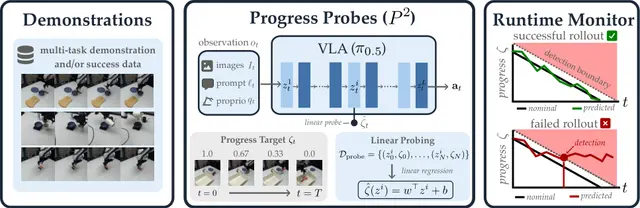
Progress Probes Monitor Vision-Language-Action Models at Runtime
Robotics17 p eest
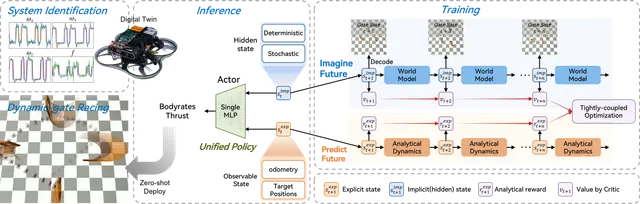
Quadrotor Control Pairs World Models with Differentiable Physics for Agile Flight
Robotics17 p eest
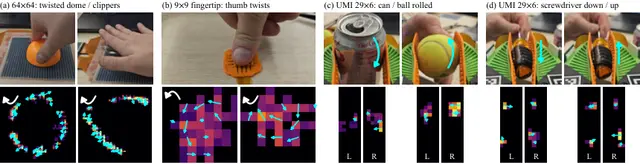
OpenTac Makes Custom Robot Touch Sensors Easier to Build and Simulate
AI17 p eest
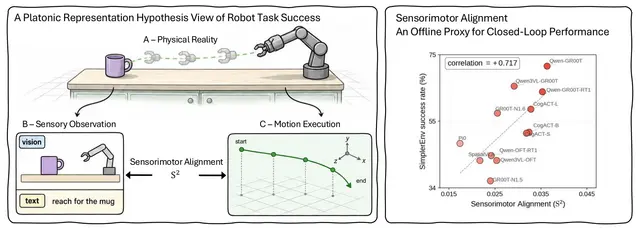
Sensorimotor Alignment Offers a Useful Clue to Embodied Robot Policy Success
AI18 p eest
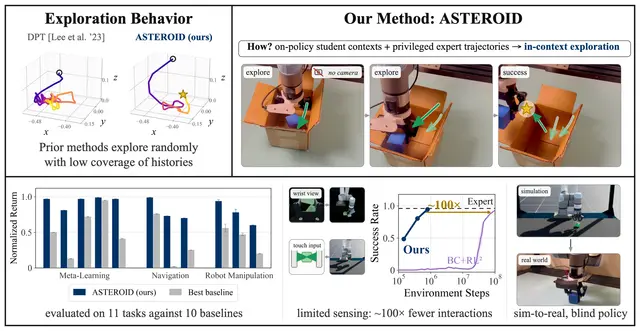
How Robots Learn In-Context Exploration Through On-Policy Distillation
AI18 p eest
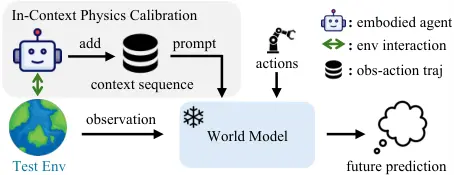
Calibrating Robot World Models with In-Context Physics from Test-Scene Interaction
Robotics18 p eest
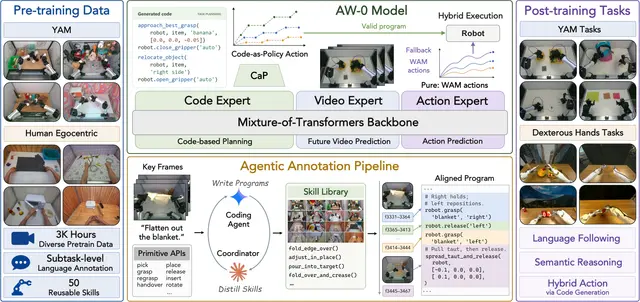
Agentic World Action Models: Code-Guided Skills for Robot Control
AI19 p eest
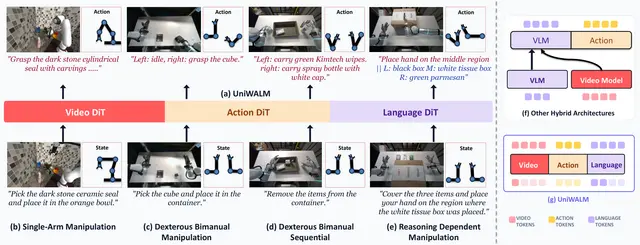
One Model Connects Robot Video, Language, Memory, and Actions for Control
AI19 p eest
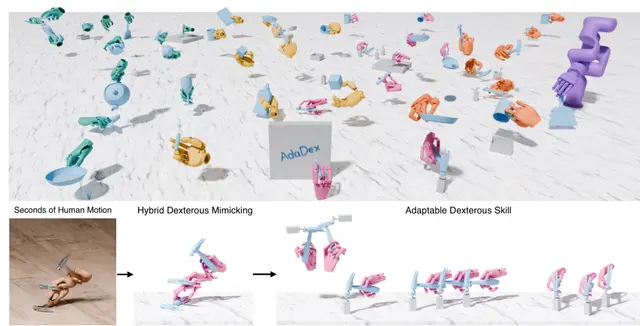
Teaching Robot Hands to Copy and Adapt Everyday Human Object Skills
AI19 p eest