Durchschnittspreis pro Tag
Beträge in USD
Beschreibung
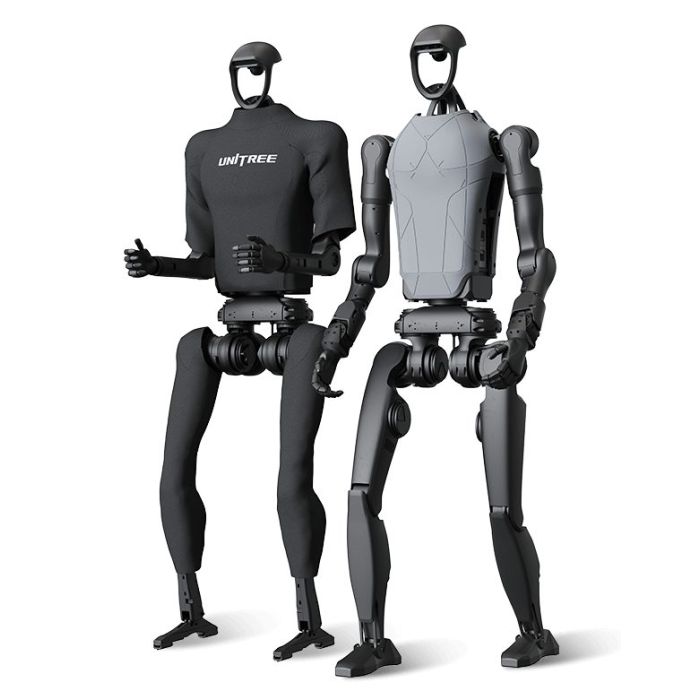
Unitree H1 The New Generation of Robots Human Size Universal Humanoid Robot Highest power performance The advanced powertrain provides the highest level of speed, power, maneuverability and flexibility. Full-size general-purpose humanoid robot that can run Possessing a stable gait and highly flexible movement capabilities, it is able to walk and run autonomously in complex terrains and environments. 360° depth perception Equipped with 3D LiDAR + depth camera, real-time acquisition of high-precision spatial data to achieve panoramic scanning. Unitree H1 Full-Size Universal Humanoid Robot Body Size Height: ~180cm Weight: ~47kg Peak Torque Density 189N.m/Kg Athletic Ability Walking speed>1.5m/s Potential athletic performance>5m/s Endurance Battery capacity: 864Wh (Quickly replaceable) Maximum Joint Torque 360N.m 360° Depth Sensing 3D LIDAR + Depth Camera Unitree M107 Joint Motor Super powerful power performance Significantly improved in terms of agility, speed, load capacity, endurance, and more M107 T-1 T-2 Maximum torque / Pulling force(3.5cm arm equivalent) 360N.m10000N 180N.m 8000N Weight 1.9kg 2.26kg 2.2kg Torque or Tension / Weight Ratio 1895263 79 3636 Hollow shaft Yes Yes - Dual Encoder Yes Yes Yes Dimensions(mm) 107 × 74 100 × 130 60 × 180 Unitree H1 Parameters H1 H1-2 Key Dimensions (1520+285)mm × 570mm × 220mm (1503+285)mm × 510mm × 287mm Thigh and Calf Length 400mm × 2 400mm × 2 Total Arm Length 338mm × 2 685mm DOF of Each Leg 5(Hip × 3 + Knee × 1 + Ankle × 1) 6(Hip × 3 + Knee x 1 + Ankle x 2) DOF of Each Arm 4(Expandable) 7(Shoulder x 3 + Elbow x 1 + Wrist x 3) Total Weight About 47kg About 70kg Joint output bearing Industrial grade crossed roller bearings (high precision,high load capacity) Industrial grade crossed roller bearings (high precision,high load capacity) Core Joint motor Low inertia high-speed internal rotor PMSM (permanent magnet synchronous motor,better response speed and heat dissipation) Low inertia high-speed internal rotor PMSM (permanent magnet synchronous motor,better response speed and heat dissipation) Ultimate Torque of Joint Unit Knee Torque About 360N.m, Hip Joint Torque About 220N.m, Ankle Torque About 59N.m, Arm Joint Torque About 75N.m Knee Torque About 360N.m, Hip Joint Torque About 220N.m, Waist Joint About 220N.m, Ankle Joint About 75x2 N.m. Mobility Moving speed of 3.3m/s(world record),Potential mobility > 5m/s Moving speed <2m/s Battery Battery capacity 15Ah(0.864KWh), Max Voltage 67.2V Battery capacity 15Ah(0.864KWh), Max Voltage 67.2V Control and Perception Computing Power Standard configuration: Intel Core i5(Platform Function),Intel Core i7(User Development) Optional Configuration: Multiple brands and models available, Intel Core i7 or such as Orin NX, etc. Standard configuration: Intel Core i5(Platform Function),Intel Core i7(User Development) Optional Configuration: Multiple brands and models available, Intel Core i7 or Orin NX (Maximum up to 3 devices) Sensor Configuration 3D LIDAR + Depth Camera 3D LIDAR + Depth Camera Dexterous Hand Optional Optional Dex5-1 or other ambidextrous hands Arm joint performance(peak torque) / Shoulder: About 120N.m, Elbow: About 120N.m Wrist: About 30N.m Arm normal load / Peak: About 21Kg; Rated: About 7Kg Versions Comparison Robot H1 Basic H1 Plus H1 Smart H1 Ultimate H1-2 Basic H1-2 Plus H1-2 Smart H1-2 Ultimate Dexterous Hands / RH56DFQ-2R,RH56DFQ-2L / RH56DFTP-2R,RH56DFTP-2L Processor Configuration 1 × Intel Core i5-1235U + 1 × Intel Core i7-1255U/1265U 1 × Intel Core i5-1235U + 2 × Intel Core i7-1255U/1265U (1* can switch to Jetson Orin NX) 1 × Intel Core i5-1235U + 2 × Intel Core i7-1255U/1265U (1* can switch to Jetson Orin NX)) + Jetson Orin NX (On the back of H1) 1 × Intel Core i5-1235U + 2 × Intel Core i7-1255U/1265U (1* can switch to Jetson Orin NX)) + Jetson Orin Nx (can upgrade to AGX) 1 × Intel Core i5-1235U + 1 × Intel Core i7-1255U/1265U 1 × Intel Core i5-1235U + 2 × Intel Core i7-1255U/1265U (1* can switch to Jetson Orin NX) 1 × Intel Core i5-1235U + 2 × Intel Core i7-1255U/1265U (1* can switch to Jetson Orin NX)) + Jetson Orin AGX (On the back of H1-2) 1 × Intel Core i5-1235U + 2 × Intel Core i7-1255U/1265U (1* can switch to Jetson Orin NX)) + Jetson Orin AGX (On the back of H1-2) Introducing the Unitree H1: Revolutionizing Robotics with Embodied AI Meet the Unitree H1, a groundbreaking general-purpose humanoid robot that pushes the boundaries of power and performance. Weighing approximately 47kg and boasting a maximum joint torque of 360N.m, the H1 stands as the pinnacle of robotic innovation. With its advanced embodied AI, this marvel of engineering exemplifies Unitree's commitment to shaping the future of robotics. Experience the next level of humanoid robotics with the Unitree H1.
Unitree H1 The New Generation of Robots Human Size Universal Humanoid Robot Highest power performance The advanced powertrain provides the highest level of speed, power, maneuverability and flexibility. Full-size general-purpose humanoid robot that can run Possessing a stable gait and highly flexible movement capabilities, it is able to walk and run autonomously in complex terrains and environments. 360° depth perception Equipped with 3D LiDAR + depth camera, real-time acquisition of high-precision spatial data to achieve panoramic scanning. Unitree H1 Full-Size Universal Humanoid Robot Body Size Height: ~180cm Weight: ~47kg Peak Torque Density 189N.m/Kg Athletic Ability Walking speed>1.5m/s Potential athletic performance>5m/s Endurance Battery capacity: 864Wh (Quickly replaceable) Maximum Joint Torque 360N.m 360° Depth Sensing 3D LIDAR + Depth Camera Unitree M107 Joint Motor Super powerful power performance Significantly improved in terms of agility, speed, load capacity, endurance, and more M107 T-1 T-2 Maximum torque / Pulling force(3.5cm arm equivalent) 360N.m10000N 180N.m 8000N Weight 1.9kg 2.26kg 2.2kg Torque or Tension / Weight Ratio 1895263 79 3636 Hollow shaft Yes Yes - Dual Encoder Yes Yes Yes Dimensions(mm) 107 × 74 100 × 130 60 × 180 Unitree H1 Parameters H1 H1-2 Key Dimensions (1520+285)mm × 570mm × 220mm (1503+285)mm × 510mm × 287mm Thigh and Calf Length 400mm × 2 400mm × 2 Total Arm Length 338mm × 2 685mm DOF of Each Leg 5(Hip × 3 + Knee × 1 + Ankle × 1) 6(Hip × 3 + Knee x 1 + Ankle x 2) DOF of Each Arm 4(Expandable) 7(Shoulder x 3 + Elbow x 1 + Wrist x 3) Total Weight About 47kg About 70kg Joint output bearing Industrial grade crossed roller bearings (high precision,high load capacity) Industrial grade crossed roller bearings (high precision,high load capacity) Core Joint motor Low inertia high-speed internal rotor PMSM (permanent magnet synchronous motor,better response speed and heat dissipation) Low inertia high-speed internal rotor PMSM (permanent magnet synchronous motor,better response speed and heat dissipation) Ultimate Torque of Joint Unit Knee Torque About 360N.m, Hip Joint Torque About 220N.m, Ankle Torque About 59N.m, Arm Joint Torque About 75N.m Knee Torque About 360N.m, Hip Joint Torque About 220N.m, Waist Joint About 220N.m, Ankle Joint About 75x2 N.m. Mobility Moving speed of 3.3m/s(world record),Potential mobility > 5m/s Moving speed <2m/s Battery Battery capacity 15Ah(0.864KWh), Max Voltage 67.2V Battery capacity 15Ah(0.864KWh), Max Voltage 67.2V Control and Perception Computing Power Standard configuration: Intel Core i5(Platform Function),Intel Core i7(User Development) Optional Configuration: Multiple brands and models available, Intel Core i7 or such as Orin NX, etc. Standard configuration: Intel Core i5(Platform Function),Intel Core i7(User Development) Optional Configuration: Multiple brands and models available, Intel Core i7 or Orin NX (Maximum up to 3 devices) Sensor Configuration 3D LIDAR + Depth Camera 3D LIDAR + Depth Camera Dexterous Hand Optional Optional Dex5-1 or other ambidextrous hands Arm joint performance(peak torque) / Shoulder: About 120N.m, Elbow: About 120N.m Wrist: About 30N.m Arm normal load / Peak: About 21Kg; Rated: About 7Kg Versions Comparison Robot H1 Basic H1 Plus H1 Smart H1 Ultimate H1-2 Basic H1-2 Plus H1-2 Smart H1-2 Ultimate Dexterous Hands / RH56DFQ-2R,RH56DFQ-2L / RH56DFTP-2R,RH56DFTP-2L Processor Configuration 1 × Intel Core i5-1235U + 1 × Intel Core i7-1255U/1265U 1 × Intel Core i5-1235U + 2 × Intel Core i7-1255U/1265U (1* can switch to Jetson Orin NX) 1 × Intel Core i5-1235U + 2 × Intel Core i7-1255U/1265U (1* can switch to Jetson Orin NX)) + Jetson Orin NX (On the back of H1) 1 × Intel Core i5-1235U + 2 × Intel Core i7-1255U/1265U (1* can switch to Jetson Orin NX)) + Jetson Orin Nx (can upgrade to AGX) 1 × Intel Core i5-1235U + 1 × Intel Core i7-1255U/1265U 1 × Intel Core i5-1235U + 2 × Intel Core i7-1255U/1265U (1* can switch to Jetson Orin NX) 1 × Intel Core i5-1235U + 2 × Intel Core i7-1255U/1265U (1* can switch to Jetson Orin NX)) + Jetson Orin AGX (On the back of H1-2) 1 × Intel Core i5-1235U + 2 × Intel Core i7-1255U/1265U (1* can switch to Jetson Orin NX)) + Jetson Orin AGX (On the back of H1-2)
Preisverlauf
Ein Datenpunkt pro Tag, gemittelt nach Beobachtungsdatum.
Beträge in USD
Die Durchschnittswerte werden pro UTC-Tag anhand aller erfassten Angebotspreise berechnet.

Unitree
110.000 €

Unitree
$94.905

Unitree
$99.900

Unitree
$94.905

Unitree
$96.000

Unitree
$65.900

Unitree
$66.800

Unitree
$63.900

Unitree
$56.900

Unitree
$64.300
Unitree
$66.300
Unitree
$62.300
🍪 Cookie-Einstellungen
Wir verwenden Cookies zur Leistungsmessung. Datenschutzerklärung