Durchschnittspreis pro Tag
Beträge in USD
Beschreibung
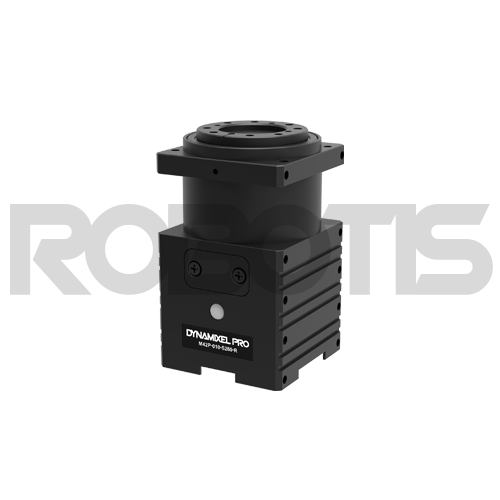
Features DYNAMIXEL is a robot exclusive smart actuator with fully integrated DC Motor + Reduction Gearhead + Controller + Driver + Network in one DC servo module. DYNAMIXEL PRO Plus Series implements removable reduction cycloid gears, resulting in high precision and impact resistance. Torque control based on current sensing Position, Torque and Speed-based command High resolution with combination of Incremental Encoder and Contactless Absolute Encoder Full metal housing for high durability Can be used to make a full-size manipulator, pan tilt, humanoid, etc. [DYNAMIXEL PRO Plus] Upgrade Details Improved design and JST connectors applied Improved dirt inflow and leakage Improved control table (Supports X-series functions) Enhanced control performance such as responsiveness and resolution Enhanced communication responsiveness Improved heat, noise, and durability Package Components PM42-010-S260-R 1 Robot Cable-X4P 600mm 2 Wrench Bolt WB M3x8 20 Performance Comparison Compatible Products Controller : OpenCM 485 Expansion Board, OpenCR1.0 Interface : USB2Dynamixel, U2D2 Caution The operational voltage is different from other DYNAMIXEL series (Operational voltage: 24V). Depending on the number of units used, it is recommended to use a separate power supply. Molex 4Pin connector is used for communication. Factory Default Settings ID : 1 Baud Rate : 57600bps (User can change various settings including ID and baud rate according to environment) Specification Model Name PM42-010-S260-R MCU Cortex-M4 (168 [Mhz], 32 [bit]) Input Voltage 24.0 V Performance Characteristics @24v No Load Speed 28 rpm No Load Current 0.52 A Continuous Operation@24v Torque [N·m] 1.7 Speed [rpm] 26.0 Current [A] 0.6 Resolution Resolution [deg/pulse] 0.0007 Step [pulse] 526,374 Angle [degree] 360 Position Sensor Contactless absolute encoder Incremental encoder Operating Temperature Min. [°C] -5 Max. [°C] 55 Motor Coreless (Maxon) Baud Rate Min. [bps] 9,600 Max. [bps] 10,500,000 Control Algorithm PID Gear Type Cycloid Gear Material Precious Metal Case Material Precious Metal Dimensions (WⅹHⅹD) [mm] 42.0 X 72.0 X 42.0 Dimensions (WⅹHⅹD) [inch] 1.65 X 2.83 X 1.65 Weight [g] 270.00 Weight [oz] 9.52 Gear Ratio 257.0 : 1 Command Signal Digital Packet Protocol Type Half duplex Asynchronous Serial Communication (8bit, 1stop, No Parity) Link (Physical) RS485 Multi Drop Bus ID 0 ~ 252 Feedback Position, Velocity, Current, Temperature, Voltage, External Port, etc Protocol version 2 Operating Mode / Angle Torque Control Mode Velocity Control Mode Position Control Mode Extended Position Control Mode PWM Control Mode Output [W] 10 Standby Current [mA] 30
Features DYNAMIXEL is a robot exclusive smart actuator with fully integrated DC Motor + Reduction Gearhead + Controller + Driver + Network in one DC servo module. DYNAMIXEL PRO Plus Series implements removable reduction cycloid gears, resulting in high precision and impact resistance. Torque control based on current sensing Position, Torque and Speed-based command High resolution with combination of Incremental Encoder and Contactless Absolute Encoder Full metal housing for high durability Can be used to make a full-size manipulator, pan tilt, humanoid, etc. [DYNAMIXEL PRO Plus] Upgrade Details Improved design and JST connectors applied Improved dirt inflow and leakage Improved control table (Supports X-series functions) Enhanced control performance such as responsiveness and resolution Enhanced communication responsiveness Improved heat, noise, and durability Package Components PM42-010-S260-R 1 Robot Cable-X4P 600mm 2 Wrench Bolt WB M3x8 20 Performance Comparison Compatible Products Controller : OpenCM 485 Expansion Board, OpenCR1.0 Interface : USB2Dynamixel, U2D2 Caution The operational voltage is different from other DYNAMIXEL series (Operational voltage: 24V). Depending on the number of units used, it is recommended to use a separate power supply. Molex 4Pin connector is used for communication. Factory Default Settings ID : 1 Baud Rate : 57600bps (User can change various settings including ID and baud rate according to environment) Specification Model Name PM42-010-S260-R MCU Cortex-M4 (168 [Mhz], 32 [bit]) Input Voltage 24.0 V Performance Characteristics @24v No Load Speed 28 rpm No Load Current 0.52 A Continuous Operation@24v Torque [N·m] 1.7 Speed [rpm] 26.0 Current [A] 0.6 Resolution Resolution [deg/pulse] 0.0007 Step [pulse] 526,374 Angle [degree] 360 Position Sensor Contactless absolute encoder Incremental encoder Operating Temperature Min. [°C] -5 Max. [°C] 55 Motor Coreless (Maxon) Baud Rate Min. [bps] 9,600 Max. [bps] 10,500,000 Control Algorithm PID Gear Type Cycloid Gear Material Precious Metal Case Material Precious Metal Dimensions (WⅹHⅹD) [mm] 42.0 X 72.0 X 42.0 Dimensions (WⅹHⅹD) [inch] 1.65 X 2.83 X 1.65 Weight [g] 270.00 Weight [oz] 9.52 Gear Ratio 257.0 : 1 Command Signal Digital Packet Protocol Type Half duplex Asynchronous Serial Communication (8bit, 1stop, No Parity) Link (Physical) RS485 Multi Drop Bus ID 0 ~ 252 Feedback Position, Velocity, Current, Temperature, Voltage, External Port, etc Protocol version 2 Operating Mode / Angle Torque Control Mode Velocity Control Mode Position Control Mode Extended Position Control Mode PWM Control Mode Output [W] 10 Standby Current [mA] 30
Preisverlauf
Ein Datenpunkt pro Tag, gemittelt nach Beobachtungsdatum.
Beträge in USD
Die Durchschnittswerte werden pro UTC-Tag anhand aller erfassten Angebotspreise berechnet.
Robotis
755,95 €

Robotis
$758,20

Robotis
$783,50
Robotis
894,92 €
Robotis
947,95 €
Robotis
£545,92

Robotis
$885,50

Robotis
$527,67

Robotis
ab $530,44
Robotis
444 €
Robotis
416,95 €
Robotis
983,95 €
🍪 Cookie-Einstellungen
Wir verwenden Cookies zur Leistungsmessung. Datenschutzerklärung