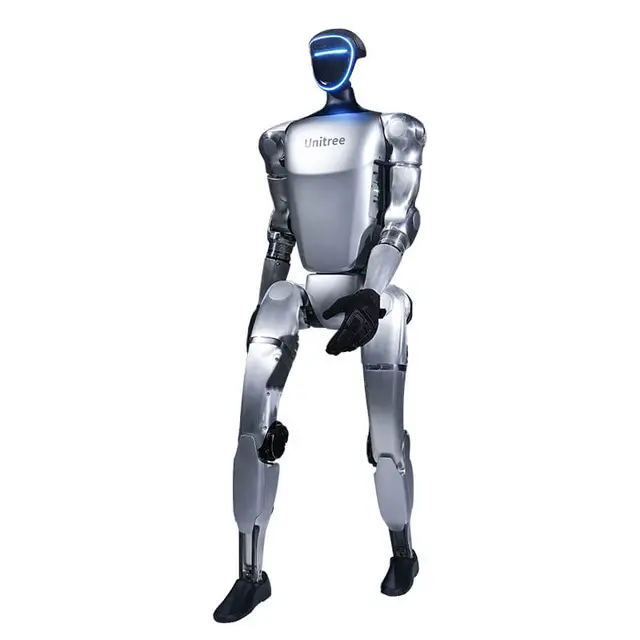
The FF Master Mini Pro is the middle of the three Master Mini configurations, positioned for development, teaching and research rather than first lessons alone. It uses the same 95 cm, 19.5 kg humanoid body as the Master Mini and the Mini Ultra and changes the two things that limit longer work: onboard compute and battery.
Compute rises to 117 TOPS, against 48 TOPS on the Master Mini, which leaves more headroom for perception models and learned behaviours running on the robot itself. The 5 Ah battery gives about 80 minutes of walking at 0.4 m/s, against about 30 minutes on the 2 Ah Master Mini, so a lab session or a practice match can run without a battery change. The Mini Ultra keeps the same battery and moves to 200 TOPS on an NVIDIA Jetson AGX Orin 32 GB.
The body itself does not change: 22 degrees of freedom across legs (6 × 2), arms (4 × 2) and head (2), 60 N·m of peak joint torque, a top speed of 1.1 m/s and turning at 1.5 rad/s. Perception combines a stereo depth camera with a 9-axis IMU, and a circular three-microphone array with a speaker handles voice interaction. It suits university labs working on locomotion and embodied AI, schools running robot-soccer teams, and developers who want more running time per battery than the entry model allows.
Development runs through a ROS 2 SDK with custom development support, connectivity is Wi-Fi and Bluetooth, and updates arrive over the air. The robot comes with a joystick controller and a charger, and a Faraday Future Skill Pack is included. Its contents, the processor behind the 117 TOPS figure and the charging time are confirmed at quote.
Key Capabilities
-
117 TOPS Onboard: The middle compute tier of the Master Mini range leaves more headroom for on-robot perception and learning models.
-
About 80 Minutes per Battery: The 5 Ah battery gives about 80 minutes of walking at 0.4 m/s, against about 30 minutes on the Master Mini.
-
Built for Development and Research: Faraday Future positions the Pro for development, teaching and research work.
-
Shared 22-DOF Body: Each leg has six joints, each arm four and the head two, with 60 N·m of peak joint torque.
-
Quick on Its Feet: It reaches 1.1 m/s and turns at 1.5 rad/s for robot soccer and athletic competition.
-
Depth Vision and Voice: A stereo depth camera, a 9-axis IMU, three microphones and a speaker cover vision, balance and conversation.
-
ROS 2 SDK and OTA: Custom development runs through the ROS 2 SDK, and updates arrive over the air.
Buying through Robotix Market
This unit is sourced new through established distribution channels and ships worldwide with the full manufacturer warranty. Technical support is coordinated with the manufacturer's own service network. Deployment scope, configuration, and commissioning responsibilities are agreed as part of the quotation — on-site installation is not included in the product price.