每日平均价格
金额单位:USD
描述
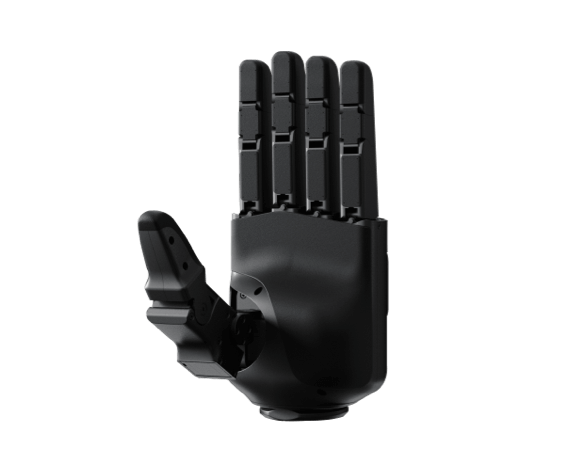
#html-body [data-pb-style=Q755IPP],#html-body [data-pb-style=WKO3B3D]{background-position:left top;background-size:cover;background-repeat:no-repeat;background-attachment:scroll}#html-body [data-pb-style=WKO3B3D]{justify-content:flex-start;display:flex;flex-direction:column}#html-body [data-pb-style=Q755IPP]{align-self:stretch}#html-body [data-pb-style=JQXQX7P]{display:flex;width:100%}#html-body [data-pb-style=M4LWALF]{justify-content:center;display:flex;flex-direction:column;background-position:left top;background-size:cover;background-repeat:no-repeat;background-attachment:scroll;width:50%;align-self:stretch}#html-body [data-pb-style=X83QYA3]{justify-content:flex-start;display:flex;flex-direction:column;width:50%;align-self:stretch}#html-body [data-pb-style=M81G3AD],#html-body [data-pb-style=SQW0094],#html-body [data-pb-style=X83QYA3]{background-position:left top;background-size:cover;background-repeat:no-repeat;background-attachment:scroll}#html-body [data-pb-style=M81G3AD]{justify-content:flex-start;display:flex;flex-direction:column}#html-body [data-pb-style=SQW0094]{align-self:stretch}#html-body [data-pb-style=ADRWR16]{display:flex;width:100%}#html-body [data-pb-style=S89E3ED]{justify-content:flex-start;display:flex;flex-direction:column;background-position:left top;width:50%;align-self:stretch}#html-body [data-pb-style=DAVPE8X],#html-body [data-pb-style=S89E3ED],#html-body [data-pb-style=U0GA9C4]{background-size:cover;background-repeat:no-repeat;background-attachment:scroll}#html-body [data-pb-style=U0GA9C4]{justify-content:center;display:flex;flex-direction:column;background-position:left top;width:50%;align-self:stretch}#html-body [data-pb-style=DAVPE8X]{background-position:center center;min-height:900px;text-align:left}#html-body [data-pb-style=WRFJBXB]{background-color:transparent}#html-body [data-pb-style=EP7NGOU],#html-body [data-pb-style=V351URH]{background-position:left top;background-size:cover;background-repeat:no-repeat;background-attachment:scroll}#html-body [data-pb-style=V351URH]{justify-content:flex-start;display:flex;flex-direction:column}#html-body [data-pb-style=EP7NGOU]{align-self:stretch}#html-body [data-pb-style=MSXJR5B]{display:flex;width:100%}#html-body [data-pb-style=PX8HQWL]{justify-content:flex-start;display:flex;flex-direction:column;background-position:left top;background-size:cover;background-repeat:no-repeat;background-attachment:scroll;width:58.3333%;align-self:stretch}#html-body [data-pb-style=B0A3F56]{border-style:none}#html-body [data-pb-style=MSG2D65],#html-body [data-pb-style=RU8QFAM]{max-width:100%;height:auto}#html-body [data-pb-style=CKK5THY],#html-body [data-pb-style=VXKC1IV]{display:flex;flex-direction:column;background-position:left top;background-size:cover;background-repeat:no-repeat;background-attachment:scroll}#html-body [data-pb-style=VXKC1IV]{justify-content:center;width:41.6667%;align-self:stretch}#html-body [data-pb-style=CKK5THY]{justify-content:flex-start;text-align:center}#html-body [data-pb-style=W8491HI]{text-align:center}#html-body [data-pb-style=X4XG9MH]{border-style:none}#html-body [data-pb-style=TJ2E7VW],#html-body [data-pb-style=WT6M7N1]{max-width:100%;height:auto}#html-body [data-pb-style=K68TM7M]{justify-content:flex-start;display:flex;flex-direction:column}#html-body [data-pb-style=GNOKVCH],#html-body [data-pb-style=K68TM7M]{background-position:left top;background-size:cover;background-repeat:no-repeat;background-attachment:scroll}#html-body [data-pb-style=GBE61WE]{border-radius:0;min-height:800px;background-color:transparent}#html-body [data-pb-style=SDUMPKS]{text-align:center;padding-top:50px}@media only screen and (max-width: 768px) { #html-body [data-pb-style=B0A3F56],#html-body [data-pb-style=X4XG9MH]{border-style:none} }Unitree Dex5-1Smart Adaptability, Instant Responsiveness20 Degrees of freedom (16 active+4)High Precision, Ultimate ControlEach finger joint has degrees of freedom to support smooth backdrivability. Eliminates "stiff hands", making operations smoother and more convenient for reinforcement learning(RL) training.Ultra-fast Reflexes, Snake-like FlexibilityNumber of degrees of freedom 20 5pieces All five fingers can be replaced independently ±22° Four-finger Lateral SwingImproved grip reliability and adapts more effectively to curved surfaces of grasped objects.Precise Feedback, Control Every Millimeter94 tactile sensors per hand;supports secondary development of tactile algorithms for dexterous handsHigh-power densityhollow-cup motorHigh-power density driveand high-precision encoderLow damping small clearance reducerMicro-gap design ensures smooth and effortless motionThe rotation axis of joint is closer to the surface, with ultra-small joint gaps. This enables a smoother and more fluid grasp, preventing joint corners from getting stuck on objects.Product Parameters Dex5-1 Dex5-1P Weight 1000g 1000g Size [1] 217.3mm x 127.5mm x 72.1mm(The final shipped version may vary.) 217.3mm x 127.5mm x 72.1mm(The final shipped version may vary.) Degrees of Freedom Thumb x 4 Index Finger x 3 Middle Finger x 3 Ring Finger x 3 Little Finger x 3 Thumb x 4 Index Finger x 3 Middle Finger x 3 Ring Finger x 3 Little Finger x 3 Transmission Mechanism 12 self-developed micro force-controlled composite transmission joints (enables robot to achieve tactile proprioception) 4 micro force-controlled joint gear transmission 12 self-developed micro force-controlled composite transmission joints (enables robot to achieve tactile proprioception) 4 micro force-controlled joint gear transmission Angle of Joint Thumb Joint: Thumb Joint 0: -33.5°~39° Thumb Joint 1: 0°~100° Thumb Joint 2: 0°~110° Thumb Joint 3: 0°~92° Four-Finger Joints: Knuckles 0: -22°~22° Knuckles 1: 0°~90° Knuckles 2: 0°~95° Knuckles 3: 0°~81°(Coupling with finger joint 2) Thumb Joint: Thumb Joint 0: -33.5°~39° Thumb Joint 1: 0°~100° Thumb Joint 2: 0°~110° Thumb Joint 3: 0°~92° Four-Finger Joints: Knuckles 0: -22°~22° Knuckles 1: 0°~90° Knuckles 2: 0°~95° Knuckles 3: 0°~81°(Coupling with finger joint 2) Four-Finger Lateral Swing ±22° ±22° Minimum grip diameter 10mm 10mm Fingertip Repeat Positioning Accuracy ±1mm ±1mm Fingertip strength 10N 10N Working Voltage 24V~60V 24V~60V Static Current [email protected] [email protected] Maximum Current 58V@3A 58V@3A Communication Interface USB2.0 USB2.0 Working Temperature Range -20℃ ~ 60℃ -20℃ ~ 60℃ Load Conditions ( Palm Facing Down At Room Temperature, Grasping A 5cm Round Hard Object) The Maximum Weight is 3.5kg The Maximum Weight is 3.5kg Load Condition (Palm Facing Left At Room Temperature, Grasping A 5cm Round Hard Object) The Maximum Weight is 4.5kg The Maximum Weight is 4.5kg Number of Pressure Sensors / 12 (94 pressure sensors in total) Array resolution / 2 x 5 (Palm) 2 x 3 (Single Finger Pad) x 5 2 x 3 (Single Fingertip) x 5 2 x 3 (Single Finger Root) x 4 Range of Perception / 10g-2500g Maximum Acceptance (Unamaged) [2] / 20Kg Communication rate 1000Hz 1000Hz The number of bytes in a full packet Sender:1234 bytes Receiver:1270 bytes Sender:1234 bytes Receiver:1270 bytes Perceptual feedback Joint Mode, Joint Position, Joint Velocity, Joint Torque, Joint Temperature, Voltage and Current, imu Data Joint Mode, Joint Position, Joint Velocity, Joint Torque, Joint Temperature, Voltage and Current, Sensor Pressure Value, Sensor Temperature Value, imu Data Control feedback Joint Mode, Joint Position, Joint Velocity, Joint Torque, Joint Stiffness Coefficient, Joint Damping Coefficient Joint Mode, Joint Position, Joint Velocity, Joint Torque, Joint Stiffness Coefficient, Joint Damping Coefficient [1] It is the size of the dexterous hand in flat state. [2] The data refers to the pressure exerted by the dexterous hand when it is pressed by a vertical downward cylinder with a diameter of 1cm, which varies in different application scenarios. Please refer to the actual situation. [3] The above parameters may vary in different scenarios and configurations, please subject to actual situation. [4] If any change in the appearance of the product, please refer to the actual product. [5] This product is a civilian robot. We kindly request that all users refrain from making any dangerous modifications or using the robot in a hazardous manner. [6] Please visit Unitree Robotics Website for more related terms and policies, and comply with local laws and regulations. Coming Soon
#html-body [data-pb-style=Q755IPP],#html-body [data-pb-style=WKO3B3D]{background-position:left top;background-size:cover;background-repeat:no-repeat;background-attachment:scroll}#html-body [data-pb-style=WKO3B3D]{justify-content:flex-start;display:flex;flex-direction:column}#html-body [data-pb-style=Q755IPP]{align-self:stretch}#html-body [data-pb-style=JQXQX7P]{display:flex;width:100%}#html-body [data-pb-style=M4LWALF]{justify-content:center;display:flex;flex-direction:column;background-position:left top;background-size:cover;background-repeat:no-repeat;background-attachment:scroll;width:50%;align-self:stretch}#html-body [data-pb-style=X83QYA3]{justify-content:flex-start;display:flex;flex-direction:column;width:50%;align-self:stretch}#html-body [data-pb-style=M81G3AD],#html-body [data-pb-style=SQW0094],#html-body [data-pb-style=X83QYA3]{background-position:left top;background-size:cover;background-repeat:no-repeat;background-attachment:scroll}#html-body [data-pb-style=M81G3AD]{justify-content:flex-start;display:flex;flex-direction:column}#html-body [data-pb-style=SQW0094]{align-self:stretch}#html-body [data-pb-style=ADRWR16]{display:flex;width:100%}#html-body [data-pb-style=S89E3ED]{justify-content:flex-start;display:flex;flex-direction:column;background-position:left top;width:50%;align-self:stretch}#html-body [data-pb-style=DAVPE8X],#html-body [data-pb-style=S89E3ED],#html-body [data-pb-style=U0GA9C4]{background-size:cover;background-repeat:no-repeat;background-attachment:scroll}#html-body [data-pb-style=U0GA9C4]{justify-content:center;display:flex;flex-direction:column;background-position:left top;width:50%;align-self:stretch}#html-body [data-pb-style=DAVPE8X]{background-position:center center;min-height:900px;text-align:left}#html-body [data-pb-style=WRFJBXB]{background-color:transparent}#html-body [data-pb-style=EP7NGOU],#html-body [data-pb-style=V351URH]{background-position:left top;background-size:cover;background-repeat:no-repeat;background-attachment:scroll}#html-body [data-pb-style=V351URH]{justify-content:flex-start;display:flex;flex-direction:column}#html-body [data-pb-style=EP7NGOU]{align-self:stretch}#html-body [data-pb-style=MSXJR5B]{display:flex;width:100%}#html-body [data-pb-style=PX8HQWL]{justify-content:flex-start;display:flex;flex-direction:column;background-position:left top;background-size:cover;background-repeat:no-repeat;background-attachment:scroll;width:58.3333%;align-self:stretch}#html-body [data-pb-style=B0A3F56]{border-style:none}#html-body [data-pb-style=MSG2D65],#html-body [data-pb-style=RU8QFAM]{max-width:100%;height:auto}#html-body [data-pb-style=CKK5THY],#html-body [data-pb-style=VXKC1IV]{display:flex;flex-direction:column;background-position:left top;background-size:cover;background-repeat:no-repeat;background-attachment:scroll}#html-body [data-pb-style=VXKC1IV]{justify-content:center;width:41.6667%;align-self:stretch}#html-body [data-pb-style=CKK5THY]{justify-content:flex-start;text-align:center}#html-body [data-pb-style=W8491HI]{text-align:center}#html-body [data-pb-style=X4XG9MH]{border-style:none}#html-body [data-pb-style=TJ2E7VW],#html-body [data-pb-style=WT6M7N1]{max-width:100%;height:auto}#html-body [data-pb-style=K68TM7M]{justify-content:flex-start;display:flex;flex-direction:column}#html-body [data-pb-style=GNOKVCH],#html-body [data-pb-style=K68TM7M]{background-position:left top;background-size:cover;background-repeat:no-repeat;background-attachment:scroll}#html-body [data-pb-style=GBE61WE]{border-radius:0;min-height:800px;background-color:transparent}#html-body [data-pb-style=SDUMPKS]{text-align:center;padding-top:50px}@media only screen and (max-width: 768px) { #html-body [data-pb-style=B0A3F56],#html-body [data-pb-style=X4XG9MH]{border-style:none} }Unitree Dex5-1Smart Adaptability, Instant Responsiveness20 Degrees of freedom (16 active+4)High Precision, Ultimate ControlEach finger joint has degrees of freedom to support smooth backdrivability. Eliminates "stiff hands", making operations smoother and more convenient for reinforcement learning(RL) training.Ultra-fast Reflexes, Snake-like FlexibilityNumber of degrees of freedom 20 5pieces All five fingers can be replaced independently ±22° Four-finger Lateral SwingImproved grip reliability and adapts more effectively to curved surfaces of grasped objects.Precise Feedback, Control Every Millimeter94 tactile sensors per hand;supports secondary development of tactile algorithms for dexterous handsHigh-power densityhollow-cup motorHigh-power density driveand high-precision encoderLow damping small clearance reducerMicro-gap design ensures smooth and effortless motionThe rotation axis of joint is closer to the surface, with ultra-small joint gaps. This enables a smoother and more fluid grasp, preventing joint corners from getting stuck on objects.Product Parameters Dex5-1 Dex5-1P Weight 1000g 1000g Size [1] 217.3mm x 127.5mm x 72.1mm(The final shipped version may vary.) 217.3mm x 127.5mm x 72.1mm(The final shipped version may vary.) Degrees of Freedom Thumb x 4 Index Finger x 3 Middle Finger x 3 Ring Finger x 3 Little Finger x 3 Thumb x 4 Index Finger x 3 Middle Finger x 3 Ring Finger x 3 Little Finger x 3 Transmission Mechanism 12 self-developed micro force-controlled composite transmission joints (enables robot to achieve tactile proprioception) 4 micro force-controlled joint gear transmission 12 self-developed micro force-controlled composite transmission joints (enables robot to achieve tactile proprioception) 4 micro force-controlled joint gear transmission Angle of Joint Thumb Joint: Thumb Joint 0: -33.5°~39° Thumb Joint 1: 0°~100° Thumb Joint 2: 0°~110° Thumb Joint 3: 0°~92° Four-Finger Joints: Knuckles 0: -22°~22° Knuckles 1: 0°~90° Knuckles 2: 0°~95° Knuckles 3: 0°~81°(Coupling with finger joint 2) Thumb Joint: Thumb Joint 0: -33.5°~39° Thumb Joint 1: 0°~100° Thumb Joint 2: 0°~110° Thumb Joint 3: 0°~92° Four-Finger Joints: Knuckles 0: -22°~22° Knuckles 1: 0°~90° Knuckles 2: 0°~95° Knuckles 3: 0°~81°(Coupling with finger joint 2) Four-Finger Lateral Swing ±22° ±22° Minimum grip diameter 10mm 10mm Fingertip Repeat Positioning Accuracy ±1mm ±1mm Fingertip strength 10N 10N Working Voltage 24V~60V 24V~60V Static Current [email protected] [email protected] Maximum Current 58V@3A 58V@3A Communication Interface USB2.0 USB2.0 Working Temperature Range -20℃ ~ 60℃ -20℃ ~ 60℃ Load Conditions ( Palm Facing Down At Room Temperature, Grasping A 5cm Round Hard Object) The Maximum Weight is 3.5kg The Maximum Weight is 3.5kg Load Condition (Palm Facing Left At Room Temperature, Grasping A 5cm Round Hard Object) The Maximum Weight is 4.5kg The Maximum Weight is 4.5kg Number of Pressure Sensors / 12 (94 pressure sensors in total) Array resolution / 2 x 5 (Palm) 2 x 3 (Single Finger Pad) x 5 2 x 3 (Single Fingertip) x 5 2 x 3 (Single Finger Root) x 4 Range of Perception / 10g-2500g Maximum Acceptance (Unamaged) [2] / 20Kg Communication rate 1000Hz 1000Hz The number of bytes in a full packet Sender:1234 bytes Receiver:1270 bytes Sender:1234 bytes Receiver:1270 bytes Perceptual feedback Joint Mode, Joint Position, Joint Velocity, Joint Torque, Joint Temperature, Voltage and Current, imu Data Joint Mode, Joint Position, Joint Velocity, Joint Torque, Joint Temperature, Voltage and Current, Sensor Pressure Value, Sensor Temperature Value, imu Data Control feedback Joint Mode, Joint Position, Joint Velocity, Joint Torque, Joint Stiffness Coefficient, Joint Damping Coefficient Joint Mode, Joint Position, Joint Velocity, Joint Torque, Joint Stiffness Coefficient, Joint Damping Coefficient [1] It is the size of the dexterous hand in flat state. [2] The data refers to the pressure exerted by the dexterous hand when it is pressed by a vertical downward cylinder with a diameter of 1cm, which varies in different application scenarios. Please refer to the actual situation. [3] The above parameters may vary in different scenarios and configurations, please subject to actual situation. [4] If any change in the appearance of the product, please refer to the actual product. [5] This product is a civilian robot. We kindly request that all users refrain from making any dangerous modifications or using the robot in a hazardous manner. [6] Please visit Unitree Robotics Website for more related terms and policies, and comply with local laws and regulations.
价格历史
每天显示一个数据点,按观测日期计算平均值。
金额单位:USD
每天的平均价格根据该 UTC 日期记录的所有报价计算。

Unitree
$7,600

Unitree
$7,600

Unitree
$6,200

Unitree
$5,900

Unitree
$5,900

Unitree
$5,850

Unitree
$9,120
Unitree
6,000 €

Unitree
$5,600

Unitree
$5,600

Unitree
$6,200

Unitree
$9,120
🍪 Cookie 偏好设置
我们使用 Cookie 来衡量性能。 隐私政策