-15%
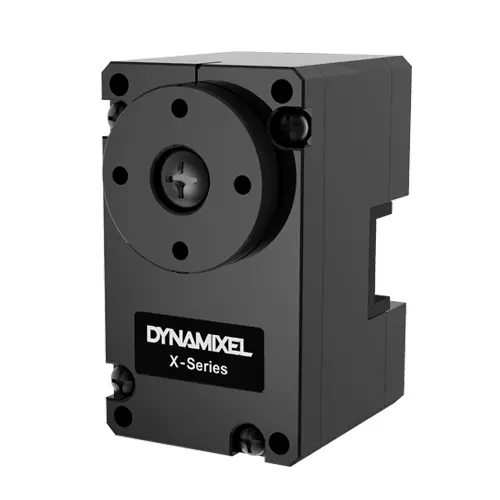
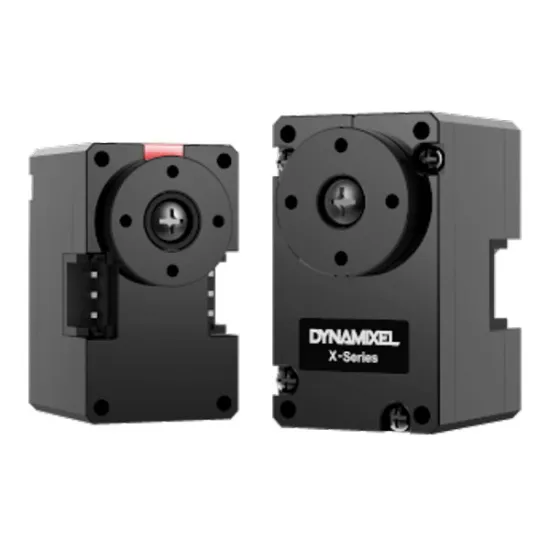
Dynamixel XC330-T288-T Servo

Dynamixel XC330-T288-T Servo

Dynamixel XC330-T288-T Servo
Robotis | A-000000-04952
€110.40
€93.84 VAT incl. €78.20 VAT excl.
Save 15%

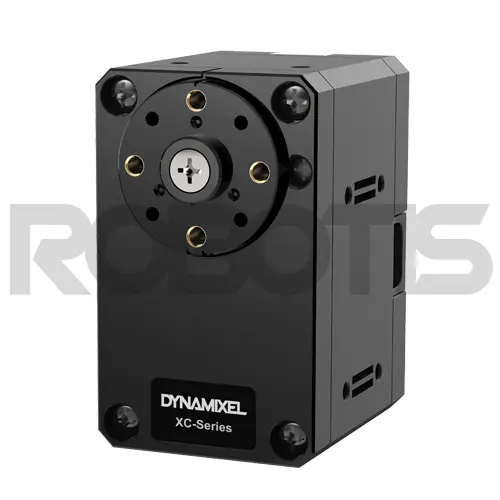
With its higher gear ratio and stall torque, the Dynamixel XC330-T288-T is one of the most powerful servo motors in the XC series.


Manufacturer reference: 902-0171-000

Quantity
Available at the end of January 2027

Create a cart and turn it into a quote instantly!
Payment methods (see T&C)
Debit card
PayPal
Payment by invoice
Wire transfer

How does this servo fit into the DYNAMIXEL range?

This video gives a quick overview to understand which types of projects this servo may suit: articulated robot, mobile base, gripper or prototype.

✅

✅

✅

Place this model within the range

Compare options without starting from scratch

Save time during selection

Dynamixel XC330-T288-T: more power, less speed

The Dynamixel Robotis XC range of servos is designed for roboticists requiring faster and more powerful servos than those in the more economical XL range. The Dynamixel XC330-T288-T offers a slightly higher torque and gear ratio for a somewhat muted speed (65 rpm, one of the lowest in the XC range).

If you’re looking for a really fast servo motor, you’ll be better off with the XC330-T181-T, which has an equivalent input voltage range (between 6.5 and 12 V). But if you want to experiment with an economical, customisable and slightly more powerful actuator, the XC330-T288-T is an excellent compromise.

As always, this servo comes with all the Dynamixel guarantees: superior programmability, multiple control modes, comprehensive feedback, etc. Created from engineering plastic and metal, it also offers great freedom in terms of assembly used with the associated kits.

Technical specifications of the XC330-T288-T servo motor

  • ARM CORTEX-M0+ 64 MHz, 32-bit processor
  • Position sensor: contactless absolute encoder (12 bits, 360°)
  • Coreless DC motor
  • Baud rate: 9,600 bps to 4 Mbps
  • Control algorithm: PID
  • Resolution: 4,096 pulses/revolution
  • Operating modes: current control, velocity control, position control (0 to 360°), extended position control (multi-turn), current-based position control, PWM control (voltage control)
  • Gear ratio: 288.35:1
  • Stall torque:
    • 0.76 N.m @ 9 V, 0.61 A
    • 0.92 N.m @ 11.1 V, 0.80 A
    • 1 N.m @ 12 V, 0.88 A
  • No-load speed:
    • 52 rev/min @ 9 V
    • 65 rev/min @ 11.1 V
    • 71 rev/min @ 12 V
  • Input voltage: 6.5–12 V (recommended: 11.1 V)
  • Standby current: 17 mA
  • Digital packet command signal
  • Physical connection:
  • TTL multidrop bus (3.3 V logic, 5 V compatible)
  • TTL half duplex asynchronous serial communication (8 bits, 1 stop, no parity)
  • ID: 253 (0~252)
  • Feedback: position, velocity, current, real-time tick, trajectory, temperature, input voltage, etc.
  • Case material: engineering plastic
  • Gear material: full metal gear (2 bearings)
  • Operating temperature: -5 to +60 °C
  • Weight: 23 g
  • Dimensions: 20 x 34 x 26 mm

Resources for the XC330-T288-T servo motor

Find the right information for your Dynamixel XC330-T288-T servo among this list of links, compiled especially for you:

    My Dynamixel servomotor is not detected, what can I do about it ?

    Check that your Dynamixel servomotor is correctly configured. Do not hesitate to re-flash it with the ROBOTIS Software Roboplus. After re-flash remember to re-configure it. If the issue is not solved, for an advanced support.


    My motor works but it seems like there is an offset. Why ?

    The motor is probably not well mounted. Check that you correctly mounted the horns by respecting the mark.


    My Dynamixel servomotor seems blocked. I can't turn it even when it is not alimented.

    There is probably a mechanical issue with the Dynamixel servomotor. You can directly to get more advance support.


    My Dynamixel servomotor is not working properly.

    Check your power supply and the system cabling (try with a different servomotor). You can also reset the servo. If nothing works, the best solution is to go through the Dynamixel servomotor checklist!


    What is the difference between Protocol 1.0 and Protocol 2.0?

    The 1.0 protocol is dedicated to the Dynamixel AX and MX series. Protocol 2.0 is for the X and Dynamixel Pro series. Protocol 2.0 control tables include PID controls which allow for more precise adjustment of the servo motor movements. Protocol 2.0 can be updated on MX series servo motors. You can refer to the protocol 1.0 and protocol 2.0 pages for more informations.


价格历史

平均价格走势

每天显示一个数据点,按观测日期计算平均值。

每日平均价格

金额单位:USD

$103.01
以 USD 计价的平均价格历史图表从 2026年10月2日 到 2026年11月22日 的 61 条观测数据折线图。$125$120$115$110$105$10010月2日10月14日10月27日11月9日11月22日2026年10月2日:平均价 $121.192026年10月3日:平均价 $121.192026年10月4日:平均价 $121.192026年10月5日:平均价 $121.192026年10月6日:平均价 $121.192026年10月7日:平均价 $121.192026年10月8日:平均价 $121.192026年10月9日:平均价 $121.192026年10月10日:平均价 $121.192026年10月11日:平均价 $121.192026年10月12日:平均价 $121.192026年10月13日:平均价 $121.192026年10月14日:平均价 $121.192026年10月15日:平均价 $121.192026年10月16日:平均价 $121.192026年10月17日:平均价 $121.192026年10月18日:平均价 $121.192026年10月19日:平均价 $121.192026年10月20日:平均价 $121.192026年10月21日:平均价 $121.192026年10月22日:平均价 $121.192026年10月23日:平均价 $121.192026年10月24日:平均价 $121.192026年10月25日:平均价 $121.192026年10月26日:平均价 $121.192026年10月27日:平均价 $121.192026年10月28日:平均价 $121.192026年10月29日:平均价 $121.192026年10月30日:平均价 $121.192026年10月31日:平均价 $121.192026年11月1日:平均价 $121.192026年11月2日:平均价 $103.012026年11月3日:平均价 $103.012026年11月4日:平均价 $103.012026年11月5日:平均价 $103.012026年11月6日:平均价 $103.012026年11月7日:平均价 $103.012026年11月8日:平均价 $103.012026年11月9日:平均价 $103.012026年11月10日:平均价 $103.012026年11月11日:平均价 $103.012026年11月12日:平均价 $103.012026年11月13日:平均价 $103.012026年11月14日:平均价 $103.012026年11月15日:平均价 $103.012026年11月16日:平均价 $103.012026年11月17日:平均价 $103.012026年11月18日:平均价 $103.012026年11月19日:平均价 $103.012026年11月20日:平均价 $103.012026年11月21日:平均价 $103.012026年11月22日:平均价 $103.01

每天的平均价格根据该 UTC 日期记录的所有报价计算。