Including €0.01 for ecotax
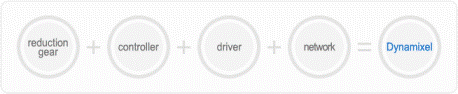
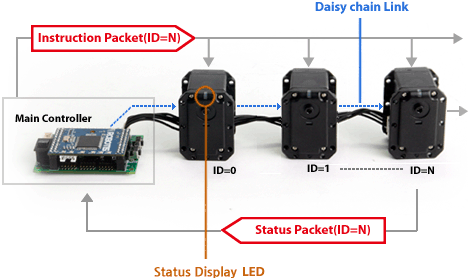
The servomotors have to be linked to a main controller (CM-700, CM-5, CM-510 or CM-530) to be commanded. The progams are made with RoboPlus, which allow really easy programmation, without much previous knowledge.
The most recent main controllers support embedded C and there is a SDK for you to developp your own applications.
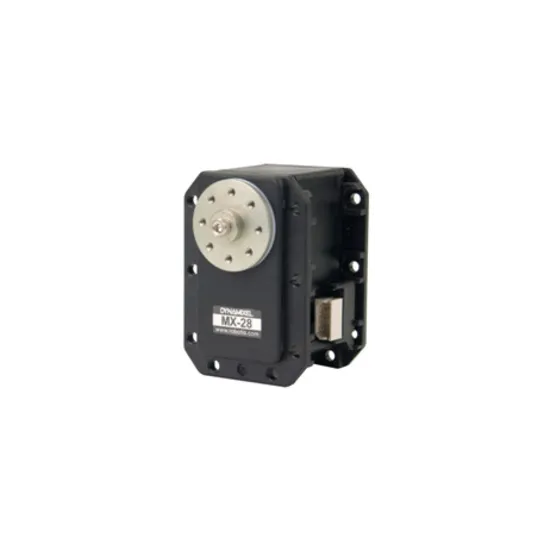
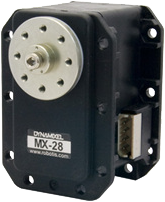
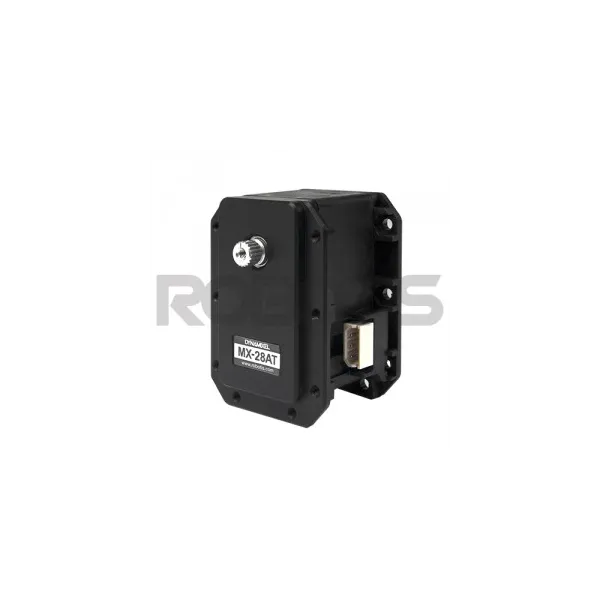
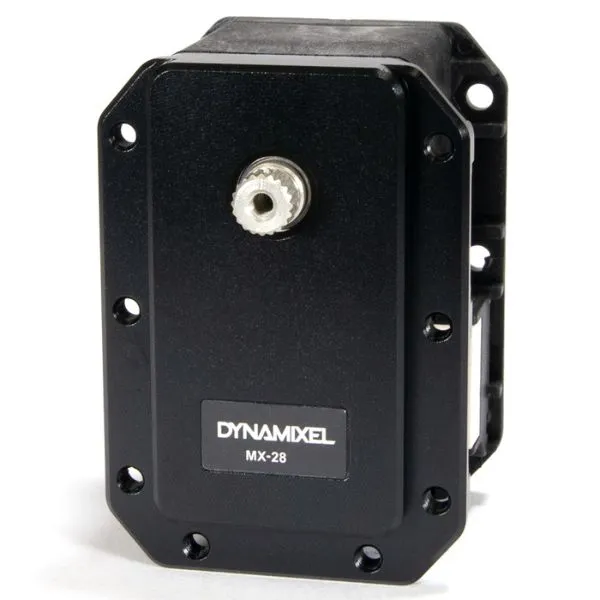
The MX series differs from the other due to features such as a more advanced features on the PID control, 360° control et high speed communication. The MX-28 servomoteur has been splited into two models: the Dynamixel MX-28T actuator that keeps the Half duplex Asynchronous Serial Communication protocol and the TTL Level Multi Drop physical link, when the Dynamixel MX-28R actuator uses RS485 communication protocol and multi drop bus.
This document offers an overview on the characteristics of all the Dynamixel servomotors.
 Comparison between all Dynamixel servomotors |
The chart below compare the Dynamixel actuators on their performance. Servomotors are differentiated by communication type (and the MX range proposes both protocols).
Check that your Dynamixel servomotor is correctly configured. Do not hesitate to re-flash it with the ROBOTIS Software Roboplus. After re-flash remember to re-configure it. If the issue is not solved, contact us for an advanced support.
The motor is probably not well mounted. Check that you correctly mounted the horns by respecting the mark.
There is probably a mechanical issue with the Dynamixel servomotor. You can directly contact us to get more advance support.
Check your power supply and the system cabling (try with a different servomotor). You can also reset the servo. If nothing works, the best solution is to go through the Dynamixel servomotor checklist!
The 1.0 protocol is dedicated to the Dynamixel AX and MX series. Protocol 2.0 is for the X and Dynamixel Pro series. Protocol 2.0 control tables include PID controls which allow for more precise adjustment of the servo motor movements. Protocol 2.0 can be updated on MX series servo motors. You can refer to the protocol 1.0 and protocol 2.0 pages for more informations.
价格历史
每天显示一个数据点,按观测日期计算平均值。
金额单位:USD
每天的平均价格根据该 UTC 日期记录的所有报价计算。

Robotis
$298.89
Robotis
£224.02
Robotis
223.40 €
Robotis
300.26 €
Robotis
331.43 €
Robotis
329.40 €
Robotis
340.74 €
Robotis
325.56 €
Robotis
327.54 €
Robotis
317.40 €
Robotis
317.40 €
Robotis
304.20 €
🍪 Cookie 偏好设置
我们使用 Cookie 来衡量性能。 隐私政策