每日平均价格
金额单位:USD
描述
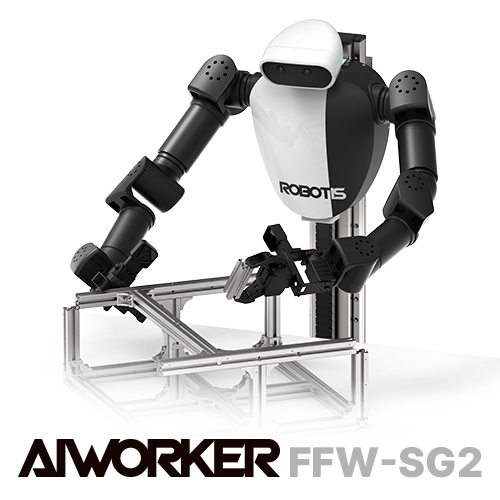
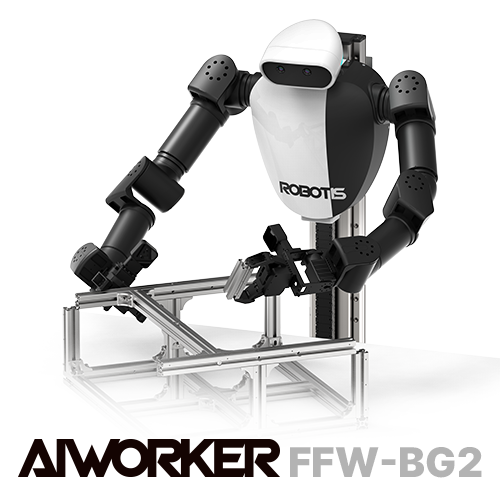
DYNAMIXEL Control Controls high-quality DYNAMIXELs with a single integrated protocol to simplify and precisely implement the overall system's motion. Expandable Hand Comes with a standard 2-finger gripper, which can be replaced with various end-effectors depending on the purpose to ensure high manipulability. Swerve Drive Applies an omnidirectional swerve drive, allowing for free movement and high reliability even in narrow spaces. Exoskeleton Leader Through an intuitive leader-follower system structure, it can collect and efficiently use precise motion data in real time. End-to-End Pipeline Provides an end-to-end pipeline that covers the entire Al development process, from data collection and training to execution. Built-in Battery Equipped with a built-in battery, it can operate continuously for up to 6 hours without an external power source, minimizing constraints on work time and space. Open-Source Platform Offers all hardware, software, and simulation files as open-source, allowing anyone to freely use them for research and development. Simulation Integration Maximizes development efficiency by perfectly integrating with major simulators like Isaac Sim/Lab, MuJoCo, and Gazebo to pre-verify the robot's movements. Specification Follower Properties FFW-BG2(Basic Type) FFW-SG2(Swerve Type) Dimensions (WxDxH) 604x564x1607 mm23.8x22.2x63.2 (inch) 604x602x1623 mm23.8x23.7x63.8 (inch) Weight 85 kg (187 lb) 90 kg (198 lb) Degrees of Freedom Total: 19 DOF- Arm: 7 DOF x2- Gripper: 1 DOF x2- Head: 2 DOF x1- Lift: 1 DOF x1 Total: 25 DOF- Arm: 7 DOF x2- Gripper: 1 DOF x2- Head: 2 DOF x1- Lift: 1 DOF x1- Mobile: 6DOF Arm Reach 641 mm (to wrist) + hand 641 mm (to wrist) + hand Arm Payload(Nominal) 3.0 kg (single arm)6.0 kg (dual arm) 3.0 kg (single arm)6.0 kg (dual arm) Arm Payload(Peak) 5.0 kg (single arm)10.0 kg (dual arm) 5.0 kg (single arm)10.0 kg (dual arm) Gripper/Hand RH-P12-RN RH-P12-RN Mobile Type None Swerve Drive Mobile Operation Velocity None 1.5 m/s Power Type AC powered via SMPS Battery & AC powered via SMPS Power Specifications 24VDC, 80A, 1920W 25V, 80 Ah (2040Wh) & 24VDC, 80A, 1920W Ambient Operating Temperature 0 ~ 40ºC 0 ~ 40ºC Exterior Materials Aluminum, Plastic Aluminum, Plastic Sensor RGBD Camera x3 RGBD Camera x3, LiDAR x2, IMU Host Interface Ethernet (Direct connection to host PC) Ethernet (WI-FI router up to 1Gbps) Internal Communications RS-485 RS-485 Communication Baudrate 4 Mbps 4 Mbps Computer NVIDIA Jetson AGX Orin 32GB NVIDIA Jatson AGX Orin 32GB Software ROS 2 Support, Python, C++, Web UI ROS 2 Support, Python, C++, Web UI Leader Properties FF-LG2 Dimensions (WxDxH) 598x146x705 (mm)23.5x27.8x27.8 (inch) Weight 3 kg (6.6 lb) Degrees of Freedom Total: 22 DOF- Arm: 7 DOF x2- Gripper: 1 DOF x2- Joystick: 3 DOF x2 Exterior Materials Aluminum, Plastic Internal Communications TTL Communication Baudrate 4 Mbps Software ROS 2 Support, Python, C++ Links e-Manual A Humanoid robot paltform optimized for Physical AI. Expand the boundaries of AI by interacting with the real world.
DYNAMIXEL Control Controls high-quality DYNAMIXELs with a single integrated protocol to simplify and precisely implement the overall system's motion. Expandable Hand Comes with a standard 2-finger gripper, which can be replaced with various end-effectors depending on the purpose to ensure high manipulability. Swerve Drive Applies an omnidirectional swerve drive, allowing for free movement and high reliability even in narrow spaces. Exoskeleton Leader Through an intuitive leader-follower system structure, it can collect and efficiently use precise motion data in real time. End-to-End Pipeline Provides an end-to-end pipeline that covers the entire Al development process, from data collection and training to execution. Built-in Battery Equipped with a built-in battery, it can operate continuously for up to 6 hours without an external power source, minimizing constraints on work time and space. Open-Source Platform Offers all hardware, software, and simulation files as open-source, allowing anyone to freely use them for research and development. Simulation Integration Maximizes development efficiency by perfectly integrating with major simulators like Isaac Sim/Lab, MuJoCo, and Gazebo to pre-verify the robot's movements. Specification Follower Properties FFW-BG2(Basic Type) FFW-SG2(Swerve Type) Dimensions (WxDxH) 604x564x1607 mm23.8x22.2x63.2 (inch) 604x602x1623 mm23.8x23.7x63.8 (inch) Weight 85 kg (187 lb) 90 kg (198 lb) Degrees of Freedom Total: 19 DOF- Arm: 7 DOF x2- Gripper: 1 DOF x2- Head: 2 DOF x1- Lift: 1 DOF x1 Total: 25 DOF- Arm: 7 DOF x2- Gripper: 1 DOF x2- Head: 2 DOF x1- Lift: 1 DOF x1- Mobile: 6DOF Arm Reach 641 mm (to wrist) + hand 641 mm (to wrist) + hand Arm Payload(Nominal) 3.0 kg (single arm)6.0 kg (dual arm) 3.0 kg (single arm)6.0 kg (dual arm) Arm Payload(Peak) 5.0 kg (single arm)10.0 kg (dual arm) 5.0 kg (single arm)10.0 kg (dual arm) Gripper/Hand RH-P12-RN RH-P12-RN Mobile Type None Swerve Drive Mobile Operation Velocity None 1.5 m/s Power Type AC powered via SMPS Battery & AC powered via SMPS Power Specifications 24VDC, 80A, 1920W 25V, 80 Ah (2040Wh) & 24VDC, 80A, 1920W Ambient Operating Temperature 0 ~ 40ºC 0 ~ 40ºC Exterior Materials Aluminum, Plastic Aluminum, Plastic Sensor RGBD Camera x3 RGBD Camera x3, LiDAR x2, IMU Host Interface Ethernet (Direct connection to host PC) Ethernet (WI-FI router up to 1Gbps) Internal Communications RS-485 RS-485 Communication Baudrate 4 Mbps 4 Mbps Computer NVIDIA Jetson AGX Orin 32GB NVIDIA Jatson AGX Orin 32GB Software ROS 2 Support, Python, C++, Web UI ROS 2 Support, Python, C++, Web UI Leader Properties FF-LG2 Dimensions (WxDxH) 598x146x705 (mm)23.5x27.8x27.8 (inch) Weight 3 kg (6.6 lb) Degrees of Freedom Total: 22 DOF- Arm: 7 DOF x2- Gripper: 1 DOF x2- Joystick: 3 DOF x2 Exterior Materials Aluminum, Plastic Internal Communications TTL Communication Baudrate 4 Mbps Software ROS 2 Support, Python, C++ Links e-Manual
价格历史
每天显示一个数据点,按观测日期计算平均值。
金额单位:USD
每天的平均价格根据该 UTC 日期记录的所有报价计算。
Robotis
£34,986.54
Robotis
1,429.95 €
Robotis
490.95 €
Robotis
£1,055.58
Robotis
£8,822.56

Robotis
$1,207.50

Robotis
$2,759.89

Robotis
$13,764.35

Robotis
$474.38

Unitree
$53,900

Unitree
$54,900

Unitree
$51,900
🍪 Cookie 偏好设置
我们使用 Cookie 来衡量性能。 隐私政策