每日平均价格
金额单位:USD
描述
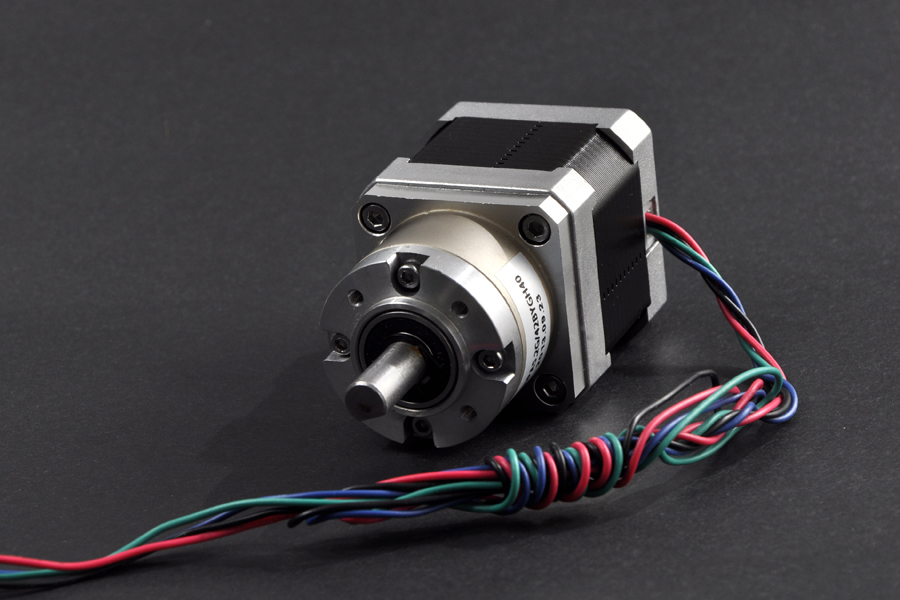
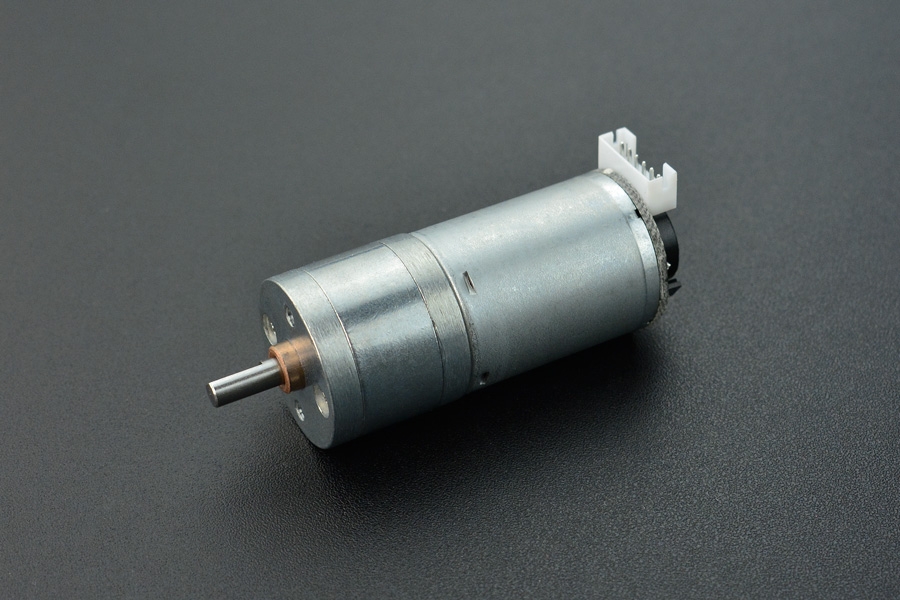
INTRODUCTION This bipolar stepper motor with planet gear box (gear ratio: 5.18) uses a standard 8mm-diameter D type output shaft, and has a 1.8° step angle (200 steps/revolution). Each phase draws 1.6 A at 2.78 V, allowing for a holding torque of 18kg-cm (176N-cm). The motor has a body dimension of 42mm square and 40mm in length, while the planet gear box is 36mm in diameter and 27mm in length. The motor has four color-coded wires terminated with bare leads: black and green connect to one coil; red and blue connect to the other. It can be easily mounted with 4 M3 threaded holes and can be controlled with the Dual Bipolar Stepper Motor Shield for Arduino (A4988). Notice: please carefully confirm techical details (torque, dimension, mounting, etc) for your project(s) before purchasing. APPLICATIONS Printer 3D Printer CNC Robotics Linear Actuators SPECIFICATION Model No:36PA5.2G-42BYG40-160-4A Step Angle (degrees) :1.8 2 Phase Rated Current : [email protected] /* */ ,0.37A@12V Holding Torque : 3.5kg*cm (48.6 oz/in) Hold Torque with Gearbox: 18kg·cm (176N·cm) Gear Ratio: 5.18:1 Winding resistance: 1.5 Ω Winding inductance: 2.5 mH Max flux linkage: 1.8 Vs Step Angle Accuracy : ±5% (full step, no load) Resistance Accuracy: ±10% Inductance Accuracy: ±20% Temperature Rise: 80°C Max.(rated current,2 phase on) Ambient Temperature: -20°C~+50°C Insulation Class: B Dimension: 42×42×40mm Mounting: 4 x M3 Mounting Hole Diameter:Φ28 DOCUMENTS Mechanic Datasheet SHIPPING LIST Stepper Motor with Planet Gear Box ×1 Bipolar Stepper Motor with Planet Gear Box (18kg.cm). This bipolar stepper motor with planet gear box (gear ratio: 5.18) uses a standard 8mm-diameter D type output shaft, and has a 1.8° step angle (200 steps/revolution). Each phase draws 1.6 A at 2.78 V, allowing for a holding torque of 18kg-cm (176N-cm). The motor has a body dimension of 42mm square and 40mm in length, while the planet gear box is 36mm in diameter and 27mm in length.
INTRODUCTION This bipolar stepper motor with planet gear box (gear ratio: 5.18) uses a standard 8mm-diameter D type output shaft, and has a 1.8° step angle (200 steps/revolution). Each phase draws 1.6 A at 2.78 V, allowing for a holding torque of 18kg-cm (176N-cm). The motor has a body dimension of 42mm square and 40mm in length, while the planet gear box is 36mm in diameter and 27mm in length. The motor has four color-coded wires terminated with bare leads: black and green connect to one coil; red and blue connect to the other. It can be easily mounted with 4 M3 threaded holes and can be controlled with the Dual Bipolar Stepper Motor Shield for Arduino (A4988). Notice: please carefully confirm techical details (torque, dimension, mounting, etc) for your project(s) before purchasing. APPLICATIONS Printer 3D Printer CNC Robotics Linear Actuators SPECIFICATION Model No:36PA5.2G-42BYG40-160-4A Step Angle (degrees) :1.8 2 Phase Rated Current : [email protected] /* */ ,0.37A@12V Holding Torque : 3.5kg*cm (48.6 oz/in) Hold Torque with Gearbox: 18kg·cm (176N·cm) Gear Ratio: 5.18:1 Winding resistance: 1.5 Ω Winding inductance: 2.5 mH Max flux linkage: 1.8 Vs Step Angle Accuracy : ±5% (full step, no load) Resistance Accuracy: ±10% Inductance Accuracy: ±20% Temperature Rise: 80°C Max.(rated current,2 phase on) Ambient Temperature: -20°C~+50°C Insulation Class: B Dimension: 42×42×40mm Mounting: 4 x M3 Mounting Hole Diameter:Φ28 DOCUMENTS Mechanic Datasheet SHIPPING LIST Stepper Motor with Planet Gear Box ×1
价格历史
每天显示一个数据点,按观测日期计算平均值。
金额单位:USD
每天的平均价格根据该 UTC 日期记录的所有报价计算。

RoboSavvy
£30.35

RoboSavvy
£28.92

RoboSavvy
£34.50
RoboSavvy
£31.03
RoboSavvy
£34.42
RoboSavvy
£31.92

RoboSavvy
£34.43
RoboSavvy
£30.75
RoboSavvy
£24.67

RoboSavvy
£22.48

RoboSavvy
£24.65

RoboSavvy
£24.69
🍪 Cookie 偏好设置
我们使用 Cookie 来衡量性能。 隐私政策