Dagligt genomsnittspris
Belopp i USD
Beskrivning
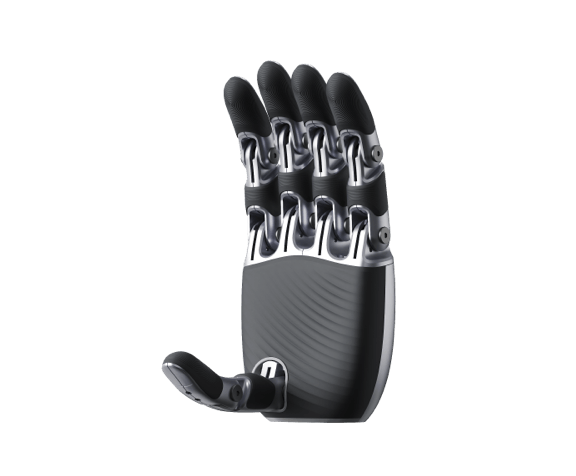
Unitree Dex2/5 Gala-style tendon-driven dexterous hand, precise control for unbeatable strength. Lightweight Compact Reliable Ultra-long fatigue life for greater durability The entire hand has passed over 100000 fatigue cycles Ensuring stable and reliable long-term operation Rugged impact resistance, impervious to knocks and bumps Completed over 100 drop tests Superior robust design ensures the dexterous hand is no longer fragile Hidden internal wiring Compatible with G1/R1 models Let the "meridians" run beneath the "skin" Lightweight and compact Specifications Weight 365g Size 151mm x 70mm x 63mm [1] Degrees of Freedom Thumb×1 Index Finger、Middle Finger、Ring Finger、Little Finger:share one DOF Transmission Mechanism Gear‑tendon rope drive Angle of Joint Thumb Joint 0:0~42° Thumb Joint 1:0~105° Four-Finger Joint0:0~88° Four-Finger Joint1:0~105° Minimum fist clench time 0.5 s Minimum grip diameter 8mm Fingertip strength Thumb:15N Index finger, middle finger, ring finger, little finger: total 15 N Working Voltage 24V-60V Static Current [email protected] Maximum Current [email protected] Communication Interface RS485 Working Temperature Range -20℃ ~ 60℃ Load Conditions ( Palm Facing Down At Room Temperature, Grasping A 5cm Round Hard Object) The Maximum Weight is 1.5kg Load Conditions (Palm Facing Left At Room Temperature, Grasping A 5cm Round Hard Object) The Maximum Weight is 1.5kg Communication Rate 1000Hz Perceptual Feedback Joint Mode, Joint Position, Joint Velocity, Joint Torque, Joint Temperature, Voltage and Current Control Feedback Joint Mode, Joint Position, Joint Velocity, Joint Torque, Joint Stiffness Coefficient, Joint Damping Coefficient [1] It is the size of the dexterous hand in flat state. [2] All parameters listed above may vary in different application scenarios or with different model configurations. Please refer to your specific use case. [3] The product appearance is subject to change. Please refer to the final product. [4] This product is a civilian robot. We kindly request that all users refrain from making any dangerous modifications or using the robot in a hazardous manner. [5] Please visit Unitree Robotics Website for more related terms and policies, and comply with local laws and regulations. Gala-style tendon-driven dexterous hand, precise control for unbeatable strength. 10‑DOF (2 actuated) 5‑finger tendon‑driven dexterous hand Compatible with G1 and R1 (hidden internal cable routing dedicated fit)
Unitree Dex2/5 Gala-style tendon-driven dexterous hand, precise control for unbeatable strength. Lightweight Compact Reliable Ultra-long fatigue life for greater durability The entire hand has passed over 100000 fatigue cycles Ensuring stable and reliable long-term operation Rugged impact resistance, impervious to knocks and bumps Completed over 100 drop tests Superior robust design ensures the dexterous hand is no longer fragile Hidden internal wiring Compatible with G1/R1 models Let the "meridians" run beneath the "skin" Lightweight and compact Specifications Weight 365g Size 151mm x 70mm x 63mm [1] Degrees of Freedom Thumb×1 Index Finger、Middle Finger、Ring Finger、Little Finger:share one DOF Transmission Mechanism Gear‑tendon rope drive Angle of Joint Thumb Joint 0:0~42° Thumb Joint 1:0~105° Four-Finger Joint0:0~88° Four-Finger Joint1:0~105° Minimum fist clench time 0.5 s Minimum grip diameter 8mm Fingertip strength Thumb:15N Index finger, middle finger, ring finger, little finger: total 15 N Working Voltage 24V-60V Static Current [email protected] Maximum Current [email protected] Communication Interface RS485 Working Temperature Range -20℃ ~ 60℃ Load Conditions ( Palm Facing Down At Room Temperature, Grasping A 5cm Round Hard Object) The Maximum Weight is 1.5kg Load Conditions (Palm Facing Left At Room Temperature, Grasping A 5cm Round Hard Object) The Maximum Weight is 1.5kg Communication Rate 1000Hz Perceptual Feedback Joint Mode, Joint Position, Joint Velocity, Joint Torque, Joint Temperature, Voltage and Current Control Feedback Joint Mode, Joint Position, Joint Velocity, Joint Torque, Joint Stiffness Coefficient, Joint Damping Coefficient [1] It is the size of the dexterous hand in flat state. [2] All parameters listed above may vary in different application scenarios or with different model configurations. Please refer to your specific use case. [3] The product appearance is subject to change. Please refer to the final product. [4] This product is a civilian robot. We kindly request that all users refrain from making any dangerous modifications or using the robot in a hazardous manner. [5] Please visit Unitree Robotics Website for more related terms and policies, and comply with local laws and regulations.
Prishistorik
En datapunkt per dag, beräknad utifrån observationsdatumet.
Belopp i USD
Genomsnittet beräknas per UTC-dygn utifrån alla registrerade erbjudandepriser.

Unitree
$1 490

Unitree
$1 490

Unitree
$6 500

Unitree
$8 680

Unitree
$7 800

Unitree
$10 000

Unitree
$25 000

Unitree
$25 000

Unitree
$7 680
Unitree
$8 680

Unitree
$16 450

Unitree
$18 950
🍪 Cookieinställningar
Vi använder cookies för att mäta prestanda. Integritetspolicy