Dagligt genomsnittspris
Belopp i USD
Beskrivning
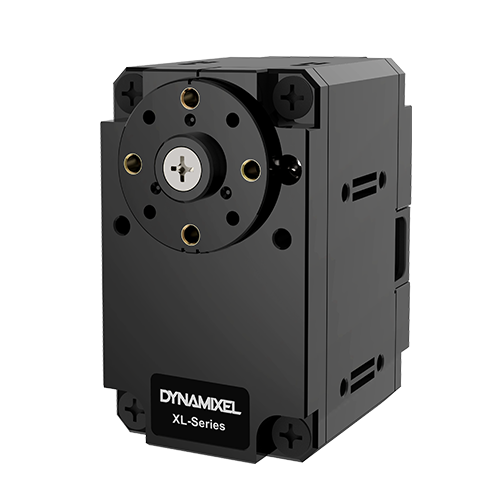
The DYNAMIXEL X-Series is a new line-up of high performance networked actuators. The Dynamixel XL series adopts new features that allow 360 degrees control mode with its contactless magnetic encoder and hollow back case assembly structure. The XL series has the same mechanical structure as the XM430 and XH430 and is compatible with the respective models. Improved Torque, Compact Design Enhanced Durability and Expandability Hollow Back Case Minimizes Cable Stress (3-Way Wiring) Frames Directly Screwed onto the Case (No Nuts Needed) 6 Operating Modes Profile Control for Smooth Motion Planning Energy Efficient with Improved Operation Time Package Contents Item Quantity XL430-W250-T Servo 1 HN11-N101 Horn (pre assembled) 1 Robot Cable-X3P 180mm Cable 1 M2.6x5 Tap bolt 5 M2x5 bolt 5 Spacer Ring 5 Hardware Specifications Model Name XL430-W250-T Weight (g) 57.2 Dimension (mm) 28.5 x 46.5 x 34 Gear Ratio 258.5 : 1 Operation Voltage (V) 9.0 11.1 12.0 Stall Torque (N.m) 1.0 1.4 1.5 Stall Current (A) 1.0 1.3 1.4 No Load Speed (RPM) 47 57 61 MCU ST CORTEX-M3 (STM32F103C8 @ 72MHZ,32BIT) Position Sensor Contactless absolute encoder (12BIT,360°) by AMS Motor Cored Resolution 0.088° x 4,096 steps Operating Range Velocity Control Mode : Endless turn Position Control Mode : 360[deg] Extended Control Mode : ±256[rev] PWM Control Mode : Endless turn Input Voltage (V) 6.5~12.0V (Recommended voltage : 11.1V) Operating Temperature -5°C ~ 72°C Command Signal Digital Packet Protocol Type Half duplex Asynchronous Serial Communication (8bit,1stop, No Parity) Link (physical) TTL Level Multi Drop Bus ID 253 ID (0~252) Baud Rate 9600 bps ~ 4.5 Mbps Feedback Position, Velocity, Load, Realtime tick, Trajectory, Temperature, Input Voltage, etc. Material Case : Engineering Plastic Gear : Engineering Plastic Standby current (mA) 52 Default Settings ID: 1 Baud Rate: 57600bps *Please make necessary modifications to ID, baud rate, etc. after purchase. Different Cabling Setup Links and Downloads Frame, Horn, Bearing Compatible Chart : Click HereController Compatibility Chart : Click HereDownload Drawing : Click HereDynamixel SDK : Click HereOpenCM IDE : Click HereSoftware RoboPlus (R+) : Click HereLink to e-Manual : Click Here Must Read! The DYNAMIXEL X-Series adopted a new gold-plated JST connector for secure and reliable communication.For more information, please see the [DYNAMIXEL Connector Standard] page on the e-Manual.To control DYNAMIXEL X-Series actuators via OpenCM or USB2Dynamixel, please use the JST-Molex Convertible Cable enclosed in the package. However, the Molex-JST convertible cable is NOT included in the XL430 model. Please purchase a convertible cable when using a controller and interface that supports the JST connector. Controller / Interface Board Connectors Cable Dynamixel X Connectors Communication OpenCM+485 Expansion Board USB2Dynamixel Molex (3P, 4P) Robot Cable-X3P 180mm (Convertible) JST-3P TTL OpenCR1.0 U2D2 JST (3P, 4P) Robot Cable -X3P (by length) JST-3P TTL OpenCM+485 Expansion Board USB2Dynamixel Molex (3P, 4P) Robot Cable -X3P 180mm (Convertible) JST-4P RS-485 OpenCR1.0 U2D2 JST (3P, 4P) Robot Cable -X3P (by length) JST-4P RS-485
The DYNAMIXEL X-Series is a new line-up of high performance networked actuators. The Dynamixel XL series adopts new features that allow 360 degrees control mode with its contactless magnetic encoder and hollow back case assembly structure. The XL series has the same mechanical structure as the XM430 and XH430 and is compatible with the respective models. Improved Torque, Compact Design Enhanced Durability and Expandability Hollow Back Case Minimizes Cable Stress (3-Way Wiring) Frames Directly Screwed onto the Case (No Nuts Needed) 6 Operating Modes Profile Control for Smooth Motion Planning Energy Efficient with Improved Operation Time Package Contents Item Quantity XL430-W250-T Servo 1 HN11-N101 Horn (pre assembled) 1 Robot Cable-X3P 180mm Cable 1 M2.6x5 Tap bolt 5 M2x5 bolt 5 Spacer Ring 5 Hardware Specifications Model Name XL430-W250-T Weight (g) 57.2 Dimension (mm) 28.5 x 46.5 x 34 Gear Ratio 258.5 : 1 Operation Voltage (V) 9.0 11.1 12.0 Stall Torque (N.m) 1.0 1.4 1.5 Stall Current (A) 1.0 1.3 1.4 No Load Speed (RPM) 47 57 61 MCU ST CORTEX-M3 (STM32F103C8 @ 72MHZ,32BIT) Position Sensor Contactless absolute encoder (12BIT,360°) by AMS Motor Cored Resolution 0.088° x 4,096 steps Operating Range Velocity Control Mode : Endless turn Position Control Mode : 360[deg] Extended Control Mode : ±256[rev] PWM Control Mode : Endless turn Input Voltage (V) 6.5~12.0V (Recommended voltage : 11.1V) Operating Temperature -5°C ~ 72°C Command Signal Digital Packet Protocol Type Half duplex Asynchronous Serial Communication (8bit,1stop, No Parity) Link (physical) TTL Level Multi Drop Bus ID 253 ID (0~252) Baud Rate 9600 bps ~ 4.5 Mbps Feedback Position, Velocity, Load, Realtime tick, Trajectory, Temperature, Input Voltage, etc. Material Case : Engineering Plastic Gear : Engineering Plastic Standby current (mA) 52 Default Settings ID: 1 Baud Rate: 57600bps *Please make necessary modifications to ID, baud rate, etc. after purchase. Different Cabling Setup Links and Downloads Frame, Horn, Bearing Compatible Chart : Click HereController Compatibility Chart : Click HereDownload Drawing : Click HereDynamixel SDK : Click HereOpenCM IDE : Click HereSoftware RoboPlus (R+) : Click HereLink to e-Manual : Click Here Must Read! The DYNAMIXEL X-Series adopted a new gold-plated JST connector for secure and reliable communication.For more information, please see the [DYNAMIXEL Connector Standard] page on the e-Manual.To control DYNAMIXEL X-Series actuators via OpenCM or USB2Dynamixel, please use the JST-Molex Convertible Cable enclosed in the package. However, the Molex-JST convertible cable is NOT included in the XL430 model. Please purchase a convertible cable when using a controller and interface that supports the JST connector. Controller / Interface Board Connectors Cable Dynamixel X Connectors Communication OpenCM+485 Expansion Board USB2Dynamixel Molex (3P, 4P) Robot Cable-X3P 180mm (Convertible) JST-3P TTL OpenCR1.0 U2D2 JST (3P, 4P) Robot Cable -X3P (by length) JST-3P TTL OpenCM+485 Expansion Board USB2Dynamixel Molex (3P, 4P) Robot Cable -X3P 180mm (Convertible) JST-4P RS-485 OpenCR1.0 U2D2 JST (3P, 4P) Robot Cable -X3P (by length) JST-4P RS-485
Prishistorik
En datapunkt per dag, beräknad utifrån observationsdatumet.
Belopp i USD
Genomsnittet beräknas per UTC-dygn utifrån alla registrerade erbjudandepriser.

Robotis
$27,50
Robotis
36 €
Robotis
£22,67
Robotis
£22,25
Robotis
£20,50

Robotis
$23,23

Robotis
$21,85

Robotis
$20,47

Robotis
$24,73

Robotis
$23,23

Robotis
$21,85

Robotis
$21,85
🍪 Cookieinställningar
Vi använder cookies för att mäta prestanda. Integritetspolicy