Dagligt genomsnittspris
Belopp i USD
Beskrivning
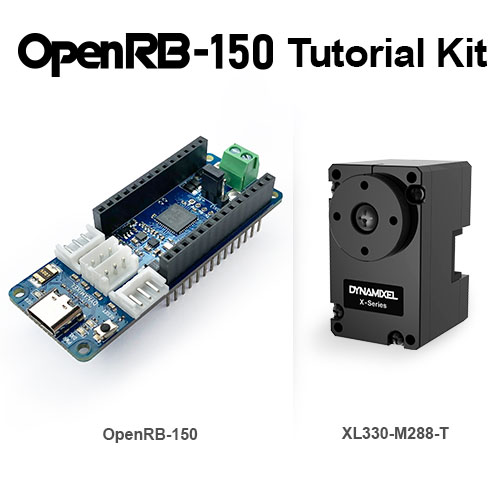
Features * OpenRB-150 Tutorial Kit is a product consisting of OpenRB-150 and XL330-M288-T. * Product Name Change on May 20, 2025 (Previous Name: OpenRB-150 Starter Kit) * Batteries, USB Cables, and Power Cables are not included. OpenRB-150 Has the same pinout and form factor as the Arduino MKR, and supports programming using the Arduino IDE. XL330-M288-T Compact and lightweight DYNAMIXEL. Supports RC protocol & 6 control modes including Current Control and Current Based Position Control. Package Components Product Name Quantity Product Description OpenRB-150 1 DYNAMIXEL Controller XL330-M288-T 1 DYNAMIXEL Robot Cable-X3P 180mm 1 TTL 3P cable (JST-JST) PHS M2x6 TAP 6 Bolts for Horn PHS M2x8 TAP 10 Bolts for Frame Assembly H/W Specifications OpenRB-150 Category Specifications MCUSAMD21 Cortex-M0+ 32bit low power ARM® Operation Voltage5.0V (USB 3.0)3.7V ~ 12.6V (VIN or Terminal) Operation Temperature-40℃ ~ 85℃ Allowable Current3.0A (DYNAMIXEL Port) Connector TypeUSB C-Type, Terminal Block DYNAMIXEL Port (TTL)JST B3B-EH-A(2), JST S3B-EH-A(2) [Max 1Mbps] Dimensions66 × 25 mm Weight13g XL330-M288-T Category Item Specifications MCU Cortex-M0+ (64 [MHz], 32bit) Input Voltage Min. [V] 3.7 Recommended [V] 5.0 Max. [V] 6.0 Performance Characteristics Voltage [V] 5.0 Stall Torque [N·m] 0.52 Stall Current [A] 1.5 No Load Speed [rpm] 104.0 No Load Current [A] 0.15 Continuous Operation Voltage / Torque / Speed / Current – Torque [N·m] – Speed [rpm] – Current [A] – Resolution Resolution [deg/pulse] 0.0879 Step [pulse/rev] 4 Angle [degree] 360 Position Sensor Contactless absolute encoder (12Bit, 360 [deg])Maker: ams (www.ams.com), Part No: AS5601 Operating Temperature Min. [°C] -5 Max. [°C] 60 Motor Cored Baud Rate Min. [bps] 9,600 Max. [bps] 4,000,000 Control Algorithm PID Gear Type Spur Gear Material Engineering Plastic Case Material Engineering Plastic Dimensions (W×H×D) 20 × 34 × 26 mm / 0.78 × 1.33 × 1.02 in Weight 18.00 g / 0.63 oz Gear Ratio 288.4 : 1 Command Signal Digital Packet Communication Half duplex Asynchronous Serial Communication (8bit, 1stop, No Parity) Physical Link TTL Level Multi Drop Bus ID 0 ~ 252 Feedback Position, Velocity, Current, Realtime tick, Trajectory, Temperature, Input Voltage, etc. Protocol Protocol 2.0 Experimental S.BUS, iBUS, RC-PWM Operating Mode / Angle Current Control: Endless turnVelocity Control: Endless turnPosition Control: 360°Extended Position Control: ±256 revCurrent-based Position Control: ±256 revPWM Control: Endless turn Output [W] – Standby Current [mA] 15 How to Supply Power (3 Methods) Power can be supplied to the OpenRB-150 in three ways depending on the voltage and serial communication type of DYNAMIXEL. 1. 5V TTL DYNAMIXEL 2. 12V TTL DYNAMIXEL 3. 12V RS-485 DYNAMIXEL Compatible DYNAMIXEL The OpenRB-150 is compatible with all DYNAMIXEL models. However, additional equipment is required for use with the following types of DYNAMIXEL. 1. RS-485 The DYNAMIXEL Communication Bridge is required to convert signals. 2. 24V A separate power supply is required. 3. DYNAMIXEL-AX and MX Series (Molex connectors) A Molex-JST convertible cable is required. Caution 1. The Arduino MKR board is not included in the package. 2. When supplying power, please check the jumper settings. (USB C Type, VIN, Terminal VIN) 3. Please do not charge the battery when it is connected to the controller. 4. Please check the power input terminal before connecting it to the controller. Link e-Manual Drawing Board Manager(GitHub) DYNAMIXEL2Arduino Library [Video] DYNAMIXEL Quick Start Guide with Arduino [Video] DYNAMIXEL Quick Start Guide with DYNAMIXEL Wizard 2.0 Features OpenRB-150 Tutorial Kit is a product consisting of OpenRB-150 and XL330-M288-T. Product Name Change on May 20, 2025 (Previous Name: OpenRB-150 Starter Kit) Batteries, USB Cables, and Power Cables are not included.
Features * OpenRB-150 Tutorial Kit is a product consisting of OpenRB-150 and XL330-M288-T. * Product Name Change on May 20, 2025 (Previous Name: OpenRB-150 Starter Kit) * Batteries, USB Cables, and Power Cables are not included. OpenRB-150 Has the same pinout and form factor as the Arduino MKR, and supports programming using the Arduino IDE. XL330-M288-T Compact and lightweight DYNAMIXEL. Supports RC protocol & 6 control modes including Current Control and Current Based Position Control. Package Components Product Name Quantity Product Description OpenRB-150 1 DYNAMIXEL Controller XL330-M288-T 1 DYNAMIXEL Robot Cable-X3P 180mm 1 TTL 3P cable (JST-JST) PHS M2x6 TAP 6 Bolts for Horn PHS M2x8 TAP 10 Bolts for Frame Assembly H/W Specifications OpenRB-150 Category Specifications MCUSAMD21 Cortex-M0+ 32bit low power ARM® Operation Voltage5.0V (USB 3.0)3.7V ~ 12.6V (VIN or Terminal) Operation Temperature-40℃ ~ 85℃ Allowable Current3.0A (DYNAMIXEL Port) Connector TypeUSB C-Type, Terminal Block DYNAMIXEL Port (TTL)JST B3B-EH-A(2), JST S3B-EH-A(2) [Max 1Mbps] Dimensions66 × 25 mm Weight13g XL330-M288-T Category Item Specifications MCU Cortex-M0+ (64 [MHz], 32bit) Input Voltage Min. [V] 3.7 Recommended [V] 5.0 Max. [V] 6.0 Performance Characteristics Voltage [V] 5.0 Stall Torque [N·m] 0.52 Stall Current [A] 1.5 No Load Speed [rpm] 104.0 No Load Current [A] 0.15 Continuous Operation Voltage / Torque / Speed / Current – Torque [N·m] – Speed [rpm] – Current [A] – Resolution Resolution [deg/pulse] 0.0879 Step [pulse/rev] 4 Angle [degree] 360 Position Sensor Contactless absolute encoder (12Bit, 360 [deg])Maker: ams (www.ams.com), Part No: AS5601 Operating Temperature Min. [°C] -5 Max. [°C] 60 Motor Cored Baud Rate Min. [bps] 9,600 Max. [bps] 4,000,000 Control Algorithm PID Gear Type Spur Gear Material Engineering Plastic Case Material Engineering Plastic Dimensions (W×H×D) 20 × 34 × 26 mm / 0.78 × 1.33 × 1.02 in Weight 18.00 g / 0.63 oz Gear Ratio 288.4 : 1 Command Signal Digital Packet Communication Half duplex Asynchronous Serial Communication (8bit, 1stop, No Parity) Physical Link TTL Level Multi Drop Bus ID 0 ~ 252 Feedback Position, Velocity, Current, Realtime tick, Trajectory, Temperature, Input Voltage, etc. Protocol Protocol 2.0 Experimental S.BUS, iBUS, RC-PWM Operating Mode / Angle Current Control: Endless turnVelocity Control: Endless turnPosition Control: 360°Extended Position Control: ±256 revCurrent-based Position Control: ±256 revPWM Control: Endless turn Output [W] – Standby Current [mA] 15 How to Supply Power (3 Methods) Power can be supplied to the OpenRB-150 in three ways depending on the voltage and serial communication type of DYNAMIXEL. 1. 5V TTL DYNAMIXEL 2. 12V TTL DYNAMIXEL 3. 12V RS-485 DYNAMIXEL Compatible DYNAMIXEL The OpenRB-150 is compatible with all DYNAMIXEL models. However, additional equipment is required for use with the following types of DYNAMIXEL. 1. RS-485 The DYNAMIXEL Communication Bridge is required to convert signals. 2. 24V A separate power supply is required. 3. DYNAMIXEL-AX and MX Series (Molex connectors) A Molex-JST convertible cable is required. Caution 1. The Arduino MKR board is not included in the package. 2. When supplying power, please check the jumper settings. (USB C Type, VIN, Terminal VIN) 3. Please do not charge the battery when it is connected to the controller. 4. Please check the power input terminal before connecting it to the controller. Link e-Manual Drawing Board Manager(GitHub) DYNAMIXEL2Arduino Library [Video] DYNAMIXEL Quick Start Guide with Arduino [Video] DYNAMIXEL Quick Start Guide with DYNAMIXEL Wizard 2.0
Prishistorik
En datapunkt per dag, beräknad utifrån observationsdatumet.
Belopp i USD
Genomsnittet beräknas per UTC-dygn utifrån alla registrerade erbjudandepriser.
Robotis
36 €
Robotis
£35
Robotis
£32,08
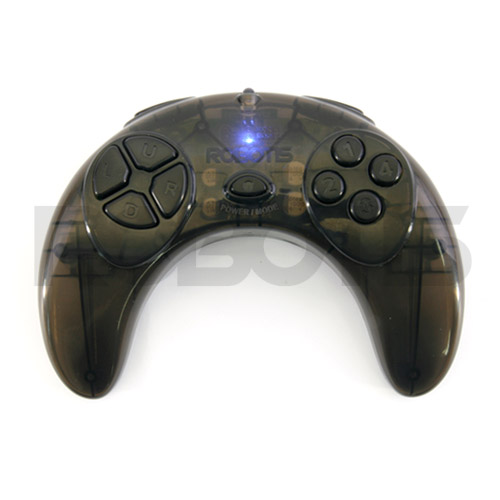
Robotis
£37,75
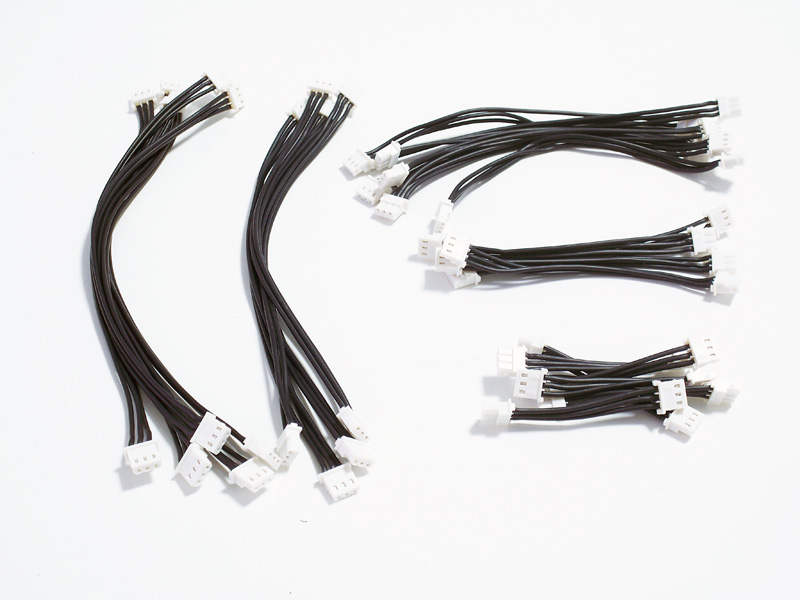
Robotis
£32,33
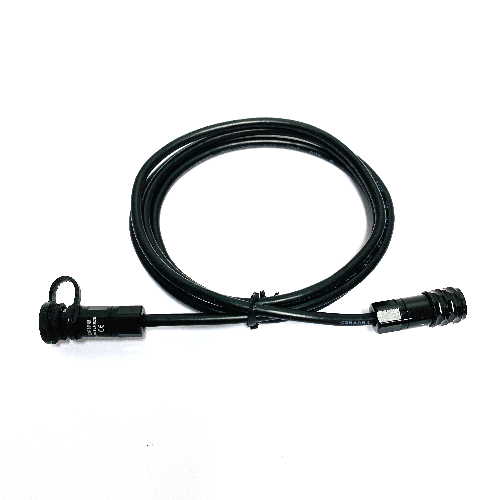
Robotis
£36,42

Robotis
$30,94

Robotis
$32,89

Robotis
$32,89
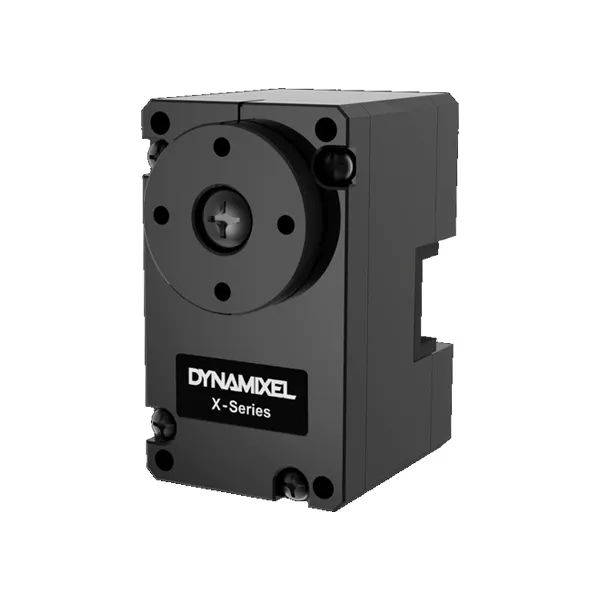
Robotis
40,20 €
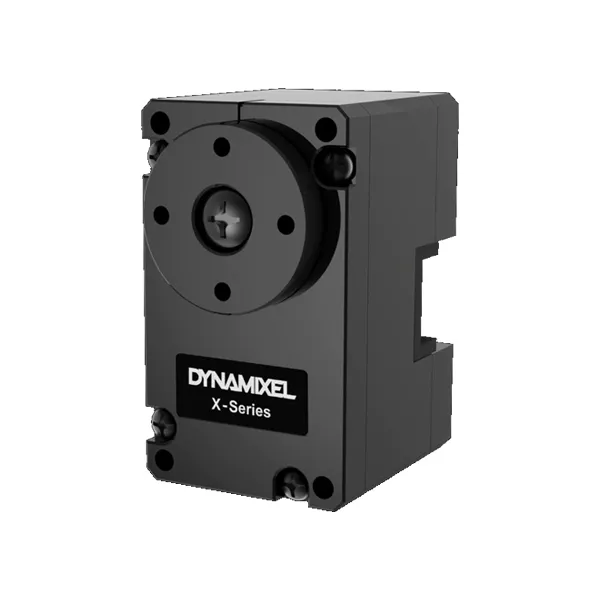
Robotis
40,20 €
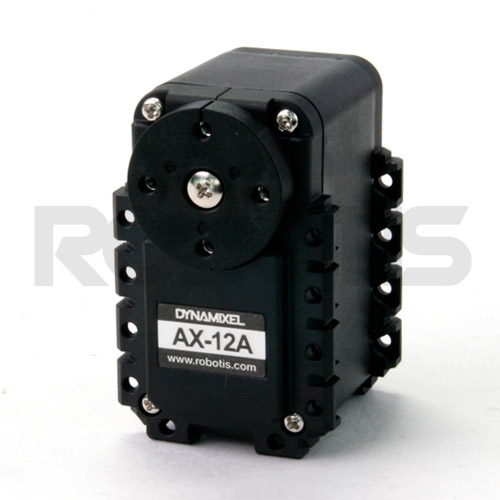
Robotis
£38,56
🍪 Cookieinställningar
Vi använder cookies för att mäta prestanda. Integritetspolicy