Raziskovalni članki

Poljudni povzetki najnovejših raziskav o robotiki — humanoidni roboti, štirinožni roboti, industrijska avtomatizacija in umetna inteligenca.
499 članki
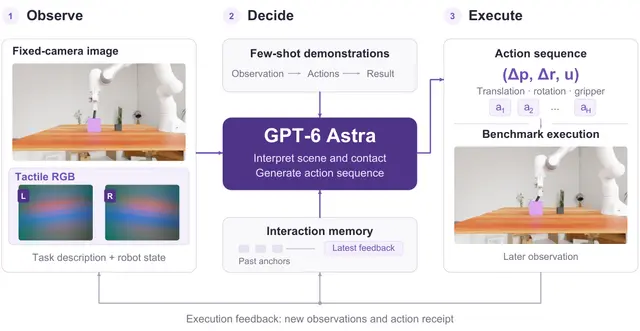
How GPT-6 Astra Uses Vision and Touch for Tricky Robot Tasks
Roboticspred 20 dnevi

How GPT-6 Astra Uses Vision and Touch for Tricky Robot Tasks

Astra combines visual and tactile images for simulated robot manipulation, but contact diagnosis and precise corrections remain challenging.

Chen Yang, Linzhe Shi, Hang Zhang, Mu Xu +2

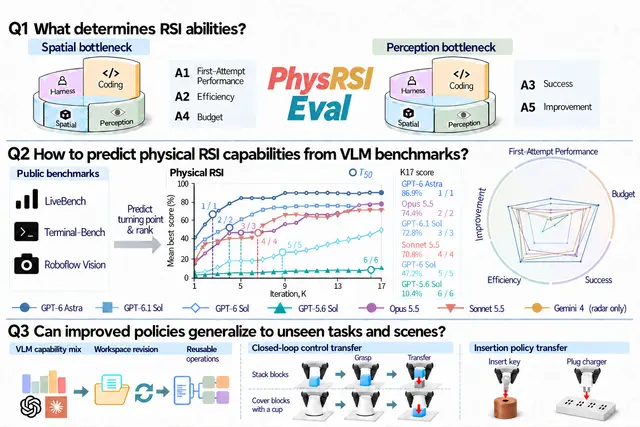
How LLMs Improve Robot Manipulation Through Physical Feedback and Repeated Practice
AIpred 20 dnevi

How LLMs Improve Robot Manipulation Through Physical Feedback and Repeated Practice
Frontier LLM agents demonstrate remarkable capabilities in directly generating actions for robotic manipulation.

Zekai Li, Jiayi Yu, Jinlu Zhang +8

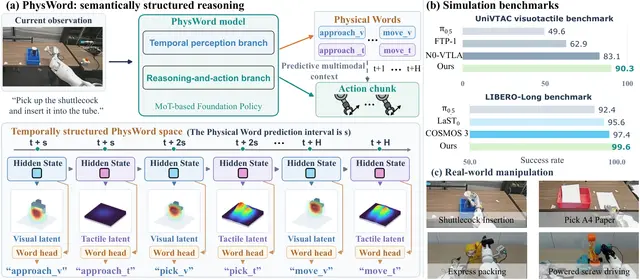
Robot Words Help Manipulators Predict Motion, Touch, and Reuse Actions Better
Roboticspred 20 dnevi

Robot Words Help Manipulators Predict Motion, Touch, and Reuse Actions Better
PhysWord helps robot manipulators predict future motion and contact using reusable visual and tactile action representations.

Jiaming Liu, Xinghao Zhu, Yiming Zhang +8

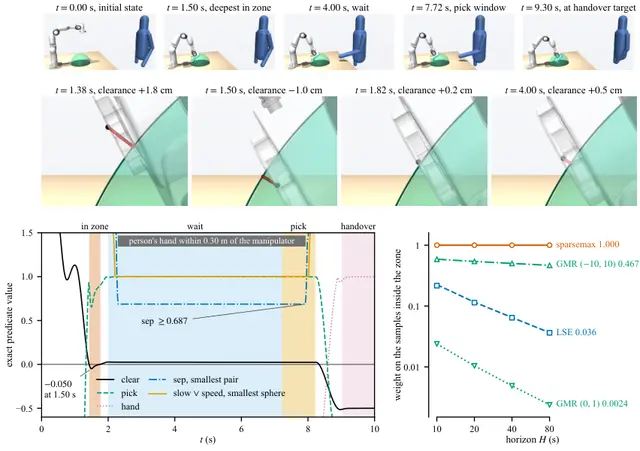
SparseMax-dSTL Enables Sound Temporal Logic Trajectory Optimization
Roboticspred 21 dnevi

SparseMax-dSTL Enables Sound Temporal Logic Trajectory Optimization

Sai Sandeep Damera, Ryan Matheu, John S. Baras +1

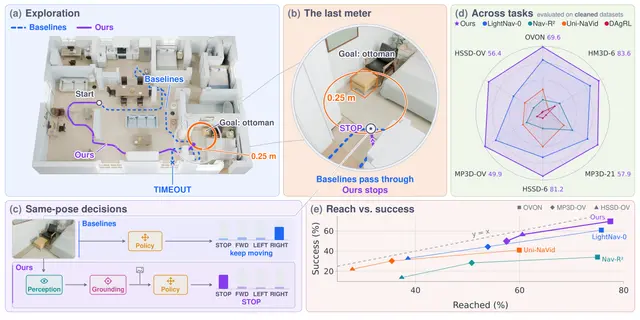
Why Robots Reach Navigation Goals but Still Fail to Stop Correctly
Roboticspred 21 dnevi

Why Robots Reach Navigation Goals but Still Fail to Stop Correctly

Xinhao Liu, Yunsheng Tian, Yuheng Qiu +4

Precise Proprioceptive Sim-to-Real Robot Assembly for Diverse Pegs, Gears, and Nuts
Roboticspred 21 dnevi

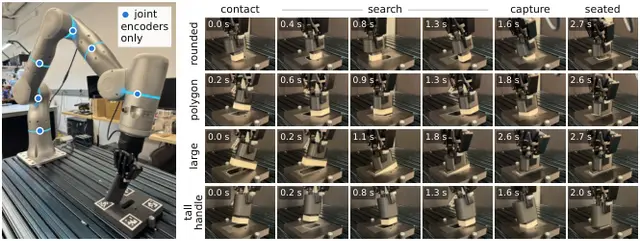
Precise Proprioceptive Sim-to-Real Robot Assembly for Diverse Pegs, Gears, and Nuts
The pegs are prisms with varying cross-section, size, aspect ratio, mass, and length, with 1.0–1.5 mm of clearance per side.

Antonia Bronars, Younghyo Park, Kushal Kedia +1

Robots Learn to Ask Better Questions About What People Really Want
AIpred 22 dnevi

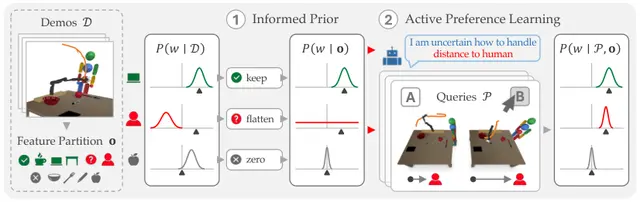
Robots Learn to Ask Better Questions About What People Really Want

A preference-learning method helps robots detect underspecified human feedback, improve their starting assumptions, and ask more targeted questions.

Helena Merker, Nick Walker, Andreea Bobu

Active Perception for Better-Lit Autonomous Spacecraft Inspection in Orbit
Roboticspred 22 dnevi

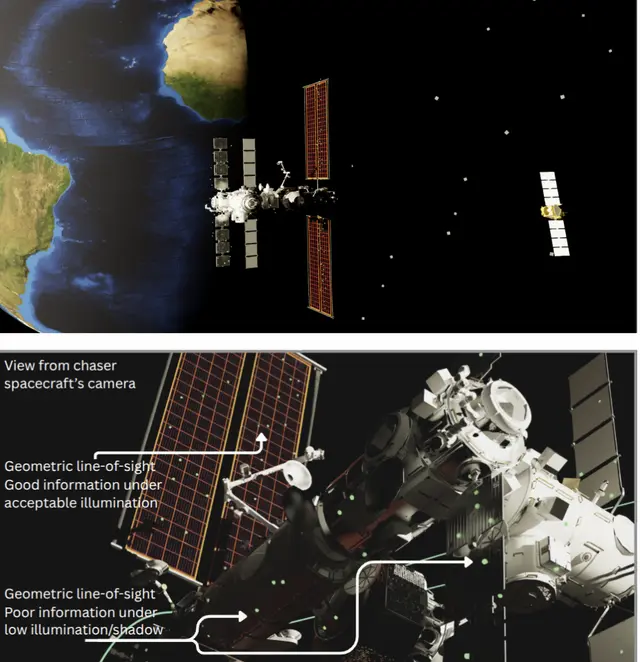
Active Perception for Better-Lit Autonomous Spacecraft Inspection in Orbit
Sagarika Rao Valluri, Benjamin Riviere

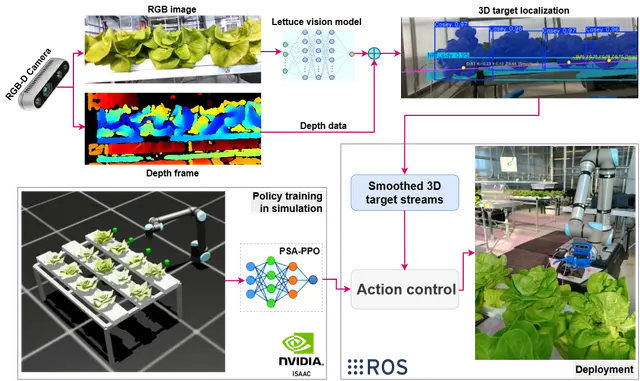
Path-Safe Sim-to-Real Learning for Hydroponic Lettuce Harvesting
Roboticspred 22 dnevi

Path-Safe Sim-to-Real Learning for Hydroponic Lettuce Harvesting

Al Bashir, Partho Ghose, Yibin Wang +4

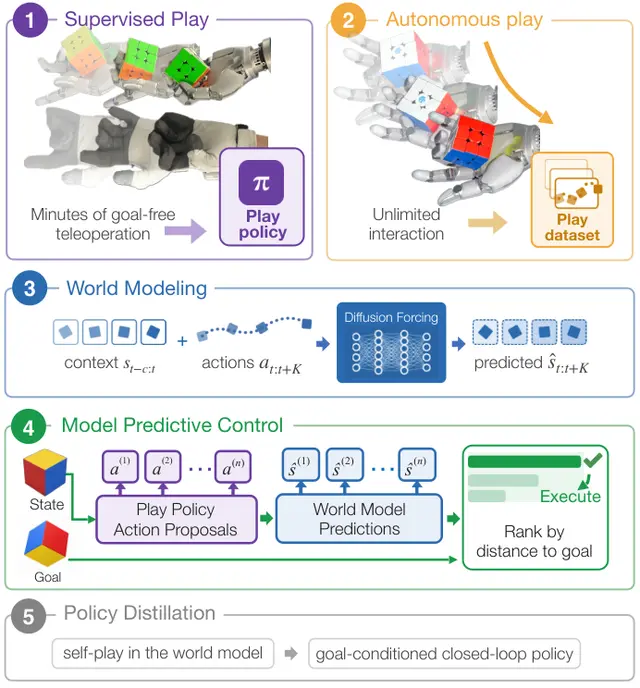
Dexterous Robot Manipulation Through Supervised Play and Planning
AIpred 23 dnevi

Dexterous Robot Manipulation Through Supervised Play and Planning

Dexterity from Supervised Play turns limited goal-free human play into autonomous contact-rich data, an action-conditioned world model, and goal-directed control through play-guided MPC.

Botao He, Yiming Dou, Yiannis Aloimonos +3

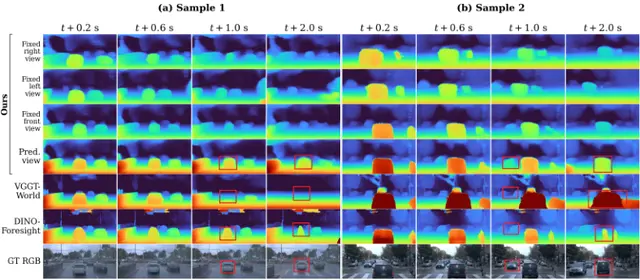
GeoState Helps Robots Predict 3D Scenes Beyond Their Current Camera View
AIpred 23 dnevi

GeoState Helps Robots Predict 3D Scenes Beyond Their Current Camera View

GeoState forecasts a view-decoupled 3D geometry state, then decodes it for a requested camera viewpoint.

Hongchang Liu, Jian Liu, Yujuan Ding +5

How Co-Evolving Robot Training Worlds Helps Policies Learn and Adapt Better
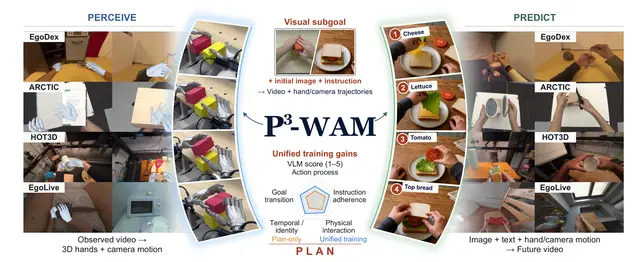
AIpred 23 dnevi

How Co-Evolving Robot Training Worlds Helps Policies Learn and Adapt Better

Tianjiao Yu, Zhilin Ou, Yifan Shen +5

Dexterous Robots See, Predict, and Plan with One World Action Model
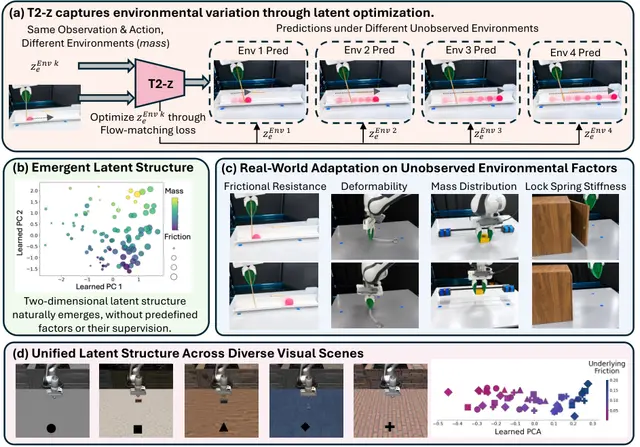
Roboticspred 24 dnevi

Dexterous Robots See, Predict, and Plan with One World Action Model

Zirui Wu, Chen Guo, Tianjian Jiang +11

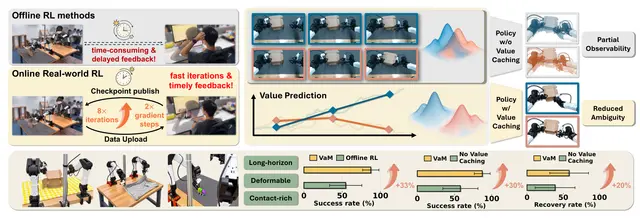
T2-z Optimizes Environment Latents for Robotic World Models at Test Time
AIpred 24 dnevi

T2-z Optimizes Environment Latents for Robotic World Models at Test Time

T2-z augments robotic world models with environment-latent conditioning.

Chenyuan Zhou, Yining Hong, Huang Huang +9

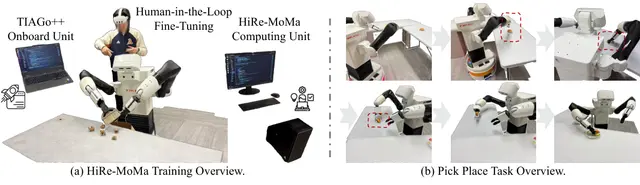
Robot Policies Turn Value Predictions Into Memory to Learn Online
Roboticspred 24 dnevi

Robot Policies Turn Value Predictions Into Memory to Learn Online

VaM gives robot policies cached task-progress predictions, helping them learn more efficiently from demonstrations and deployment experience.

Wenye Yu, Yijin Chen, Kaiyi Xiong +7

Sparse Human Guidance Trains Mobile Robots for Real-World Object Manipulation Tasks
AIpred 25 dnevi

Sparse Human Guidance Trains Mobile Robots for Real-World Object Manipulation Tasks
Zhefei Gong, Hefeifei Jiang, Zehao Wang +1

Diffusion Builds Humanoid Controllers From Weights for Real Robot Motion
Humanoidpred 25 dnevi

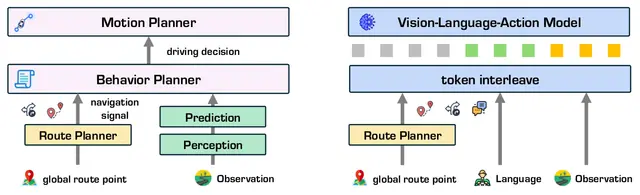
Diffusion Builds Humanoid Controllers From Weights for Real Robot Motion

Huixuan Cheng, Bike Zhang, Shankar Sastry +1

A Driving AI That Checks If Navigation Commands Are Safe First
Roboticspred 25 dnevi

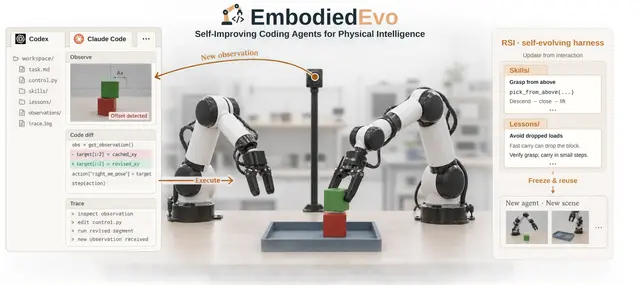
A Driving AI That Checks If Navigation Commands Are Safe First

SafeDriveVLA checks navigation commands against the driving scene, using mode labels and a world model to reduce unsafe actions.

Shaoyuan Xie, Zihan Zhang, Jingxuan Wang +6

EmbodiedEvo: Coding Agents Build Reusable Skills for Physical Robot Tasks
Roboticspred 26 dnevi

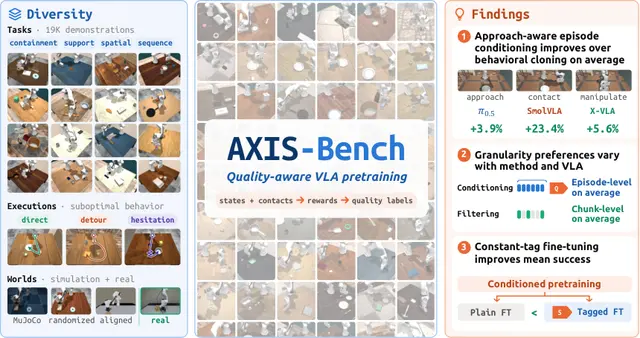
EmbodiedEvo: Coding Agents Build Reusable Skills for Physical Robot Tasks

Code as World organizes interaction with the physical environment into two levels of code.

Wenyi Li, Yizhe Chi, Youjie Zheng +8

Quality Labels Improve Robot VLA Pretraining, but Method Choices Matter Too
AIpred 26 dnevi

Quality Labels Improve Robot VLA Pretraining, but Method Choices Matter Too

Mingxuan Yan, Litian Gong, Dihong Huang +19