Średnia cena dzienna
Kwoty w USD


Three-Finger Force-Controlled Dexterous Hand for Precise Object Manipulation
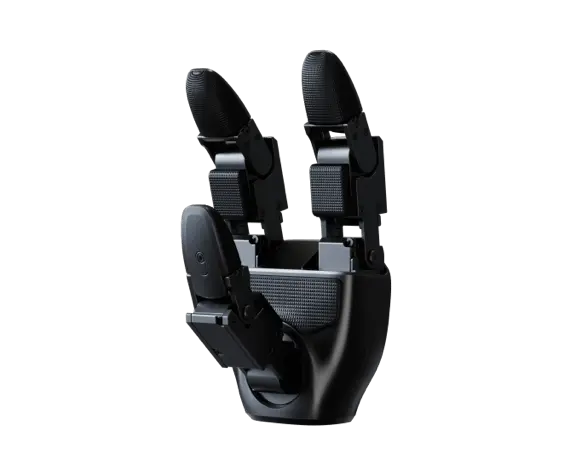
The Unitree Dex3-1 is a three-finger dexterous hand combining force-position hybrid control for sensitive, reliable operation. It simulates the human hand to achieve precise manipulation of objects, making it ideal for humanoid robot applications. Designed for use with the Unitree G1 humanoid robot, it executes a wide range of complex actions.
Each hand features 7 DOF across 7 moving joints: 6 micro brushless force-controlled joints with direct drive, plus 1 micro brushless force-controlled joint with gear transmission. The thumb has 3 joints, the index finger 2, and the middle finger 2.
Nine sensor arrays (33 pressure sensors total) provide comprehensive tactile perception: palm 2×2 ×3, finger pad 2×2 ×3, fingertip 3×1 ×3.
Fingertip repeat positioning accuracy of ±2 mm ensures repeatable, controlled movements for delicate tasks.
Joint stiffness and damping coefficients are adjustable, enabling tailored control strategies for different grasping scenarios.
1000 Hz communication rate with real-time feedback of joint position, velocity, torque, temperature, voltage/current, sensor pressure values, and IMU data.
At just 710 g and 175 × 88 × 77 mm, the Dex3-1 minimizes payload impact while maintaining robust structural integrity.
| Weight | 710 g |
|---|---|
| Dimensions | 175 × 88 × 77 mm |
| Degrees of Freedom | 7 (Thumb ×3, Index ×2, Middle ×2) |
| Transmission | 6× micro brushless force-controlled joints (direct drive) + 1× gear transmission |
| Fingertip Repeat Accuracy | ±2 mm |
| Operating Voltage | 12 – 58 V |
| Static Current | 58 V @ 0.2 A |
| Maximum Current | 10 A |
| Communication Interface | USB 2.0 |
| Operating Temperature | -20°C to 60°C |
| Joint | Range |
|---|---|
| Thumb Joint 0 | -60° to 60° |
| Thumb Joint 1 | -35° to 60° |
| Thumb Joint 2 | 0° to 100° |
| Index Joint 0 | 0° to 90° |
| Index Joint 1 | 0° to 100° |
| Middle Joint 0 | 0° to 90° |
| Middle Joint 1 | 0° to 100° |
Room temperature, palm facing down, grasping 5 cm round hard object.
| Maximum Load | 500 g |
|---|---|
| Peak Power | 400 W @ 3 s |
Room temperature, palm facing left, grasping 5 cm round hard object — same ratings: 500 g max load, 400 W @ 3 s peak power.
| Sensor Arrays | 9 (33 pressure sensors total) |
|---|---|
| Array Resolution | Palm: 2×2 ×3 / Finger pad: 2×2 ×3 / Fingertip: 3×1 ×3 |
| Perception Range | 10 g – 2500 g |
| Maximum Withstand Force (no damage) | 20 kg |
| Communication Rate | 1000 Hz |
|---|---|
| Packet Size (TX) | 1234 bytes |
| Packet Size (RX) | 1270 bytes |
| Perception Feedback | Joint mode, position, velocity, torque, temperature, voltage/current, sensor pressure, sensor temperature, IMU data |
| Control Feedback | Joint mode, position, velocity, torque, stiffness coefficient, damping coefficient |
| Parameter | F-1515-108 | F-1515-214 |
|---|---|---|
| Weight | 45 g | 45 g |
| Dimensions | 34.8 × 23.1 × 23.3 mm | 34.8 × 23.1 × 23.3 mm |
| Reduction Ratio | 1:108 | 1:214 |
| Max Torque (ideal) | 0.76 Nm | 1.498 Nm |
| Max Torque (actual, same direction) | 0.49 Nm | 0.86 Nm |
| Max Torque (actual, opposite direction) | 1.37 Nm | 3.1 Nm |
| Max Speed | 23 rad/s | 11 rad/s |
| Max Line Current | 4.76 A | — |
| Communication Control Frequency | 1000 Hz | 1000 Hz |
| Communication Method | High-speed single bus | High-speed single bus |
| Encoder | Rotor absolute encoder | Rotor absolute encoder |
| Operating Environment | -20°C to 60°C | -20°C to 60°C |
| Operating Voltage | 12 – 24 V | 12 – 24 V |
| Motor Feedback | Torque, angle, angular velocity, temperature | Torque, angle, angular velocity, temperature |
| Motor Control Commands | Torque, angle, angular velocity, stiffness, damping | Torque, angle, angular velocity, stiffness, damping |
2× Unitree Dex3-1 Tactile Dexterous Hand
Three-Finger Force-Controlled Dexterous Hand for Precise Object Manipulation
The Unitree Dex3-1 is a three-finger dexterous hand combining force-position hybrid control for sensitive, reliable operation. It simulates the human hand to achieve precise manipulation of objects, making it ideal for humanoid robot applications. Designed for use with the Unitree G1 humanoid robot, it executes a wide range of complex actions.
Each hand features 7 DOF across 7 moving joints: 6 micro brushless force-controlled joints with direct drive, plus 1 micro brushless force-controlled joint with gear transmission. The thumb has 3 joints, the index finger 2, and the middle finger 2.
Nine sensor arrays (33 pressure sensors total) provide comprehensive tactile perception: palm 2×2 ×3, finger pad 2×2 ×3, fingertip 3×1 ×3.
Fingertip repeat positioning accuracy of ±2 mm ensures repeatable, controlled movements for delicate tasks.
Joint stiffness and damping coefficients are adjustable, enabling tailored control strategies for different grasping scenarios.
1000 Hz communication rate with real-time feedback of joint position, velocity, torque, temperature, voltage/current, sensor pressure values, and IMU data.
At just 710 g and 175 × 88 × 77 mm, the Dex3-1 minimizes payload impact while maintaining robust structural integrity.
| Weight | 710 g |
|---|---|
| Dimensions | 175 × 88 × 77 mm |
| Degrees of Freedom | 7 (Thumb ×3, Index ×2, Middle ×2) |
| Transmission | 6× micro brushless force-controlled joints (direct drive) + 1× gear transmission |
| Fingertip Repeat Accuracy | ±2 mm |
| Operating Voltage | 12 – 58 V |
| Static Current | 58 V @ 0.2 A |
| Maximum Current | 10 A |
| Communication Interface | USB 2.0 |
| Operating Temperature | -20°C to 60°C |
| Joint | Range |
|---|---|
| Thumb Joint 0 | -60° to 60° |
| Thumb Joint 1 | -35° to 60° |
| Thumb Joint 2 | 0° to 100° |
| Index Joint 0 | 0° to 90° |
| Index Joint 1 | 0° to 100° |
| Middle Joint 0 | 0° to 90° |
| Middle Joint 1 | 0° to 100° |
Room temperature, palm facing down, grasping 5 cm round hard object.
| Maximum Load | 500 g |
|---|---|
| Peak Power | 400 W @ 3 s |
Room temperature, palm facing left, grasping 5 cm round hard object — same ratings: 500 g max load, 400 W @ 3 s peak power.
| Sensor Arrays | 9 (33 pressure sensors total) |
|---|---|
| Array Resolution | Palm: 2×2 ×3 / Finger pad: 2×2 ×3 / Fingertip: 3×1 ×3 |
| Perception Range | 10 g – 2500 g |
| Maximum Withstand Force (no damage) | 20 kg |
| Communication Rate | 1000 Hz |
|---|---|
| Packet Size (TX) | 1234 bytes |
| Packet Size (RX) | 1270 bytes |
| Perception Feedback | Joint mode, position, velocity, torque, temperature, voltage/current, sensor pressure, sensor temperature, IMU data |
| Control Feedback | Joint mode, position, velocity, torque, stiffness coefficient, damping coefficient |
| Parameter | F-1515-108 | F-1515-214 |
|---|---|---|
| Weight | 45 g | 45 g |
| Dimensions | 34.8 × 23.1 × 23.3 mm | 34.8 × 23.1 × 23.3 mm |
| Reduction Ratio | 1:108 | 1:214 |
| Max Torque (ideal) | 0.76 Nm | 1.498 Nm |
| Max Torque (actual, same direction) | 0.49 Nm | 0.86 Nm |
| Max Torque (actual, opposite direction) | 1.37 Nm | 3.1 Nm |
| Max Speed | 23 rad/s | 11 rad/s |
| Max Line Current | 4.76 A | — |
| Communication Control Frequency | 1000 Hz | 1000 Hz |
| Communication Method | High-speed single bus | High-speed single bus |
| Encoder | Rotor absolute encoder | Rotor absolute encoder |
| Operating Environment | -20°C to 60°C | -20°C to 60°C |
| Operating Voltage | 12 – 24 V | 12 – 24 V |
| Motor Feedback | Torque, angle, angular velocity, temperature | Torque, angle, angular velocity, temperature |
| Motor Control Commands | Torque, angle, angular velocity, stiffness, damping | Torque, angle, angular velocity, stiffness, damping |
2× Unitree Dex3-1 Tactile Dexterous Hand

Historia cen
Jeden punkt danych na dzień, uśredniony według daty pomiaru.
Kwoty w USD
Średnie obliczane są dla każdej doby UTC na podstawie wszystkich zarejestrowanych cen ofert.

Unitree · Barcelona, ES
$8680

Unitree · Austin, US
$8680

Unitree · Austin, US
$8680

Unitree · Austin, US
$8680

Unitree · Barcelona, ES
$7680

Unitree · Austin, US
$6500
Unitree · Austin, US
$7680
Unitree · London, GB
£5705,08

Unitree · Los Angeles, US
od $6500

Unitree · Barcelona, ES
$6500

Unitree · Barcelona, ES
$7800

Unitree · Munich, DE
5798 €
🍪 Preferencje plików cookie
Używamy plików cookie do pomiaru wydajności. Polityka prywatności