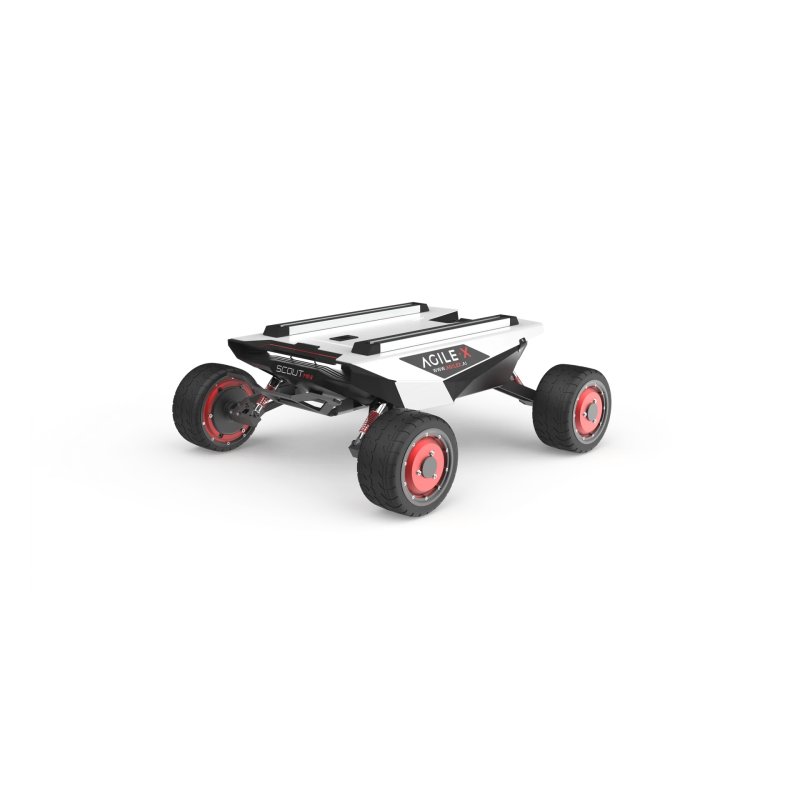
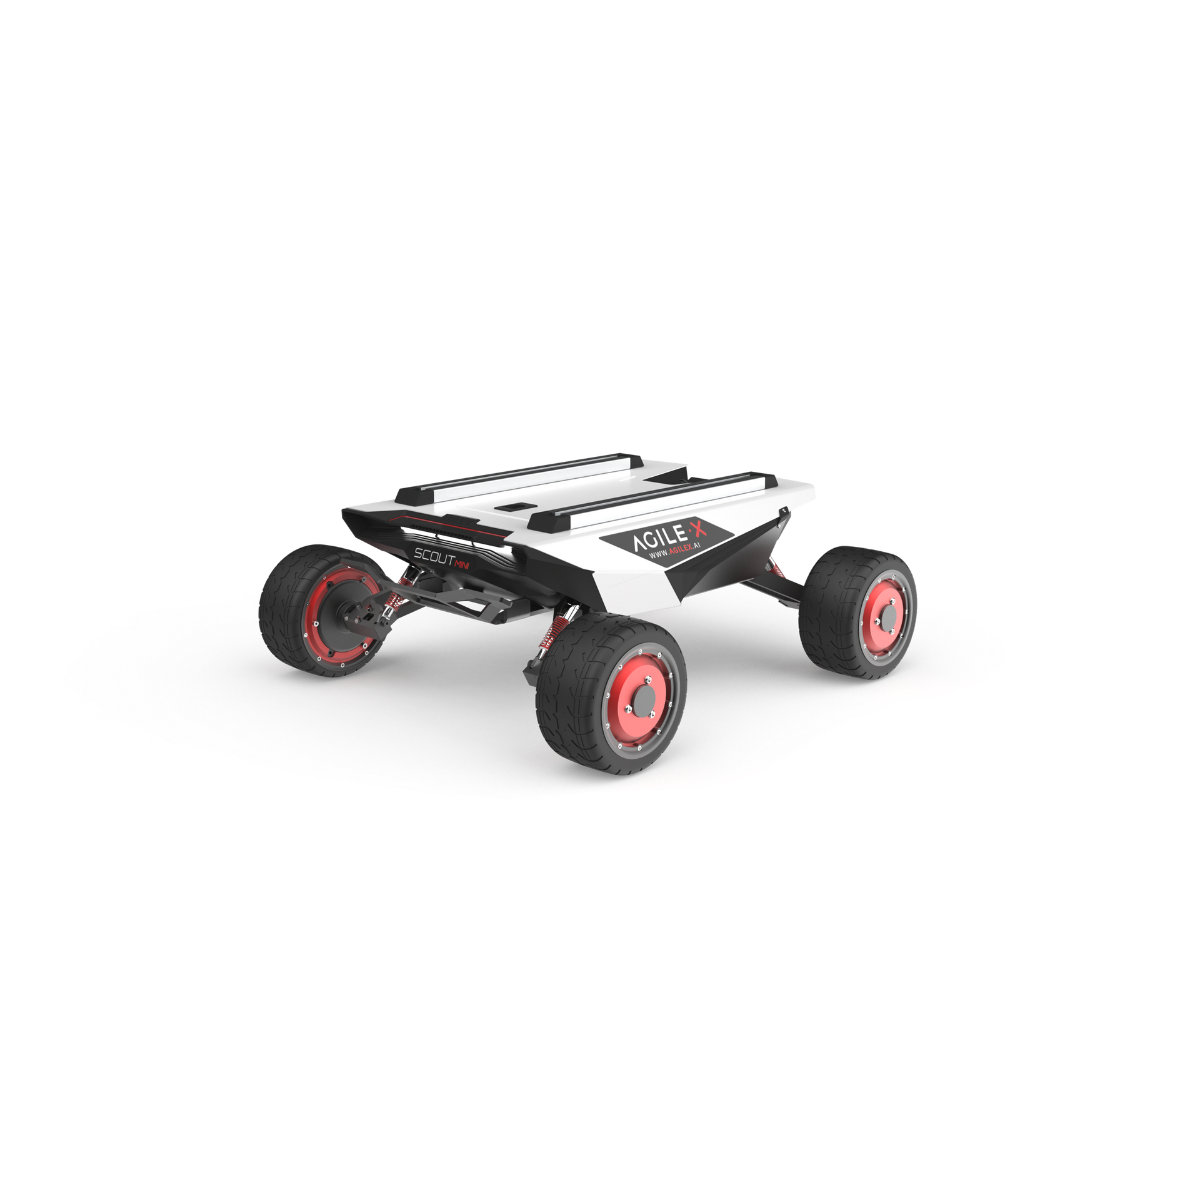
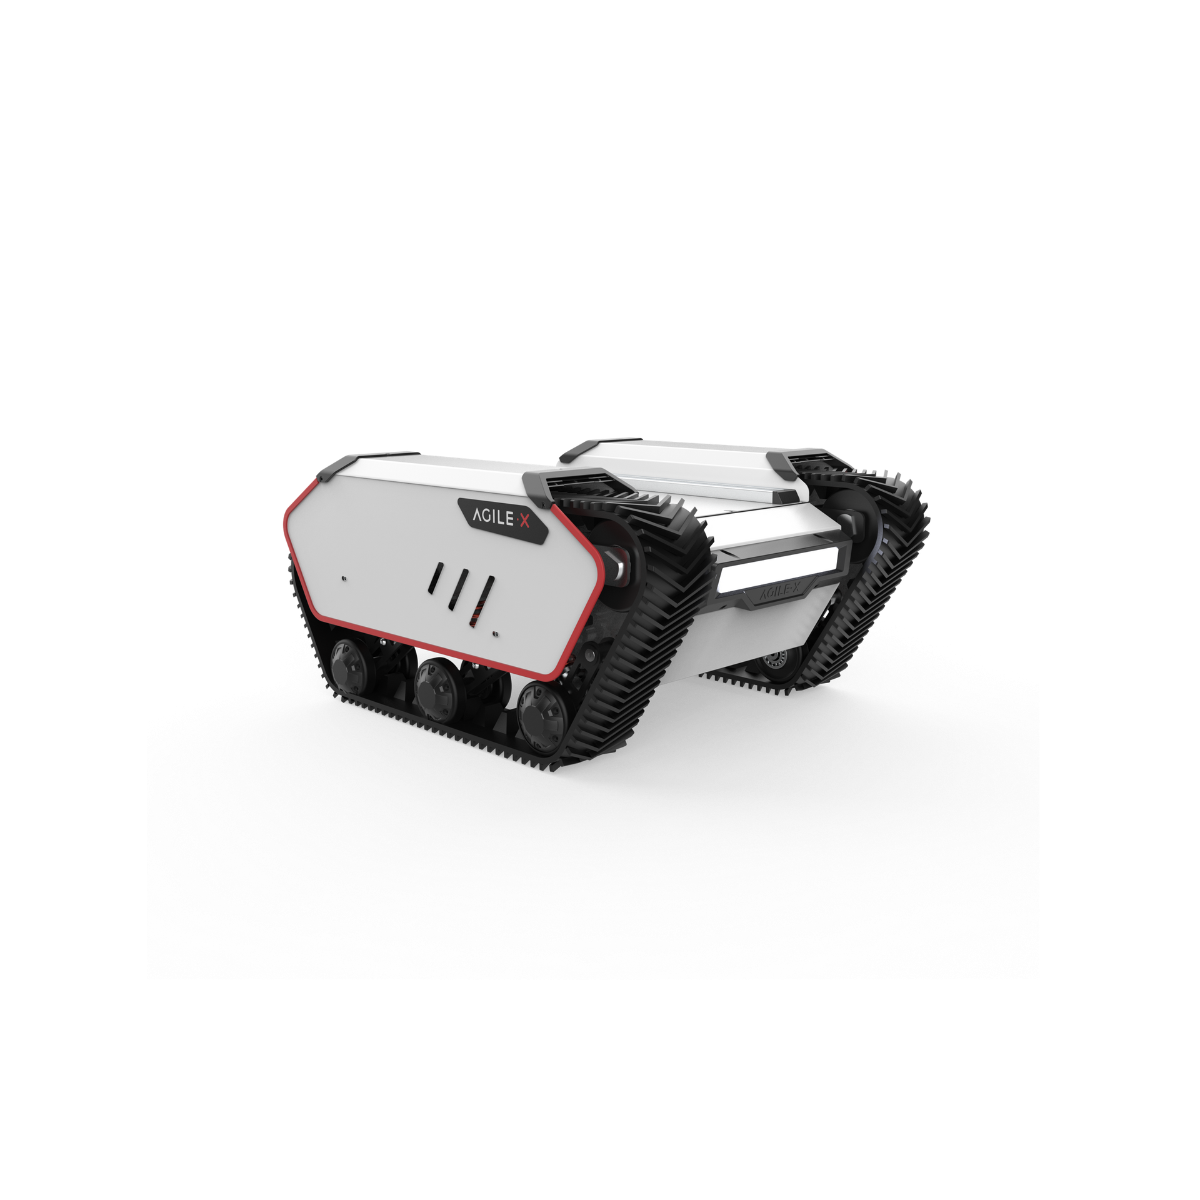
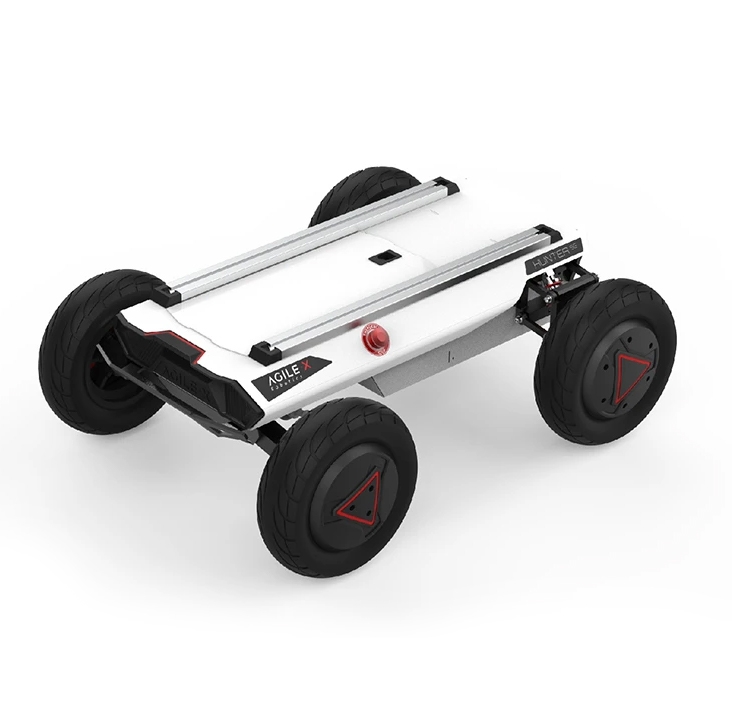
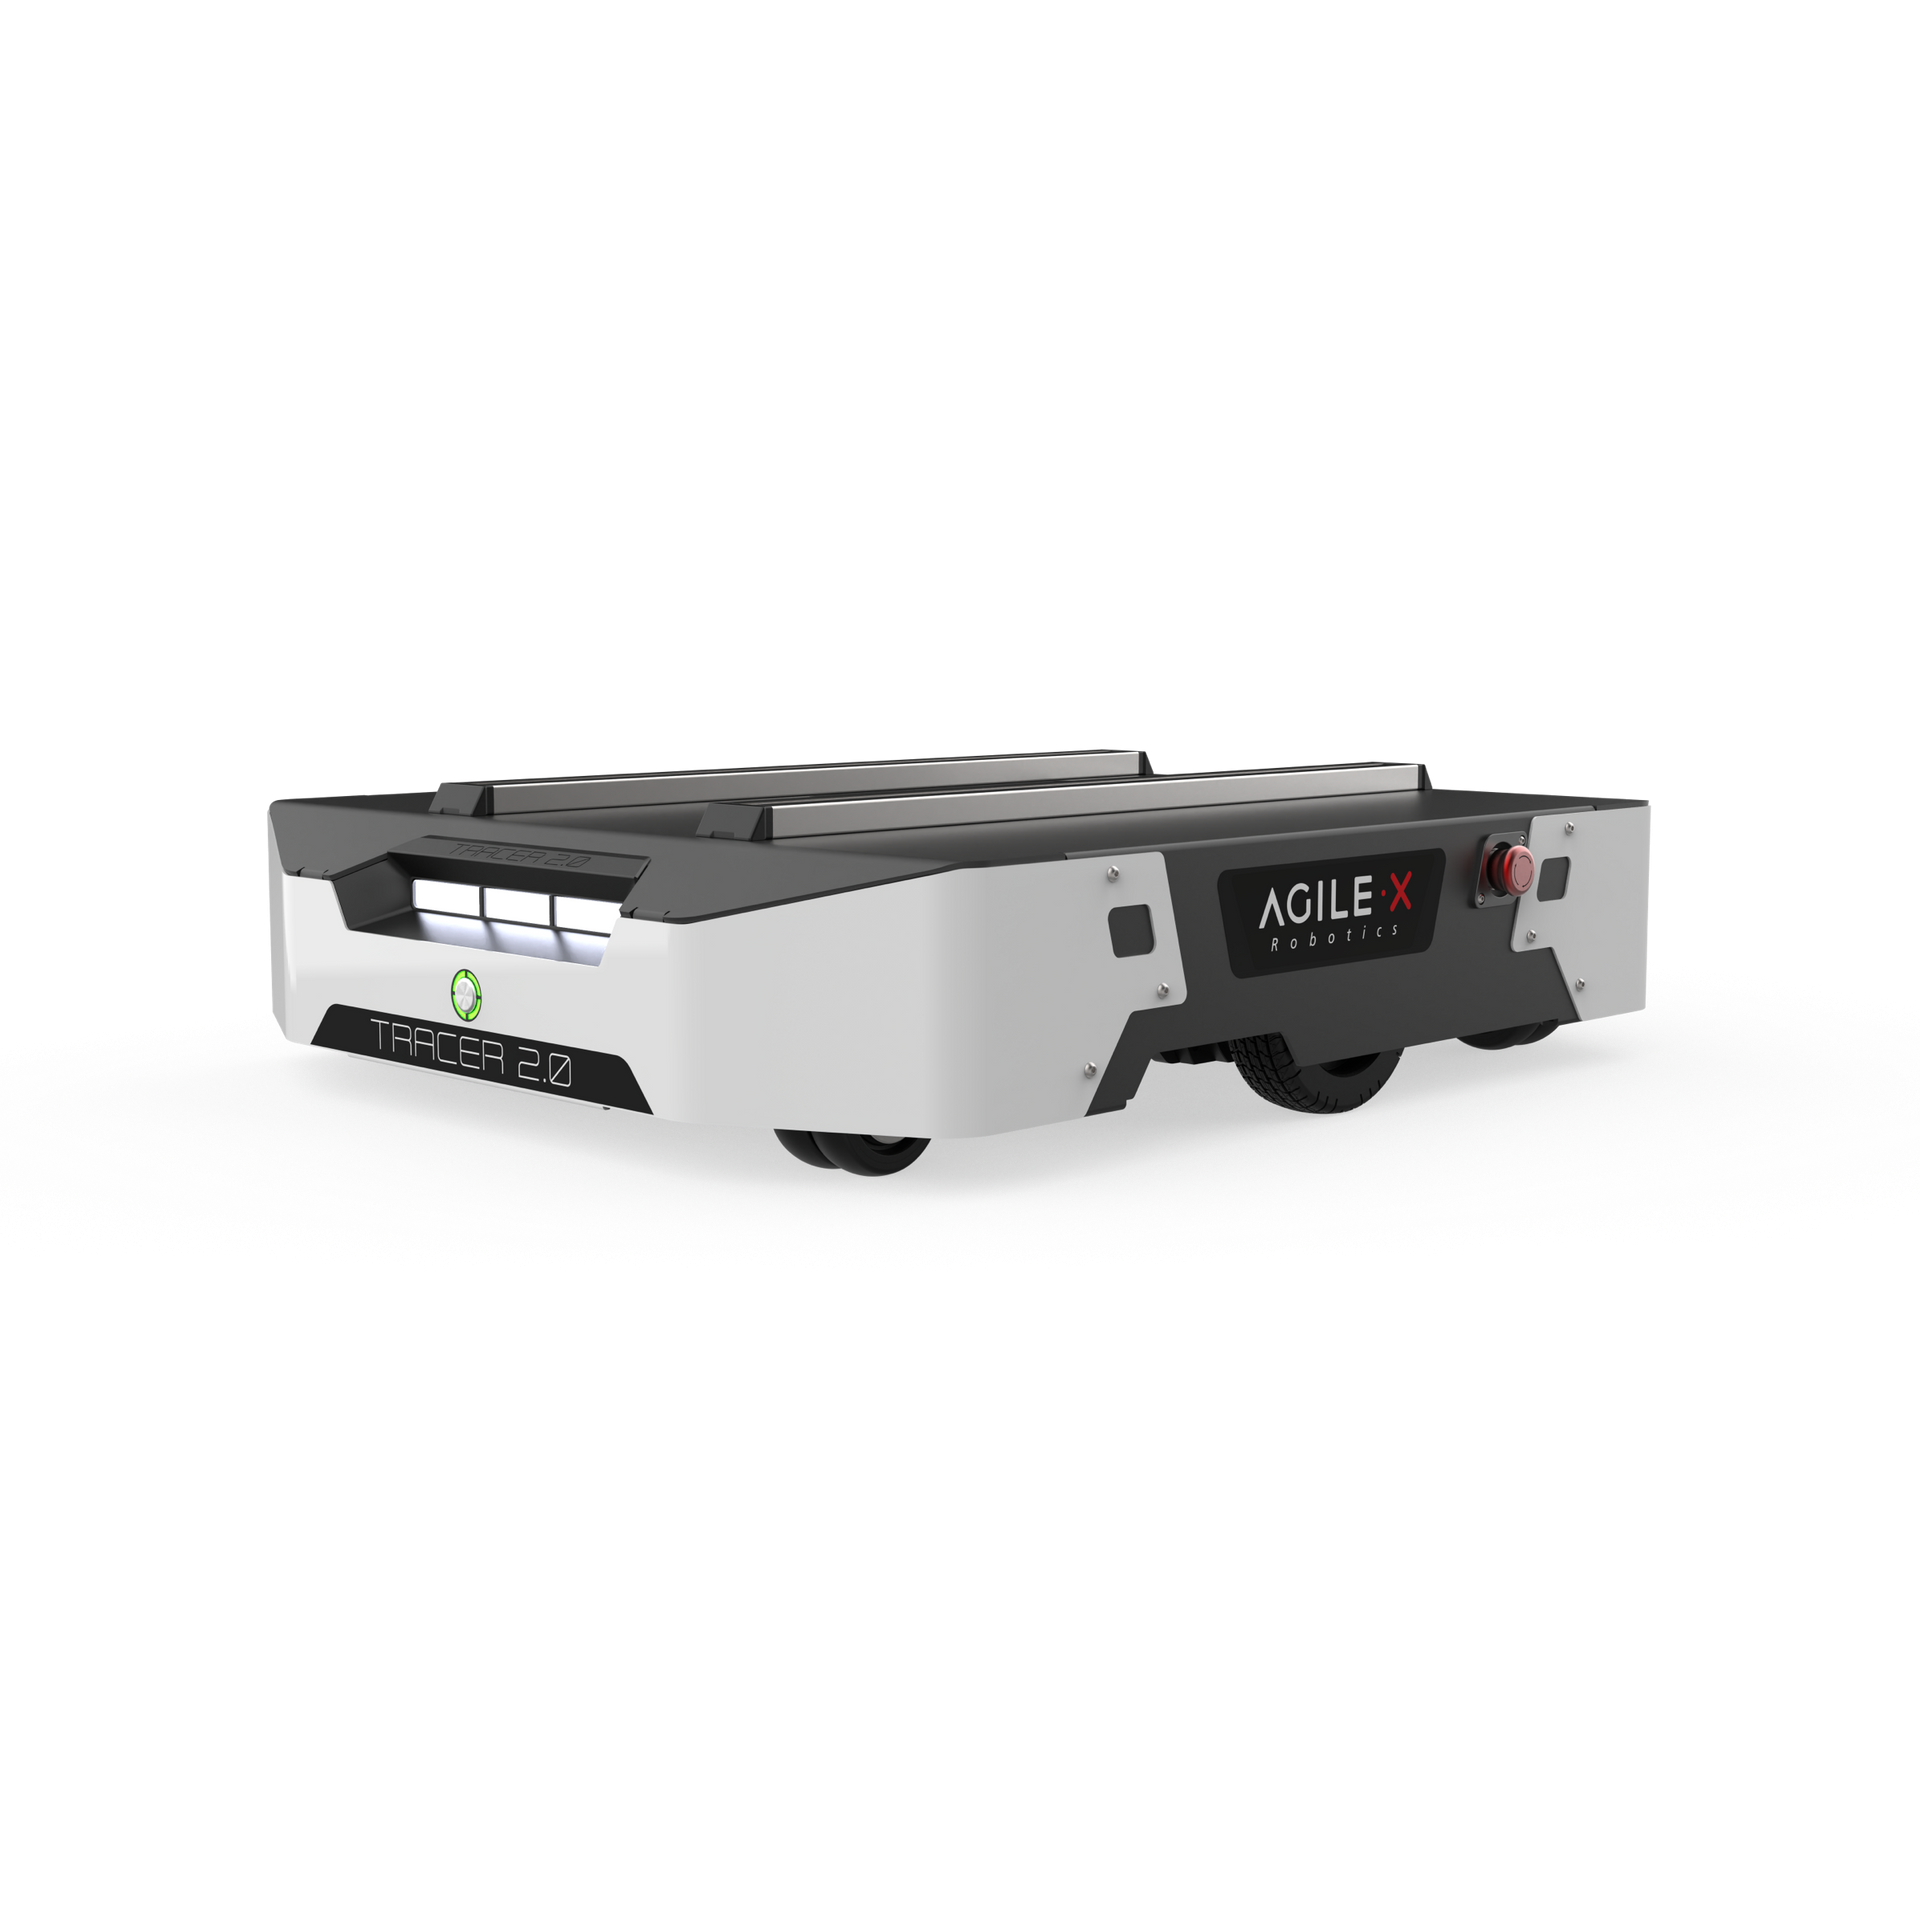
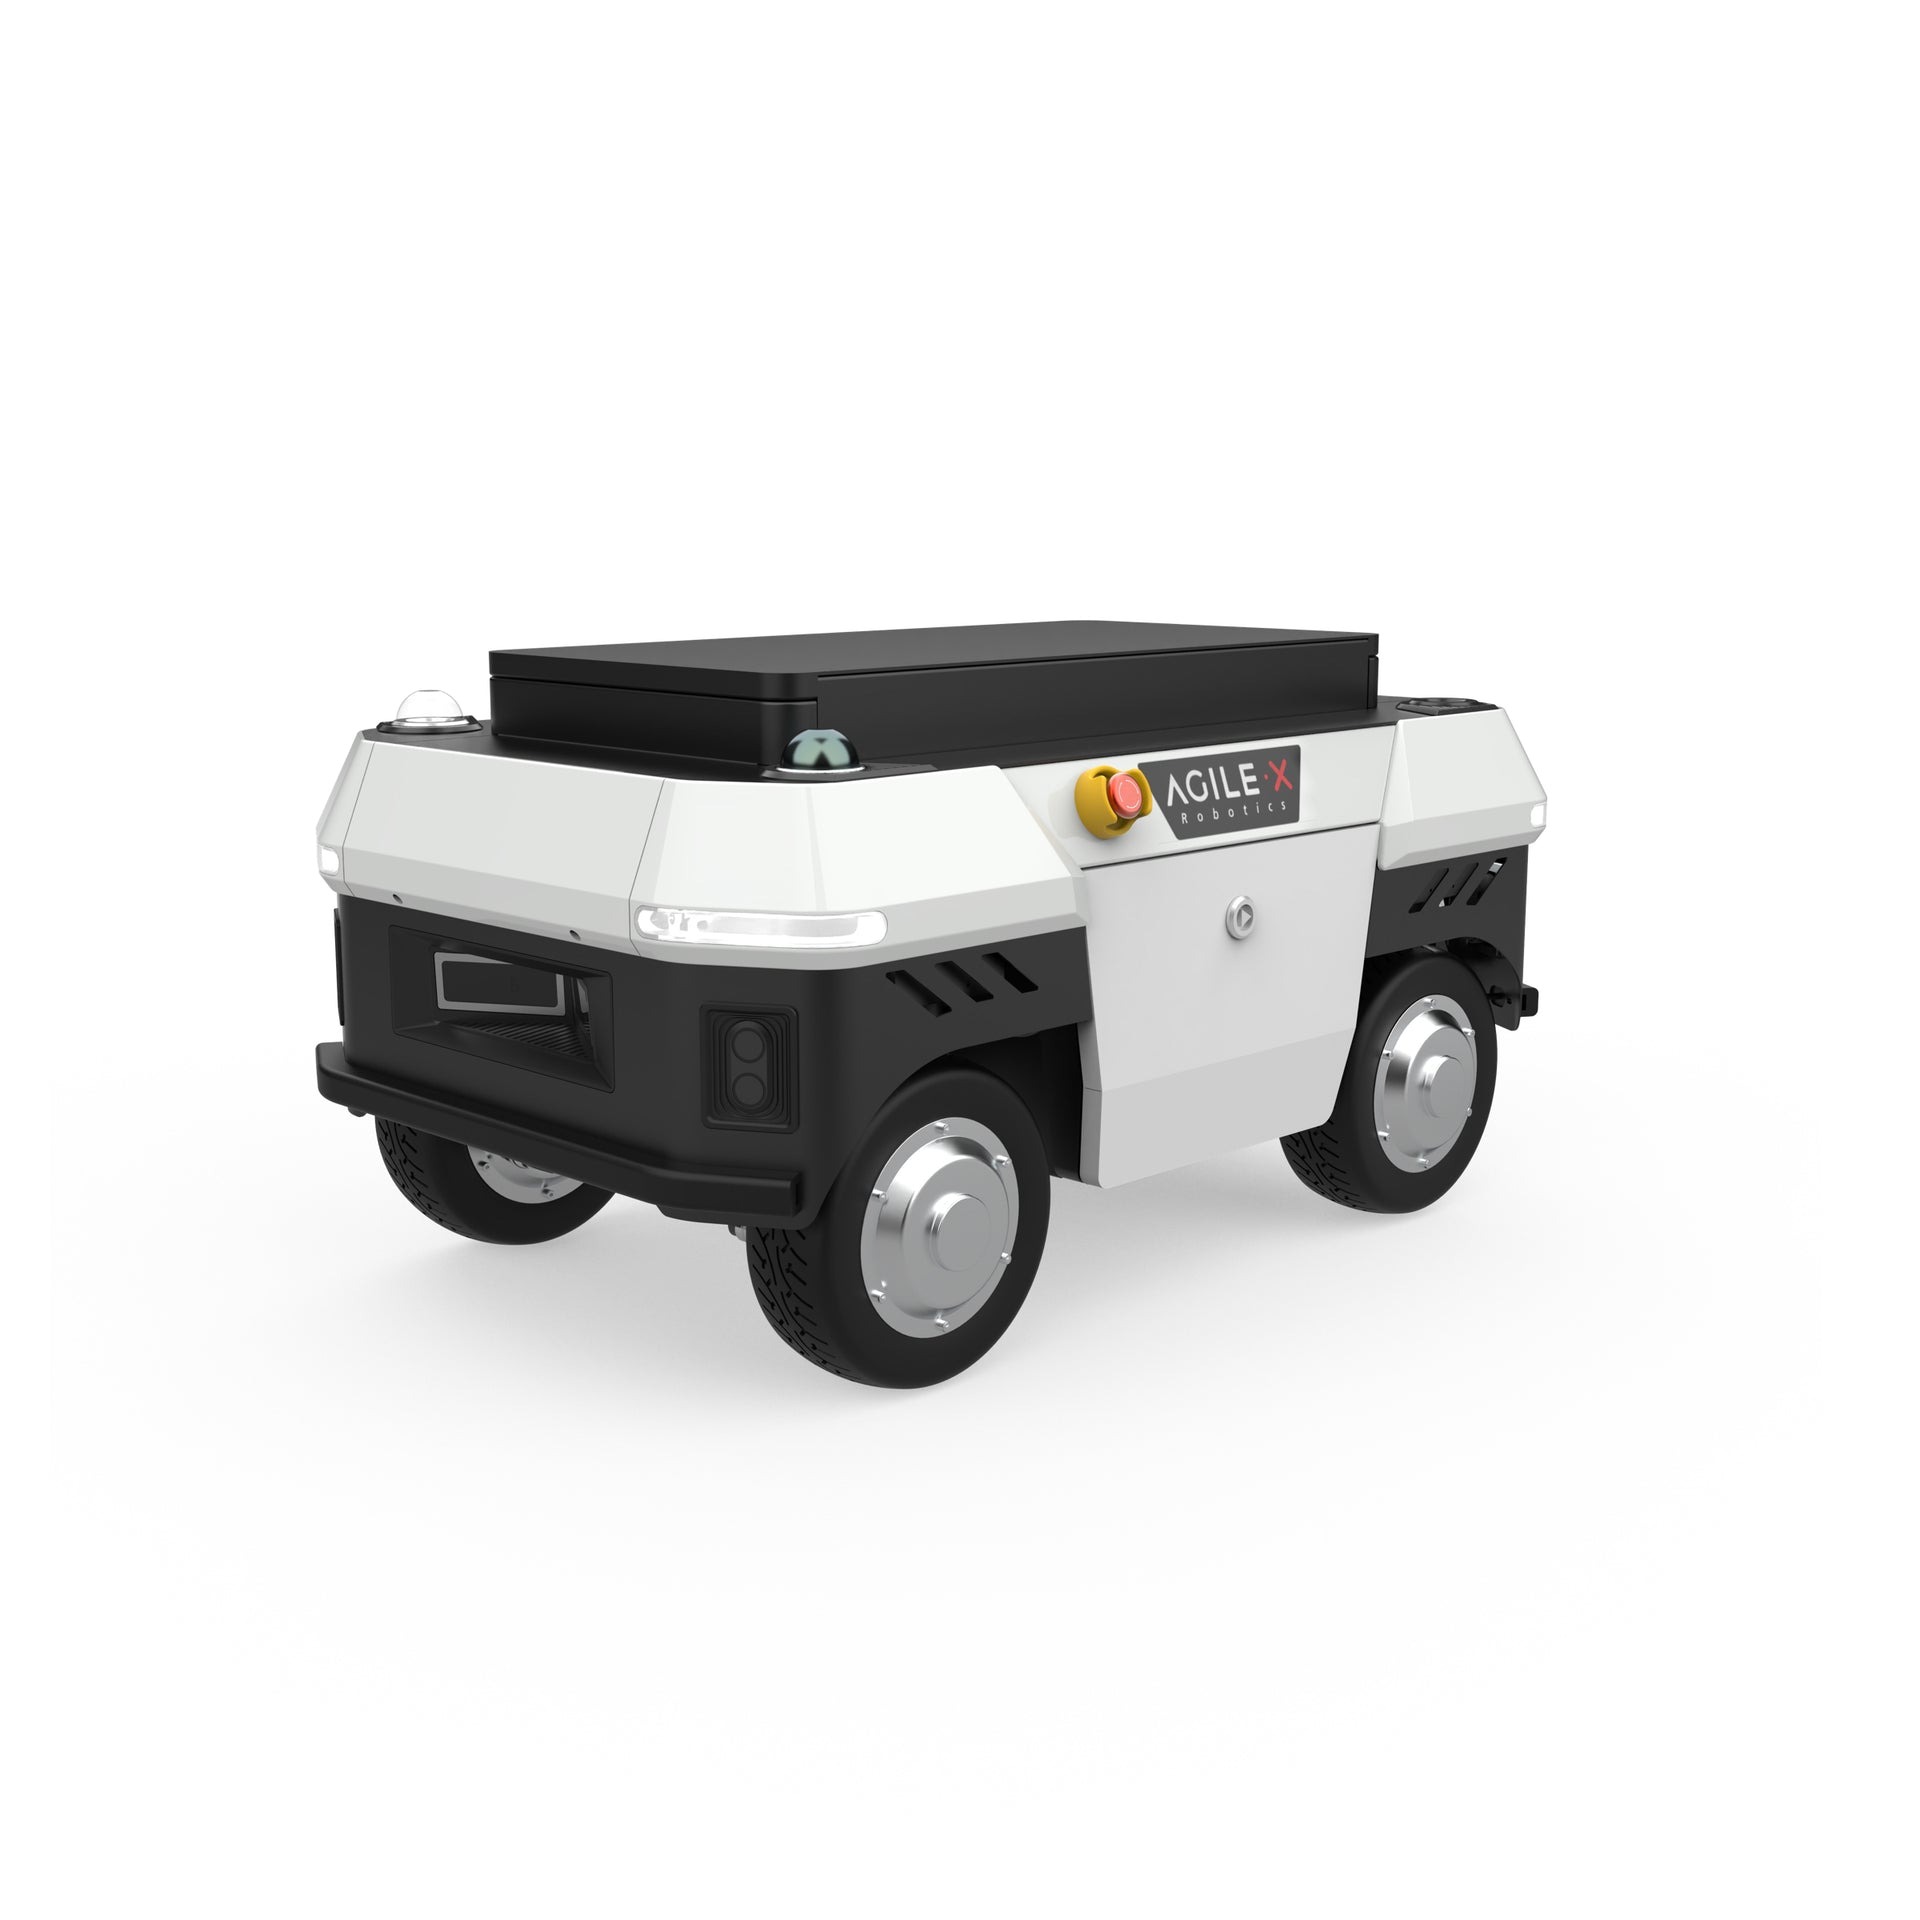
- 4WD with dual wheel options Four-wheel drive layout with standard wheels for differential steering or optional mecanum wheels for omnidirectional movement in confined spaces.
- CAN bus and serial interfaces Onboard CAN bus and serial connectivity—including USB-to-CAN and USB-to-RS232 modules—provide direct integration with autonomy stacks and secondary development workflows.
- 10 kg payload capacity Designed to carry sensors, edge compute, GNSS/RTK modules, and custom payloads while maintaining stable motion performance.
- ROS and C++ open development Open-source software resources for C++ and ROS support robotics middleware integration, SLAM pipelines, and navigation algorithm experimentation.
- Terrain mobility Approximately 115 mm ground clearance, up to 70 mm obstacle crossing height, and ~30° slope capability for mixed indoor-outdoor deployments.
- Compact, low-profile chassis Dimensions of approximately 612 × 580 × 245 mm with a low center of gravity for stability during rapid turns and traversal of uneven ground.

Harga purata harian
Jumlah dalam USD