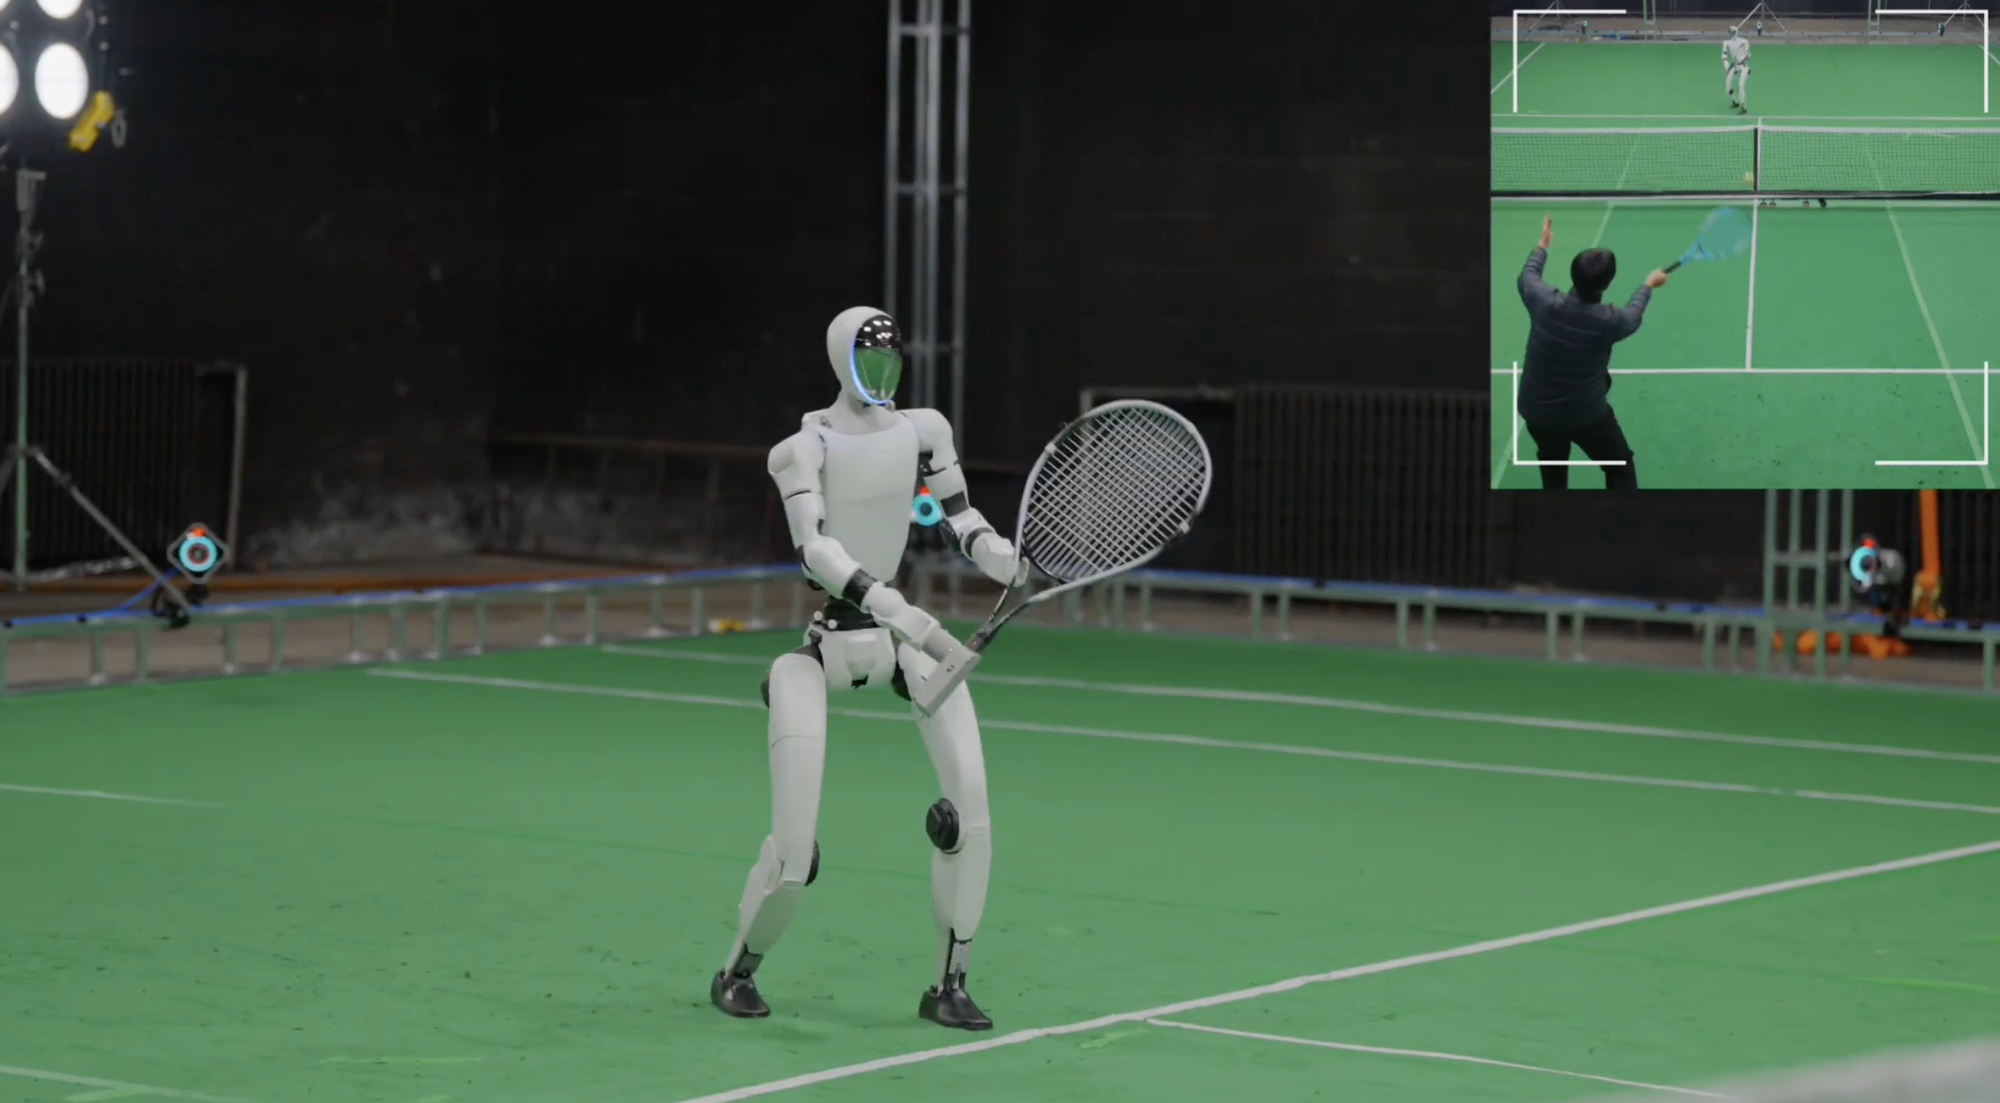
A humanoid robot learning competitive tennis from imperfect human motion data is the headline act in this week's robotics roundup — and it signals something bigger: Physical AI systems are now learning dynamic athletic skills without clean reference data. From apple-peeling dexterous hands to KAIST's field-tested humanoid, the pace of embodied AI progress is accelerating visibly.
Table of Contents
- What Is LATENT and How Does It Learn Tennis from Humans?
- Sharpa's Dexterous Apple-Peeling Robot and MoDE-VLA
- Other Humanoid and Legged Robot Milestones This Week
- Manipulation, Perception, and Edge Cases Worth Watching
- What This Week's Videos Mean for Humanoid Robotics
What Is LATENT and How Does It Learn Tennis from Humans?
LATENT (Learns Athletic humanoid TEnnis skills from imperfect human motioN daTa) is a system that trains a humanoid robot to perform competitive tennis rallies by learning from noisy, imperfect human motion data — without requiring clean, robot-specific kinematic reference data. The result is a humanoid that can track and return a high-speed tennis ball in live play against human opponents.
The core challenge LATENT addresses is deceptively hard. Human tennis motion is fast, highly dynamic, and deeply contextual — a forehand drive at 80 km/h requires coordinated whole-body posture, predictive footwork, and millisecond-level swing timing. Capturing that precisely enough for robot imitation learning has historically required either expensive motion-capture rigs or perfect human kinematic data mapped to robot morphology. LATENT sidesteps that bottleneck entirely.
According to the LATENT project page, the system tolerates noisy, imperfect human demonstration data and still produces stable, dynamic policy execution on a full-sized humanoid. That's the Physical AI insight worth internalising here: the brittleness of imitation learning to data quality is being systematically eroded. As the gap narrows between messy real-world human data and usable robot training signal, the range of athletic and dexterous skills transferable to humanoids expands dramatically.
Tennis is a deliberate benchmark choice. It requires high-speed perception (tracking ball trajectory), reactive whole-body control (footwork, swing mechanics, weight transfer), and tool-use (racket as an extended effector). If a humanoid can learn that from imperfect data, factory-floor manipulation tasks with similar dynamics — rapid pick-and-place, dynamic assembly — become more tractable. The athletic isn't the point; the generalisation capability is.
Sharpa's Dexterous Apple-Peeling Robot and MoDE-VLA
Sharpa claims to be the first robotics company to demonstrate a robot peeling an apple using dual dexterous humanlike hands — a bimanual, contact-rich manipulation task that pushes well beyond the capability of conventional industrial grippers. The underlying system, MoDE-VLA (Mixture of Dexterous Experts — Vision-Language-Action), fuses vision, language, force, and touch data using a team of specialist AI "experts" to stabilise control across high-dimensional action spaces.
The honest framing here is that this is a constrained demo. Apple peeling is deeply unstructured: the fruit's shape varies, the skin's resistance changes, and in-hand rotation requires continuous multi-finger coordination that even teleoperation can't easily provide. Sharpa's solution was a shared-autonomy architecture — rather than commanding every finger individually, an operator triggers pre-learned skill primitives (like "rotate object") via keyboard or foot pedal, while the robot handles the low-level coordination.
That design choice matters. Finger-level teleoperation of high-degree-of-freedom (high-DoF) robotic hands is practically infeasible for scalable data collection. By abstracting operator input to skill-level triggers, Sharpa makes reinforcement learning (RL) training feasible at scale. The MoDE-VLA framework then handles the actual in-hand coordination — fusing tactile feedback and visual data through its mixture-of-experts architecture to maintain stable contact during continuous manipulation.
For buyers evaluating humanoid robots for precision assembly or food handling, this architecture is worth tracking. Contact-rich bimanual manipulation has been one of the hardest capability gaps to close in commercial robotics. Sharpa's approach suggests a credible path to closing it — though the gap between peeling one apple on a demo table and peeling ten thousand in a production line remains very wide.
Other Humanoid and Legged Robot Milestones This Week
Several other demonstrations from this week's roundup deserve attention as a cohort:
| System | Organisation | Key Capability | Training Method |
|---|---|---|---|
| KAIST Humanoid v0.7 | KAIST DRCD Lab | Field tests + human interaction | Deep RL + human demonstrations |
| UMV (Unmanned Mobile Vehicle) | Robotics and AI Institute | Driving, jumping, flipping | NVIDIA Isaac Lab RL |
| LimX Dynamics Oli | LimX Dynamics | Glass door detection + navigation | Computer vision |
| Tesollo Finger-Tip Changer | Tesollo / Hanyang University | Modular fingertip swapping | Collaborative hardware design |
| KAIST Humanoid v0.7 | KAIST DRCD Lab | In-house actuators, field locomotion | Deep RL |
The KAIST Humanoid v0.7 is notable because it uses in-house actuators — a design choice that signals the lab's ambition to control the full stack from hardware to policy. Most academic humanoid platforms rely on commercial actuator systems; vertical integration at the joint level gives researchers tighter control over torque bandwidth and compliance tuning, which directly impacts locomotion stability.
The Robotics and AI Institute's UMV earned a mention during NVIDIA's GTC keynote as an "AI Native" company — a designation that indicates Isaac Lab simulation-to-real (sim-to-real) transfer is producing transferable locomotion policies capable of behaviours like flips and hops. Sim-to-real gap reduction remains one of the most commercially important problems in robotics; every successful transfer reduces the data collection burden for policy training.
LimX Dynamics' glass door perception is smaller news in isolation but significant as a capability milestone. Transparent surfaces have historically defeated standard depth sensors (lidar, structured light) because they reflect or transmit the sensing beam rather than returning a usable signal. Solving this in a walking robot's real-time navigation stack removes a genuine deployment blocker for legged robots in commercial buildings.
Manipulation, Perception, and Edge Cases Worth Watching
Beyond humanoids, two demonstrations this week highlight how robotics engineers solve problems that aren't obvious until you're standing on the factory floor trying to make something work.
Nomagic's shoebox manipulation robot addresses a surprisingly specific and genuinely difficult problem: cardboard boxes with lids cannot be reliably grasped by the lid because the grip force opens the box rather than lifts it. Nomagic developed specialised hardware to handle this — and their system is already deployed commercially, with Zalando installing up to 50 Nomagic robots across its logistics operations. That's not a lab demo; that's a production constraint being solved at scale in an active warehouse.
The Cranfield University wind-powered robot inspired by Strandbeest linkage mechanisms offers a different kind of insight. Designed for long-duration exploration of hostile environments, it runs on wind energy — no battery, no charging infrastructure. For inspection and environmental monitoring applications in remote locations, that energy independence matters more than speed or precision.
Stanford BDML's tree-hugging perching drone, meanwhile, demonstrates compliant aerial grasping using structured perching mechanisms. The application domain is environmental sensing, but the underlying capability — a flying robot that can anchor itself to irregular natural surfaces and remain stationary — has direct implications for infrastructure inspection (powerlines, bridge pylons) without the hover-time energy cost.
What This Week's Videos Mean for Humanoid Robotics
This week's demonstration cohort points toward three converging trends that buyers and engineers should track.
Learning from imperfect data is becoming the norm. Both LATENT and KAIST's v0.7 explicitly use noisy or demonstration-derived training data. The clean-data bottleneck — which once required expensive mocap rigs or specialist data pipelines — is losing its grip. This accelerates the timeline for teaching humanoids novel tasks.
Dexterity is being tackled through architecture, not just hardware. Sharpa's MoDE-VLA approach fuses multiple sensory modalities (vision, touch, force, language) using specialist sub-models. This mirrors the mixture-of-experts pattern in large language models, now applied to physical manipulation. It's a genuine architectural shift away from monolithic control policies.
Deployment-blocking edge cases are being solved one by one. Glass doors. Shoebox lids. Modular fingertips. Each of these is unglamorous compared to a tennis-playing humanoid, but commercial deployment is gated by exactly these edge cases. The speed at which the field is generating targeted solutions for specific failure modes is itself a signal about maturity.
For buyers evaluating used industrial robots alongside emerging humanoid platforms, the practical takeaway is that capability gaps that seemed structural twelve months ago are closing faster than most procurement timelines assume. Build review cycles that account for rapid capability shifts — particularly in manipulation and autonomous navigation.