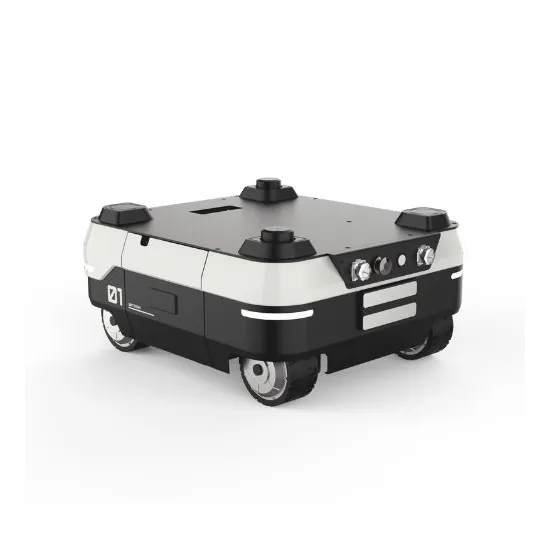
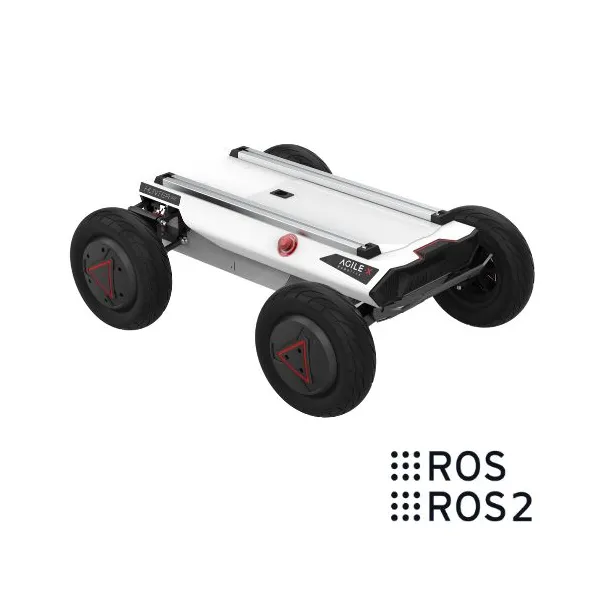
This mobile robot chassis for mixed indoor/outdoor environments serves as a base for research, education, and the integration of humanoid systems or intelligent collaboration.
価格の推移
観測日ごとに平均した、1日あたり1つのデータポイント。
USDでの金額
記録されたすべての販売価格を対象に、UTCの日ごとの平均を算出しています。

Unitree
$4,800
Unitree
4,867.20 €

Unitree
$4,655

Unitree
$4,500
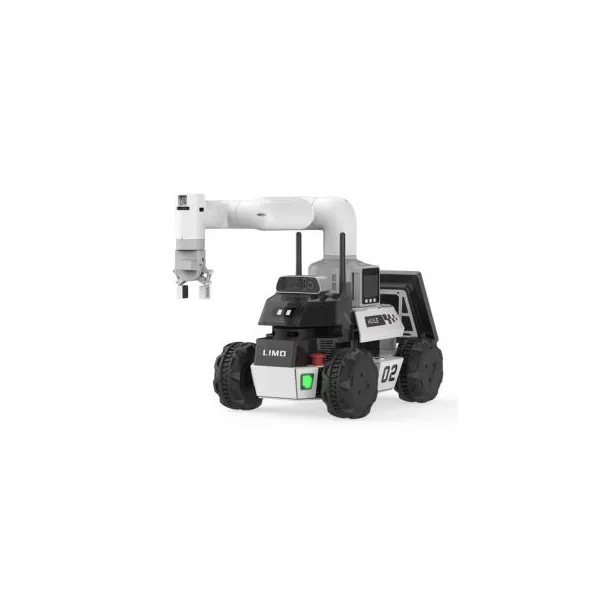
Unitree
5,179.20 €
Unitree
3,600 €

Unitree
$3,995
Unitree
6,427.20 €

Unitree
$2,925

Unitree
$5,850
Unitree
8,112 €
Unitree
8,400 €
🍪 クッキーの設定
パフォーマンスを測定するためにクッキーを使用しています。 プライバシーポリシー