Unitree Dex5-1P Tactile Hand for Unitree H1/H1-2 (Left)
    Unitree Dex5-1P Tactile Hand for Unitree H1/H1-2 (Left)
    Unitree Dex5-1P Tactile Hand for Unitree H1/H1-2 (Left)
    Unitree Dex5-1P Tactile Hand for Unitree H1/H1-2 (Left)
    Unitree Dex5-1P Tactile Hand for Unitree H1/H1-2 (Left)
    Unitree Dex5-1P Tactile Hand for Unitree H1/H1-2 (Left)
Unitree Dex5-1P Tactile Hand for Unitree H1/H1-2 (Left)
Open media 1 in gallery view
Unitree Dex5-1P Tactile Hand for Unitree H1/H1-2 (Left)
Open media 2 in gallery view
Unitree Dex5-1P Tactile Hand for Unitree H1/H1-2 (Left)
Open media 3 in gallery view
Unitree Dex5-1P Tactile Hand for Unitree H1/H1-2 (Left)
Open media 4 in gallery view
Unitree Dex5-1P Tactile Hand for Unitree H1/H1-2 (Left)
Open media 5 in gallery view
Unitree Dex5-1P Tactile Hand for Unitree H1/H1-2 (Left)
    Unitree Dex5-1P Tactile Hand for Unitree H1/H1-2 (Left)
    Unitree Dex5-1P Tactile Hand for Unitree H1/H1-2 (Left)
    Unitree Dex5-1P Tactile Hand for Unitree H1/H1-2 (Left)
    Unitree Dex5-1P Tactile Hand for Unitree H1/H1-2 (Left)
    Unitree Dex5-1P Tactile Hand for Unitree H1/H1-2 (Left)
Unitree Dex5-1P Tactile Hand for Unitree H1/H1-2 (Left)
Open media 1 in gallery view
Unitree Dex5-1P Tactile Hand for Unitree H1/H1-2 (Left)
Open media 2 in gallery view
Unitree Dex5-1P Tactile Hand for Unitree H1/H1-2 (Left)
Open media 3 in gallery view
Unitree Dex5-1P Tactile Hand for Unitree H1/H1-2 (Left)
Open media 4 in gallery view
Unitree Dex5-1P Tactile Hand for Unitree H1/H1-2 (Left)
Open media 5 in gallery view

About

Description

Description

The Unitree Dex5-1P Tactile Hand for Unitree H1/H1-2 (Left) is a next-generation robotic hand engineered for high-performance humanoid applications, designed specifically for compatibility with the Unitree H1 and H1-2 robots. Featuring 20 degrees of freedom and individually replaceable fingers, the Dex5-1 sets a new benchmark in robotic dexterity. Each joint is designed for smooth backdrivability, eliminating the rigid, "stiff-hand" sensation and providing the fluid responsiveness required for reinforcement learning (RL) environments. Its four-finger lateral swing (±22°) enhances grip reliability, adapting intelligently to curved and irregular surfaces.

Built for both speed and sensitivity, the Dex5-1 integrates 94 tactile sensors per hand and supports secondary algorithm development, giving researchers and developers complete control down to the millimeter. High-power density hollow-cup motors, micro force-controlled transmission, and ultra-low damping joint design ensure lightning-fast reflexes and seamless motion. With fingertip positioning accuracy of ±1mm, gripping strength of up to 10N, and a load capacity of up to 4.5 kg, the hand offers both power and finesse.
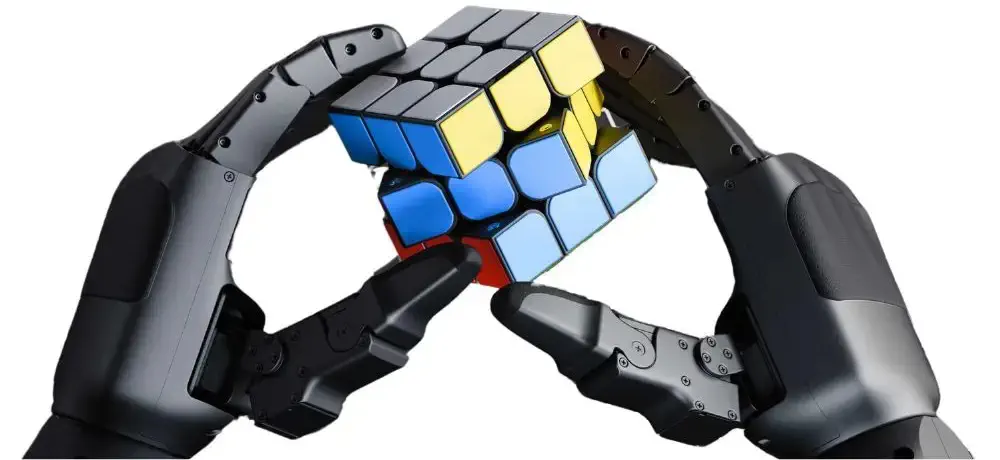
From its ultra-small joint gap design that prevents snagging, to its 1000Hz communication rate and real-time perceptual feedback - including position, torque, stiffness, and IMU data - the Dex5-1 is engineered for high-fidelity interaction. Whether in academic research, advanced robotics training, or real-world manipulation tasks, the Unitree Dex5-1 delivers unmatched tactile control and adaptability.

  • Unitree Dex5-1P Tactile Hand (Left)
  • Designed for Unitree H1/H1-2 humanoid robots
  • 20 Degrees of Freedom with Independent Finger Replacement
  • 94 Tactile Sensors per Hand – Supports advanced tactile feedback
  • 12 Pressure Sensors (94 pressure sensors in total)
  • High-Speed Reflexes with Micro Force-Controlled Joints
  • Ultra-Precise Fingertip Control with ±1mm repeat positioning accuracy
  • 217.3 x 127.5 x 72.1 mm (Note: The final shipped version may vary.)
  • Minimum grip diameter: 10mm
  • Fingertip Repeat Positioning Accuracy: ±1mm

Sensing parameters

Software functions

  • Degrees of Freedom
    • Thumb x 4
    • Index Finger x 3
    • Middle Finger x 3
    • Ring Finger x 3
    • Little Finger x 3
  • Transmission Mechanism
    • 12 self-developed micro force-controlled composite transmission joints (enable robot to achieve tactile proprioception)
    • 4 micro force-controlled joint gear transmission
  • Angle of Joint
    • Thumb Joint:
      • Thumb Joint 0: -33.5°~39°
      • Thumb Joint 1: 0°~100°
      • Thumb Joint 2: 0°~110°
      • Thumb Joint 3: 0°~92°
    • Four-Finger Joints:
      • Knuckles 0: -22°~22°
      • Knuckles 1: 0°~90°
      • Knuckles 2: 0°~95°
      • Knuckles 3: 0°~81°(Coupling with finger joint 2)
  • Four-Finger Lateral Swing: ±22°
  • Fingertip strength: 10N
  • Working Voltage: 24V ~ 60V
  • Static Current: 58V at 0.2A
  • Maximum Current: 58V at 3A
  • Communication Interface: USB 2.0
  • Working Temperature Range: -20 °C ~ 60 °C
  • Load Conditions (Palm facing down at room temperature, grasping a 5cm round hard object): Maximum Weight is 3.5 kg
  • Load Condition (Palm facing left at room temperature, grasping a 5cm round hard object): Maximum Weight is 4.5 kg
  • Weight: 1000 g
  • Number of Pressure Sensors: 12 (94 pressure sensors in total)
  • Array resolution
    • 2 x 5 (Palm)
    • 2 x 3 (Single Finger Pad) x5
    • 2 x 3 (Single Fingertip) x5
    • 2 x 3 (Single Finger Root) x4
  • Range of Perception: 10 g - 2500 g
  • Maximum Acceptance (Unamaged): 20 kg
  • Communication rate: 1000 Hz
  • The number of bytes in a full packet
    • Sender: 1234 bytes
    • Receiver: 1270 bytes
  • Perceptual feedback: Joint Mode, Joint Position, Joint Velocity, Joint Torque, Joint Temperature, Voltage and Current, imu Data
  • Control feedback: Joint Mode, Joint Position, Joint Velocity, Joint Torque, Joint Stiffness Coefficient, Joint Damping Coefficient
Body Parameters
Description

Description

The Unitree Dex5-1P Tactile Hand for Unitree H1/H1-2 (Left) is a next-generation robotic hand engineered for high-performance humanoid applications, designed specifically for compatibility with the Unitree H1 and H1-2 robots. Featuring 20 degrees of freedom and individually replaceable fingers, the Dex5-1 sets a new benchmark in robotic dexterity. Each joint is designed for smooth backdrivability, eliminating the rigid, "stiff-hand" sensation and providing the fluid responsiveness required for reinforcement learning (RL) environments. Its four-finger lateral swing (±22°) enhances grip reliability, adapting intelligently to curved and irregular surfaces.

Built for both speed and sensitivity, the Dex5-1 integrates 94 tactile sensors per hand and supports secondary algorithm development, giving researchers and developers complete control down to the millimeter. High-power density hollow-cup motors, micro force-controlled transmission, and ultra-low damping joint design ensure lightning-fast reflexes and seamless motion. With fingertip positioning accuracy of ±1mm, gripping strength of up to 10N, and a load capacity of up to 4.5 kg, the hand offers both power and finesse.

From its ultra-small joint gap design that prevents snagging, to its 1000Hz communication rate and real-time perceptual feedback - including position, torque, stiffness, and IMU data - the Dex5-1 is engineered for high-fidelity interaction. Whether in academic research, advanced robotics training, or real-world manipulation tasks, the Unitree Dex5-1 delivers unmatched tactile control and adaptability.

  • Unitree Dex5-1P Tactile Hand (Left)
  • Designed for Unitree H1/H1-2 humanoid robots
  • 20 Degrees of Freedom with Independent Finger Replacement
  • 94 Tactile Sensors per Hand – Supports advanced tactile feedback
  • 12 Pressure Sensors (94 pressure sensors in total)
  • High-Speed Reflexes with Micro Force-Controlled Joints
  • Ultra-Precise Fingertip Control with ±1mm repeat positioning accuracy
  • 217.3 x 127.5 x 72.1 mm (Note: The final shipped version may vary.)
  • Minimum grip diameter: 10mm
  • Fingertip Repeat Positioning Accuracy: ±1mm

Sensing parameters

Software functions

  • Degrees of Freedom
    • Thumb x 4
    • Index Finger x 3
    • Middle Finger x 3
    • Ring Finger x 3
    • Little Finger x 3
  • Transmission Mechanism
    • 12 self-developed micro force-controlled composite transmission joints (enable robot to achieve tactile proprioception)
    • 4 micro force-controlled joint gear transmission
  • Angle of Joint
    • Thumb Joint:
      • Thumb Joint 0: -33.5°~39°
      • Thumb Joint 1: 0°~100°
      • Thumb Joint 2: 0°~110°
      • Thumb Joint 3: 0°~92°
    • Four-Finger Joints:
      • Knuckles 0: -22°~22°
      • Knuckles 1: 0°~90°
      • Knuckles 2: 0°~95°
      • Knuckles 3: 0°~81°(Coupling with finger joint 2)
  • Four-Finger Lateral Swing: ±22°
  • Fingertip strength: 10N
  • Working Voltage: 24V ~ 60V
  • Static Current: 58V at 0.2A
  • Maximum Current: 58V at 3A
  • Communication Interface: USB 2.0
  • Working Temperature Range: -20 °C ~ 60 °C
  • Load Conditions (Palm facing down at room temperature, grasping a 5cm round hard object): Maximum Weight is 3.5 kg
  • Load Condition (Palm facing left at room temperature, grasping a 5cm round hard object): Maximum Weight is 4.5 kg
  • Weight: 1000 g
  • Number of Pressure Sensors: 12 (94 pressure sensors in total)
  • Array resolution
    • 2 x 5 (Palm)
    • 2 x 3 (Single Finger Pad) x5
    • 2 x 3 (Single Fingertip) x5
    • 2 x 3 (Single Finger Root) x4
  • Range of Perception: 10 g - 2500 g
  • Maximum Acceptance (Unamaged): 20 kg
  • Communication rate: 1000 Hz
  • The number of bytes in a full packet
    • Sender: 1234 bytes
    • Receiver: 1270 bytes
  • Perceptual feedback: Joint Mode, Joint Position, Joint Velocity, Joint Torque, Joint Temperature, Voltage and Current, imu Data
  • Control feedback: Joint Mode, Joint Position, Joint Velocity, Joint Torque, Joint Stiffness Coefficient, Joint Damping Coefficient
Body Parameters
Unitree by Unitree

Unitree Dex5-1P Tactile Hand for Unitree H1/H1-2 (Left)

SKU: DEX5-HANDL
Regular price
$25,000.00
Sale price
$25,000.00
Regular price
Unit price
 per 
Shipping calculated at checkout.
Providing the best new Tech Experience, Energy Independence and Robotics Ways of Optimisation
Packaging note:
Equipment is being supplied in a manufacturer packaging
Unitree Dex5-1P Tactile Hand for Unitree H1/H1-2 (Left) Unitree Dex5-1P Tactile Hand for Unitree H1/H1-2 (Left) Unitree Dex5-1P Tactile Hand for Unitree H1/H1-2 (Left) Unitree Dex5-1P Tactile Hand for Unitree H1/H1-2 (Left) Unitree Dex5-1P Tactile Hand for Unitree H1/H1-2 (Left)

価格の推移

平均価格の推移

観測日ごとに平均した、1日あたり1つのデータポイント。

日ごとの平均価格

USDでの金額

$25,000
USDで表示した平均価格の推移グラフ2026/10/02から2026/10/07までの7件の観測値を示す折れ線グラフ。$25,000.03$25,000.02$25,000.01$25,000$24,999.9910月2日10月3日10月4日10月5日10月7日2026/10/02:平均$25,0002026/10/03:平均$25,0002026/10/04:平均$25,0002026/10/05:平均$25,0002026/10/06:平均$25,0002026/10/07:平均$25,000

記録されたすべての販売価格を対象に、UTCの日ごとの平均を算出しています。