日ごとの平均価格
USDでの金額
説明
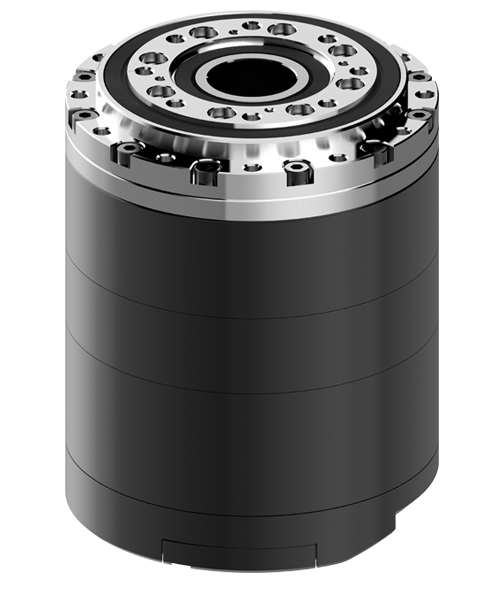
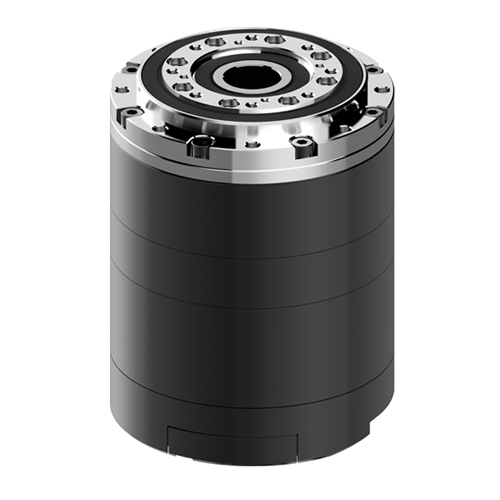
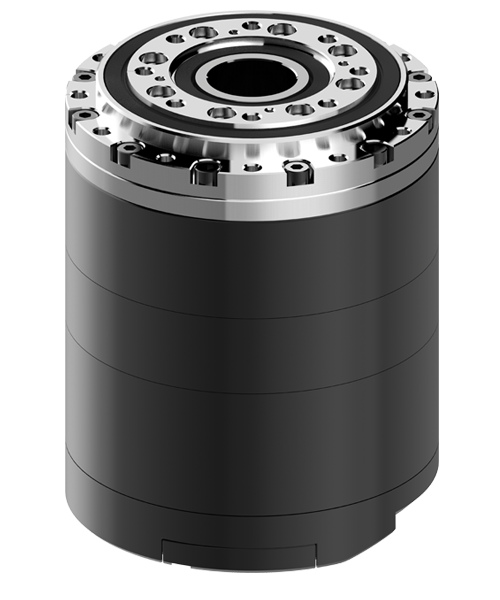
YM080-230-A051-RH is an all-in-one robot actuator with a built-in cycloidal reducer, specifically the DYNAMIXEL DRIVE (DYD) DYD-17H-051 model. DYNAMIXEL DRIVE (DYD) cannot be replaced after purchasing the product. Features High Performance Frameless Motor with Hollow Shaft Torque control based on current sensing PID control to enhance position, speed reliability and accuracy The integrated absolute magnetic encoder and replaceable battery allow multi-turn position information to be retained even after complete power-off (with back up battery). Metal housing for high durability Modular configuration makes it easy to create applications of varying degrees of freedom Package Components Products Qty. Note YM080-230-A051-RH 1 DYNAMIXEL-Y(R-option) Robot Cable-2P-X4P 600mm(Convertible) 1 RS485 2P-4P Cable(MOLEX-JST) Robot cable-2P 600mm 1 RS485 2P Cable(MOLEX-MOLEX) Cord End Terminal 4 For power connection Terminal Plug 2 For power connection Wrench Bolt WB M3X20 14 For shaft frame assembly Wrench Bolt WB M4x10 10 For frame assembly How to Connect a Multi-turn Backup Battery 1. Disconnect the power from the DYNAMIXEL-Y and release the locking bolt on the battery cover. 2. Open the battery cover. 3. Connect the battery cable. 4. Reattach the battery cover. 5. Tighten and secure the locking bolt of the battery cover. 6. Run DYNAMIXEL Wizard 2.0, and follow the battery replacement procedure. 7. Refer to the e-Manual for details (link) Drawing Drawing download Assembly guide Caution [Warning!] -Due to the material properties, rust may occur depending on the user environment. -Repairs due to rust may incur costs, so please refer to the following guidelines to prevent rust: Please take steps to reduce humidity and improve ventilation. Salt removal and anti-corrosion treatment should be performed on a regular basis. - Please be aware of different operational voltage from other DYNAMIXEL series (Operational voltage: 24V). - Please refer to the drawings provided online when combining with other power transmission products. - This product is designed as an integral unit; the cycloidal reducer and motor cannot be separated for individual use. - Please be cautious of overheating during prolonged high-speed usage. - Please use a frame that matches the screw length considering the depth of the tabs indicated in the drawing. - After purchasing the product, ensure to connect the multi-turn backup battery before use. - Please refer to the drawings when combined with various products such as reducers, linear actuators, and servo cylinders depending on the intended purpose. - For additional precautions, please refer to the e-manual. Specification Model Name YM080-230-A051-RH Series DYNAMIXEL Y MCU ARM Cortex-M4 (168 [Mhz], 32 [bit]) Input Voltage Min. [V] - Recommended [V] 24.0 Max. [V] - Performance Characteristics Voltage [V] 24.0 Stall Torque [N·m] - Stall Current [A] - No Load Speed [rpm] 62.0 No Load Current [A] - Continuous Operation *) Voltage [V] 24.0 Torque [N·m] 15.8 Speed [rpm] 39.0 Current [A] 12.6 Resolution Resolution [deg/pulse] 0.0000134636 Step [pulse/rev] 26,738,688 Angle [degree] 360 Position Sensor Contactless absolute encoder (19Bit, 360 [deg])Multi-turn (18Bit, 262,144 [rev], Battery back up) Operating Temperature Min. [°C] -5 Max. [°C] 55 Motor Frameless BLDC Baud Rate Min. [bps] 9,600 Max. [bps] 10,500,000 Control Algorithm PID Gear Type Cycloid Gear Material Metal Case Material Metal (Plastic Bottom) Dimensions (WⅹHⅹD) [mm] D80 x 100.1 Dimensions (WⅹHⅹD) [inch] D3.14 x 3.94 Weight [g] 1,550.00 Weight [oz] 54.67 Gear Ratio 51:1 Backlash [arcmin] < 3.0 Backlash [deg] - Command Signal Digital Packet Protocol Type Half duplex Asynchronous Serial Communication (8bit, 1stop, No Parity) Link (Physical) RS-485 Multidrop Bus ID 0 ~ 252 Feedback Position, Velocity, Current, Temperature, Voltage, etc Protocol version Protocol 2.0 Operating Mode / Angle Current Control mode:Endless turnVelocity Control mode:Endless turnPosition Control Mode : ±2,570 [Rev] Output [W] 230 Standby Current [mA] 40 * ) *Continuous operation: Please refer to the performance curve for details including torque and contact us separately in a long-term use environment. Link ○ e-Manual ○ Drawing ○ Software (DYNAMIXEL Wizard 2.0) ○ Selection Guide ○ DYNAMIXEL SDK Description Shipping Return/Refund Policy Related Items 1. All international orders are processed via DHL from KOREA (not USA) unless otherwise requested.2. Orders are normally processed within a 2 week time period. A lead time is applicable for certain items. (Normally ships out within 3 working days when in stock).3. If multiple orders are placed on the same day, they will be shipped in the same package, unless requested to ship separately by order. If an error is discovered in your order that requires change or cancellation, please contact us immediately. We will not be held responsible for any costs that may arise due to your negligence.4. Please note that destination charges (import tax, customs duty, etc.) are not included in the shipping charges. We will not be able to calculate or pre-pay this fee for you.5. If an order is placed and the payment is not settled within 14 days, it will automatically be cancelled. If necessary, please re-place the order and make the payment in a timely manner.6. We recommend you to insure your orders to avoid lost or damaged shipments which is 1% from the total invoice value. We will not be held responsible for lost or damaged shipments.
YM080-230-A051-RH is an all-in-one robot actuator with a built-in cycloidal reducer, specifically the DYNAMIXEL DRIVE (DYD) DYD-17H-051 model. DYNAMIXEL DRIVE (DYD) cannot be replaced after purchasing the product. Features High Performance Frameless Motor with Hollow Shaft Torque control based on current sensing PID control to enhance position, speed reliability and accuracy The integrated absolute magnetic encoder and replaceable battery allow multi-turn position information to be retained even after complete power-off (with back up battery). Metal housing for high durability Modular configuration makes it easy to create applications of varying degrees of freedom Package Components Products Qty. Note YM080-230-A051-RH 1 DYNAMIXEL-Y(R-option) Robot Cable-2P-X4P 600mm(Convertible) 1 RS485 2P-4P Cable(MOLEX-JST) Robot cable-2P 600mm 1 RS485 2P Cable(MOLEX-MOLEX) Cord End Terminal 4 For power connection Terminal Plug 2 For power connection Wrench Bolt WB M3X20 14 For shaft frame assembly Wrench Bolt WB M4x10 10 For frame assembly How to Connect a Multi-turn Backup Battery 1. Disconnect the power from the DYNAMIXEL-Y and release the locking bolt on the battery cover. 2. Open the battery cover. 3. Connect the battery cable. 4. Reattach the battery cover. 5. Tighten and secure the locking bolt of the battery cover. 6. Run DYNAMIXEL Wizard 2.0, and follow the battery replacement procedure. 7. Refer to the e-Manual for details (link) Drawing Drawing download Assembly guide Caution [Warning!] -Due to the material properties, rust may occur depending on the user environment. -Repairs due to rust may incur costs, so please refer to the following guidelines to prevent rust: Please take steps to reduce humidity and improve ventilation. Salt removal and anti-corrosion treatment should be performed on a regular basis. - Please be aware of different operational voltage from other DYNAMIXEL series (Operational voltage: 24V). - Please refer to the drawings provided online when combining with other power transmission products. - This product is designed as an integral unit; the cycloidal reducer and motor cannot be separated for individual use. - Please be cautious of overheating during prolonged high-speed usage. - Please use a frame that matches the screw length considering the depth of the tabs indicated in the drawing. - After purchasing the product, ensure to connect the multi-turn backup battery before use. - Please refer to the drawings when combined with various products such as reducers, linear actuators, and servo cylinders depending on the intended purpose. - For additional precautions, please refer to the e-manual. Specification Model Name YM080-230-A051-RH Series DYNAMIXEL Y MCU ARM Cortex-M4 (168 [Mhz], 32 [bit]) Input Voltage Min. [V] - Recommended [V] 24.0 Max. [V] - Performance Characteristics Voltage [V] 24.0 Stall Torque [N·m] - Stall Current [A] - No Load Speed [rpm] 62.0 No Load Current [A] - Continuous Operation *) Voltage [V] 24.0 Torque [N·m] 15.8 Speed [rpm] 39.0 Current [A] 12.6 Resolution Resolution [deg/pulse] 0.0000134636 Step [pulse/rev] 26,738,688 Angle [degree] 360 Position Sensor Contactless absolute encoder (19Bit, 360 [deg])Multi-turn (18Bit, 262,144 [rev], Battery back up) Operating Temperature Min. [°C] -5 Max. [°C] 55 Motor Frameless BLDC Baud Rate Min. [bps] 9,600 Max. [bps] 10,500,000 Control Algorithm PID Gear Type Cycloid Gear Material Metal Case Material Metal (Plastic Bottom) Dimensions (WⅹHⅹD) [mm] D80 x 100.1 Dimensions (WⅹHⅹD) [inch] D3.14 x 3.94 Weight [g] 1,550.00 Weight [oz] 54.67 Gear Ratio 51:1 Backlash [arcmin] < 3.0 Backlash [deg] - Command Signal Digital Packet Protocol Type Half duplex Asynchronous Serial Communication (8bit, 1stop, No Parity) Link (Physical) RS-485 Multidrop Bus ID 0 ~ 252 Feedback Position, Velocity, Current, Temperature, Voltage, etc Protocol version Protocol 2.0 Operating Mode / Angle Current Control mode:Endless turnVelocity Control mode:Endless turnPosition Control Mode : ±2,570 [Rev] Output [W] 230 Standby Current [mA] 40 * ) *Continuous operation: Please refer to the performance curve for details including torque and contact us separately in a long-term use environment. Link ○ e-Manual ○ Drawing ○ Software (DYNAMIXEL Wizard 2.0) ○ Selection Guide ○ DYNAMIXEL SDK Description Shipping Return/Refund Policy Related Items 1. All international orders are processed via DHL from KOREA (not USA) unless otherwise requested.2. Orders are normally processed within a 2 week time period. A lead time is applicable for certain items. (Normally ships out within 3 working days when in stock).3. If multiple orders are placed on the same day, they will be shipped in the same package, unless requested to ship separately by order. If an error is discovered in your order that requires change or cancellation, please contact us immediately. We will not be held responsible for any costs that may arise due to your negligence.4. Please note that destination charges (import tax, customs duty, etc.) are not included in the shipping charges. We will not be able to calculate or pre-pay this fee for you.5. If an order is placed and the payment is not settled within 14 days, it will automatically be cancelled. If necessary, please re-place the order and make the payment in a timely manner.6. We recommend you to insure your orders to avoid lost or damaged shipments which is 1% from the total invoice value. We will not be held responsible for lost or damaged shipments.
価格の推移
観測日ごとに平均した、1日あたり1つのデータポイント。
USDでの金額
記録されたすべての販売価格を対象に、UTCの日ごとの平均を算出しています。
Robotis
£2,232.71
Robotis
£1,999.50
Robotis
£1,999.50
Robotis
£2,215.05
Robotis
1,838.95 €

Robotis
$1,629.09

Robotis
$1,933.61

Robotis
$1,908.31
Robotis
3,291.60 €
Robotis
1,540.95 €
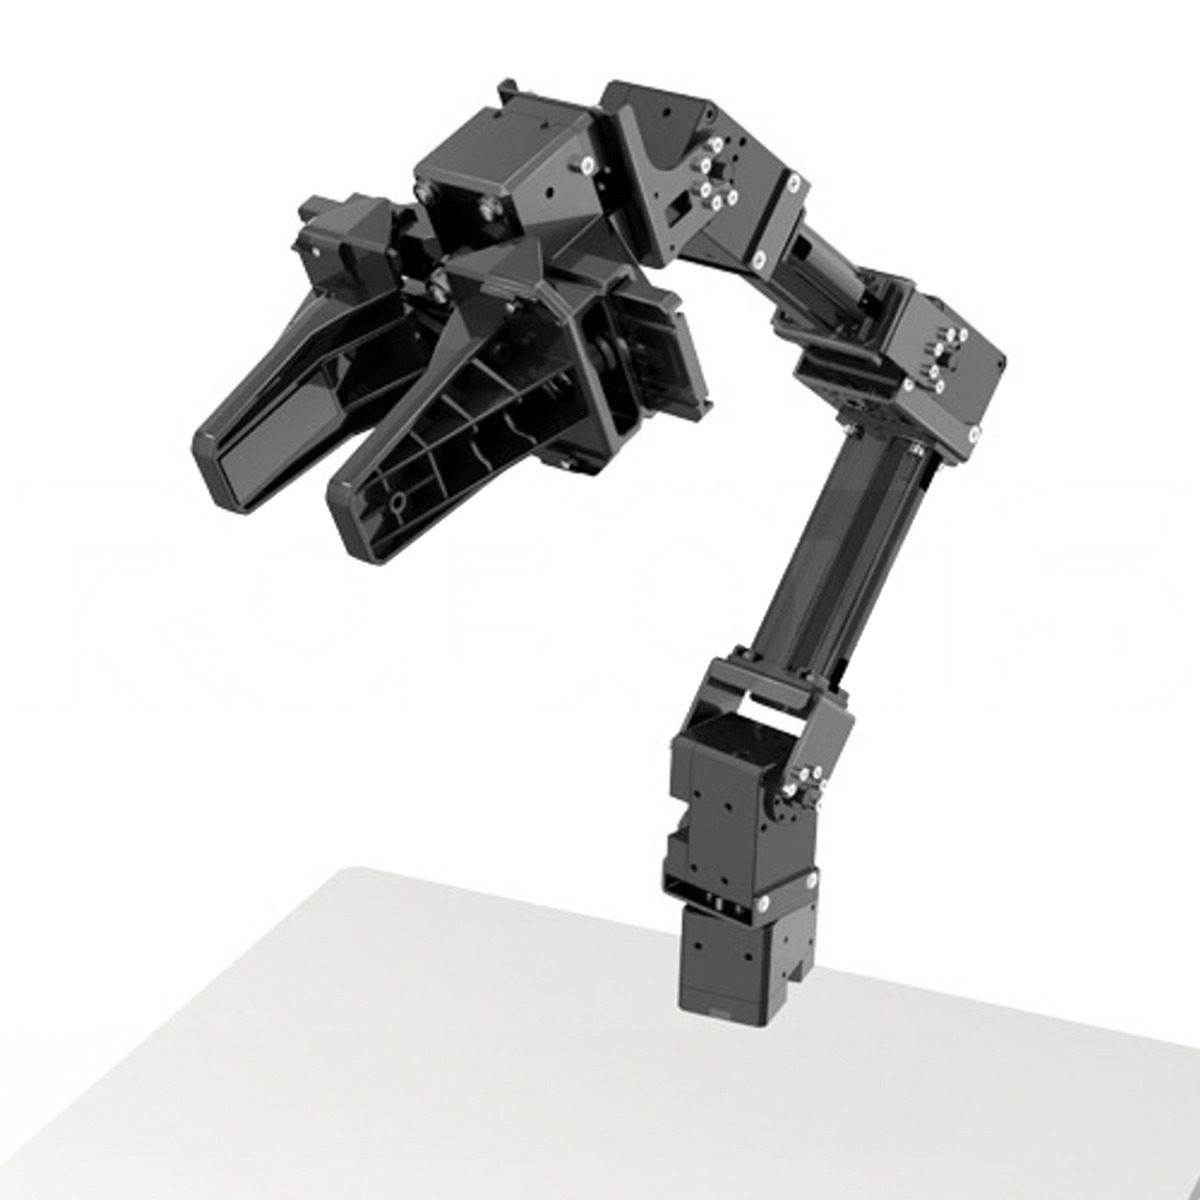
Robotis
£1,118.42
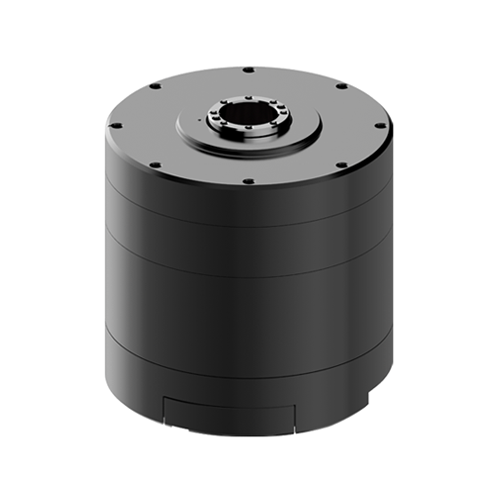
Robotis
£1,250.61
🍪 クッキーの設定
パフォーマンスを測定するためにクッキーを使用しています。 プライバシーポリシー