日ごとの平均価格
USDでの金額
説明
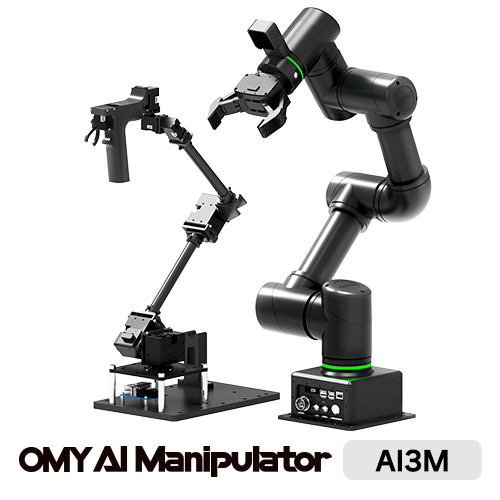
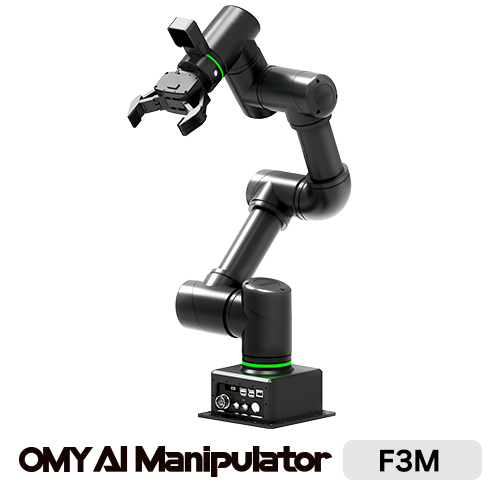
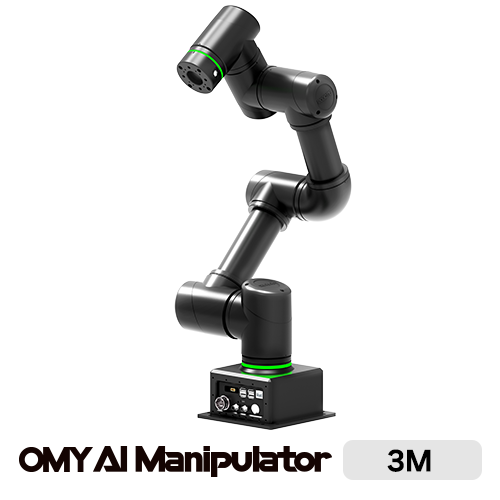
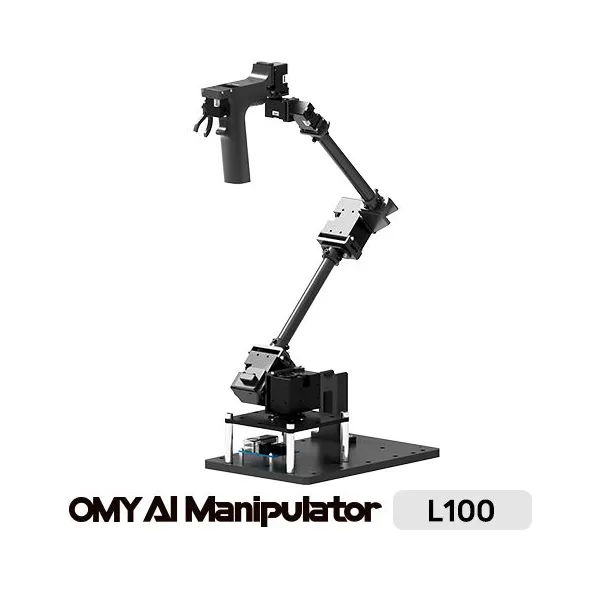
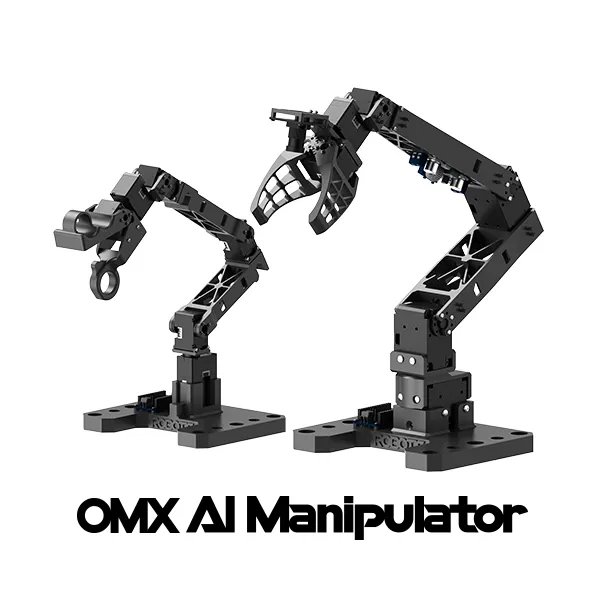
Features Physical Al Providing convenient data collection processes using the Physical Al Tool. Reducing model training preparation time through quick and easy data management. Supporting model training and inference examples to help machine learning and inference processes. Convenience Minimize operator fatigue through gravity and friction compensation, and spring effect features. Adopting built-in collision avoidance feature to Prevent operator injury and robot damage through. Delivering smooth acceleration and deceleration during operation with the time-based trajectory profile function. OpenSource Platform Delivering perfect compatibility with ROS2 and open-source support. Offering various packages and simulators (e.g., Movelt 2, Gazebo). Supporting development convenience through a dedicated OMY Control GUI. Specification Items OMY-L100 (Leader) OMY-F3M (Follower) DOF 7 6 Payload - 3 [kg] Reach 560 [mm] 580 [mm] Weight 1.46 [kg] 13.5 [kg] Operating Voltage 12 [VDC] 24 [VDC] Joint Resolution -π(rad) ~ π(rad), -2,048 ~ 2,048 [pulse/rev] -π(rad) ~ π(rad), -262,144 ~ 262,144 [pulse/rev] Joint Range Joint 1: ±180° Joint 2: -70º ~ +100° Joint 3,4,5,6: ±180° Joint 7: -90° ~ +60º Joint 1,2: ±360° Joint 3: ±150° Joint 4,5,6: ±360° DYNAMIXEL-Y Specification Joint 1,2,3: XH540-W150 Joint 4,5,6: XC330-T288 Joint 7: XC330-T181 Joint 1,2: YM080-230-A099-RH Joint 3,4,5,6: YM070-210-A099-RH Repeatability - ±0.05 [mm] Brake Force - 200% of the continuous torque for each joint TCP Speed -
Features Physical Al Providing convenient data collection processes using the Physical Al Tool. Reducing model training preparation time through quick and easy data management. Supporting model training and inference examples to help machine learning and inference processes. Convenience Minimize operator fatigue through gravity and friction compensation, and spring effect features. Adopting built-in collision avoidance feature to Prevent operator injury and robot damage through. Delivering smooth acceleration and deceleration during operation with the time-based trajectory profile function. OpenSource Platform Delivering perfect compatibility with ROS2 and open-source support. Offering various packages and simulators (e.g., Movelt 2, Gazebo). Supporting development convenience through a dedicated OMY Control GUI. Specification Items OMY-L100 (Leader) OMY-F3M (Follower) DOF 7 6 Payload - 3 [kg] Reach 560 [mm] 580 [mm] Weight 1.46 [kg] 13.5 [kg] Operating Voltage 12 [VDC] 24 [VDC] Joint Resolution -π(rad) ~ π(rad), -2,048 ~ 2,048 [pulse/rev] -π(rad) ~ π(rad), -262,144 ~ 262,144 [pulse/rev] Joint Range Joint 1: ±180° Joint 2: -70º ~ +100° Joint 3,4,5,6: ±180° Joint 7: -90° ~ +60º Joint 1,2: ±360° Joint 3: ±150° Joint 4,5,6: ±360° DYNAMIXEL-Y Specification Joint 1,2,3: XH540-W150 Joint 4,5,6: XC330-T288 Joint 7: XC330-T181 Joint 1,2: YM080-230-A099-RH Joint 3,4,5,6: YM070-210-A099-RH Repeatability - ±0.05 [mm] Brake Force - 200% of the continuous torque for each joint TCP Speed -
価格の推移
観測日ごとに平均した、1日あたり1つのデータポイント。
USDでの金額
記録されたすべての販売価格を対象に、UTCの日ごとの平均を算出しています。

Robotis
$17,248.85

Robotis
$11,498.85
Robotis
13,923.95 €
Robotis
£9,313.13

Robotis
$14,373.85
Robotis
15,549.95 €
Robotis
£7,420.21

Robotis
$16,176.02
Robotis
17,272.96 €
Robotis
894.92 €
Robotis
3,291.60 €
Robotis
444 €
🍪 クッキーの設定
パフォーマンスを測定するためにクッキーを使用しています。 プライバシーポリシー