日ごとの平均価格
USDでの金額
説明
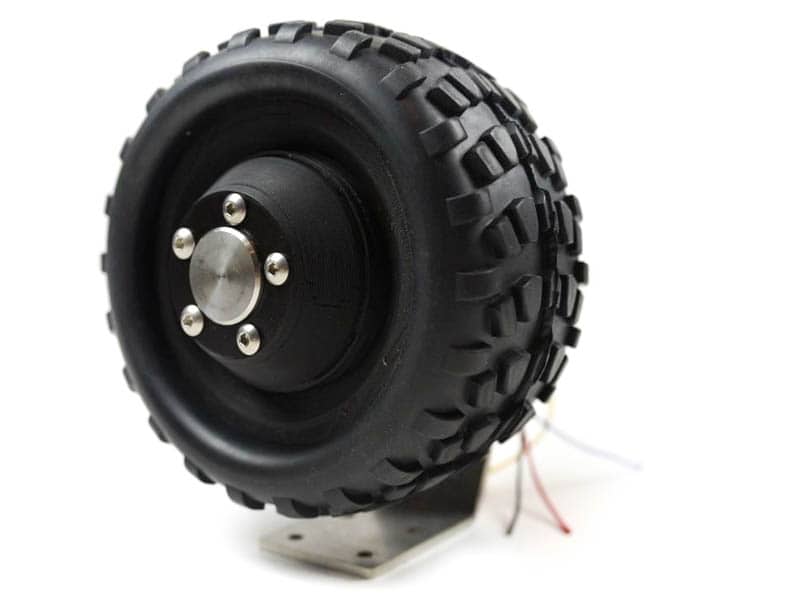
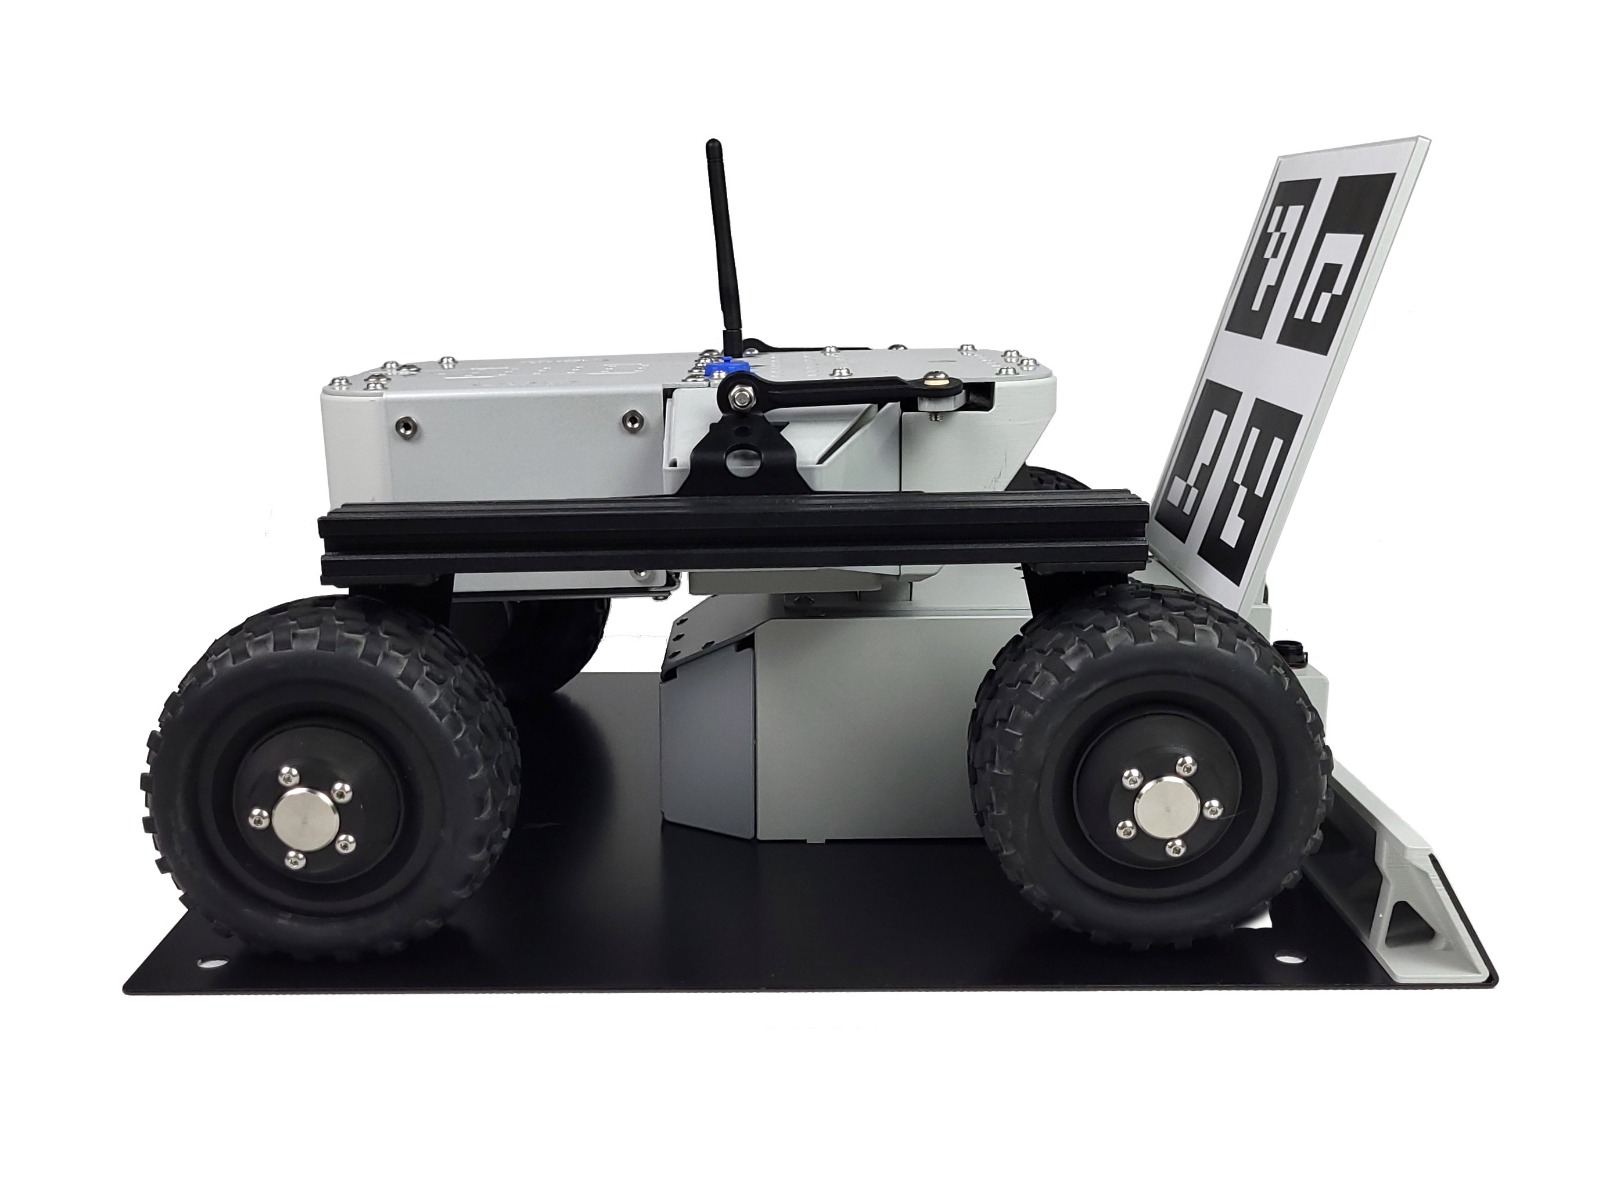
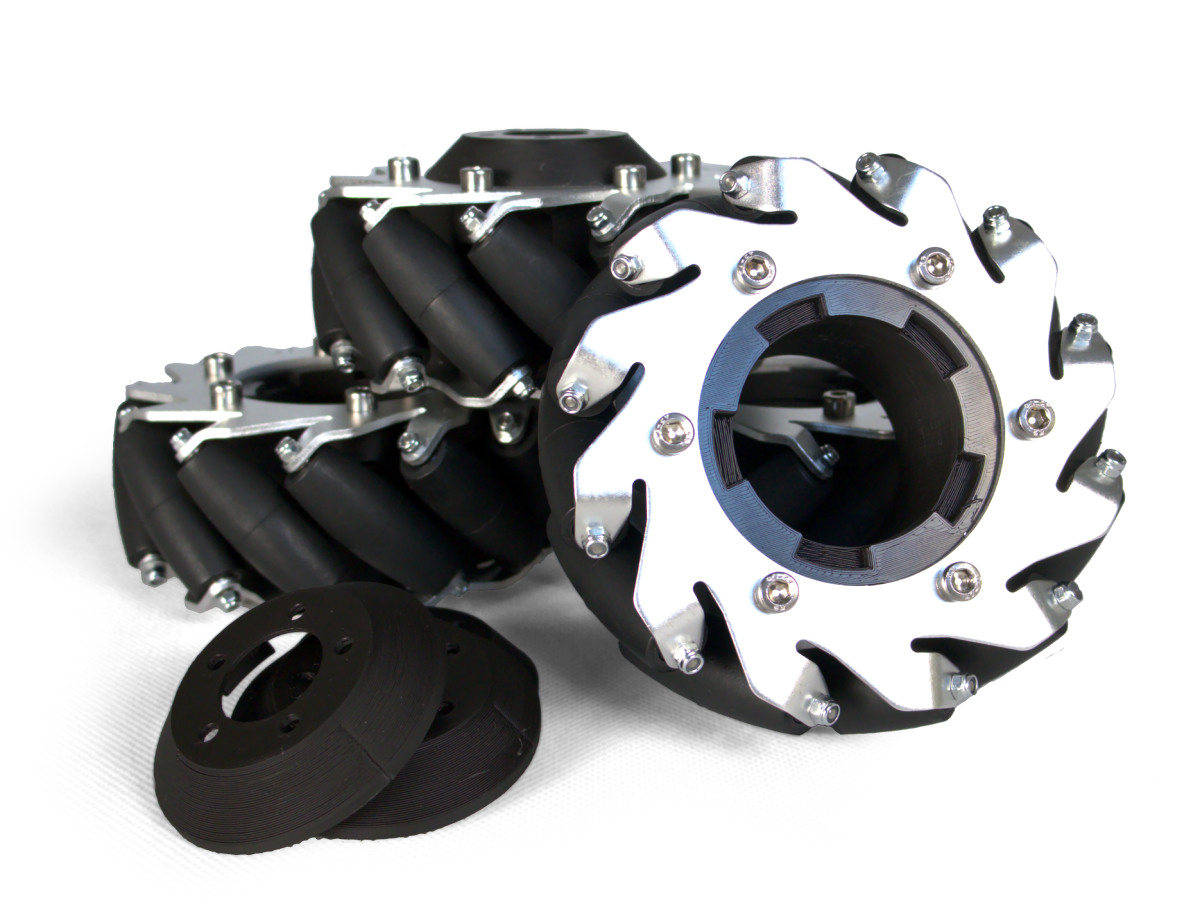
Wheel motors Buehler Motors 1.61.077.414 Leo Rover uses Buehler motors as the wheels actuators. Here you have all the useful resources listed in case you need to access the motors specifications. Buehler Motors 1.61.077.414 Specification CAD model Parameters: 12V DC motor with 12 CPR magnetic encoder Motor specifications: 1 Nm, 40 RPM rated speed, planetary 3-stage gearbox with 73.1:1 ratio - see more CNC-machined hub and motor tube, 3D-printed rim, torque plate and wheel mounts, rubber tire, 2x ball bearings Prepared with 10cm 2x power wires and 4x encoder wires Sealed with rubber seals to comply with IP66 protection rate Provided with 2x M5 mounting holes that fit Rover Scarecrow (The wheel stand is not included) Pololu Romi 12 CPR magnetic encoders Connection: Encoder Pin Mating Connection M1 negative (-) pole of the motor & OUTA of Core2ROS M2 positive (+) pole of the motor & OUTB of Core2ROS VCC +5V pin of Core2-ROS OUT A ENC A on Core2-ROS OUT B ENC B on Core2-ROS GND GND pin of Core2-ROS Dimension drawings Mind the encoder magnets are modified to fit Buehler Motors shaft. Internal hole is redrilled to 3 mm (instead of 1.5 mm). Drawings CAD models - Romi Encoder Pair Kit, 12 CPR, 3.5-18V Wheel tires Tire specifications Inner rim diameter: 2.8" Outer diameter: ~ 125 mm Width: ~ 70 mm Typically described as for 1/10 scale Monster Truck RC vehicles The dimensions may vary +- 10mm with no compatibility issues, remember the tires are made of rubber, they can stretch. You can always look for different outer diameter tires, but it will change the rover's speed and force (slope/climbing ability). You can as well find different rubber compounds: softer or tougher ones. Keep in mind that softer compounds will affect Leo Rover's turning resistance, but on the other hand, will help climbing obstacles. Higher outer diameter = higher speed & lower force Lower outer diameter = lower speed & higher force It's always a matter of compromise. How to assemble: Assembly manuals: Task 1: Wheel assembly Rover Wheel v.2.0 is used in newest Leo Rovers v.1.6. Now you can use the design in your own projects with no need of getting the whole Rover. The wheel is provided as a kit - super easy to build with only basic tools needed.
Wheel motors Buehler Motors 1.61.077.414 Leo Rover uses Buehler motors as the wheels actuators. Here you have all the useful resources listed in case you need to access the motors specifications. Buehler Motors 1.61.077.414 Specification CAD model Parameters: 12V DC motor with 12 CPR magnetic encoder Motor specifications: 1 Nm, 40 RPM rated speed, planetary 3-stage gearbox with 73.1:1 ratio - see more CNC-machined hub and motor tube, 3D-printed rim, torque plate and wheel mounts, rubber tire, 2x ball bearings Prepared with 10cm 2x power wires and 4x encoder wires Sealed with rubber seals to comply with IP66 protection rate Provided with 2x M5 mounting holes that fit Rover Scarecrow (The wheel stand is not included) Pololu Romi 12 CPR magnetic encoders Connection: Encoder Pin Mating Connection M1 negative (-) pole of the motor & OUTA of Core2ROS M2 positive (+) pole of the motor & OUTB of Core2ROS VCC +5V pin of Core2-ROS OUT A ENC A on Core2-ROS OUT B ENC B on Core2-ROS GND GND pin of Core2-ROS Dimension drawings Mind the encoder magnets are modified to fit Buehler Motors shaft. Internal hole is redrilled to 3 mm (instead of 1.5 mm). Drawings CAD models - Romi Encoder Pair Kit, 12 CPR, 3.5-18V Wheel tires Tire specifications Inner rim diameter: 2.8" Outer diameter: ~ 125 mm Width: ~ 70 mm Typically described as for 1/10 scale Monster Truck RC vehicles The dimensions may vary +- 10mm with no compatibility issues, remember the tires are made of rubber, they can stretch. You can always look for different outer diameter tires, but it will change the rover's speed and force (slope/climbing ability). You can as well find different rubber compounds: softer or tougher ones. Keep in mind that softer compounds will affect Leo Rover's turning resistance, but on the other hand, will help climbing obstacles. Higher outer diameter = higher speed & lower force Lower outer diameter = lower speed & higher force It's always a matter of compromise. How to assemble: Assembly manuals: Task 1: Wheel assembly
価格の推移
観測日ごとに平均した、1日あたり1つのデータポイント。
USDでの金額
記録されたすべての販売価格を対象に、UTCの日ごとの平均を算出しています。
Leo Rover
£154.50
Leo Rover
£179.58
Leo Rover
238.16 €

Leo Rover
£248.25
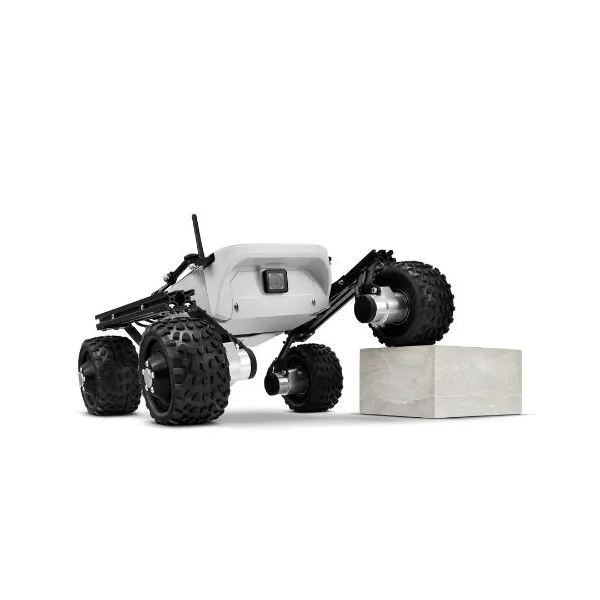
Leo Rover
5,758.80 €
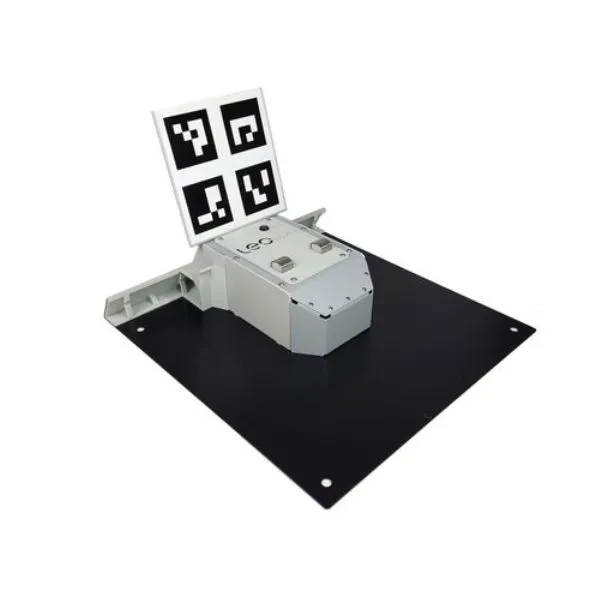
Leo Rover
1,332 €
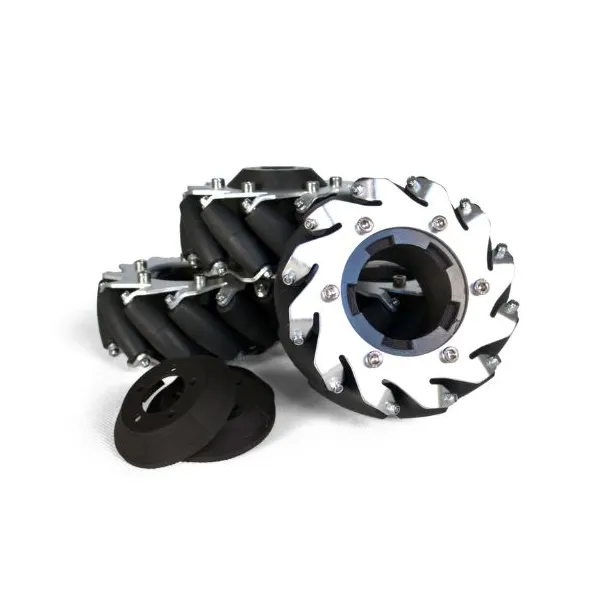
Leo Rover
618 €
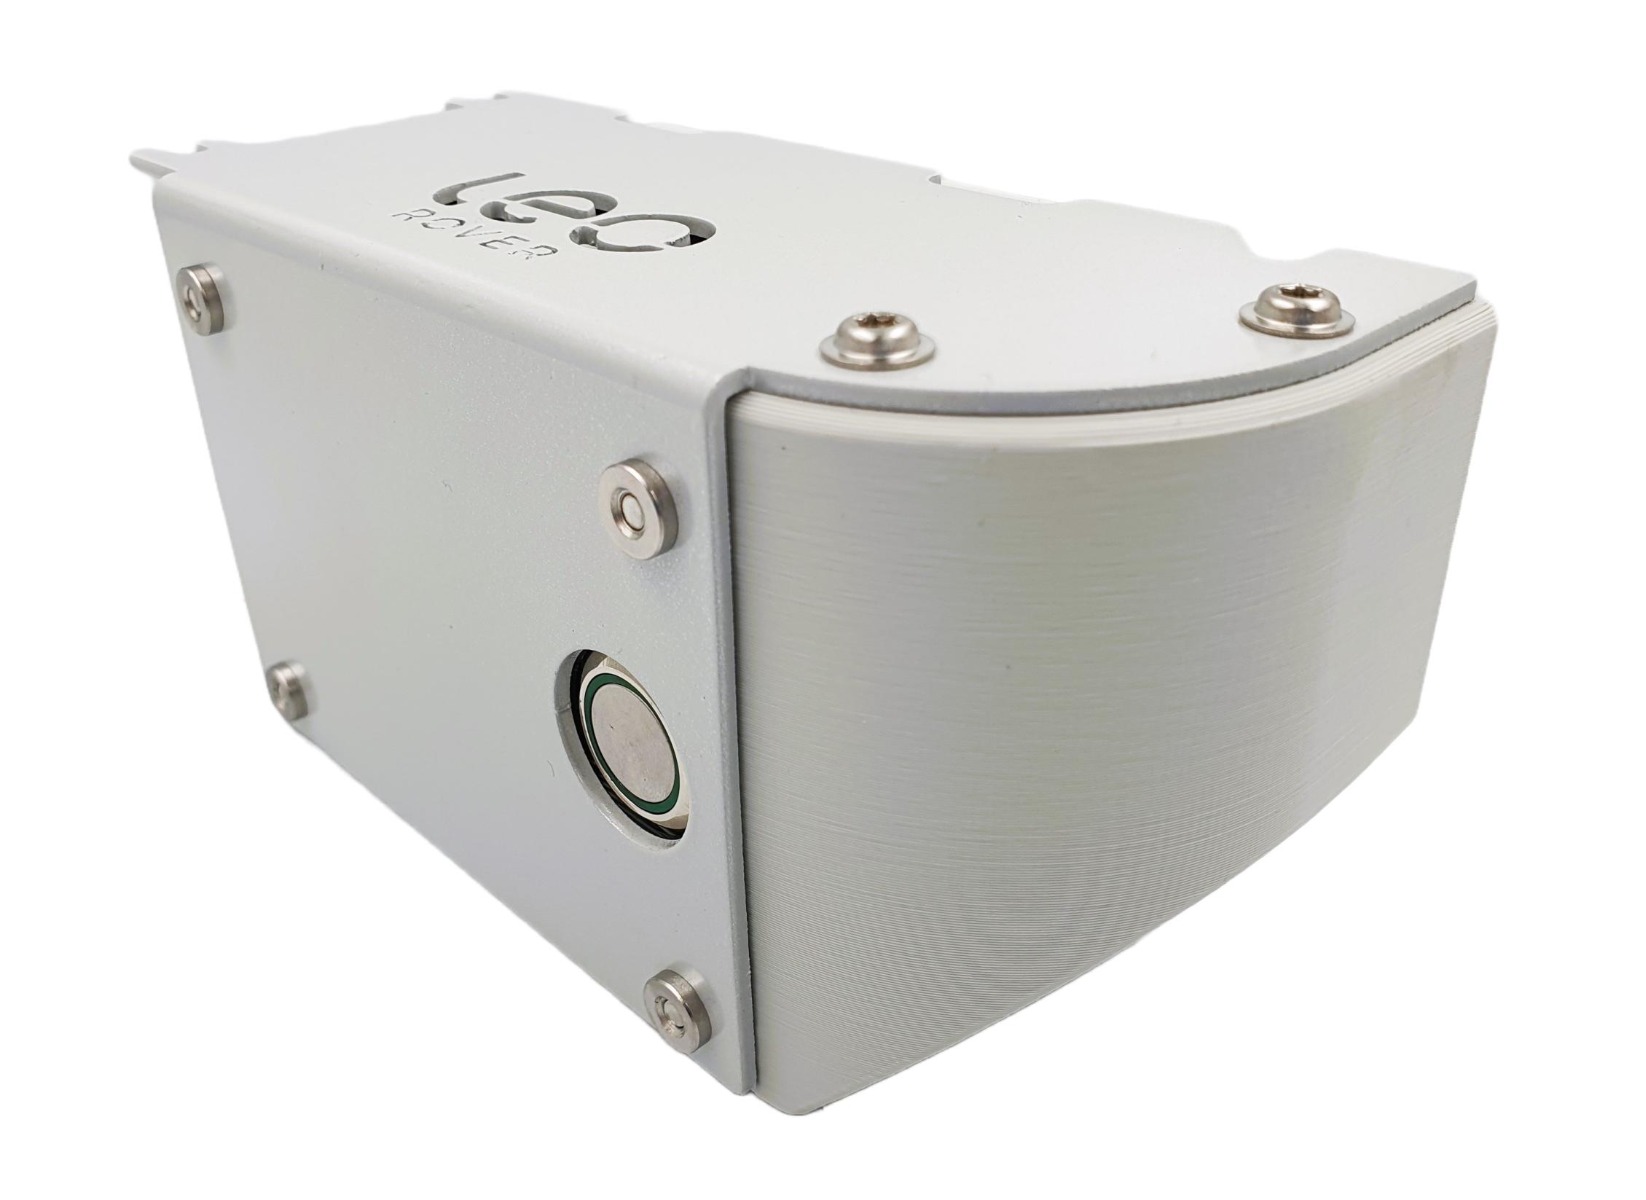
Leo Rover
£664
Leo Rover
£831
Leo Rover
£381.92

xTool
$149

xTool
$149
🍪 クッキーの設定
パフォーマンスを測定するためにクッキーを使用しています。 プライバシーポリシー