Tutkimusjulkaisut

Selkokielisiä tiivistelmiä uusimmasta robotiikan tutkimuksesta – humanoidiroboteista, nelijalkaisista roboteista, teollisuusautomaatiosta ja tekoälystä.
499 julkaisua
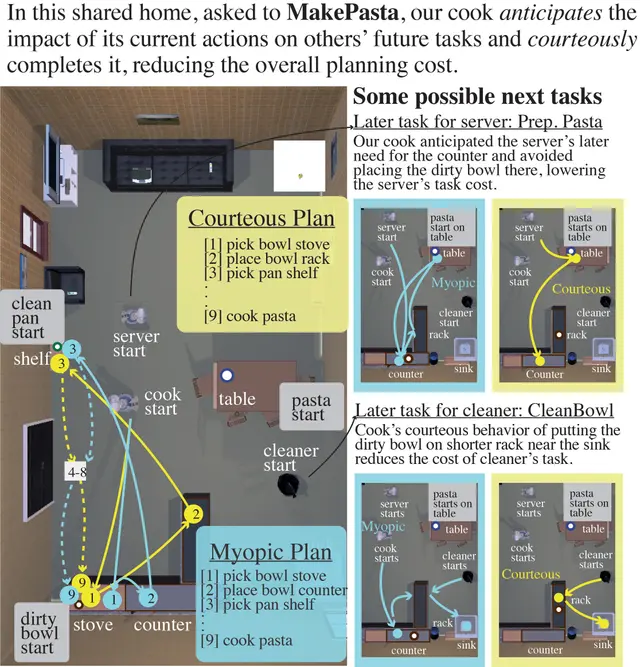
Courteous Anticipation Lets Robots Plan Better in Shared Spaces Without Conflict
AI26.7.

Courteous Anticipation Lets Robots Plan Better in Shared Spaces Without Conflict

A framework for reducing cumulative task costs in persistent shared environments by planning courteously around other robots' anticipated needs.

Md Ridwan Hossain Talukder, Roshan Dhakal, Elizabeth Phillips, Gregory J. Stein

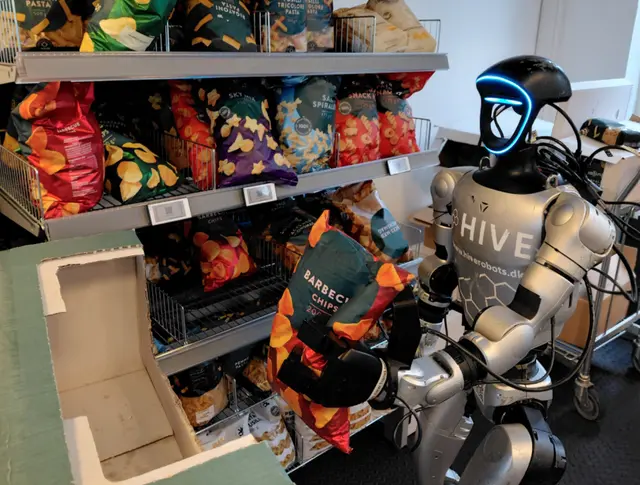
A Data-Efficient Framework for Deploying Retail Humanoid Robots in the Real World
Humanoid25.7.

A Data-Efficient Framework for Deploying Retail Humanoid Robots in the Real World

A systems-level framework for deploying VLA-based humanoids in real retail settings demonstrates that data quality matters more than data volume.

Roger Sala Sisó, Tiago Silvério, Jakob Sand +1

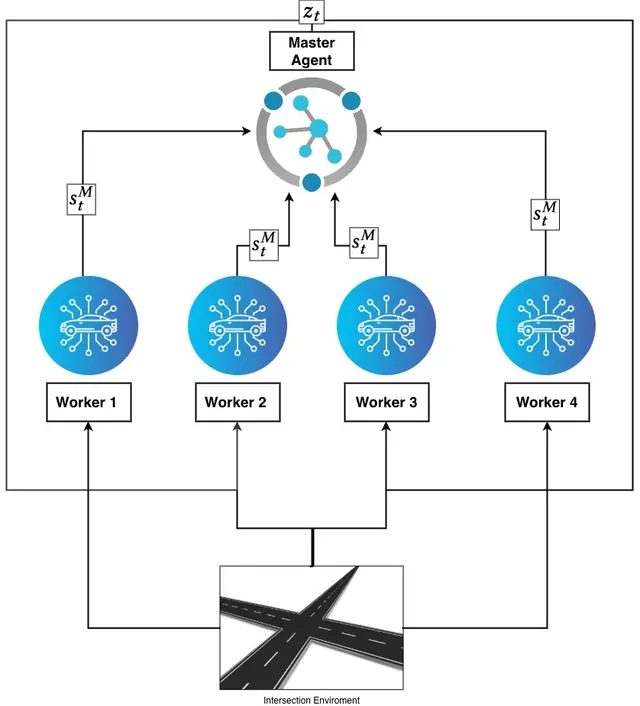
Zero-Collision Intersection Navigation via Compact Latent Coordination
AI25.7.

Zero-Collision Intersection Navigation via Compact Latent Coordination

Researchers at Ben-Gurion University developed MAPS, a hierarchical deep reinforcement learning architecture that enables autonomous vehicles to navigate uns…

Gil Lifshits, Igal Bilik, Gilad Katz

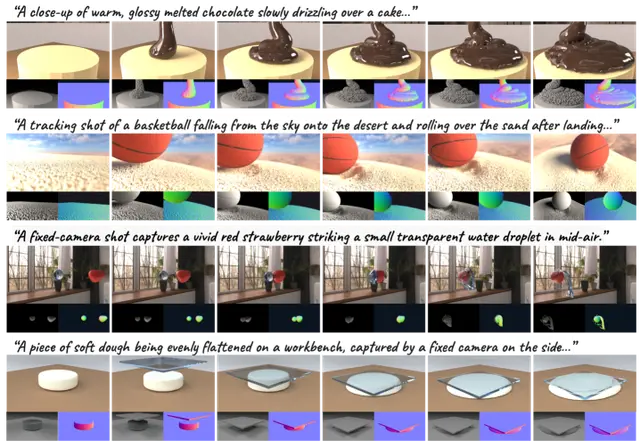
Multi-Agent Framework Generates 4D Physical Worlds From Natural Language
AI25.7.

Multi-Agent Framework Generates 4D Physical Worlds From Natural Language

Hongxin Zhang, Chunru Lin, Junyan Li +3

Why Robots Forget Answers: Memory Bottlenecks in Sequential Embodied QA
Robotics24.7.

Why Robots Forget Answers: Memory Bottlenecks in Sequential Embodied QA

Zikui Cai, Kaushal Janga, Tan Dat Dao +15

How to Train Robots That Actually Handle Novel Tasks: A Bias-Aware Data Strategy
Robotics24.7.

How to Train Robots That Actually Handle Novel Tasks: A Bias-Aware Data Strategy

Yu Qi, Zhang Ye, Xinyi Xu +6

A Growable Community-Driven Data Engine for Scalable Robot Manipulation
Robotics24.7.

A Growable Community-Driven Data Engine for Scalable Robot Manipulation

We present AXIS, a web-based, community-driven infrastructure for scalable manipulation data collection through browser-based MuJoCo-WASM teleoperation and a…

Mengfei Zhao, Dihong Huang, Yikai Tang +12

Distributed Motion Planning with Safety Guarantees for Self-Reconfiguring Robotic Boats
Robotics23.7.

Distributed Motion Planning with Safety Guarantees for Self-Reconfiguring Robotic Boats
Alejandro Gonzalez-Garcia, Wei Wang, Wei Xiao +4

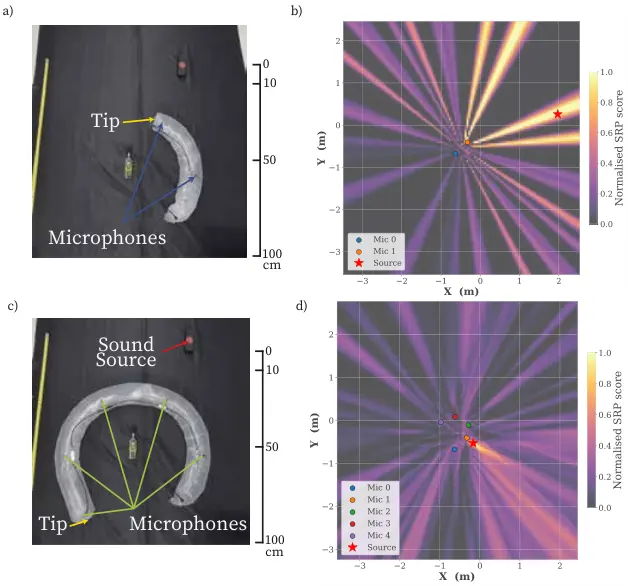
Soft Vine Robot Grows Microphone Array to Locate Sound Sources
Robotics23.7.

Soft Vine Robot Grows Microphone Array to Locate Sound Sources

Sebastian Lorca Godoy, Ciera McFarland, Michael Val +3

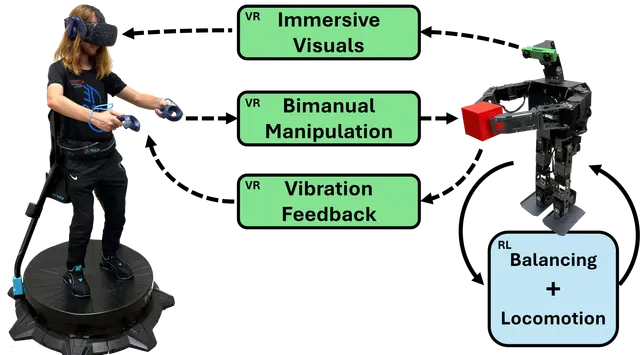
Miniature Humanoid Tele-Loco-Manipulation: VR Control + Reinforcement Learning
Humanoid23.7.

Miniature Humanoid Tele-Loco-Manipulation: VR Control + Reinforcement Learning

Researchers have created a complete system that lets an operator remotely control both the arms and legs of a miniature humanoid robot using a VR headset, ha…

Nicolas Kosanovic, Jordan Dowdy, Jean Chagas Vaz

No Training, Better Flights: Test-Time Scaling Makes Smarter UAV Navigation
drones22.7.

No Training, Better Flights: Test-Time Scaling Makes Smarter UAV Navigation

Test-time scaling lets VLMs generate and refine multiple flight plans at inference, achieving SOTA navigation without any retraining.

Feinan Cheng, Dongliang Xu, Wenli Nong +4

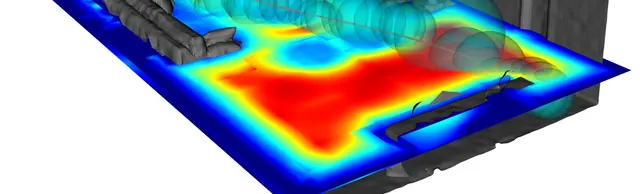
Real-Time Signed Distance Field Mapping and Fast Motion Planning for Drones
drones22.7.

Real-Time Signed Distance Field Mapping and Fast Motion Planning for Drones

Jason Stanley, Zhirui Dai, Qihao Qian +6

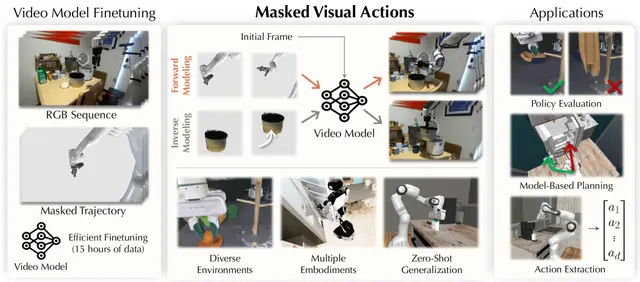
Masked Visual Actions Enable Robots to Learn World Models from Video
Robotics22.7.

Masked Visual Actions Enable Robots to Learn World Models from Video

Hadi Alzayer, Wenlong Huang, Haonan Chen +8

How Haptic Calibration and Visual Feedback Improve Humanoid Robot Grasping
Humanoid21.7.

How Haptic Calibration and Visual Feedback Improve Humanoid Robot Grasping

Low-cost calibration and visual feedback methods improve sim-to-real grasping for the NICO humanoid robot.

Juraj Gavura, Igor Farkaš

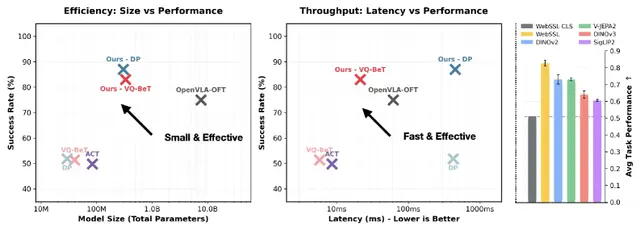
FM-VLA: Giving Robots a Sense of Touch Memory for Smarter Contact-Rich Tasks
Robotics21.7.

FM-VLA: Giving Robots a Sense of Touch Memory for Smarter Contact-Rich Tasks

Researchers have developed FM-VLA, a vision-language-action model that adds a dedicated force-based memory module, enabling robots to reason over sequences o…

Ruicheng Li, Qixiu Li, Ruichun Ma +8

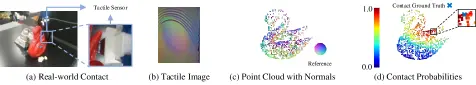
Patch Policy: Efficient Robot Control Through Dense Visual Patch Features
AI21.7.

Patch Policy: Efficient Robot Control Through Dense Visual Patch Features

Gaoyue Zhou, Zichen Jeff Cui, Ada Langford +3

VTLoc: How Robots Pinpoint Touch in 3D Space Using Vision and Feel
Robotics20.7.

VTLoc: How Robots Pinpoint Touch in 3D Space Using Vision and Feel

Zhiyuan Wu, Zhuo Chen, Shan Luo

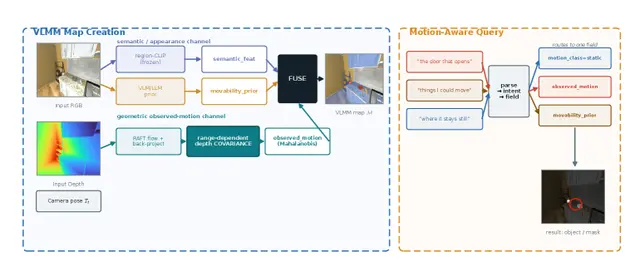
VLMM Gives Robots a New Way to Ask "Can I Move That?" in 3D Maps
Robotics20.7.

VLMM Gives Robots a New Way to Ask "Can I Move That?" in 3D Maps

Researchers have built a mapping system that adds a motion attribute to open-vocabulary 3D scene maps, letting robots query whether objects are movable, stat…

Dibyendu Ghosh, Ayushi Shakya

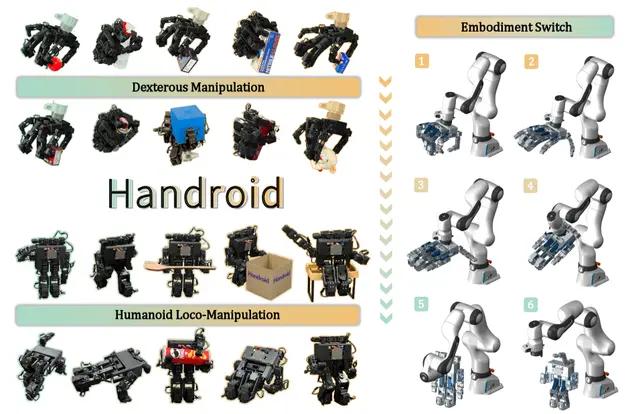
Handroid: A Desktop Robot That Switches Between Hand and Humanoid
Humanoid20.7.

Handroid: A Desktop Robot That Switches Between Hand and Humanoid

Handroid is a 27-DoF desktop robot that reconfigures from a dexterous hand into a humanoid, achieving 72% grasp success and stable locomotion.

Ruogu Li, Chenyang Ma, Sikai Li +6

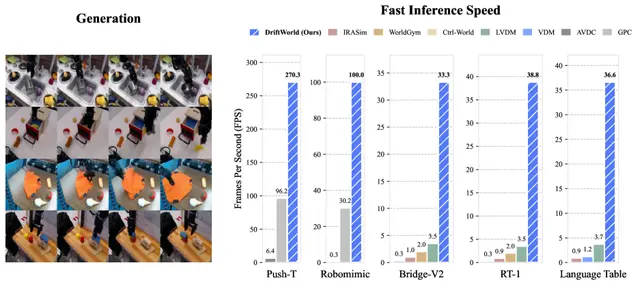
DriftWorld: Fast World Modeling Through Drifting
AI19.7.

DriftWorld: Fast World Modeling Through Drifting

Susie Lu, Haonan Chen, Weirui Ye +1