میانگین روزانهٔ قیمت
مبالغ به USD


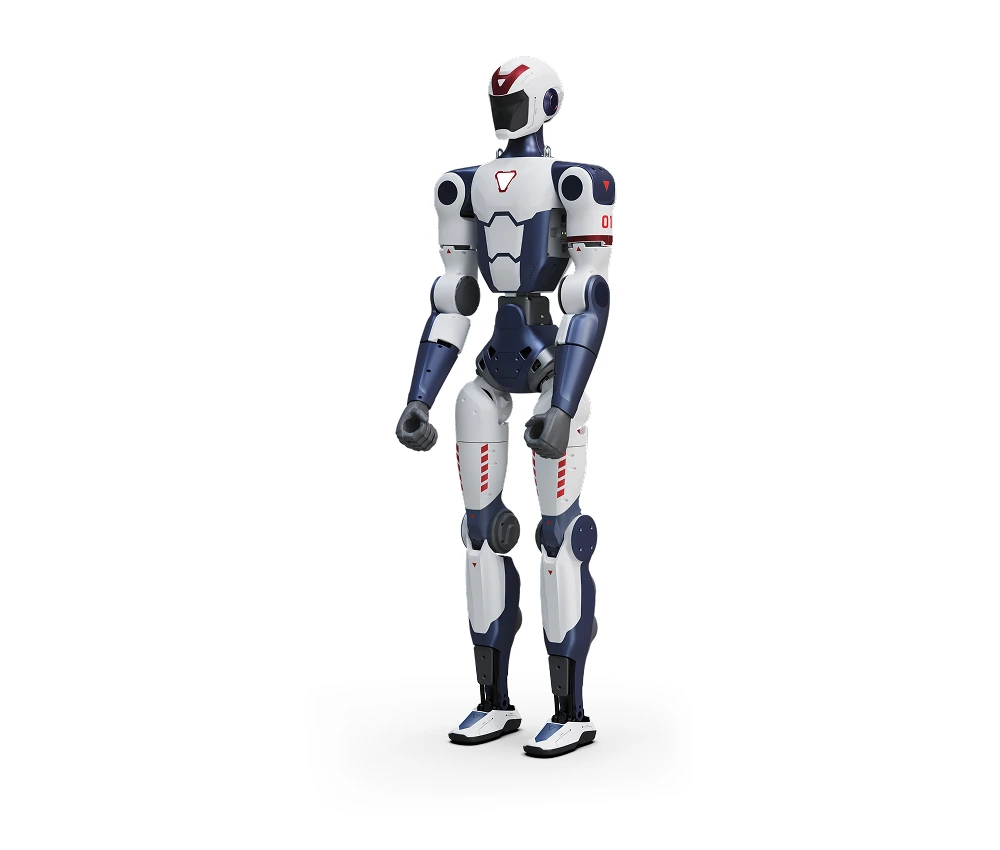
Mobile-Base Dual-Arm Humanoid Robot with Dex1-1 V2 Parallel Grippers. 16 DOF, Orin Nano 40 TOPS, MID360 LiDAR, stereo vision & full-stack open SDK. The entry-level platform for mobile manipulation research.

R1-A5-D Smart A — mobile-base humanoid with Dex1-1 V2 parallel grippers, MID360 LiDAR & stereo vision
The R1-A5-D Smart A is the entry point into mobile humanoid research. It pairs the R1-A5-D autonomous mobile base — complete with MID360 LiDAR, stereo vision, and a removable chassis battery — with Dex1-1 V2 parallel grippers for reliable pick-and-place. The built-in Orin Nano 40 TOPS handles onboard navigation, perception, and control without external compute.
The Dex1-1 V2 is a proven two-finger parallel gripper designed for consistency and durability. Its simple, robust mechanism delivers repeatable grasping force for a wide range of industrial and research objects — from small electronic components to medium-weight boxes. Pre-installed on both arms, it turns the R1-A5-D into a capable mobile manipulator for logistics, laboratory automation, and introductory robotics research.

Dex1-1 V2 parallel grippers — robust, repeatable, and ready for mobile pick-and-place
The R1-A5-D chassis adds 3 degrees of freedom to the upper body: a telescopic pillar for height adjustment and a 2-DOF wheeled base for omnidirectional navigation. Combined with the MID360 LiDAR and stereo camera head, the robot builds real-time maps, plans paths, and avoids obstacles autonomously — then stops precisely to manipulate. The removable lithium-ion battery in the chassis delivers approximately 1.5 hours of untethered operation.
Smart A processes data from two complementary sensors: a MID360 360° LiDAR for metrically accurate mapping and long-range obstacle detection, and a binocular camera head (146°×124° FOV, 60 mm baseline) for colour vision, object recognition, and depth estimation. Fused on the Orin Nano 40 TOPS, this dual-modality perception stack supports research in visual-LiDAR SLAM, semantic navigation, and active perception for mobile manipulation.
The built-in NVIDIA Jetson Orin Nano delivers 40 TOPS of AI compute, running SLAM, path planning, object detection, and arm trajectory generation locally. No external GPU server, no cloud dependency — just power on and deploy. The module is pre-installed and thermally integrated with the chassis cooling system.
A binocular camera head delivers a 146° × 124° field of view with a 60 mm stereo baseline for scene-level understanding. RGB streams at 1280×720@30 Hz and depth at 544×448@10 Hz. Combined with the MID360 LiDAR, the R1-A5-D Smart A offers a complete perception stack for research in visual-LiDAR fusion, semantic navigation, and mobile manipulation.
Four-array beamforming microphones and dual 3 W speakers enable clear voice capture and synthesis in noisy labs, warehouses, or classrooms. The open audio framework supports custom wake words, multilingual TTS, and integration with LLMs for conversational command-and-control — even while the base is in motion.
At 683 × 520 × 440 mm collapsed (1323 mm elevated), the R1-A5-D Smart A navigates standard doorways, elevators, and lab aisles. The telescopic pillar lowers the upper body for transport and raises it for manipulation. At approximately 30 kg with battery, it is a self-contained mobile research platform — no external compute rack, no tether cables during operation.

Collapsed (683 mm) and elevated (1323 mm) configurations for navigation and manipulation
Unitree provides a mature, Linux-based robot development framework with open APIs for the underlying system, robotic arms, mobile base, audio, lighting, and visual control. ROS 2 native support, dual encoders on every arm joint, and hollow internal wiring make the R1-A5-D Smart A a clean slate for reinforcement learning, mobile manipulation research, embodied AI, and autonomous navigation studies. The built-in Orin Nano 40 TOPS handles perception and planning locally without external hardware.
Smart A is the entry-level mobile configuration. Expand capability as your research evolves:
| Model | Unitree R1-A5-D Smart A (Mobile Base) |
| Dimensions (Collapsed) | 683 × 520 × 440 mm (H × W × D) |
| Dimensions (Elevated) | 1323 × 520 × 440 mm (H × W × D) |
| Weight (with Battery) | ~30 kg |
| Total DOF | 16 (Arm 5×2, Waist 1, Head 2, Pillar 1, Base 2) |
| Arm Reach | 420 mm (forearm + upper arm) |
| Peak Shoulder Torque | 60 Nm |
| Max Arm Payload | ~2 kg (posture-dependent) |
| End-Effector Precision | ±0.1 mm |
| End Effectors | Dex1-1 V2 parallel grippers (both arms, pre-installed) |
| Wrist Cameras | Not included (optional) |
| Vision | Binocular camera — RGB 1280×720@30 Hz, Depth 544×448@10 Hz, FOV 146°×124° |
| LiDAR | MID360 360° LiDAR (chassis-integrated) |
| Head Compute | 8-core high-performance CPU + 10 TOPS NPU |
| Body Compute | 8-core high-performance CPU |
| Onboard AI Compute | NVIDIA Jetson Orin Nano 40 TOPS (built-in) |
| Audio | 4-array microphone + dual 3 W speakers |
| Connectivity | Wi-Fi 6, Bluetooth 5.2, OTA updates |
| Power | Removable chassis Li-ion battery (~1.5 h) + external DC PSU. Upper body does not accept a battery. |
| SDK & Interfaces | Linux-based framework, ROS 2, open APIs for arm/base/audio/vision/lighting |
| Controllers | Standard dual-hand controllers included |
| Warranty | 12 months on the entire unit |
Every configuration shares the same R1-A5-D mobile base — the difference is the end effector. Choose the one that matches your research goals:
| Config | Hand | Features |
|---|---|---|
| Smart A | Dex1-1 V2 | Entry-level parallel grippers, Orin Nano 40 TOPS, MID360 LiDAR |
| Smart B | Dex3-1 (RGB) | 3-finger dexterous hand with wrist RGB camera |
| Smart C | Dex3-1 Tactile (RGB) | 3-finger hand with tactile sensors + wrist RGB camera |
| Smart D | BrainCo Revo 2 Basic (RGB) | 5-finger anthropomorphic hand with wrist RGB camera |
| Smart E | BrainCo Revo 2 Tactile (RGB) | 5-finger hand with tactile sensors + wrist RGB camera |
| Smart F | LinkerBot O6 (RGB) | 6-DOF dexterous hand with wrist RGB camera |
| Smart G | LinkerBot O6 Tactile (RGB) | 6-DOF hand with tactile sensors + wrist RGB camera |
| Smart H | Tendon-driven dexterous hand | Advanced tendon-driven mechanism for research-grade dexterity |
* Specifications are based on manufacturer data and may vary slightly by production batch. Optional wrist cameras, compute modules, and alternative end effectors sold separately.
Unitree® is a registered trademark of Unitree Robotics. Images are for reference; actual product appearance may differ.
Users must maintain a sufficient safety distance. This is a civilian robot — comply with local laws and regulations.
Mobile-Base Dual-Arm Humanoid Robot with Dex1-1 V2 Parallel Grippers. 16 DOF, Orin Nano 40 TOPS, MID360 LiDAR, stereo vision & full-stack open SDK. The entry-level platform for mobile manipulation research.
R1-A5-D Smart A — mobile-base humanoid with Dex1-1 V2 parallel grippers, MID360 LiDAR & stereo vision
The R1-A5-D Smart A is the entry point into mobile humanoid research. It pairs the R1-A5-D autonomous mobile base — complete with MID360 LiDAR, stereo vision, and a removable chassis battery — with Dex1-1 V2 parallel grippers for reliable pick-and-place. The built-in Orin Nano 40 TOPS handles onboard navigation, perception, and control without external compute.
The Dex1-1 V2 is a proven two-finger parallel gripper designed for consistency and durability. Its simple, robust mechanism delivers repeatable grasping force for a wide range of industrial and research objects — from small electronic components to medium-weight boxes. Pre-installed on both arms, it turns the R1-A5-D into a capable mobile manipulator for logistics, laboratory automation, and introductory robotics research.
Dex1-1 V2 parallel grippers — robust, repeatable, and ready for mobile pick-and-place
The R1-A5-D chassis adds 3 degrees of freedom to the upper body: a telescopic pillar for height adjustment and a 2-DOF wheeled base for omnidirectional navigation. Combined with the MID360 LiDAR and stereo camera head, the robot builds real-time maps, plans paths, and avoids obstacles autonomously — then stops precisely to manipulate. The removable lithium-ion battery in the chassis delivers approximately 1.5 hours of untethered operation.
Smart A processes data from two complementary sensors: a MID360 360° LiDAR for metrically accurate mapping and long-range obstacle detection, and a binocular camera head (146°×124° FOV, 60 mm baseline) for colour vision, object recognition, and depth estimation. Fused on the Orin Nano 40 TOPS, this dual-modality perception stack supports research in visual-LiDAR SLAM, semantic navigation, and active perception for mobile manipulation.
The built-in NVIDIA Jetson Orin Nano delivers 40 TOPS of AI compute, running SLAM, path planning, object detection, and arm trajectory generation locally. No external GPU server, no cloud dependency — just power on and deploy. The module is pre-installed and thermally integrated with the chassis cooling system.
A binocular camera head delivers a 146° × 124° field of view with a 60 mm stereo baseline for scene-level understanding. RGB streams at 1280×720@30 Hz and depth at 544×448@10 Hz. Combined with the MID360 LiDAR, the R1-A5-D Smart A offers a complete perception stack for research in visual-LiDAR fusion, semantic navigation, and mobile manipulation.
Four-array beamforming microphones and dual 3 W speakers enable clear voice capture and synthesis in noisy labs, warehouses, or classrooms. The open audio framework supports custom wake words, multilingual TTS, and integration with LLMs for conversational command-and-control — even while the base is in motion.
At 683 × 520 × 440 mm collapsed (1323 mm elevated), the R1-A5-D Smart A navigates standard doorways, elevators, and lab aisles. The telescopic pillar lowers the upper body for transport and raises it for manipulation. At approximately 30 kg with battery, it is a self-contained mobile research platform — no external compute rack, no tether cables during operation.
Collapsed (683 mm) and elevated (1323 mm) configurations for navigation and manipulation
Unitree provides a mature, Linux-based robot development framework with open APIs for the underlying system, robotic arms, mobile base, audio, lighting, and visual control. ROS 2 native support, dual encoders on every arm joint, and hollow internal wiring make the R1-A5-D Smart A a clean slate for reinforcement learning, mobile manipulation research, embodied AI, and autonomous navigation studies. The built-in Orin Nano 40 TOPS handles perception and planning locally without external hardware.
Smart A is the entry-level mobile configuration. Expand capability as your research evolves:
| Model | Unitree R1-A5-D Smart A (Mobile Base) |
| Dimensions (Collapsed) | 683 × 520 × 440 mm (H × W × D) |
| Dimensions (Elevated) | 1323 × 520 × 440 mm (H × W × D) |
| Weight (with Battery) | ~30 kg |
| Total DOF | 16 (Arm 5×2, Waist 1, Head 2, Pillar 1, Base 2) |
| Arm Reach | 420 mm (forearm + upper arm) |
| Peak Shoulder Torque | 60 Nm |
| Max Arm Payload | ~2 kg (posture-dependent) |
| End-Effector Precision | ±0.1 mm |
| End Effectors | Dex1-1 V2 parallel grippers (both arms, pre-installed) |
| Wrist Cameras | Not included (optional) |
| Vision | Binocular camera — RGB 1280×720@30 Hz, Depth 544×448@10 Hz, FOV 146°×124° |
| LiDAR | MID360 360° LiDAR (chassis-integrated) |
| Head Compute | 8-core high-performance CPU + 10 TOPS NPU |
| Body Compute | 8-core high-performance CPU |
| Onboard AI Compute | NVIDIA Jetson Orin Nano 40 TOPS (built-in) |
| Audio | 4-array microphone + dual 3 W speakers |
| Connectivity | Wi-Fi 6, Bluetooth 5.2, OTA updates |
| Power | Removable chassis Li-ion battery (~1.5 h) + external DC PSU. Upper body does not accept a battery. |
| SDK & Interfaces | Linux-based framework, ROS 2, open APIs for arm/base/audio/vision/lighting |
| Controllers | Standard dual-hand controllers included |
| Warranty | 12 months on the entire unit |
Every configuration shares the same R1-A5-D mobile base — the difference is the end effector. Choose the one that matches your research goals:
| Config | Hand | Features |
|---|---|---|
| Smart A | Dex1-1 V2 | Entry-level parallel grippers, Orin Nano 40 TOPS, MID360 LiDAR |
| Smart B | Dex3-1 (RGB) | 3-finger dexterous hand with wrist RGB camera |
| Smart C | Dex3-1 Tactile (RGB) | 3-finger hand with tactile sensors + wrist RGB camera |
| Smart D | BrainCo Revo 2 Basic (RGB) | 5-finger anthropomorphic hand with wrist RGB camera |
| Smart E | BrainCo Revo 2 Tactile (RGB) | 5-finger hand with tactile sensors + wrist RGB camera |
| Smart F | LinkerBot O6 (RGB) | 6-DOF dexterous hand with wrist RGB camera |
| Smart G | LinkerBot O6 Tactile (RGB) | 6-DOF hand with tactile sensors + wrist RGB camera |
| Smart H | Tendon-driven dexterous hand | Advanced tendon-driven mechanism for research-grade dexterity |
* Specifications are based on manufacturer data and may vary slightly by production batch. Optional wrist cameras, compute modules, and alternative end effectors sold separately.
Unitree® is a registered trademark of Unitree Robotics. Images are for reference; actual product appearance may differ.
Users must maintain a sufficient safety distance. This is a civilian robot — comply with local laws and regulations.

تاریخچهٔ قیمت
برای هر روز یک نقطهٔ داده؛ میانگینگیری بر اساس تاریخ مشاهده انجام شده است.
مبالغ به USD
میانگینها بر اساس همهٔ قیمتهای پیشنهادی ثبتشده در هر روزِ UTC محاسبه میشوند.
Unitree
$۱۱٬۲۹۰
Unitree
۱۰٬۵۹۹ €

Unitree
$۹٬۹۹۰

Unitree
$۱۳٬۰۹۰
Unitree
$۸٬۰۹۰
Unitree
$۸٬۳۹۰
Unitree
$۷٬۹۹۰
Unitree
$۱۲٬۰۹۰
Unitree
$۱۲٬۳۹۰
Unitree
$۱۱٬۹۹۰
Unitree
$۱۲٬۷۹۰
Unitree
$۱۳٬۶۹۰
🍪 ترجیحات کوکی
برای سنجش عملکرد از کوکیها استفاده میکنیم. سیاست حفظ حریم خصوصی