میانگین روزانهٔ قیمت
مبالغ به USD


The Unitree G1-D Standard A U1 is a fixed-base dual-arm humanoid robot designed for advanced research and light industrial applications.
With a total of 19 degrees of freedom, including dual 7-DoF arms, waist articulation, an adjustable lifting column, and dual Dex1-1 grippers, the platform offers flexible, human-like motion precision.
The robot combines two articulated arms, a two-degree-of-freedom waist, a height-adjustable lifting column, and two Dex1-1 Advanced Edition grippers.
The base robot provides 17 degrees of freedom: 7×2 arm joints, 2 waist joints, and 1 lifting-column joint.
Two additional gripper joints increase the total configuration to 19 degrees of freedom.
Each robotic arm supports a maximum payload of approximately 3 kg
Each arm provides an approximate reach of 0.45 m
The adjustable column changes the robot height from approximately 1260 mm to 1680 mm
The maximum operating height is approximately 2 meters
The height-adjustable column provides a 500 mm vertical lifting stroke.
The lifting system provides positioning accuracy of 1 mm.
The lifting column moves at a maximum speed of 60 mm/s.
The waist movement range is Z ±155° and Y −2.5° to +135°.
The Unitree G1-D Standard A U1 includes two Dex1-1 Gripper Advanced Edition end effectors.
Each gripper provides a maximum opening stroke of 90 mm
The clamping force is adjustable from 5 N to 120 N
Gripper tip position resolution is 0.1 mm
The conformal gripping load is rated at 20 kg
The friction-based gripping load is rated at 5 kg
Minimum full-stroke closing time is 0.24 seconds
The robot combines an eight-core high-performance CPU with an NVIDIA Jetson Orin 16G computing module.
The high-performance computing module provides 100 TOPS of computing power.
Base computing power is provided by an 8-core high-performance CPU.
Full secondary development support is included.
A visualization computer is included with the robot.
The head-mounted high-definition binocular camera provides a resolution of 3840 × 1200
Horizontal: 115°; vertical: 80°; diagonal: 125°.
Two wrist-mounted high-definition cameras provide a resolution of 1920 × 1080
Horizontal: 130°; vertical: 60°; diagonal: 160°.
The robot is equipped with multiple sensing sensors.
The robot uses a localized air-cooling system.
The robot uses a 9000 mAh quick-release smart battery.
Battery runtime is approximately 2 hours.
The robot supports battery operation or a direct power cable connection.
A 54 V 5 A charger is included.
Wi-Fi 6 and Bluetooth 5.2 connectivity are supported.
The robot includes a four-microphone array and a 5 W speaker.
| Model | Unitree G1-D Standard A U1 |
|---|---|
| Platform Type | Fixed-base dual-arm humanoid robot |
| Minimum Dimensions | Approx. 1260 × 500 × 500 mm |
| Maximum Dimensions | Approx. 1680 × 500 × 500 mm |
| Weight with Battery | Approx. 50 kg |
| DOF Excluding End Effectors | 17: 7×2 arms, 2 waist joints, and 1 column joint |
| Total Degrees of Freedom | 19: 7×2 arms, 2 waist, 1 column, and 1×2 grippers |
| Single Arm DOF | 7, excluding the end effector |
| Maximum Arm Payload | Approx. 3 kg |
| Arm Reach | Approx. 0.45 m, excluding the end effector |
| Waist DOF | 2 |
| Waist Movement Range | Z ±155°; Y −2.5° to +135° |
| Lifting Stroke | 500 mm |
| Lifting Accuracy | 1 mm |
| Lifting Speed | Max. 60 mm/s |
| Maximum Operating Height | Approx. 2 m |
| Cooling System | Localized air cooling |
| Power Supply | Battery-powered or direct power cable connection |
| Battery | 9000 mAh quick-release smart battery |
| Battery Runtime | 2 hours |
| Charger | 54 V 5 A |
| Base Computing Power | 8-core high-performance CPU |
| Computing Module | NVIDIA Jetson Orin 16G, 100 TOPS |
| Head Camera | 1× HD binocular camera, 3840 × 1200 |
| Head Camera FOV | H: 115°; V: 80°; D: 125° |
| Wrist Cameras | 2× HD cameras, 1920 × 1080 |
| Wrist Camera FOV | H: 130°; V: 60°; D: 160° |
| Audio | Four-microphone array and 5 W speaker |
| Connectivity | Wi-Fi 6 and Bluetooth 5.2 |
| Handheld Remote Controller | Included |
| Visualization Computer | Included |
| Smart OTA Updates | Supported |
| Secondary Development | Supported |
| Quantity | 2 |
|---|---|
| Dimensions | 143 × 78 × 67 mm |
| Weight | 550 g |
| Stroke | 90 mm |
| Position Resolution at Tip | 0.1 mm |
| Clamping Force | Adjustable from 5 to 120 N |
| Conformal Gripping Load | 20 kg |
| Friction Gripping Load | 5 kg |
| Minimum Full-Stroke Closing Time | 0.24 s |
| Gripper Length | 80 mm |
| Communication Protocol | High-Speed 485 |
The Unitree G1-D Standard A U1 is backed by a 12-month warranty.

تاریخچهٔ قیمت
برای هر روز یک نقطهٔ داده؛ میانگینگیری بر اساس تاریخ مشاهده انجام شده است.
مبالغ به USD
میانگینها بر اساس همهٔ قیمتهای پیشنهادی ثبتشده در هر روزِ UTC محاسبه میشوند.
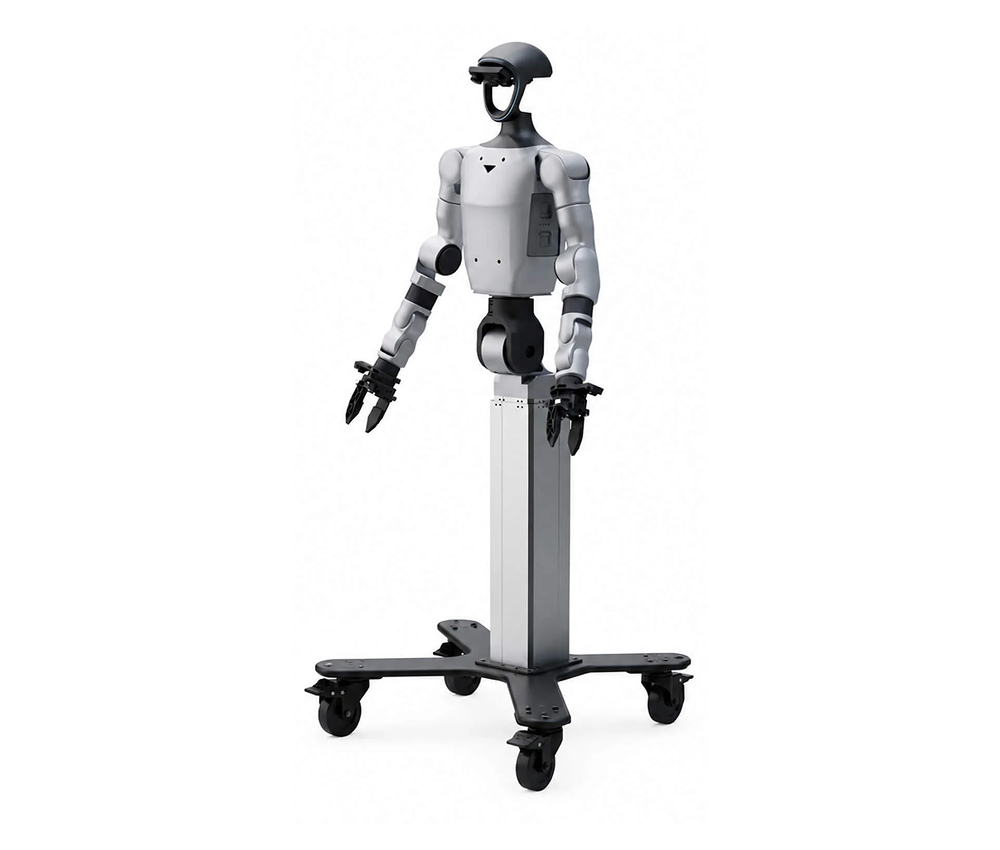
Unitree
۳۵٬۸۹۹ €

Unitree
از $۳۸٬۸۰۰

Unitree
$۳۸٬۸۰۰

Unitree
از $۳۸٬۸۰۰

Unitree
$۴۹٬۸۰۰
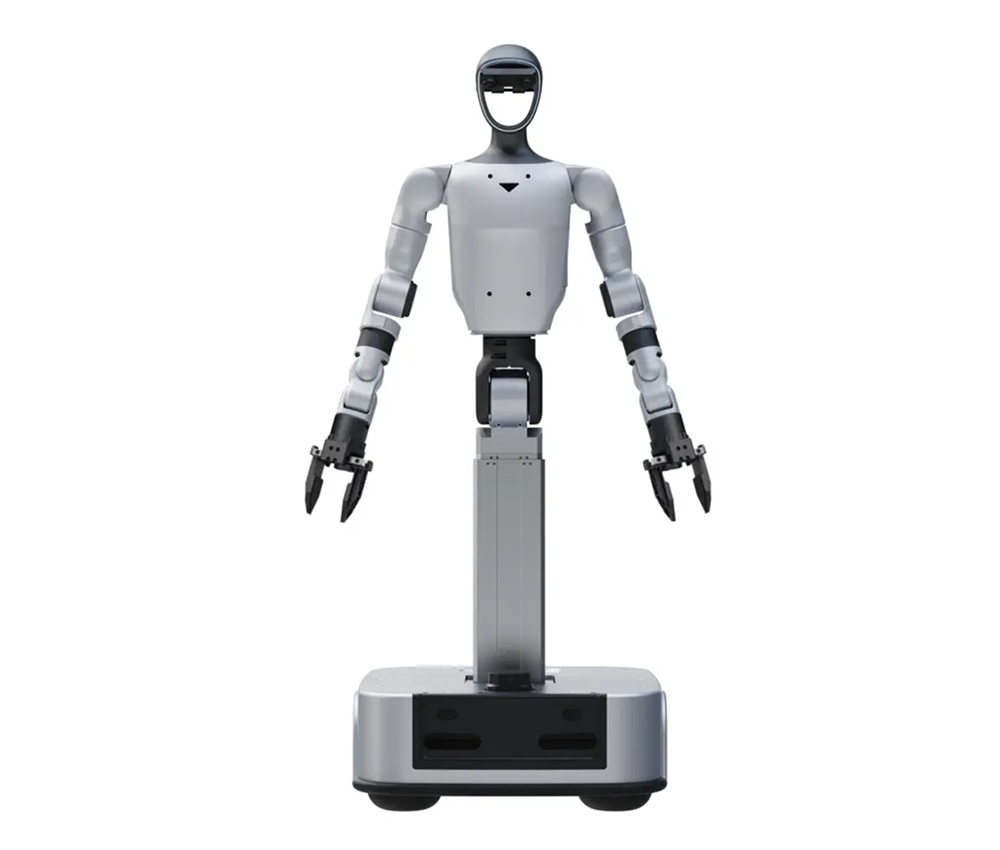
Unitree
۴۷٬۷۹۹ €

Unitree
$۴۹٬۸۰۰
Unitree
$۵۱٬۸۰۰

Unitree
$۵۱٬۹۰۰
Unitree
$۵۳٬۸۰۰
Unitree
$۵۳٬۸۰۰

Unitree
از $۵۱٬۹۰۰
🍪 ترجیحات کوکی
برای سنجش عملکرد از کوکیها استفاده میکنیم. سیاست حفظ حریم خصوصی