میانگین روزانهٔ قیمت
مبالغ به USD
توضیحات
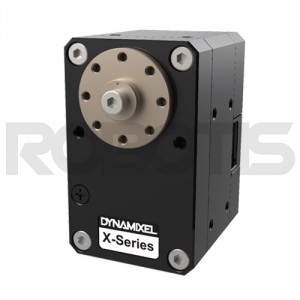
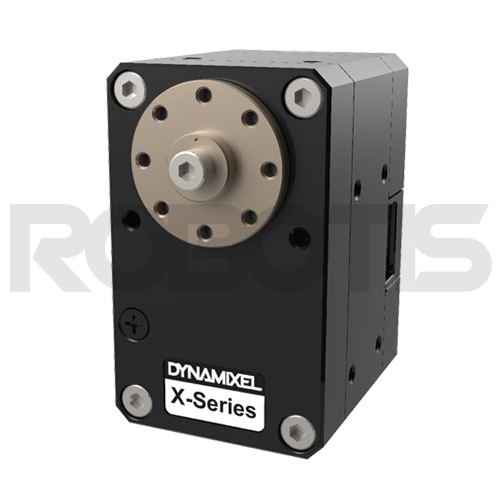
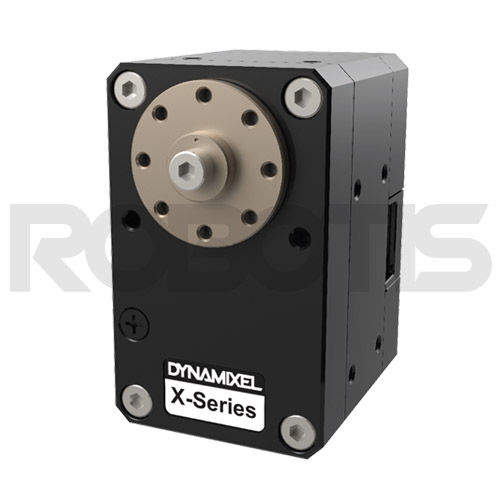
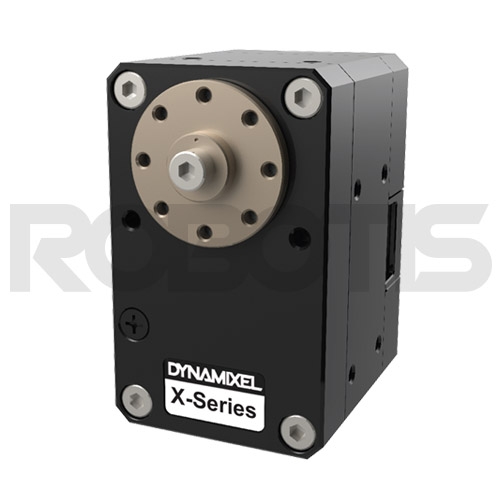
DYNAMIXEL XH430-V210-R Features DYNAMIXEL is a robot exclusive smart actuator with fully integrated DC Motor + Reduction Gearhead + Controller + Driver + Network in one DC servo module. The Dynamixel XH / XM-Series offers a variety of control techniques based on high-performance current sensing algorithms. It adopts the aluminum case and adopts the new technology such as the hollow cable fastening structure for users’ convenience. 6 Operating Modes Torque Control, Velocity Control, Position Control, Extended Position Control, Current based Position Control, PWM Control Profile Control for Smooth Motion Planning Improved Heat Sink Featuring an Aluminum Case Hollow Back Case Minimizes Cable Stress (3-way-routing) Direct Screw Assembly to the Case (without Nut Insert) Energy Saving (Reduced Current from 100mA to 40mA) 31% reduced volume compared to the previous model Package Component XH430-V210-R 1 HN12-N101 1 Teflon Washer (for Horn Assembly) 1 Robot Cable-X4P 180mm 1 Robot Cable-X4P(Convertible) 180mm 1 Wrench Bolt WB M2.5x4 16 Wrench Bolt WB M2x3 10 Wrench Bolt WB M2.5x6 1 Spacer Ring 8 Compatible Products Controller OpenCM9.04 485 Expansion Board, OpenCR1.0 Interface USB2Dynamixel, U2D2 Factory Default Settings ID 1 Baud Rate 57600bps (User can change various settings including ID and baud rate according to environment) Various Cabling Methods Caution DYNAMIXEL X-Series cable assembly through hollow case Organize the entangled cable before assembling the back case. Do not assemble the back case with entangled cable. The entangled cable can be squashed by the case and cause communication error. If you use two cables through the hollow case, the cables will be damaged. Use only one cable through the hollow case. The DYNAMIXEL X-Series adopted a new gold-plated JST connector for secure and reliable communication. The connector used for previous Dynamixel is Molex. To control DYNAMIXEL X-Series actuators via OpenCM or USB2Dynamixel, please use the JST-Molex Convertible Cable enclosed in the package. However, the Molex-JST convertible cable is NOT included in the XL430 model. Please purchase a convertible cable when using a controller and interface that supports the JST connector. Controller Cable Details Controller Model Controller Connector Cable DynamixelX Connector Dynamixel Communication OpenCM+485 Expansion Board Molex (3P, 4P) Robot Cable-X3P 180mm (Convertible) JST-3P TTL USB2Dynamixel Molex (3P, 4P) Robot Cable-X3P 180mm (Convertible) JST-3P TTL OpenCR1.0 JST (3P, 4P) Robot Cable-X3P (by length) JST-3P TTL U2D2 JST (3P, 4P) Robot Cable-X3P (by length) JST-3P TTL OpenCM+485 Expansion Board Molex (3P, 4P) Robot Cable-X4P 180mm (Convertible) JST-4P RS-485 USB2Dynamixel Molex (3P, 4P) Robot Cable-X4P 180mm (Convertible) JST-4P RS-485 OpenCR1.0 JST (3P, 4P) Robot Cable-X4P (by length) JST-4P RS-485 U2D2 JST (3P, 4P) Robot Cable-X4P (by length) JST-4P RS-485 Specifications Model Name XH430-V210-R MCU Cortex-M3 (72 [Mhz], 32 [bit]) Input Voltage Min. [V] - " Recommended [V] 24 " Max. [V] - Performance Characteristics Voltage [V] 24 " Stall Torque [N·m] 2.6 " Stall Current [A] 0.7 " No Load Speed [rpm] 52 " No Load Current [A] 0.06 Resolution Resolution [deg/pulse] 0.0879 " Step [pulse] 4,096 " Angle [degree] 360 Position Sensor Contactless absolute encoder (12 [bit], 360 [deg]). Maker : ams(www.ams.com), Part No : AS5045 Operating Temperature Min. [°C] -5 " Max. [°C] 80 Motor Coreless (Maxon) Baud Rate Min. [bps] 9,600 " Max. [bps] 4,500,000 Control Algorithm PID Gear Type Spur Gear Material Precious Metal Case Material Precious Metal(Front, Middle). Engineering Plastic(Back) Dimensions (WⅹHⅹD) [mm] 28.5 X 46.5 X 34.0 Dimensions (WⅹHⅹD) [inch] 1.12 X 1.83 X 1.34 Weight [g] 82 Weight [oz] 2.89 Gear Ratio 212.6 : 1 Command Signal Digital Packet Protocol Type Half duplex Asynchronous Serial Communication (8bit, 1stop, No Parity) Link (Physical) RS485 Multi Drop Bus ID 0 ~ 252 Feedback Position, Velocity, Current, Realtime tick, Trajectory, Temperature, Voltage, External Port, etc. Protocol version 1.0 & 2.0(Default) Operating Mode / Angle Current Control mode:Endless turn - Velocity Control mode:Endless turn - Position Control Mode:360 [deg] - Extended Position Control Mode:±256 [rev] - Current-based Position Control Mode:±256 [rev] - PWM Control Mode:Endless turn Standby Current [mA] 36 Robotis - DYNAMIXEL XH430-V210-R. DYNAMIXEL is a robot exclusive smart actuator with fully integrated DC Motor + Reduction Gearhead + Controller + Driver + Network in one DC servo module. The Dynamixel XH / XM-Series offers a variety of control techniques based on high-performance current sensing algorithms. It adopts the aluminum case and adopts the new technology such as the hollow cable fastening structure for users’ convenience.
DYNAMIXEL XH430-V210-R Features DYNAMIXEL is a robot exclusive smart actuator with fully integrated DC Motor + Reduction Gearhead + Controller + Driver + Network in one DC servo module. The Dynamixel XH / XM-Series offers a variety of control techniques based on high-performance current sensing algorithms. It adopts the aluminum case and adopts the new technology such as the hollow cable fastening structure for users’ convenience. 6 Operating Modes Torque Control, Velocity Control, Position Control, Extended Position Control, Current based Position Control, PWM Control Profile Control for Smooth Motion Planning Improved Heat Sink Featuring an Aluminum Case Hollow Back Case Minimizes Cable Stress (3-way-routing) Direct Screw Assembly to the Case (without Nut Insert) Energy Saving (Reduced Current from 100mA to 40mA) 31% reduced volume compared to the previous model Package Component XH430-V210-R 1 HN12-N101 1 Teflon Washer (for Horn Assembly) 1 Robot Cable-X4P 180mm 1 Robot Cable-X4P(Convertible) 180mm 1 Wrench Bolt WB M2.5x4 16 Wrench Bolt WB M2x3 10 Wrench Bolt WB M2.5x6 1 Spacer Ring 8 Compatible Products Controller OpenCM9.04 485 Expansion Board, OpenCR1.0 Interface USB2Dynamixel, U2D2 Factory Default Settings ID 1 Baud Rate 57600bps (User can change various settings including ID and baud rate according to environment) Various Cabling Methods Caution DYNAMIXEL X-Series cable assembly through hollow case Organize the entangled cable before assembling the back case. Do not assemble the back case with entangled cable. The entangled cable can be squashed by the case and cause communication error. If you use two cables through the hollow case, the cables will be damaged. Use only one cable through the hollow case. The DYNAMIXEL X-Series adopted a new gold-plated JST connector for secure and reliable communication. The connector used for previous Dynamixel is Molex. To control DYNAMIXEL X-Series actuators via OpenCM or USB2Dynamixel, please use the JST-Molex Convertible Cable enclosed in the package. However, the Molex-JST convertible cable is NOT included in the XL430 model. Please purchase a convertible cable when using a controller and interface that supports the JST connector. Controller Cable Details Controller Model Controller Connector Cable DynamixelX Connector Dynamixel Communication OpenCM+485 Expansion Board Molex (3P, 4P) Robot Cable-X3P 180mm (Convertible) JST-3P TTL USB2Dynamixel Molex (3P, 4P) Robot Cable-X3P 180mm (Convertible) JST-3P TTL OpenCR1.0 JST (3P, 4P) Robot Cable-X3P (by length) JST-3P TTL U2D2 JST (3P, 4P) Robot Cable-X3P (by length) JST-3P TTL OpenCM+485 Expansion Board Molex (3P, 4P) Robot Cable-X4P 180mm (Convertible) JST-4P RS-485 USB2Dynamixel Molex (3P, 4P) Robot Cable-X4P 180mm (Convertible) JST-4P RS-485 OpenCR1.0 JST (3P, 4P) Robot Cable-X4P (by length) JST-4P RS-485 U2D2 JST (3P, 4P) Robot Cable-X4P (by length) JST-4P RS-485 Specifications Model Name XH430-V210-R MCU Cortex-M3 (72 [Mhz], 32 [bit]) Input Voltage Min. [V] - " Recommended [V] 24 " Max. [V] - Performance Characteristics Voltage [V] 24 " Stall Torque [N·m] 2.6 " Stall Current [A] 0.7 " No Load Speed [rpm] 52 " No Load Current [A] 0.06 Resolution Resolution [deg/pulse] 0.0879 " Step [pulse] 4,096 " Angle [degree] 360 Position Sensor Contactless absolute encoder (12 [bit], 360 [deg]). Maker : ams(www.ams.com), Part No : AS5045 Operating Temperature Min. [°C] -5 " Max. [°C] 80 Motor Coreless (Maxon) Baud Rate Min. [bps] 9,600 " Max. [bps] 4,500,000 Control Algorithm PID Gear Type Spur Gear Material Precious Metal Case Material Precious Metal(Front, Middle). Engineering Plastic(Back) Dimensions (WⅹHⅹD) [mm] 28.5 X 46.5 X 34.0 Dimensions (WⅹHⅹD) [inch] 1.12 X 1.83 X 1.34 Weight [g] 82 Weight [oz] 2.89 Gear Ratio 212.6 : 1 Command Signal Digital Packet Protocol Type Half duplex Asynchronous Serial Communication (8bit, 1stop, No Parity) Link (Physical) RS485 Multi Drop Bus ID 0 ~ 252 Feedback Position, Velocity, Current, Realtime tick, Trajectory, Temperature, Voltage, External Port, etc. Protocol version 1.0 & 2.0(Default) Operating Mode / Angle Current Control mode:Endless turn - Velocity Control mode:Endless turn - Position Control Mode:360 [deg] - Extended Position Control Mode:±256 [rev] - Current-based Position Control Mode:±256 [rev] - PWM Control Mode:Endless turn Standby Current [mA] 36
تاریخچهٔ قیمت
برای هر روز یک نقطهٔ داده؛ میانگینگیری بر اساس تاریخ مشاهده انجام شده است.
مبالغ به USD
میانگینها بر اساس همهٔ قیمتهای پیشنهادی ثبتشده در هر روزِ UTC محاسبه میشوند.

Robotis
$۴۱۳٫۸۹
Robotis
۴۱۸٫۲۰ €
Robotis
۳۰۰٫۲۶ €
Robotis
۳۰۴٫۲۰ €
Robotis
£۲۷۸٫۳۱
Robotis
£۲۶۸٫۵۰
Robotis
£۲۷۸٫۳۵
Robotis
£۲۷۸٫۴۹
Robotis
£۲۷۸٫۳۲

Robotis
$۲۹۸٫۸۹

Robotis
$۲۹۸٫۸۹

Robotis
از $۲۸۴٫۶۹
🍪 ترجیحات کوکی
برای سنجش عملکرد از کوکیها استفاده میکنیم. سیاست حفظ حریم خصوصی