میانگین روزانهٔ قیمت
مبالغ به USD
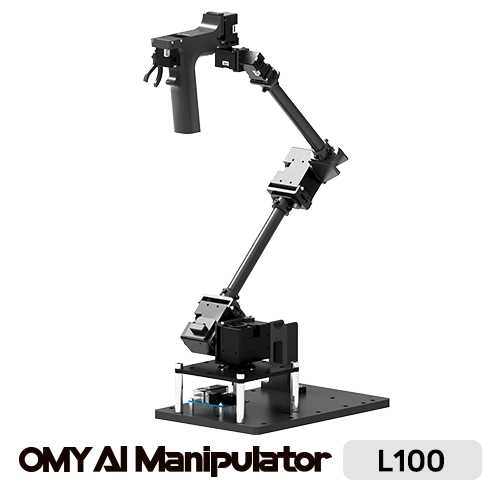
توضیحات
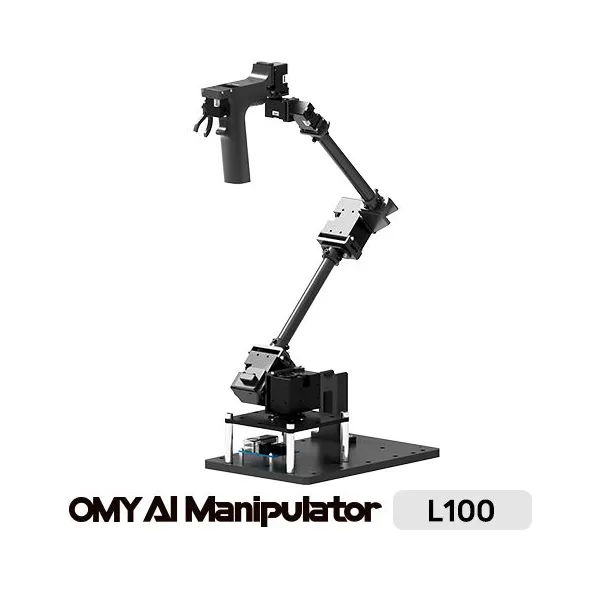
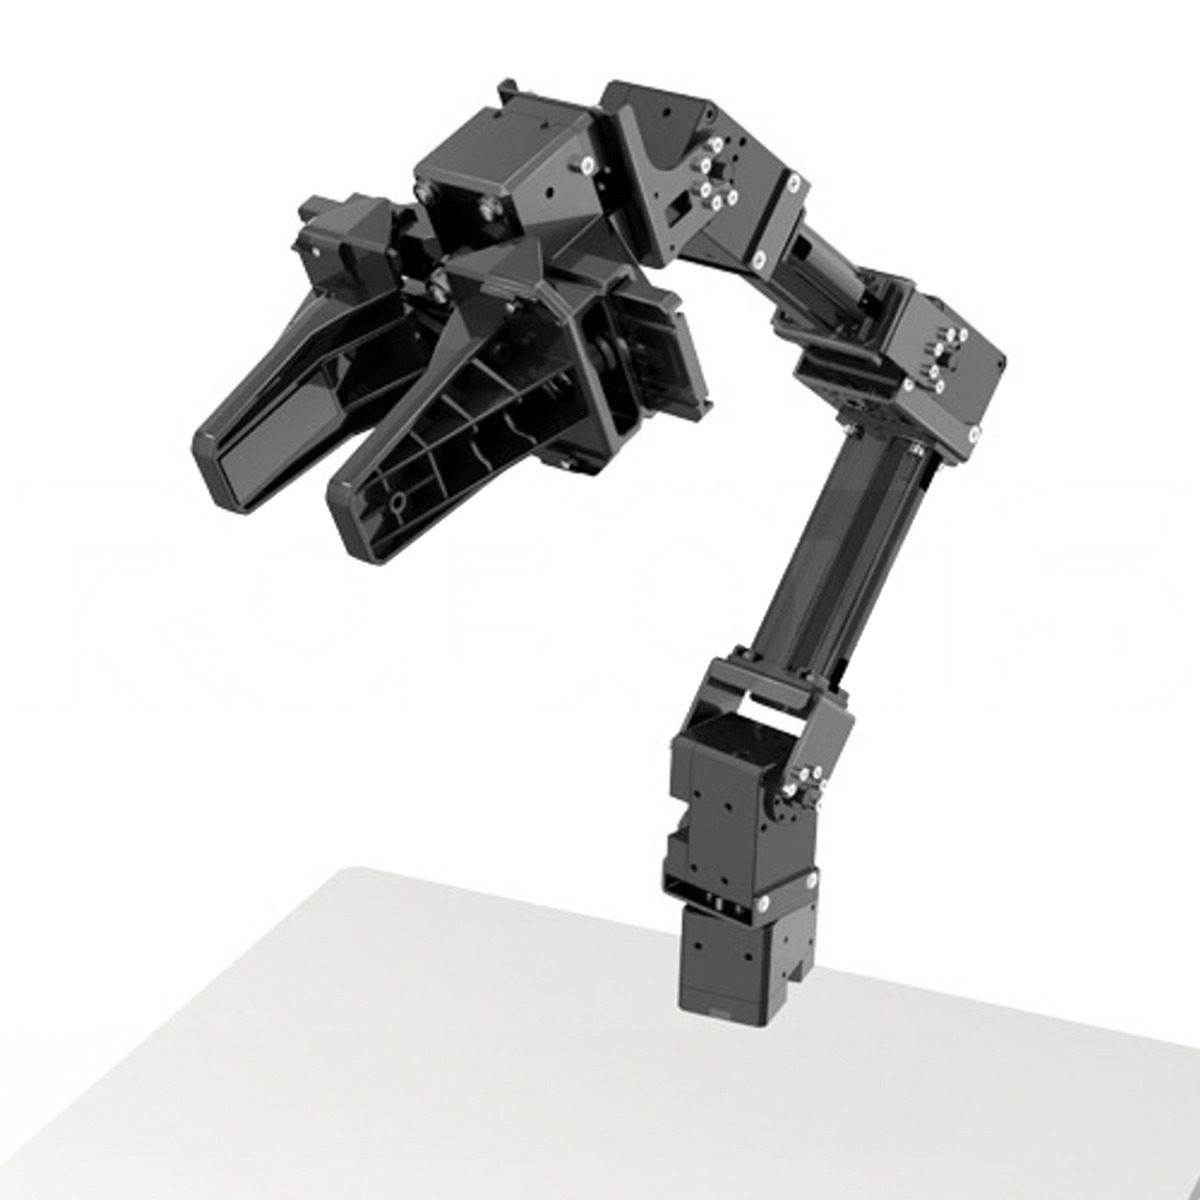
Features Convenience Minimize operator fatigue through gravity and friction compensation, and spring effect features. Offering operational and customization flexibility via a lightweight (under 1.5kg) and modular structure. OpenSource Platform Delivering perfect compatibility with ROS2 and open-source support. Offering various packages and simulators (e.g., Movelt 2, Gazebo, MuJoCo). Enabling compatibility between heterogeneous/multiple robots based on the ROS2 environment. Specification Items OMY-L100 (Leader) DOF 7 Payload - Reach 560 [mm] Weight 1.46 [kg] Operating Voltage 12 [VDC] Joint Resolution -π(rad) ~ π(rad), -2,048 ~ 2,048 [pulse/rev] Joint Range Joint 1: ±180° Joint 2: -70º ~ +100° Joint 3,4,5,6: ±180° Joint 7: -90° ~ +60º DYNAMIXEL-Y Specification Joint 1,2,3: XH540-W150 Joint 4,5,6: XC330-T288 Joint 7: XC330-T181 Repeatability - Brake Force - TCP Speed - Host Interface U2D2 (USB 2.0) Internal Communications TTL Multidrop Bus Communication Baudrate 4 [Mbps] Robot Hand - Camera - Links e-Manual
Features Convenience Minimize operator fatigue through gravity and friction compensation, and spring effect features. Offering operational and customization flexibility via a lightweight (under 1.5kg) and modular structure. OpenSource Platform Delivering perfect compatibility with ROS2 and open-source support. Offering various packages and simulators (e.g., Movelt 2, Gazebo, MuJoCo). Enabling compatibility between heterogeneous/multiple robots based on the ROS2 environment. Specification Items OMY-L100 (Leader) DOF 7 Payload - Reach 560 [mm] Weight 1.46 [kg] Operating Voltage 12 [VDC] Joint Resolution -π(rad) ~ π(rad), -2,048 ~ 2,048 [pulse/rev] Joint Range Joint 1: ±180° Joint 2: -70º ~ +100° Joint 3,4,5,6: ±180° Joint 7: -90° ~ +60º DYNAMIXEL-Y Specification Joint 1,2,3: XH540-W150 Joint 4,5,6: XC330-T288 Joint 7: XC330-T181 Repeatability - Brake Force - TCP Speed - Host Interface U2D2 (USB 2.0) Internal Communications TTL Multidrop Bus Communication Baudrate 4 [Mbps] Robot Hand - Camera - Links e-Manual
تاریخچهٔ قیمت
برای هر روز یک نقطهٔ داده؛ میانگینگیری بر اساس تاریخ مشاهده انجام شده است.
مبالغ به USD
میانگینها بر اساس همهٔ قیمتهای پیشنهادی ثبتشده در هر روزِ UTC محاسبه میشوند.
Robotis
£۲٬۲۱۵٫۰۵
Robotis
£۲٬۲۱۵٫۰۵
Robotis
۱٬۸۳۸٫۹۵ €
Robotis
£۱٬۹۹۹٫۵۰
Robotis
£۱٬۹۹۹٫۵۰

Robotis
$۱٬۶۲۹٫۰۹

Robotis
$۱٬۹۳۳٫۶۱

Robotis
$۱٬۹۰۸٫۳۱
Robotis
۳٬۲۹۱٫۶۰ €
Robotis
۱٬۵۴۰٫۹۵ €
Robotis
£۱٬۱۱۸٫۴۲
Robotis
£۱٬۲۵۰٫۶۱
🍪 ترجیحات کوکی
برای سنجش عملکرد از کوکیها استفاده میکنیم. سیاست حفظ حریم خصوصی