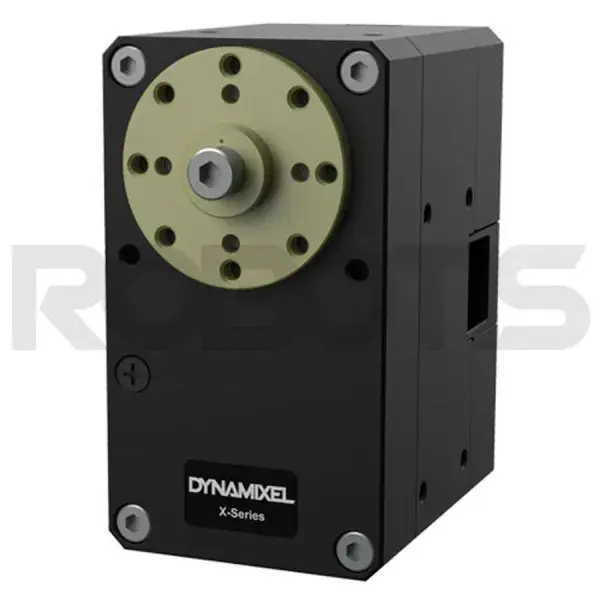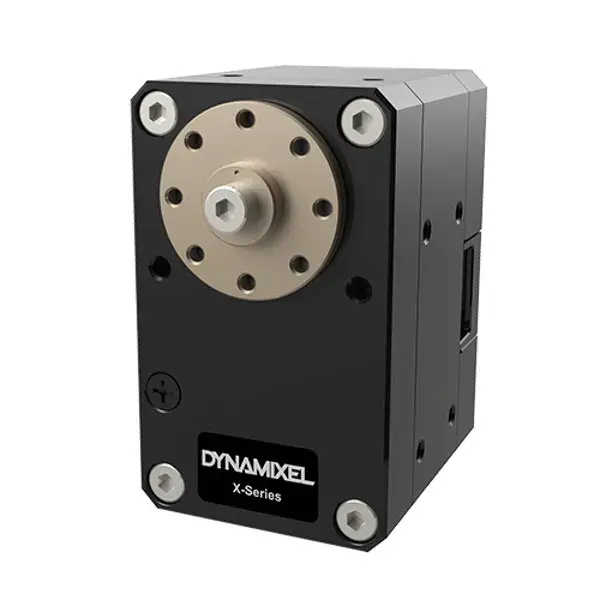
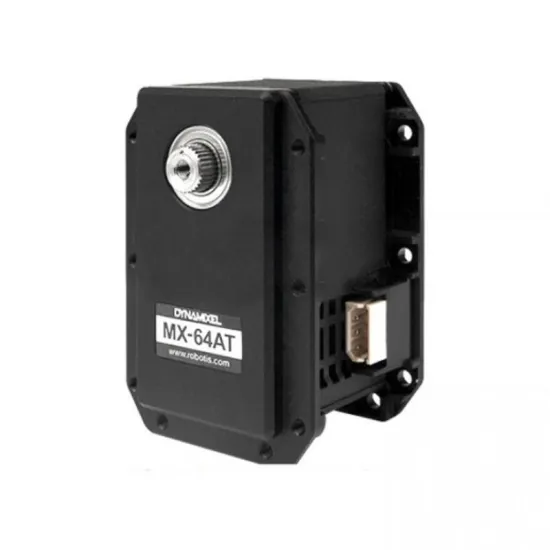
Dynamixel MX-64AT Actuator

Dynamixel MX-64AT Actuator

Dynamixel MX-64AT Actuator
Robotis | A-000000-01533
€430.20 VAT incl. €358.51 VAT excl.

Including €0.05 for ecotax
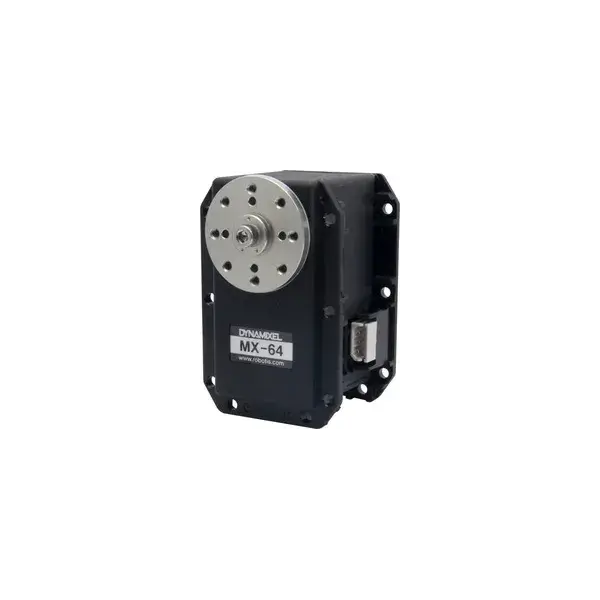
The MX-64AT is a Dynamixel servomotor, with high-level control features and very precise. It is more powerful than the MX-28AT and features the same caracteristics than the MX-64T except for the aluminium case enabling a better heat dissipation.
Quantity
2 Available

Get it in 24/48h! (see T&C)

Create a cart and turn it into a quote instantly!
Payment methods (see T&C)
Debit card
PayPal
Payment by invoice
Wire transfer

The Dynamixel servomotors

Dynamixel Servomotors main features
  • All-around assembling structure: you can make robots of various forms as using different option frames.
  • Powerful feedback : It can read current position of Dynamixel or speed as well as various information such as internal temperature, supply voltage, target position.
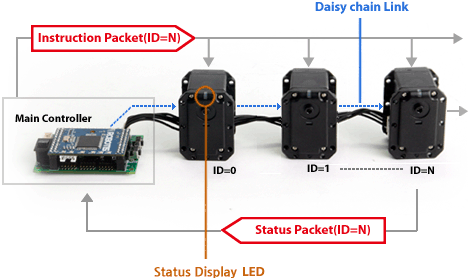
  • Simple connection structure: Wiring is simple because it is linked by Daisy Chain.
  • Alarm function: When internal temperature, torque, supply voltage etc. escaped appointed range, it gives feedback about that situation. Also in such emergency situation, it flash LED or be Torque off.
  • Compliance configuration: It can configure the compliance to control the position.
  • Torque set up : Torque can be set up by 1023 steps from maximum Torque to free run state.
  • Low-electric current/high voltagedrive : Its efficiency is high because it runs by high voltage and it improves stability of robot system that is formed by Dynamixel because current consumption is low.
  • Status LED : It has LED that can check state of the Dynamixel.
  • Drive by network: Dynamixels have unique ID and are controlled by Packet communication on a bus. It supports network of TTL, RS 485, and CAN etc. according to model.

Dynamixel actuators are controlled by Packet communication

This video illustrates the capabilities and the existing application for Dynamixel servomotors:

Programming the Dynamixel servomotors

The servomotors have to be linked to a main controller (CM-900, CM-700, CM-5, CM-510, CM-530, or OpenCM9.04) to be commanded. The programs are made with RoboPlus, which allow really easy programmation, without much previous knowledge.

The most recent main controllers support embedded C and there is a SDK for you to developp your own applications.

The Dynamixel MX-64AT servomotor

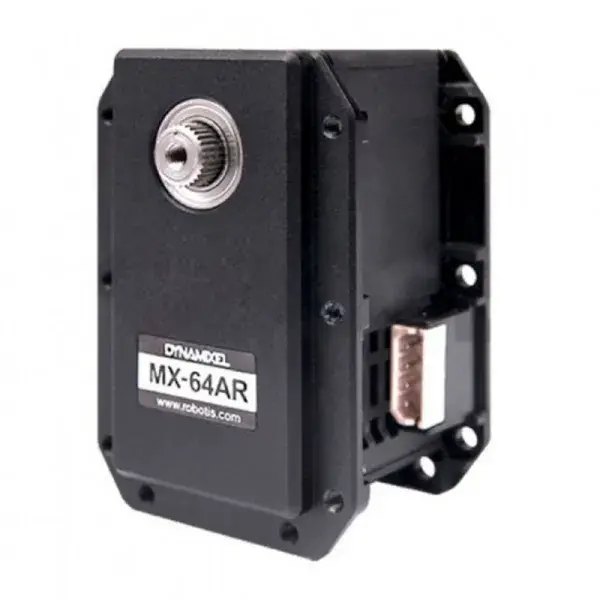
The MX-64AR and MX-64AT are new Dynamixel servomotors in the MX range. They replace and improve the RX-64 servomotor with a new absolute contactless encoder with 12 bit resolution (4096 positions), can be positionned over 360° in joint mode (251° previously), can be speed controlled in wheel mode and estimate their torque based on current.

Moreover they are controlled with a PID (proportional integral derivative), which parameters can be set servomotor by servomotor. Admissible values are between 0 and 255 and the PID coefficients are modified with the following formulas:
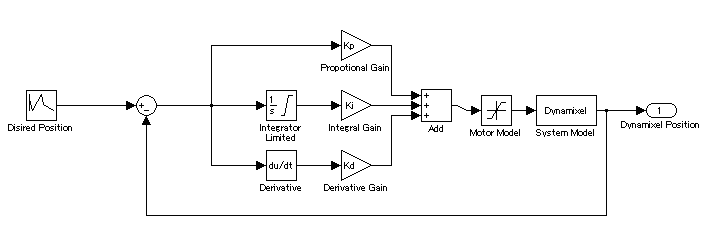
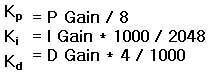
pid controller for the MX-64AT servomotor Dynamixel robotis

coefficients calculation for the pid of the MX-64AT servomotor dynamixel robotis

The case of the RX-64 has also been lightly modified, the MX-64AT servomotor is therefore not compatible with the HN05-N101/T101 horn.

The Dynamixel servomotor MX-64AT supports the TTL communication protocol (when MX-64AR supports RS484 communication) with high speed (3Mbs), it is compatible with the CM-510, CM-530, CM-700 and OpenCM9.04 main controllers. Warning, the operating voltage is not the same as the RX-64 voltage.

Technical specifications of the Dynamixel MX-64AT actuator

  • MCU : ST CORTEX-M3 (ST32F103C8 @ 72MHZ,32BIT)
  • Motor : Maxon
  • Position sensor : Contactless absolute encoder (12BIT,360 DEGREE)
  • Stall Torque : 5.5N.m (at 11.1V, 3.9A), 6.0N.m (at 12V, 4.1A), 7.3N.m (at 14.8V, 5.2A)
  • No load speed : 58rpm (at 11.1V), 63rpm (at 12V), 78rpm (at 14.8V)
  • Résolution : 0.088° x 4.096
  • Running degree : 360°
  • Control algorithm : PID
  • Command :digital packet, baud rate : 8000 bps ~ 3 Mbps
  • Protocol : Half duplex Asynchronous Serial Communication (8bit,1stop, No Parity)
  • Link (physical) : TTL Level Multi Drop Bus
  • Weight : 126g
  • Voltage : 10 ~ 14.8V (Recommended voltage 12V)
  • Gear ratio : 200 : 1
  • ID : 254 ID (0~253)
  • Feedback : Position, Temperature, Load, Input Voltage, Current, etc.
  • Ide current : 100 mA
  • Dimensions : 40.2mm x 61.1mm x 41mm (exact dimensions available here)
  • Material : Full Metal Gear, Engineering Plastic Body

All the technical specifications of the Dynamixel MX-64AR actuator are available on the website of the manufacturer at http://support.robotis.com/en/product/dynamixel/mx_series/mx-64.htm

Comparing the various Dynamixel actuators

This document offers an overview on the characteristics of all the Dynamixel servomotors.

Comparison table between all Dynamixel servomotors robotis
Comparison between all Dynamixel servomotors

The chart below compare the Dynamixel actuators on their performance. Servomotors are differentiated by communication type (and the MX range proposes both protocols).

    My Dynamixel servomotor is not detected, what can I do about it ?

    Check that your Dynamixel servomotor is correctly configured. Do not hesitate to re-flash it with the ROBOTIS Software Roboplus. After re-flash remember to re-configure it. If the issue is not solved, for an advanced support.


    My motor works but it seems like there is an offset. Why ?

    The motor is probably not well mounted. Check that you correctly mounted the horns by respecting the mark.


    My Dynamixel servomotor seems blocked. I can't turn it even when it is not alimented.

    There is probably a mechanical issue with the Dynamixel servomotor. You can directly to get more advance support.


    My Dynamixel servomotor is not working properly.

    Check your power supply and the system cabling (try with a different servomotor). You can also reset the servo. If nothing works, the best solution is to go through the Dynamixel servomotor checklist!


    What is the difference between Protocol 1.0 and Protocol 2.0?

    The 1.0 protocol is dedicated to the Dynamixel AX and MX series. Protocol 2.0 is for the X and Dynamixel Pro series. Protocol 2.0 control tables include PID controls which allow for more precise adjustment of the servo motor movements. Protocol 2.0 can be updated on MX series servo motors. You can refer to the protocol 1.0 and protocol 2.0 pages for more informations.


تاریخچهٔ قیمت

تاریخچهٔ میانگین قیمت

برای هر روز یک نقطهٔ داده؛ میانگین‌گیری بر اساس تاریخ مشاهده انجام شده است.

میانگین روزانهٔ قیمت

مبالغ به USD

$۴۷۲٫۲۳
نمودار تاریخچهٔ میانگین قیمت (به USD)نمودار خطیِ 61 مشاهده از ۱۰ مهر ۱۴۰۵ تا ۱ آذر ۱۴۰۵.$۴۷۲٫۲۶$۴۷۲٫۲۵$۴۷۲٫۲۴$۴۷۲٫۲۳$۴۷۲٫۲۲۱۰ مهر۲۲ مهر۵ آبان۱۸ آبان۱ آذر۱۰ مهر ۱۴۰۵: میانگین $۴۷۲٫۲۳۱۱ مهر ۱۴۰۵: میانگین $۴۷۲٫۲۳۱۲ مهر ۱۴۰۵: میانگین $۴۷۲٫۲۳۱۳ مهر ۱۴۰۵: میانگین $۴۷۲٫۲۳۱۴ مهر ۱۴۰۵: میانگین $۴۷۲٫۲۳۱۵ مهر ۱۴۰۵: میانگین $۴۷۲٫۲۳۱۶ مهر ۱۴۰۵: میانگین $۴۷۲٫۲۳۱۷ مهر ۱۴۰۵: میانگین $۴۷۲٫۲۳۱۸ مهر ۱۴۰۵: میانگین $۴۷۲٫۲۳۱۹ مهر ۱۴۰۵: میانگین $۴۷۲٫۲۳۲۰ مهر ۱۴۰۵: میانگین $۴۷۲٫۲۳۲۱ مهر ۱۴۰۵: میانگین $۴۷۲٫۲۳۲۲ مهر ۱۴۰۵: میانگین $۴۷۲٫۲۳۲۳ مهر ۱۴۰۵: میانگین $۴۷۲٫۲۳۲۴ مهر ۱۴۰۵: میانگین $۴۷۲٫۲۳۲۵ مهر ۱۴۰۵: میانگین $۴۷۲٫۲۳۲۶ مهر ۱۴۰۵: میانگین $۴۷۲٫۲۳۲۷ مهر ۱۴۰۵: میانگین $۴۷۲٫۲۳۲۸ مهر ۱۴۰۵: میانگین $۴۷۲٫۲۳۲۹ مهر ۱۴۰۵: میانگین $۴۷۲٫۲۳۳۰ مهر ۱۴۰۵: میانگین $۴۷۲٫۲۳۱ آبان ۱۴۰۵: میانگین $۴۷۲٫۲۳۲ آبان ۱۴۰۵: میانگین $۴۷۲٫۲۳۳ آبان ۱۴۰۵: میانگین $۴۷۲٫۲۳۴ آبان ۱۴۰۵: میانگین $۴۷۲٫۲۳۵ آبان ۱۴۰۵: میانگین $۴۷۲٫۲۳۶ آبان ۱۴۰۵: میانگین $۴۷۲٫۲۳۷ آبان ۱۴۰۵: میانگین $۴۷۲٫۲۳۸ آبان ۱۴۰۵: میانگین $۴۷۲٫۲۳۹ آبان ۱۴۰۵: میانگین $۴۷۲٫۲۳۱۰ آبان ۱۴۰۵: میانگین $۴۷۲٫۲۳۱۱ آبان ۱۴۰۵: میانگین $۴۷۲٫۲۳۱۲ آبان ۱۴۰۵: میانگین $۴۷۲٫۲۳۱۳ آبان ۱۴۰۵: میانگین $۴۷۲٫۲۳۱۴ آبان ۱۴۰۵: میانگین $۴۷۲٫۲۳۱۵ آبان ۱۴۰۵: میانگین $۴۷۲٫۲۳۱۶ آبان ۱۴۰۵: میانگین $۴۷۲٫۲۳۱۷ آبان ۱۴۰۵: میانگین $۴۷۲٫۲۳۱۸ آبان ۱۴۰۵: میانگین $۴۷۲٫۲۳۱۹ آبان ۱۴۰۵: میانگین $۴۷۲٫۲۳۲۰ آبان ۱۴۰۵: میانگین $۴۷۲٫۲۳۲۱ آبان ۱۴۰۵: میانگین $۴۷۲٫۲۳۲۲ آبان ۱۴۰۵: میانگین $۴۷۲٫۲۳۲۳ آبان ۱۴۰۵: میانگین $۴۷۲٫۲۳۲۴ آبان ۱۴۰۵: میانگین $۴۷۲٫۲۳۲۵ آبان ۱۴۰۵: میانگین $۴۷۲٫۲۳۲۶ آبان ۱۴۰۵: میانگین $۴۷۲٫۲۳۲۷ آبان ۱۴۰۵: میانگین $۴۷۲٫۲۳۲۸ آبان ۱۴۰۵: میانگین $۴۷۲٫۲۳۲۹ آبان ۱۴۰۵: میانگین $۴۷۲٫۲۳۳۰ آبان ۱۴۰۵: میانگین $۴۷۲٫۲۳۱ آذر ۱۴۰۵: میانگین $۴۷۲٫۲۳

میانگین‌ها بر اساس همهٔ قیمت‌های پیشنهادی ثبت‌شده در هر روزِ UTC محاسبه می‌شوند.