Средна дневна цена
Суми в USD
Описание
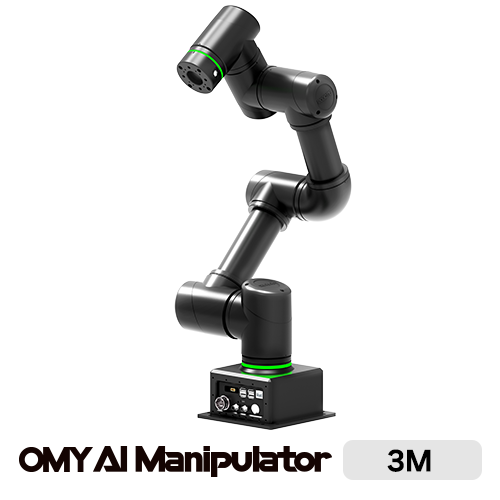
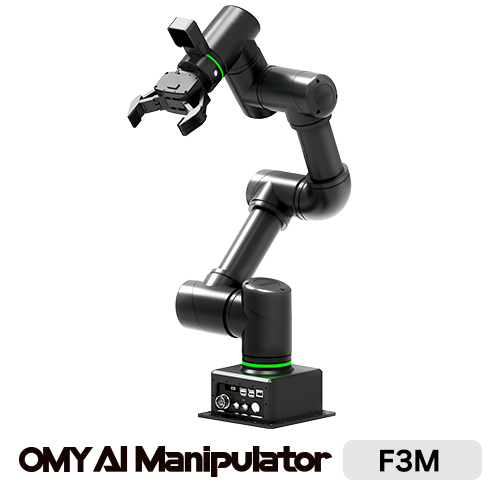
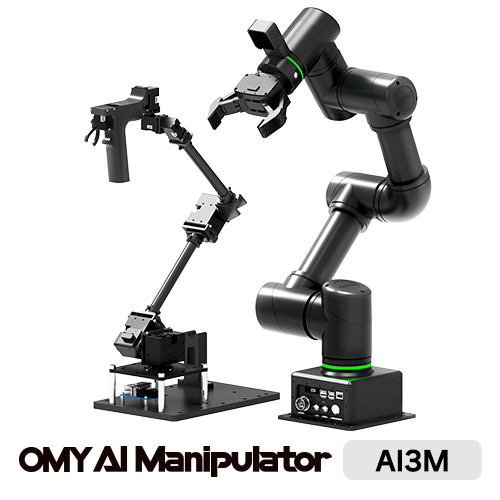
Features Custom Manipulator Easy integration of 3rd-party components (such as hands, sensors, vision systems) depending on the working environment. Providing customizable development environment (C, C#, Python, etc.) via the DYNAMIXEL SDK. Plug-and-Play Realizing a perfect benchtop manipulator through a minimal footprint and lightweight design. Providing a robot control environment via an integrated controller (SBC) without the need for a separate PC. OpenSource Platform Delivering perfect compatibility with ROS2 and open-source support. Offering various packages and simulators (e.g., Movelt 2, Gazebo). Supporting development convenience through a dedicated OMY Control GUI. Specification Items OMY-3M DOF 6 Reach 580 [mm] Weight 13.5 [kg] Operating Voltage 24 [VDC] Joint Resolution -π(rad) ~ π(rad), -262,144 ~ 262,144 [pulse/rev] Joint Range Joint 1,2: ±360° Joint 3: ±150° Joint 4,5,6: ±360° DYNAMIXEL-Y Specification Joint 1,2: YM080-230-A099-RH Joint 3,4,5,6: YM070-210-A099-RH Repeatability ±0.05 [mm] Brake Force 200% of the continuous torque for each joint TCP Speed
Features Custom Manipulator Easy integration of 3rd-party components (such as hands, sensors, vision systems) depending on the working environment. Providing customizable development environment (C, C#, Python, etc.) via the DYNAMIXEL SDK. Plug-and-Play Realizing a perfect benchtop manipulator through a minimal footprint and lightweight design. Providing a robot control environment via an integrated controller (SBC) without the need for a separate PC. OpenSource Platform Delivering perfect compatibility with ROS2 and open-source support. Offering various packages and simulators (e.g., Movelt 2, Gazebo). Supporting development convenience through a dedicated OMY Control GUI. Specification Items OMY-3M DOF 6 Reach 580 [mm] Weight 13.5 [kg] Operating Voltage 24 [VDC] Joint Resolution -π(rad) ~ π(rad), -262,144 ~ 262,144 [pulse/rev] Joint Range Joint 1,2: ±360° Joint 3: ±150° Joint 4,5,6: ±360° DYNAMIXEL-Y Specification Joint 1,2: YM080-230-A099-RH Joint 3,4,5,6: YM070-210-A099-RH Repeatability ±0.05 [mm] Brake Force 200% of the continuous torque for each joint TCP Speed
История на цените
Една точка за всеки ден, осреднена според датата на наблюдение.
Суми в USD
Средните стойности се изчисляват за всеки ден по UTC от всички записани цени на офертите.
Robotis
13 923,95 €

Robotis
$11 498,85
Robotis
£9313,13

Robotis
$4834,51
Robotis
£11 145,87

Robotis
$14 373,85
Robotis
894,92 €
Robotis
17 272,96 €
Robotis
3291,60 €
Robotis
444 €
Robotis
157,95 €
Robotis
157,95 €
🍪 Предпочитания за бисквитките
Използваме бисквитки за измерване на ефективността. Политика за поверителност