Средна дневна цена
Суми в USD
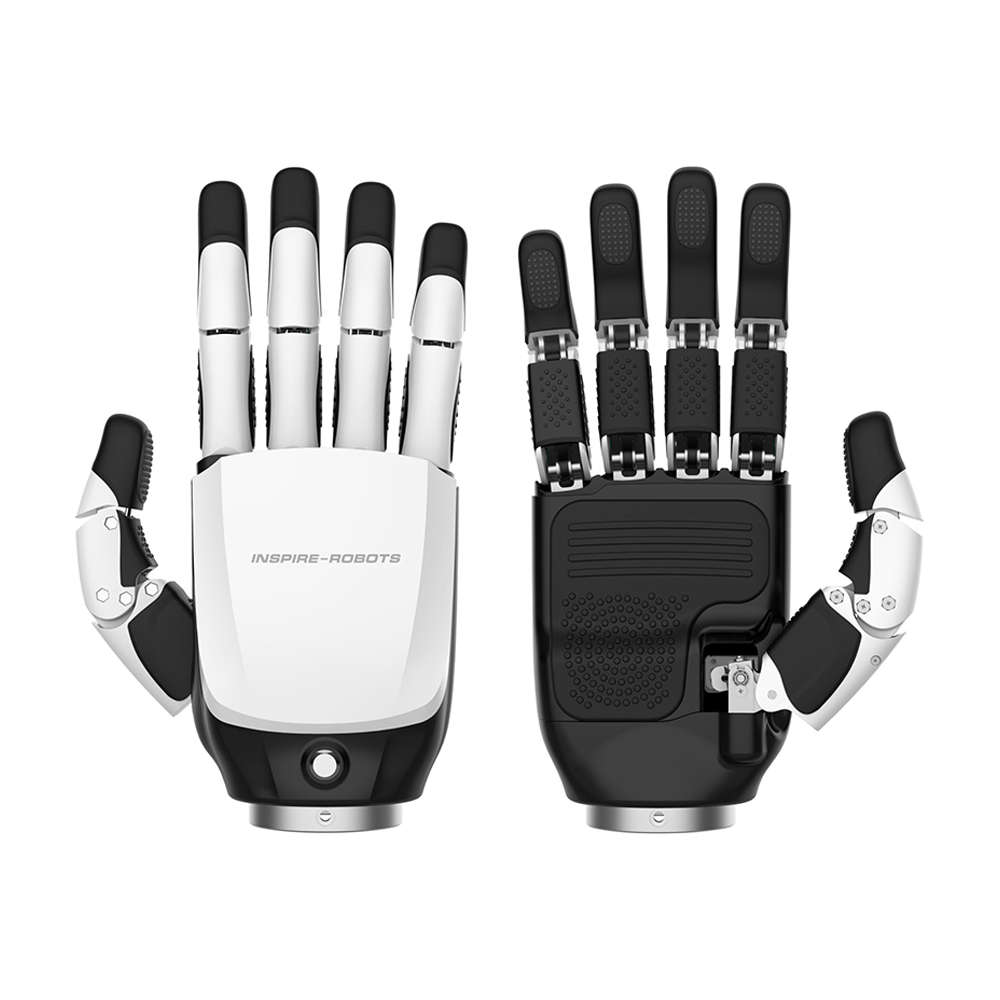
Описание
#html-body [data-pb-style=A6TL81Q],#html-body [data-pb-style=JY6J769],#html-body [data-pb-style=M451E47],#html-body [data-pb-style=U2U23ME],#html-body [data-pb-style=WMF2D59]{justify-content:flex-start;display:flex;flex-direction:column;background-position:left top;background-size:cover;background-repeat:no-repeat;background-attachment:scroll}The FTP series integrates 17 tactile sensor in a single hand,which setup allows real-time acquisition of tactile information from various parts, helping to optimize gripping actions and improve operational precision. The FTP series extended its lifespan to over a million, providing long-term reliable support.The fingertips can exert a force of up to 3 kg, making its gripping strength comparable to that of a human hand.<table border="1" cellpadding="6" cellspacing="0"> <thead> <tr> <th colspan="4">Comparison</th> </tr> <tr> <th>Robot Hands</th> <th> RH56DFTP-0L, RH56DFTP-0R (CAN)<br> RH56DFTP-2L, RH56DFTP-2R (RS485)<br> <span style="color:red;">(newest)</span> </th> <th> RH56DFX-2L<br> RH56DFX-2R<br> <span style="color:red;">(strong grip)</span> </th> <th> RH56BFX-2L<br> RH56BFX-2R<br> <span style="color:red;">(fast speed)</span> </th> </tr> </thead> <tbody> <tr><td>1. Side</td><td colspan="3">Left hand / Right hand</td></tr> <tr><td>2. Control interface</td><td>CAN + ModbusTCP (Optional: RS485)</td><td>RS485</td><td>RS485</td></tr> <tr><td>3. Degree of freedom</td><td>6</td><td>6</td><td>6</td></tr> <tr><td>4. Number of joints</td><td>12</td><td>12</td><td>12</td></tr> <tr><td>5. Weight</td><td>790±10g</td><td>540g</td><td>540g</td></tr> <tr><td>6. Operation Voltage</td><td>DC24V±10%</td><td>DC24V±10%</td><td>DC24V±10%</td></tr> <tr><td>7. Peak Current</td><td>4A</td><td>2A</td><td>2A</td></tr> <tr><td>8. Repeatability</td><td>±0.2mm</td><td>±0.2mm</td><td>±0.2mm</td></tr> <tr><td>9. Max finger grip force</td><td>30N</td><td>4N</td><td>10N</td></tr> <tr><td>10. Number of force sensors</td><td>6</td><td>6</td><td>6</td></tr> <tr><td>11. Number of tactile sensors</td><td style="color:red;">17</td><td>/</td><td>/</td></tr> <tr><td>12. Haptic data refresh rate</td><td>≥ 30Hz</td><td>/</td><td>/</td></tr> <tr><td>13. Thumb lateral rotation range</td><td>85°</td><td>65°</td><td>65°</td></tr> <tr><td>14. Angular velocity of thumb movement</td><td>130°/s</td><td>70°/s</td><td>150°/s</td></tr> <tr><td>15. Angular velocity of four-finger movement</td><td>200°/s</td><td>260°/s</td><td>570°/s</td></tr> <tr><td>16. Actuator</td><td colspan="3">6PCS micro actuator</td></tr> <tr><td>17. Max thumb grip</td><td style="color:red;">30N</td><td>15N</td><td>6N</td></tr> <tr><td>18. Max parm finger grip</td><td style="color:red;">30N</td><td>10N</td><td>4N</td></tr> <tr><td>19. Force resolution</td><td>25g (tactile sensor resolution)</td><td>0.5N</td><td>0.5N</td></tr> <tr><td>20. Thumb lateral rotation speed</td><td>130°/s</td><td>107°/s</td><td>235°/s</td></tr> <tr><td>21. Thumb bend speed</td><td>80°/s</td><td>70°/s</td><td>150°/s</td></tr> <tr><td>22. Palm finger bend speed</td><td>200°/s</td><td>260°/s</td><td>570°/s</td></tr> <tr> <td>Application</td> <td> Special Industries<br> Industrial Automation<br> Humanoid Robots<br> Welcome Reception<br> Unmanned Retail<br> Unmanned Laboratories<br> Education and Research<br> Elderly and Disabled Help </td> <td> Humanoid Robots<br> Welcome Reception<br> Unmanned Retail<br> Unmanned Laboratories<br> Education and Research<br> Elderly and Disabled Help </td> <td> Piano Playing<br> Gesture Interaction<br> Welcome Reception<br> Unmanned Laboratories<br> Education and Research </td> </tr> </tbody> </table>Software RH56DFTP Testing Software TCP Connection Check Connection Video Data Sheet RH56DFTP Brochure RH56DFTP Datasheet Other FTP_ROS2 2024-10-25 FTP_URDF_LEFT 2024-10-25 FTP_URDF_RIGHT 2024-10-25 FTP_Python Demo 2024-10-25 3D Files The FTP series integrates 17 tactile sensor in a single hand,which setup allows real-time acquisition of tactile information from various parts, helping to optimize gripping actions and improve operational precision. The FTP series extended its lifespan to over a million, providing long-term reliable support.The fingertips can exert a force of up to 3 kg, making its gripping strength comparable to that of a human hand. Choose the FTP series dexterous hands, ushering in a new era of smart manufacturing.
#html-body [data-pb-style=A6TL81Q],#html-body [data-pb-style=JY6J769],#html-body [data-pb-style=M451E47],#html-body [data-pb-style=U2U23ME],#html-body [data-pb-style=WMF2D59]{justify-content:flex-start;display:flex;flex-direction:column;background-position:left top;background-size:cover;background-repeat:no-repeat;background-attachment:scroll}The FTP series integrates 17 tactile sensor in a single hand,which setup allows real-time acquisition of tactile information from various parts, helping to optimize gripping actions and improve operational precision. The FTP series extended its lifespan to over a million, providing long-term reliable support.The fingertips can exert a force of up to 3 kg, making its gripping strength comparable to that of a human hand.<table border="1" cellpadding="6" cellspacing="0"> <thead> <tr> <th colspan="4">Comparison</th> </tr> <tr> <th>Robot Hands</th> <th> RH56DFTP-0L, RH56DFTP-0R (CAN)<br> RH56DFTP-2L, RH56DFTP-2R (RS485)<br> <span style="color:red;">(newest)</span> </th> <th> RH56DFX-2L<br> RH56DFX-2R<br> <span style="color:red;">(strong grip)</span> </th> <th> RH56BFX-2L<br> RH56BFX-2R<br> <span style="color:red;">(fast speed)</span> </th> </tr> </thead> <tbody> <tr><td>1. Side</td><td colspan="3">Left hand / Right hand</td></tr> <tr><td>2. Control interface</td><td>CAN + ModbusTCP (Optional: RS485)</td><td>RS485</td><td>RS485</td></tr> <tr><td>3. Degree of freedom</td><td>6</td><td>6</td><td>6</td></tr> <tr><td>4. Number of joints</td><td>12</td><td>12</td><td>12</td></tr> <tr><td>5. Weight</td><td>790±10g</td><td>540g</td><td>540g</td></tr> <tr><td>6. Operation Voltage</td><td>DC24V±10%</td><td>DC24V±10%</td><td>DC24V±10%</td></tr> <tr><td>7. Peak Current</td><td>4A</td><td>2A</td><td>2A</td></tr> <tr><td>8. Repeatability</td><td>±0.2mm</td><td>±0.2mm</td><td>±0.2mm</td></tr> <tr><td>9. Max finger grip force</td><td>30N</td><td>4N</td><td>10N</td></tr> <tr><td>10. Number of force sensors</td><td>6</td><td>6</td><td>6</td></tr> <tr><td>11. Number of tactile sensors</td><td style="color:red;">17</td><td>/</td><td>/</td></tr> <tr><td>12. Haptic data refresh rate</td><td>≥ 30Hz</td><td>/</td><td>/</td></tr> <tr><td>13. Thumb lateral rotation range</td><td>85°</td><td>65°</td><td>65°</td></tr> <tr><td>14. Angular velocity of thumb movement</td><td>130°/s</td><td>70°/s</td><td>150°/s</td></tr> <tr><td>15. Angular velocity of four-finger movement</td><td>200°/s</td><td>260°/s</td><td>570°/s</td></tr> <tr><td>16. Actuator</td><td colspan="3">6PCS micro actuator</td></tr> <tr><td>17. Max thumb grip</td><td style="color:red;">30N</td><td>15N</td><td>6N</td></tr> <tr><td>18. Max parm finger grip</td><td style="color:red;">30N</td><td>10N</td><td>4N</td></tr> <tr><td>19. Force resolution</td><td>25g (tactile sensor resolution)</td><td>0.5N</td><td>0.5N</td></tr> <tr><td>20. Thumb lateral rotation speed</td><td>130°/s</td><td>107°/s</td><td>235°/s</td></tr> <tr><td>21. Thumb bend speed</td><td>80°/s</td><td>70°/s</td><td>150°/s</td></tr> <tr><td>22. Palm finger bend speed</td><td>200°/s</td><td>260°/s</td><td>570°/s</td></tr> <tr> <td>Application</td> <td> Special Industries<br> Industrial Automation<br> Humanoid Robots<br> Welcome Reception<br> Unmanned Retail<br> Unmanned Laboratories<br> Education and Research<br> Elderly and Disabled Help </td> <td> Humanoid Robots<br> Welcome Reception<br> Unmanned Retail<br> Unmanned Laboratories<br> Education and Research<br> Elderly and Disabled Help </td> <td> Piano Playing<br> Gesture Interaction<br> Welcome Reception<br> Unmanned Laboratories<br> Education and Research </td> </tr> </tbody> </table>Software RH56DFTP Testing Software TCP Connection Check Connection Video Data Sheet RH56DFTP Brochure RH56DFTP Datasheet Other FTP_ROS2 2024-10-25 FTP_URDF_LEFT 2024-10-25 FTP_URDF_RIGHT 2024-10-25 FTP_Python Demo 2024-10-25 3D Files
История на цените
Една точка за всеки ден, осреднена според датата на наблюдение.
Суми в USD
Средните стойности се изчисляват за всеки ден по UTC от всички записани цени на офертите.

Inspire Robots
от $5600
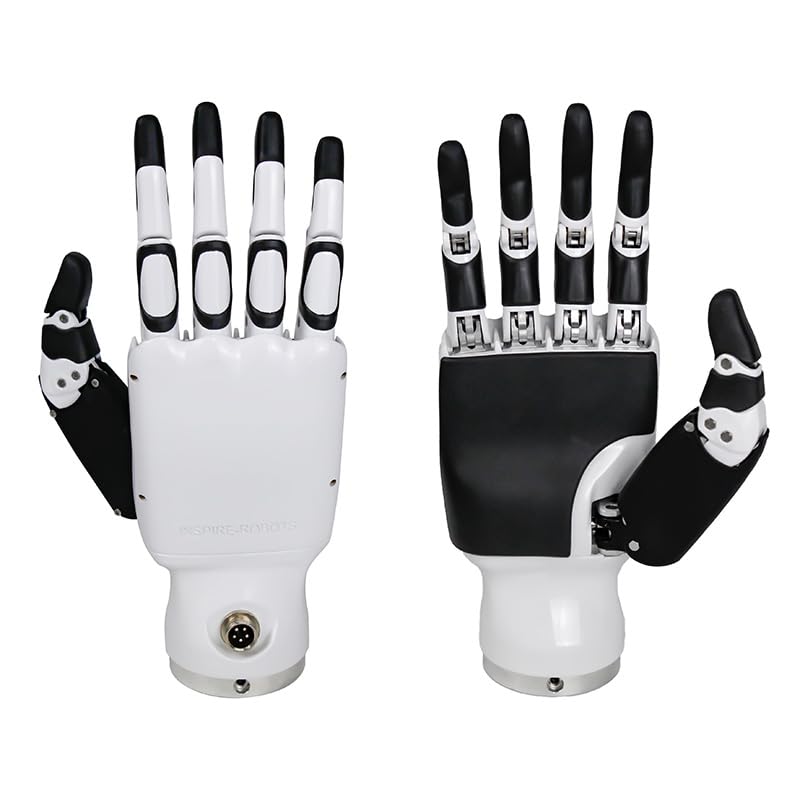
Inspire Robots
£4115,88
Inspire Robots
£4115,88

Inspire Robots
$4500

Inspire Robots
$4500

Inspire Robots
$6294

Inspire Robots
$6294

Inspire Robots
5900 €

Inspire Robots
от $6500

Inspire Robots
от $5750

Inspire Robots
от $4500

Inspire Robots
$7500
🍪 Предпочитания за бисквитките
Използваме бисквитки за измерване на ефективността. Политика за поверителност