أبحاث Papers

ملخصات مبسّطة باللغة الإنجليزية لأحدث أبحاث الروبوتات — الروبوتات الشبيهة بالبشر، والروبوتات رباعية الأرجل، والأتمتة الصناعية، والذكاء الاصطناعي.
499 أبحاث
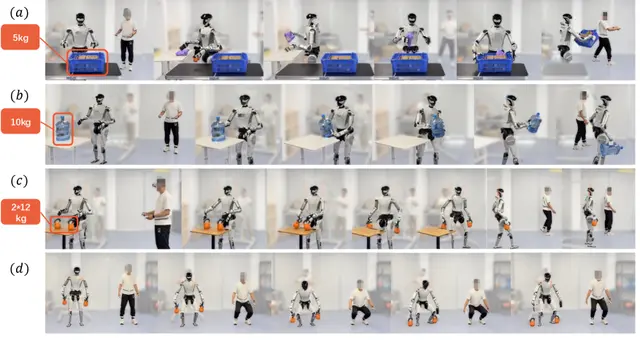
HEFT Enables Full-Size Humanoid Robots to Lift 24 kg During Teleoperation
Humanoid6 يوليو

HEFT Enables Full-Size Humanoid Robots to Lift 24 kg During Teleoperation

HEFT enables a full-size humanoid to carry 24 kg while being teleoperated via VR, using a motion-adaptive payload curriculum and privileged training.

Chenxin Liu, Qingzhou Lu, Guangxiao Yang, Xuanyang Shi +3

ACID Framework Boosts Robotic Planning With Action Consistency Check
AI5 يوليو

ACID Framework Boosts Robotic Planning With Action Consistency Check

A new decision-time planning framework called ACID adds a simple action consistency check to world model–based planning, improving control quality across rig…

Gawon Seo, Dongwon Kim, Suha Kwak

LIME Teaches Robots Where to Look Based on Language Intent
AI5 يوليو

LIME Teaches Robots Where to Look Based on Language Intent

Researchers have built LIME, an AI model that predicts where a camera should aim next based on natural-language instructions. By learning human-like camera m…

Boyang Sun, Jiajie Li, Yung-Hsu Yang +6

WorldSample Boosts Real Robot Learning with World Model Data Augmentation
AI5 يوليو

WorldSample Boosts Real Robot Learning with World Model Data Augmentation

Yuquan Xue, Le Xu, Zeyi Liu +5

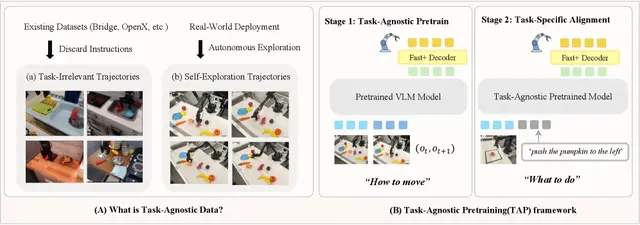
Task-Agnostic Pretraining: Teaching Robots to Move Before Teaching Tasks
AI4 يوليو

Task-Agnostic Pretraining: Teaching Robots to Move Before Teaching Tasks

Junhao Shi, Siyin Wang, Xiaopeng Yu +3

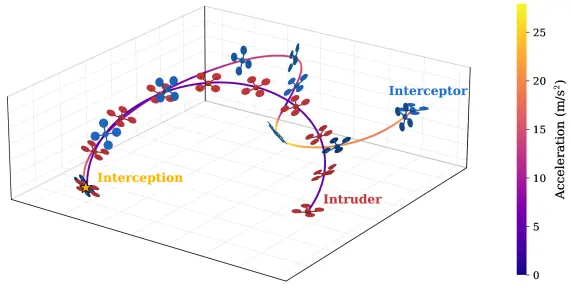
Differentiable Simulation Trains Drones to Intercept Intruders Using Only Direction
Robotics4 يوليو

Differentiable Simulation Trains Drones to Intercept Intruders Using Only Direction
Researchers at RISC Lab have developed a quadrotor interception policy that tracks and catches an intruder drone using only the direction to the target—no di…

Michael Anoruo, Xiaoyu Tian, Abhishek Rathod +5

QuadRocket Testbed Uses a Drone to Control a Rocket-Like Flying Pendulum
drones4 يوليو

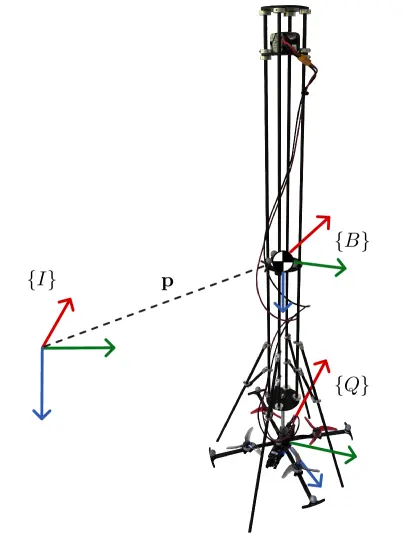
QuadRocket Testbed Uses a Drone to Control a Rocket-Like Flying Pendulum

QuadRocket uses a quadrotor attached via universal joint to control a rocket-like body, enabling low-cost indoor thrust-vector control experiments.

Pedro Santos, Joel Reis, Paulo Oliveira +1

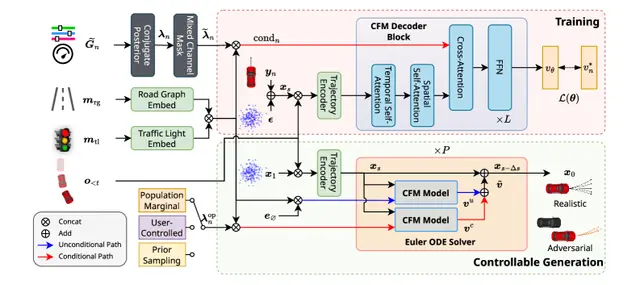
Controllable Traffic Agents Learn Steering Behaviors From Latent Variables
AI3 يوليو

Controllable Traffic Agents Learn Steering Behaviors From Latent Variables

Juanwu Lu, Junyu Zhu, Ziran Wang

Embodied.cpp Enables Efficient C++ Inference for Embodied AI on Heterogeneous Robots
Robotics3 يوليو

Embodied.cpp Enables Efficient C++ Inference for Embodied AI on Heterogeneous Robots
Ling Xu, Chuyu Han, Borui Li +6

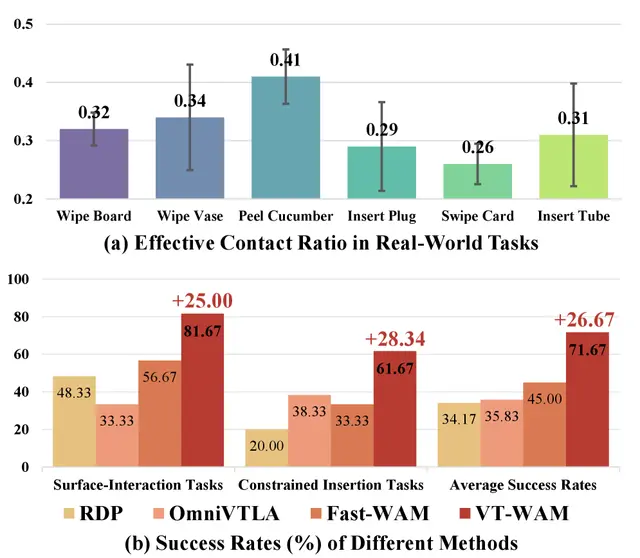
Visual-Tactile World Action Model for Contact-Rich Manipulation
Robotics3 يوليو

Visual-Tactile World Action Model for Contact-Rich Manipulation

VT-WAM couples tactile deformation dynamics with action prediction using joint visual-tactile-action flow matching for contact-rich manipulation

Shuai Tian, Yupeng Zheng, Yuhang Zheng +7

Sensorless Teleoperation Uses Inverse Dynamics for Transparent Control
Robotics2 يوليو

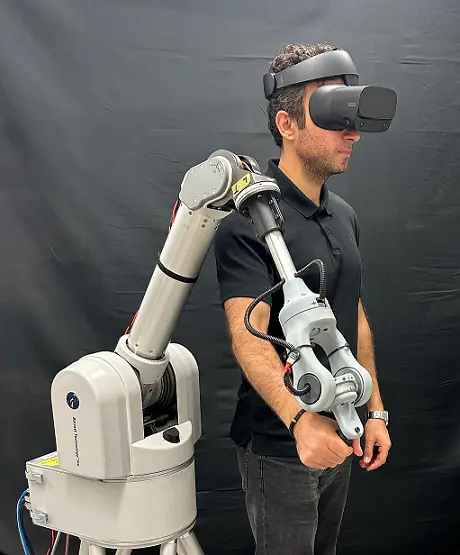
Sensorless Teleoperation Uses Inverse Dynamics for Transparent Control

A new control architecture for human-scale bilateral teleoperation eliminates force/torque sensors by using inverse dynamics modeling to estimate external fo…

Amir Noohian, Dylan Miller, Justin Valentine +2

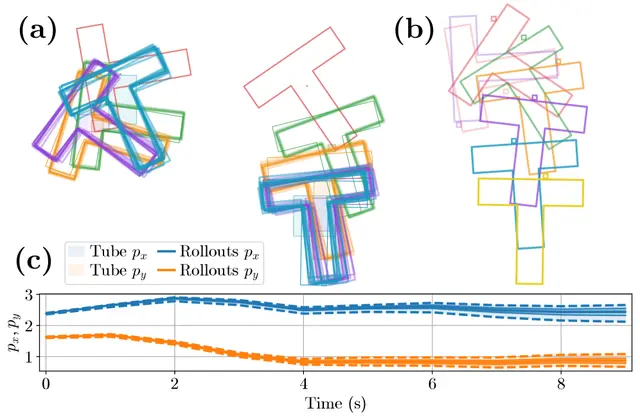
GPU-Parallel Linearization Error Bounds for Real-Time Robust Optimal Control of Nonlinear and Neural Network Dynamics
AI2 يوليو

GPU-Parallel Linearization Error Bounds for Real-Time Robust Optimal Control of Nonlinear and Neural Network Dynamics

Jeffrey Fang, Keyi Shen, Anutam Srinivasan +1

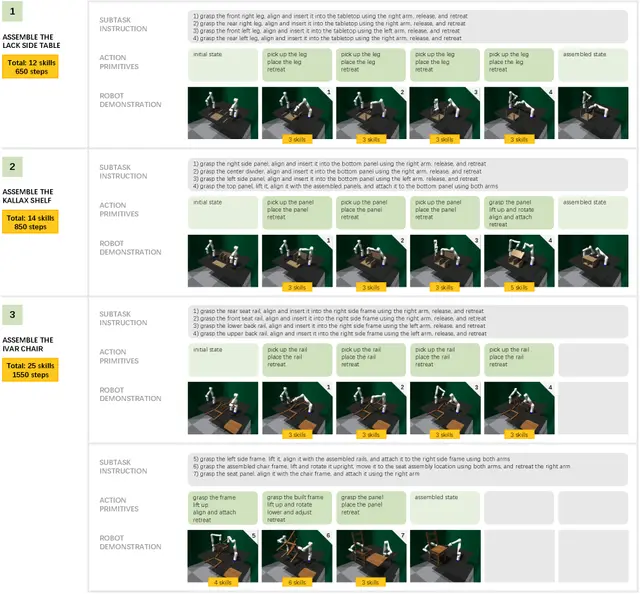
FurnitureVLA: Teaching Robots to Assemble IKEA Furniture Using Vision-Language-Action Models
AI2 يوليو

FurnitureVLA: Teaching Robots to Assemble IKEA Furniture Using Vision-Language-Action Models
Chenyang Ma, Yue Yang, Radu Corcodel +4

PrimeU: Humanoid Robot That Learns Tasks by Watching Human Videos
Humanoid1 يوليو

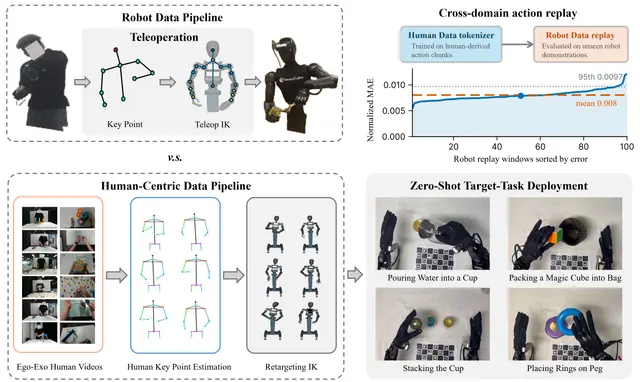
PrimeU: Humanoid Robot That Learns Tasks by Watching Human Videos

Human-aligned humanoid PrimeU learns manipulation tasks from ordinary human videos using PhysDex, reducing robot data needs by orders of magnitude.

Xiaopeng Lin, Ruoqi Yang, Shijie Lian +14

Freeform Preferences Help Robots Learn From Human Feedback Without Rigid Ratings
AI1 يوليو

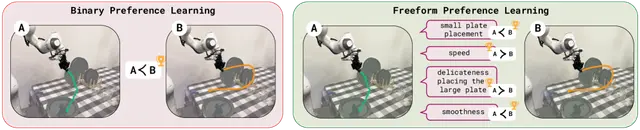
Freeform Preferences Help Robots Learn From Human Feedback Without Rigid Ratings

Learning robot policies from human preferences traditionally forces annotators to give a single binary score comparing two trajectories, collapsing complex j…

Marcel Torne, Anubha Mahajan, Abhijnya Bhat +1

Disentangled Video World Model Speeds Robotic Planning Without Sacrificing Quality
Robotics1 يوليو

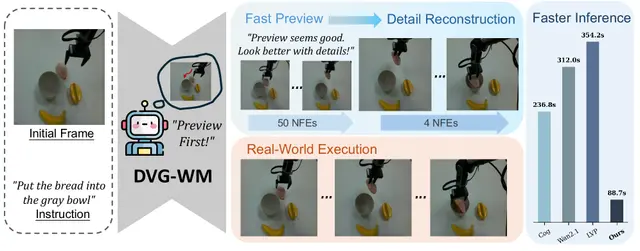
Disentangled Video World Model Speeds Robotic Planning Without Sacrificing Quality
Ziyu Shan, Zhenyu Wu, Xiaofeng Wang +2

Sequential Planning via Anchored Robotic Keypoints: Training-Free Robot Manipulation
Robotics30 يونيو

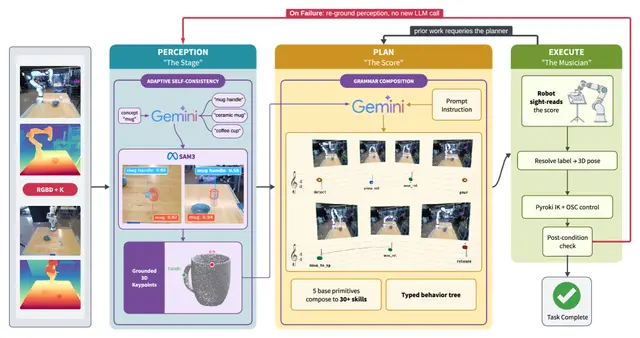
Sequential Planning via Anchored Robotic Keypoints: Training-Free Robot Manipulation
Bryce Grant, Aryeh Rothenberg, Logan Senning +3

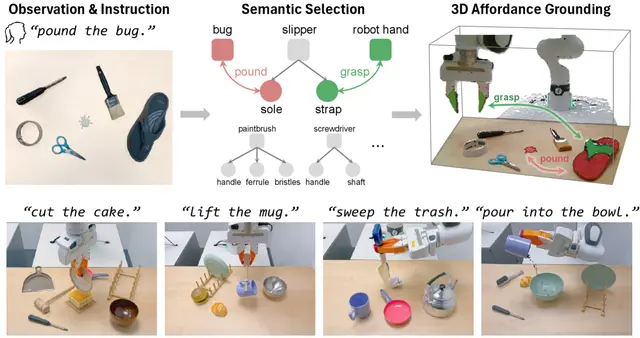
GROW²: Teaching Robots to Select Tools and Find Their Functional Regions
AI30 يونيو

GROW²: Teaching Robots to Select Tools and Find Their Functional Regions

GROW² enables robots to pick the best improvised tool from a cluttered scene and find its functional region using vision-language models and 3D reconstruction.

Yuhong Deng, Yuyao Liu, David Hsu

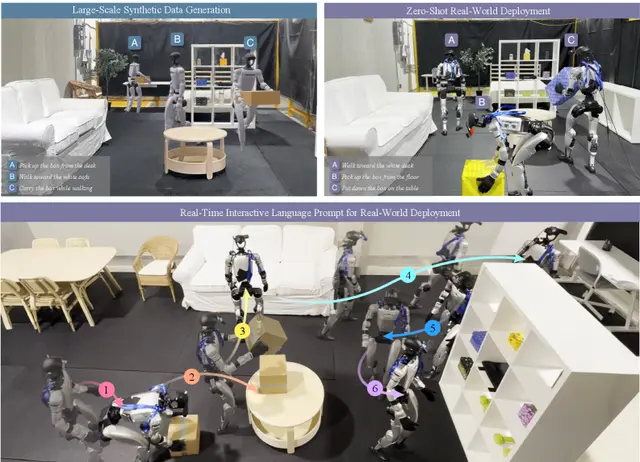
Vision-Language-Kinematics: Learning Humanoid Loco-Manipulation from Synthetic Interactions in Reconstructed 3D Scenes
Humanoid30 يونيو

Vision-Language-Kinematics: Learning Humanoid Loco-Manipulation from Synthetic Interactions in Reconstructed 3D Scenes

Connecting egocentric observations to whole-body action is a fundamental challenge for humanoid robots operating in human-centered environments. A humanoid m…

Yen-Jen Wang, Jiaman Li, Sirui Chen +9

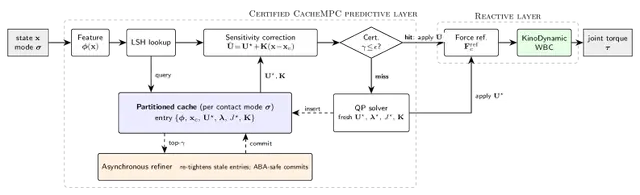
CacheMPC: Certified Cached Model Predictive Control for Quadruped Locomotion
Robotics29 يونيو

CacheMPC: Certified Cached Model Predictive Control for Quadruped Locomotion

Nimesh Khandelwal, Mehul Anand, Shakti S. Gupta +1