متوسط السعر اليومي
المبالغ بعملة USD


The R1 EDU platform supports secondary development, fully open joint and sensor control interfaces, and mainstream simulation platforms. The EDU configuration also supports high-power computing modules in the 40–100 TOPS range.
With two Unitree tendon-driven dexterous hands, the U10 configuration adds 2 actuated degrees of freedom per hand to the 26-DOF R1 EDU base, for 30 total actuated degrees of freedom.
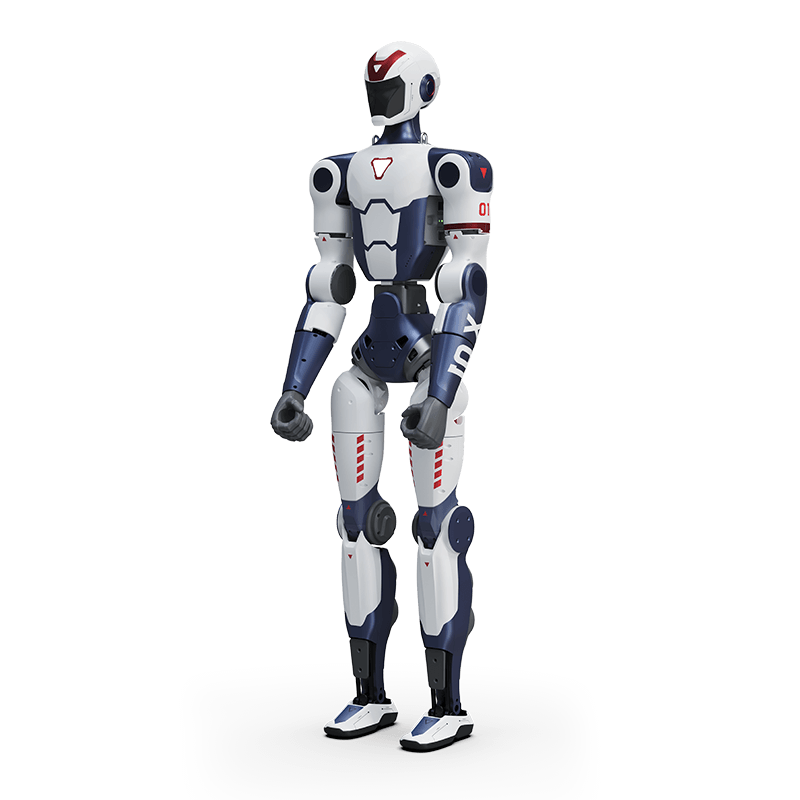
R1 EDU combines open development interfaces, high-performance computing, binocular perception, and optional dexterous manipulation hardware.
R1 EDU supports secondary development with open interfaces for robot joints and sensors.
The EDU platform supports high-power computing modules, including configurations up to 100 TOPS.
Each Unitree tendon-driven dexterous hand provides 2 actuated degrees of freedom with hidden internal wiring and compatibility with R1.
R1 EDU uses a binocular camera for onboard visual perception.
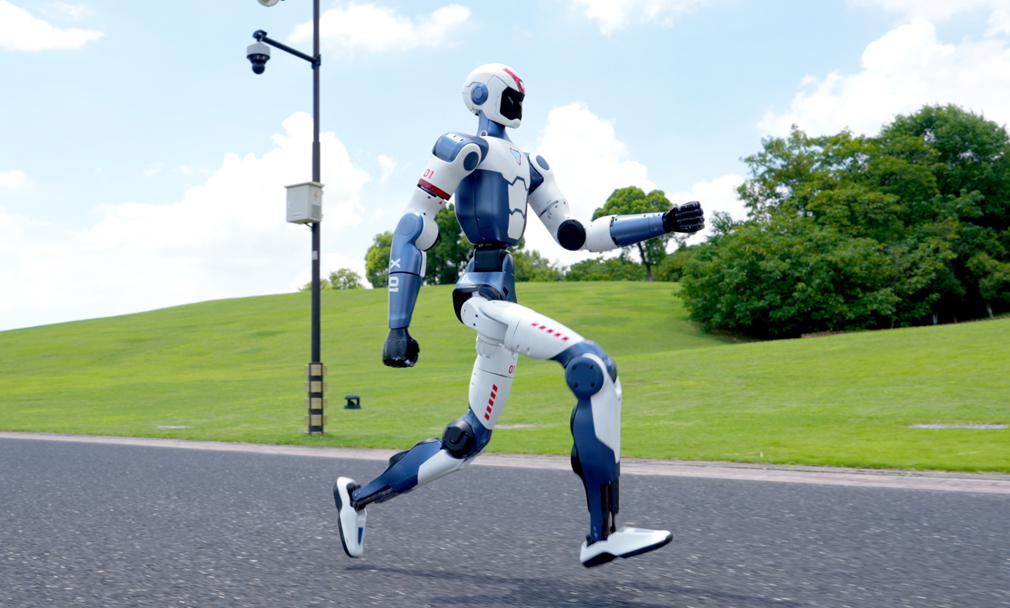

The R1 EDU base provides 26 joint degrees of freedom. Two Unitree Dex2/5 tendon-driven hands add 2 actuated degrees of freedom per hand.
R1 EDU combines an 8-core high-performance processor with optional high-power computing modules, binocular vision, open development interfaces, and support for mainstream simulation platforms.
Research-oriented R1 EDU configuration with high-power computing and dual dexterous hands.
| Specification | R1 EDU U10 |
|---|---|
| Dimensions (H × W × D), Standing | 47.6 × 14.1 × 7.5 in |
| Weight With Battery | Approx. 63.9 lbs |
| Total Degrees of Freedom | 26 |
| Degrees of Freedom Per Leg | 6 |
| Degrees of Freedom at Waist | 2 |
| Degrees of Freedom Per Arm | 5 |
| Degrees of Freedom at Head | 2 |
| Maximum Arm Load | 4.4 lbs |
| Calf + Thigh Length | 23.6 in |
| Arm Reach | Approx. 16.5 in |
| Waist Joint Range | Y: ±150° R: ±30° |
| Knee Joint Range | -10° to +139° |
| Hip Joint Range | Y: ±157° P: -168° to +146° R: -60° to +100° |
| Hollow Internal Wiring | Yes, throughout all joints |
| Joint Encoders | Dual + single encoders |
| Cooling System | Localized air cooling |
| Power Supply | Lithium-ion battery |
| Base Computing Power | 8-core high-performance CPU |
| Audio | Standard speakers and microphone array |
| Wireless Connectivity | Wi-Fi 6, Bluetooth 5.2 |
| Perception Sensors | Standard humanoid stereo camera; optional R1 LiDAR kit available |
| Included Power Accessories | 1 charger, 1 smart battery (quick-release) |
| Handheld Remote Control | 1 included |
| Battery Life | Approx. 1 hour |
| Smart OTA Updates | Supported |
| Customization | Available |
| Secondary Development | Supports both high-level and low-level customization; provides robot models and simulation interfaces; supports simulation environments such as Isaac Sim |
| Built-in Computing Docking Station | 40 TOPS, open to secondary development, with AI algorithm technical support |
| Development Support | Technical support services, comprehensive development manuals, and ecosystem support |
| Warranty | 12 months |
| Robot Accessories | Remote control, charger, robot transport case |
| Protective Mount | Not included by default |
| R1 EDU U10 Configuration | Includes all features of the R1 EDU Smart Edition |
| Dexterous Hands | 2 tendon-cable dexterous hands |
| Dexterous Hand DOF Per Hand | 2 |
| Total Robot Degrees of Freedom With Dexterous Hands | 30 (26 + 2 + 2) |
| Upgraded Computing Docking Station | 100 TOPS; supports secondary development and includes AI algorithm technical support |
| Simulation & Development Support | Supports high-level and low-level secondary development, robot models, simulation interfaces, and simulation environments such as Isaac Sim |
| Technical & Ecosystem Support | Technical support services, comprehensive development manuals, and ecosystem support |
| U10 Perception Sensors | Standard anthropomorphic stereo camera; optional R1 LiDAR kit available |
| Dexterous Hand Wiring | No external wiring between the dexterous hands and the robot |
| Wrist Camera | Not included |
| U10 Warranty | 12 months |
| U10 Protective Mount | Not included by default |
The R1 EDU platform supports secondary development, fully open joint and sensor control interfaces, and mainstream simulation platforms. The EDU configuration also supports high-power computing modules in the 40–100 TOPS range.
With two Unitree tendon-driven dexterous hands, the U10 configuration adds 2 actuated degrees of freedom per hand to the 26-DOF R1 EDU base, for 30 total actuated degrees of freedom.
R1 EDU combines open development interfaces, high-performance computing, binocular perception, and optional dexterous manipulation hardware.
R1 EDU supports secondary development with open interfaces for robot joints and sensors.
The EDU platform supports high-power computing modules, including configurations up to 100 TOPS.
Each Unitree tendon-driven dexterous hand provides 2 actuated degrees of freedom with hidden internal wiring and compatibility with R1.
R1 EDU uses a binocular camera for onboard visual perception.
The R1 EDU base provides 26 joint degrees of freedom. Two Unitree Dex2/5 tendon-driven hands add 2 actuated degrees of freedom per hand.
R1 EDU combines an 8-core high-performance processor with optional high-power computing modules, binocular vision, open development interfaces, and support for mainstream simulation platforms.
Research-oriented R1 EDU configuration with high-power computing and dual dexterous hands.
| Specification | R1 EDU U10 |
|---|---|
| Dimensions (H × W × D), Standing | 47.6 × 14.1 × 7.5 in |
| Weight With Battery | Approx. 63.9 lbs |
| Total Degrees of Freedom | 26 |
| Degrees of Freedom Per Leg | 6 |
| Degrees of Freedom at Waist | 2 |
| Degrees of Freedom Per Arm | 5 |
| Degrees of Freedom at Head | 2 |
| Maximum Arm Load | 4.4 lbs |
| Calf + Thigh Length | 23.6 in |
| Arm Reach | Approx. 16.5 in |
| Waist Joint Range | Y: ±150° R: ±30° |
| Knee Joint Range | -10° to +139° |
| Hip Joint Range | Y: ±157° P: -168° to +146° R: -60° to +100° |
| Hollow Internal Wiring | Yes, throughout all joints |
| Joint Encoders | Dual + single encoders |
| Cooling System | Localized air cooling |
| Power Supply | Lithium-ion battery |
| Base Computing Power | 8-core high-performance CPU |
| Audio | Standard speakers and microphone array |
| Wireless Connectivity | Wi-Fi 6, Bluetooth 5.2 |
| Perception Sensors | Standard humanoid stereo camera; optional R1 LiDAR kit available |
| Included Power Accessories | 1 charger, 1 smart battery (quick-release) |
| Handheld Remote Control | 1 included |
| Battery Life | Approx. 1 hour |
| Smart OTA Updates | Supported |
| Customization | Available |
| Secondary Development | Supports both high-level and low-level customization; provides robot models and simulation interfaces; supports simulation environments such as Isaac Sim |
| Built-in Computing Docking Station | 40 TOPS, open to secondary development, with AI algorithm technical support |
| Development Support | Technical support services, comprehensive development manuals, and ecosystem support |
| Warranty | 12 months |
| Robot Accessories | Remote control, charger, robot transport case |
| Protective Mount | Not included by default |
| R1 EDU U10 Configuration | Includes all features of the R1 EDU Smart Edition |
| Dexterous Hands | 2 tendon-cable dexterous hands |
| Dexterous Hand DOF Per Hand | 2 |
| Total Robot Degrees of Freedom With Dexterous Hands | 30 (26 + 2 + 2) |
| Upgraded Computing Docking Station | 100 TOPS; supports secondary development and includes AI algorithm technical support |
| Simulation & Development Support | Supports high-level and low-level secondary development, robot models, simulation interfaces, and simulation environments such as Isaac Sim |
| Technical & Ecosystem Support | Technical support services, comprehensive development manuals, and ecosystem support |
| U10 Perception Sensors | Standard anthropomorphic stereo camera; optional R1 LiDAR kit available |
| Dexterous Hand Wiring | No external wiring between the dexterous hands and the robot |
| Wrist Camera | Not included |
| U10 Warranty | 12 months |
| U10 Protective Mount | Not included by default |


سجل الأسعار
نقطة بيانات واحدة لكل يوم، محسوبة بمتوسط الأسعار المرصودة في ذلك اليوم.
المبالغ بعملة USD
تُحسب المتوسطات لكل يوم وفق التوقيت العالمي المنسق، استنادًا إلى أسعار جميع العروض المسجلة.

Unitree
$22,900
Unitree
$23,200

Unitree
$21,790
Unitree
$21,090
Unitree
$21,890
Unitree
$23,890
Unitree
$23,190
Unitree
$22,390
Unitree
$21,690
Unitree
$22,490
Unitree
$24,490
Unitree
$23,790
🍪 تفضيلات ملفات تعريف الارتباط
نستخدم ملفات تعريف الارتباط لقياس الأداء. سياسة الخصوصية