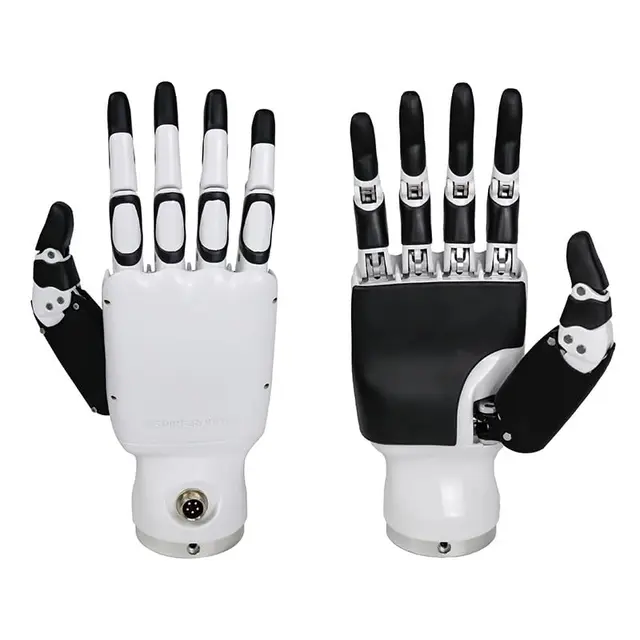
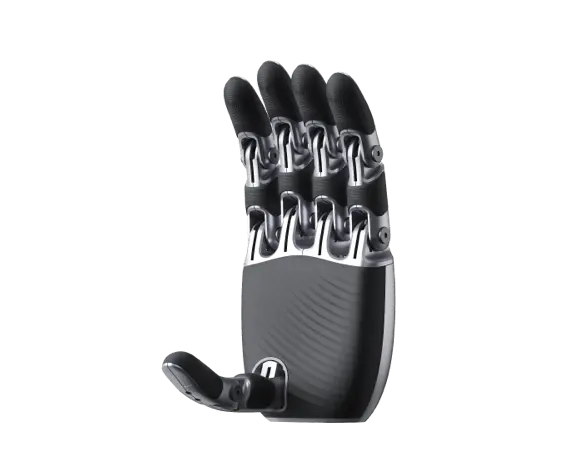
The DexRobot DexHand021 S is a three-finger dexterous robotic hand for robot arms, research benches and teaching labs. It has 8 degrees of freedom, weighs 0.6 kg and measures 208 × 80 × 82.8 mm, and DexRobot designed it to cover about 80 % of what a five-finger hand does at a cost-effective price.
A gear, tendon and linkage transmission gives the same fingers at least 20 N at the fingertip, 45 N at the finger pad and 100 N at the finger root. Three fingers lift 2.5 kg palm down at rated load and 5 kg at maximum, repeat to ±0.5 mm and grasp objects 30 mm across or smaller. Torque adjusts steplessly from 0 to 1 A, so the hand adapts to spheres and irregular objects and can screw, plug and unplug parts.
Joint position sensing and a 5 MP palm camera (30 fps, 76° field of view, objects from 6 cm) are standard, and the camera supports visual-servo grasping. Capacitive tactile sensing is an option: normal force from 0 to 20 N at 0.1 N resolution and ±2 % full-scale accuracy, tangential force at 0.25 N with 45° direction resolution and proximity from 1 cm, sampled at 50 Hz or faster. The hand runs on DC 24 V (0.13 A at rest, 2 A maximum), connects over CAN FD or RS485, comes with an open-source SDK and is rated for 200,000 cycles. DexRobot names research, education and maker projects, interactive robots and industrial and agricultural work such as fruit and vegetable picking among its uses.
For five fingers, the DexHand021 MP has 19 degrees of freedom, fingertip tactile sensing and a 5 kg hand load, and the DexHand021 Pro adds an integrated wrist and 22 degrees of freedom. Browse our dexterous robotic hands for other three- and five-finger designs.
Key Capabilities
-
Three fingers, 8 degrees of freedom: DexRobot designed the 021 S to cover about 80 % of what a five-finger hand does, from spheres and irregular objects to screwing, plugging and unplugging.
-
0.6 kg on the arm: At 0.6 kg and 208 × 80 × 82.8 mm, the hand adds little weight to the end of a collaborative arm.
-
Gear, tendon and linkage drive: Three transmissions work together to give at least 20 N at the fingertip, 45 N at the finger pad and 100 N at the finger root.
-
2.5 kg rated, 5 kg maximum: Three fingers lift 2.5 kg palm down at rated load and up to 5 kg at maximum, repeating to ±0.5 mm.
-
Palm camera for visual servoing: A 5 MP palm camera at 30 fps with a 76° field of view guides visual-servo grasping, alongside joint position sensing.
-
Optional tactile fingertips: Capacitive sensing adds normal force from 0 to 20 N at 0.1 N resolution, tangential force and proximity from 1 cm.
-
CAN FD or RS485, open SDK: The hand runs on DC 24 V, connects over CAN FD or RS485 and comes with an open-source SDK for your own control code.
Buying through Robotix Market
This unit is sourced new through established distribution channels and ships worldwide with the manufacturer warranty. Technical support is coordinated with the manufacturer's own service network. Deployment scope, configuration, and commissioning responsibilities are agreed as part of the quotation — on-site installation is not included in the product price.